

UAV Trajectory Planning for Refined Inspection of Distribution Network Power Towers Using Multi-strategy Improved Particle Swarm Optimization
-
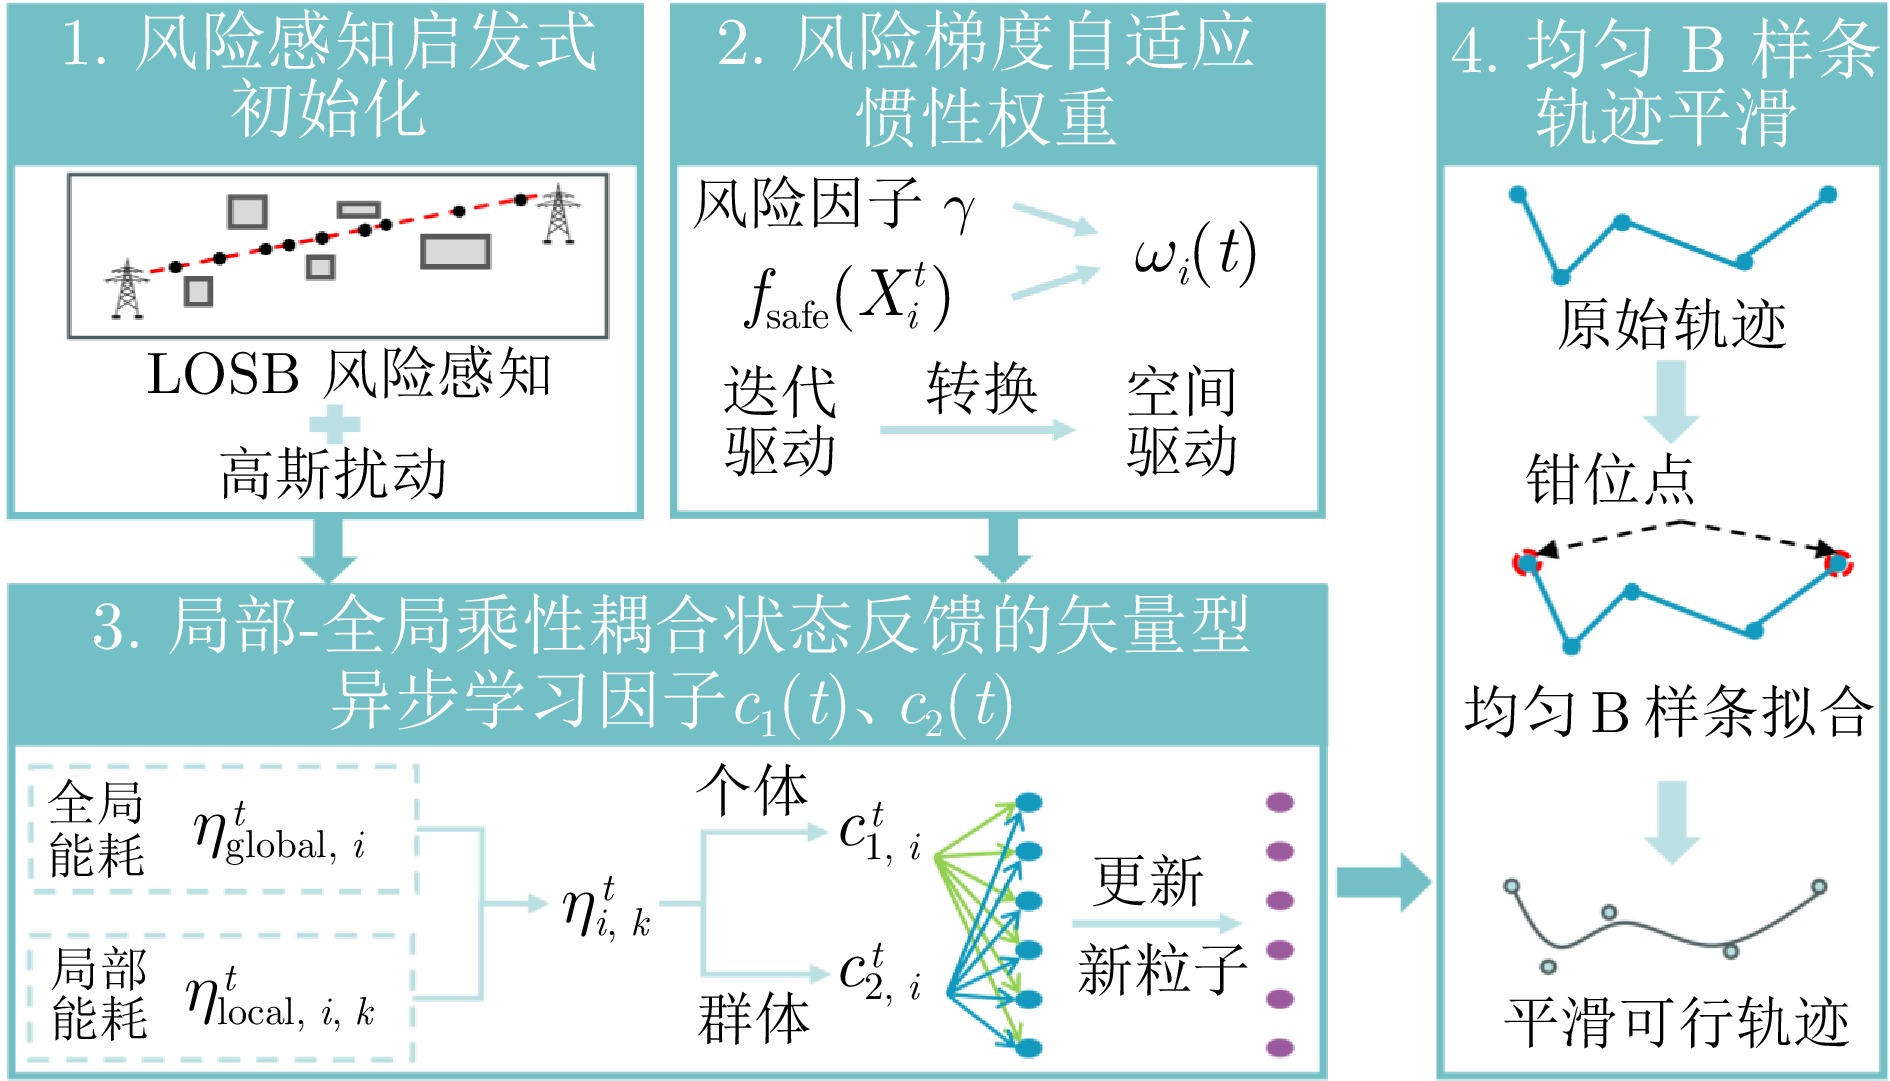
摘要: 针对老旧城区等复杂环境下无人机配电网系统巡检面临的高维多约束轨迹优化难的问题, 提出一种基于多策略优化的改进粒子群轨迹规划算法. 首先, 在多重观测约束下离线生成安全检测视点, 并融合叶素-动量理论构建精准的无人机运动能耗模型. 其次, 设计一种双层解耦的轨迹规划框架, 实现无人机巡检轨迹的快速高效优化. 其中, 上层通过全排列穷举确定最优安全巡检视点的访问序列; 下层规划框架中构建基于风险梯度驱动的惯性权重调节模型, 并将标量学习因子拓展为与采样轨迹点同长度的矢量型学习因子, 采用局部-全局耦合状态信息自适应调节学习因子的强度. 最终输出满足避碰约束的均匀三次B样条平滑轨迹. 仿真与对比验证结果表明, 所提算法在综合能效、空间平滑度、收敛速度及实时性指标上均显著优于其它群体智能优化方法.Abstract: To address the challenge of high-dimensional, multi-constrained trajectory optimization for unmanned aerial vehicle (UAV) inspection of distribution network systems in complex environments such as old urban areas, this paper proposes an improved particle swarm trajectory planning algorithm based on multi-strategy optimization. First, safe inspection viewpoints are generated offline under multiple observation constraints, and an accurate UAV motion energy consumption model is constructed by integrating the blade element momentum theory. Second, a two-layer decoupled trajectory planning framework is designed to achieve fast and efficient optimization of UAV inspection trajectories. In the upper layer, the optimal access sequence of safe inspection viewpoints is determined through full-permutation exhaustive enumeration. In the lower planning framework, a risk gradient-driven inertia weight adjustment model is developed, and the scalar learning factors are extended to vector-type learning factors with the same length as the sampled trajectory points, where the intensity of the learning factors is adaptively regulated using local-global coupled state information. Finally, a collision-free smooth trajectory based on uniform cubic B-spline is output. Simulation and comparative validation results verify that the proposed algorithm significantly outperforms other swarm intelligence optimization methods in terms of comprehensive energy efficiency, spatial smoothness, convergence speed, and real-time performance.
-
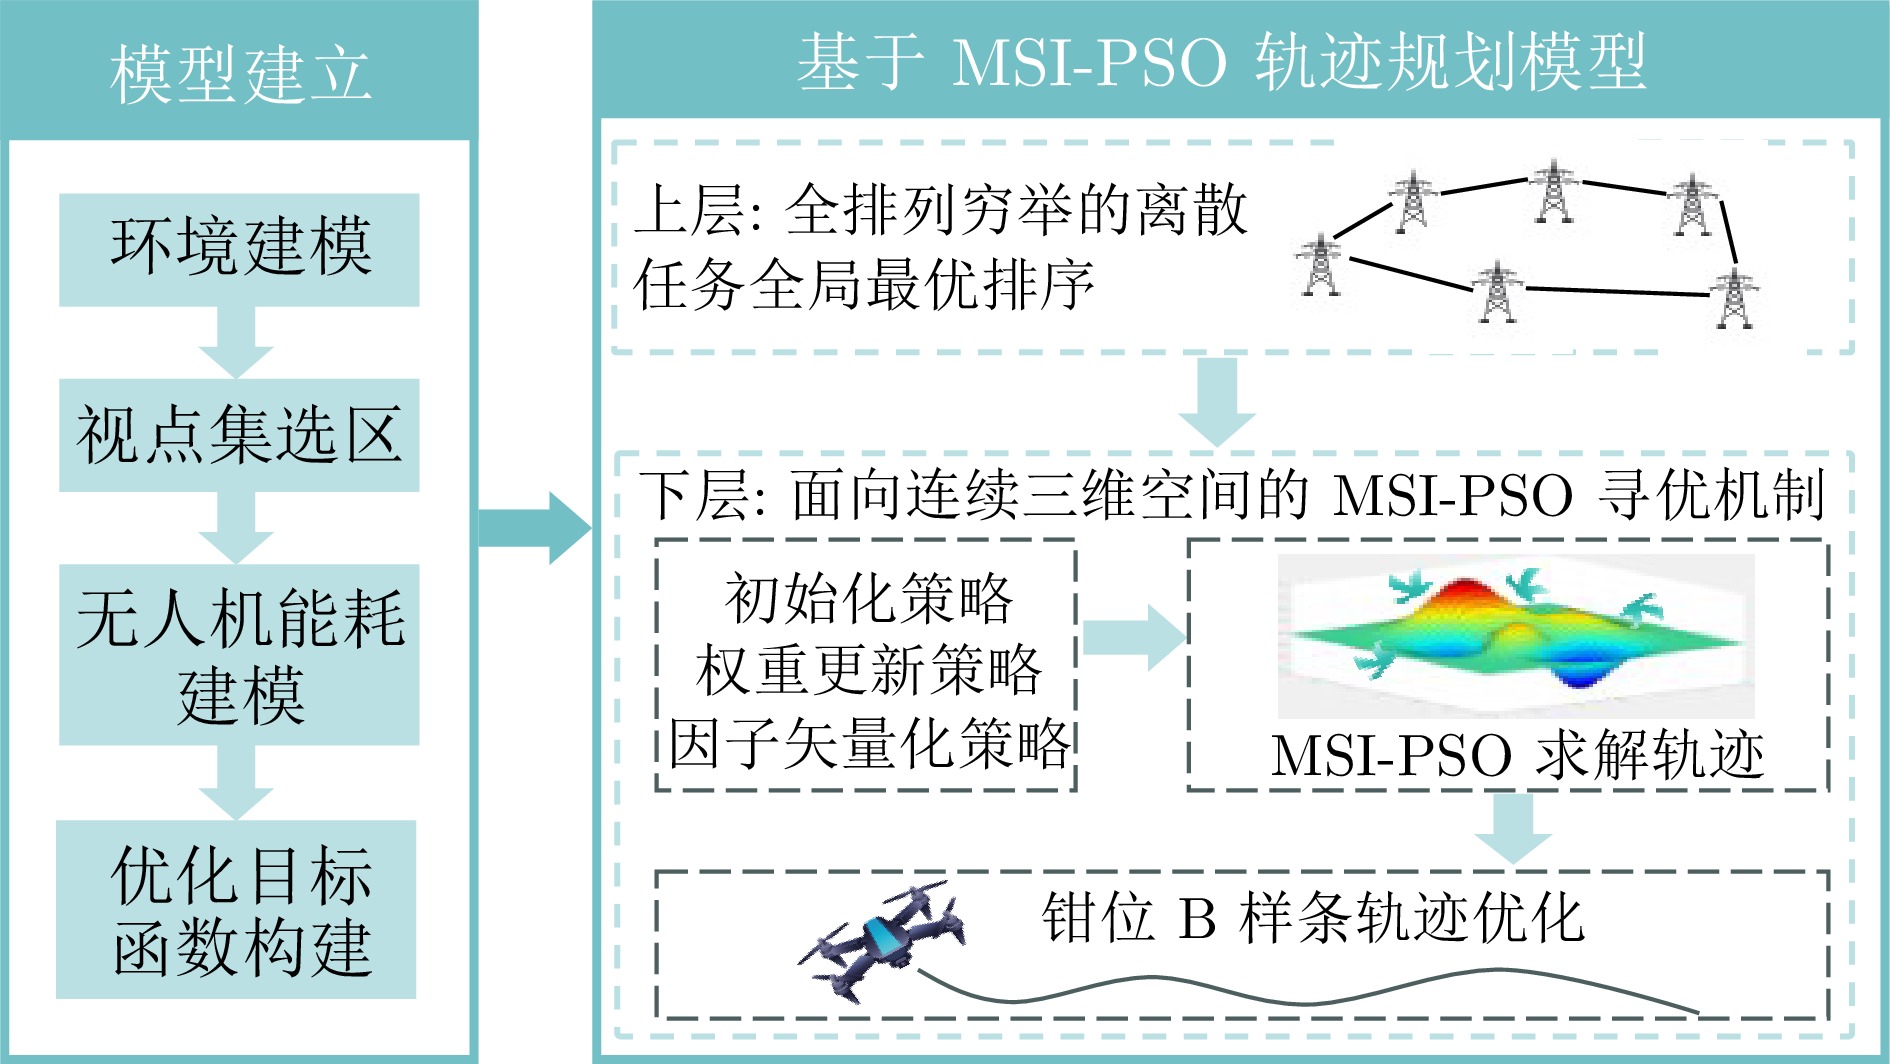
图 1 配电网精细化巡检框架图
Fig. 1 Detailed inspection framework diagram of the distribution network
表 1 无人机能耗相关物理参数定义
Table 1 Definition of physical parameters related to UAV energy consumption
符号 物理意义 单位 $ P_r $ 无人机悬停状态下的型阻功率 W $ P_p $ 无人机悬停状态下的诱导功率 W $ V_h $ 无人机的水平前飞速度 m/s $ V_z $ 无人机的垂直爬升速度 m/s $ U_{tip} $ 旋翼叶尖线速度 m/s $ v_0 $ 无人机悬停状态下的平均诱导气流速度 m/s $ d_0 $ 机身废阻力系数(与机身气动外形相关) – $ \rho $ 飞行环境的空气密度 kg/m$ ^3 $ $ s $ 旋翼实度(桨叶总面积/旋翼盘面积) – $ A $ 无人机旋翼盘正投影面积 m$ ^2 $ $ m $ 无人机整机及载荷总质量 kg $ g $ 重力加速度 m/s$ ^2 $  下载: 导出CSV
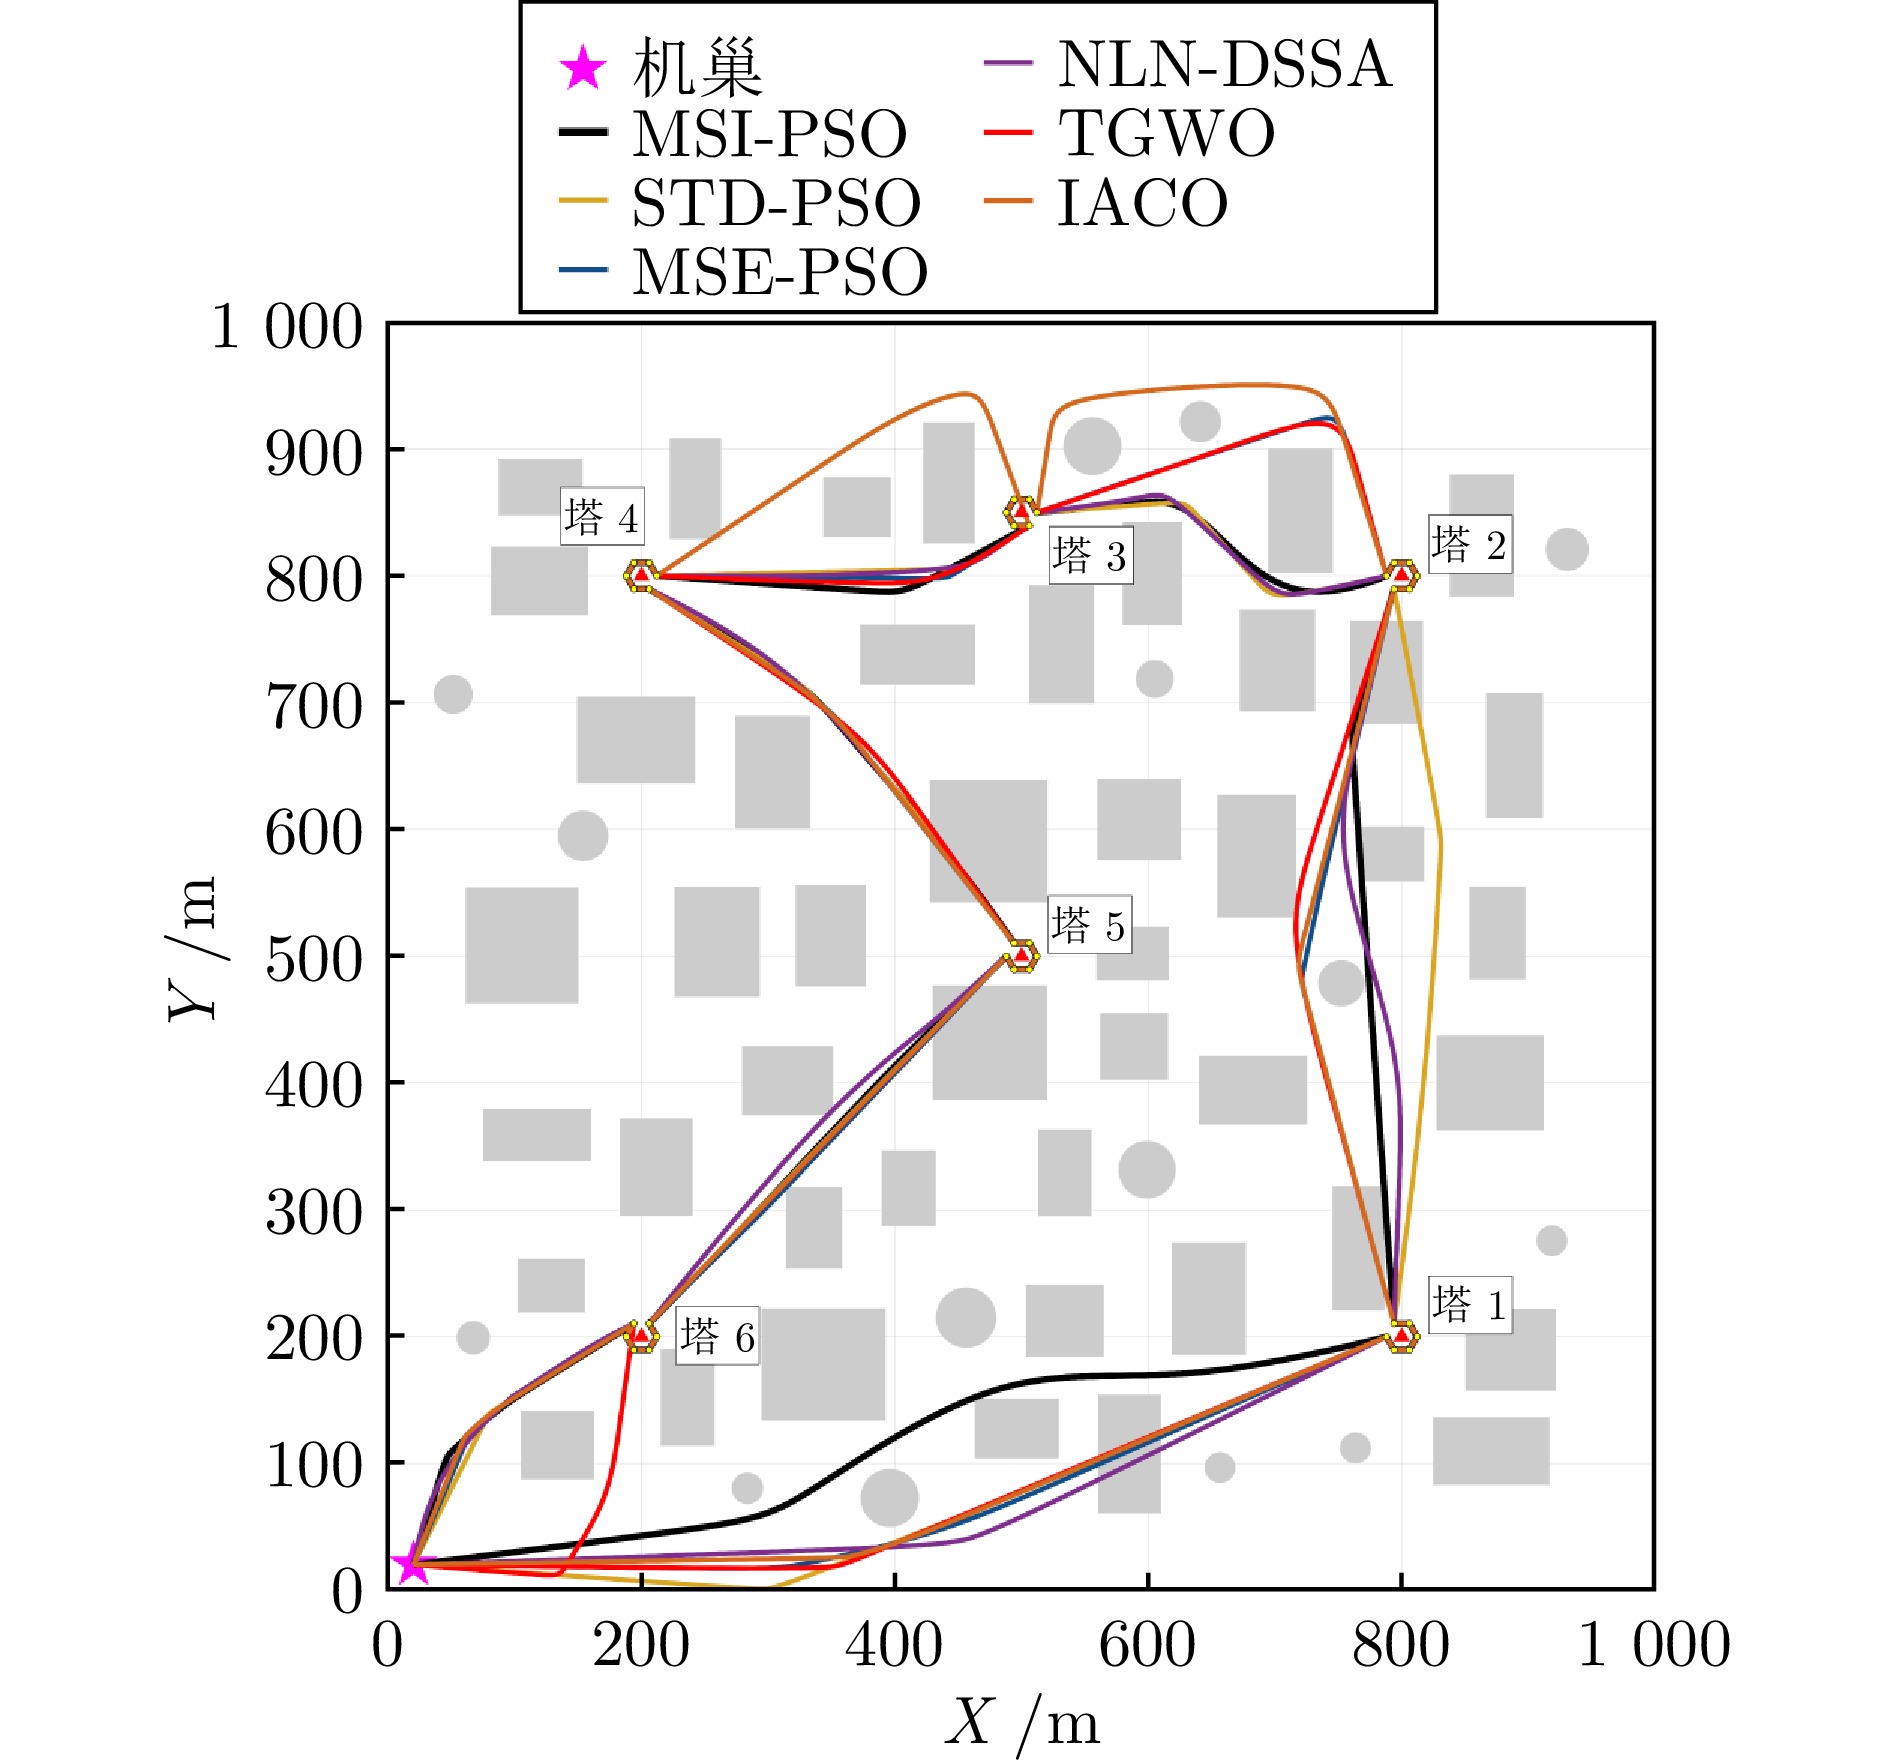
表 2 典型场景下各算法轨迹规划性能对比
Table 2 Comparison of trajectory planning performance of various algorithms in typical scenarios
下载: 导出CSV
表 3 跨场景下各算法轨迹规划性能对比
Table 3 Comparison of the performance of various algorithm trajectory across different scenarios
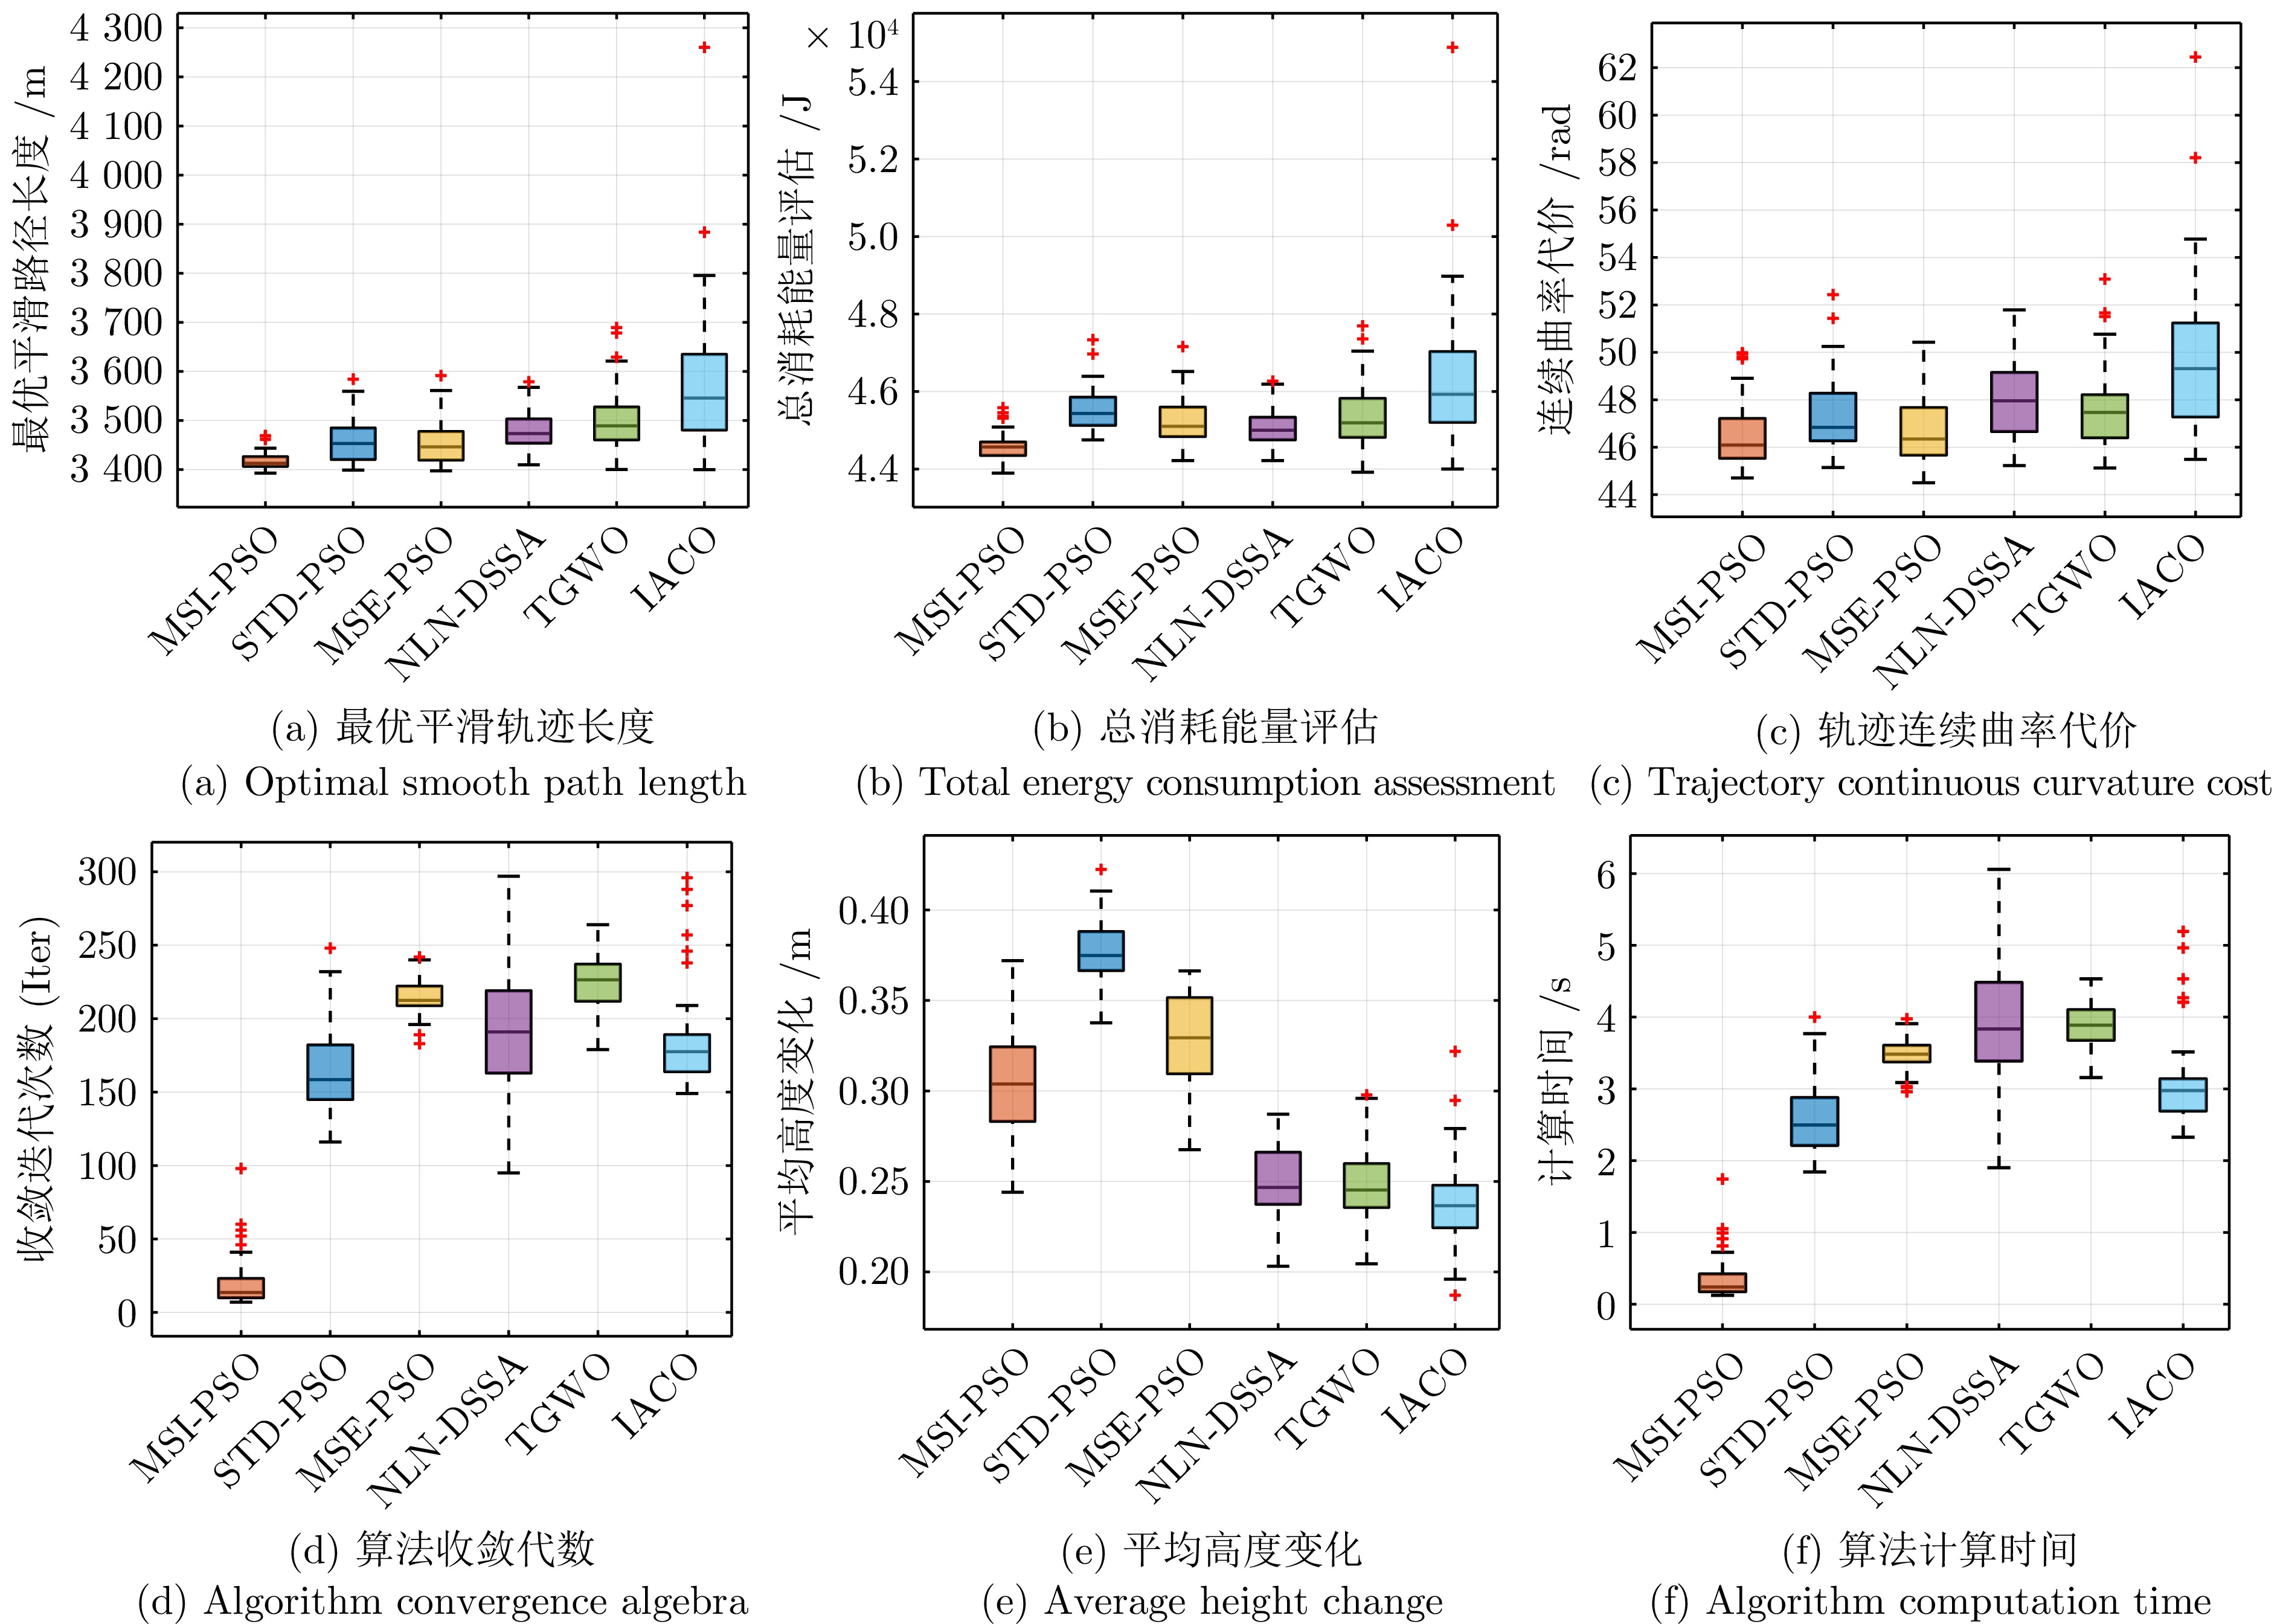
算法 平均轨迹长度(m) 平均能耗评估(J) 平均曲率代价(rad) 平均收敛代数 平均高度变化(m) 平均耗时(s) MSI-PSO 3417.32 44596.97 46.51 21 0.3054 0.33 STD-PSO 3454.85 45531.24 47.36 166 0.3771 2.55 MSE-PSO[22] 3456.47 45271.68 46.71 215 0.3292 3.30 NLN-DSSA[23] 3477.59 45077.26 47.90 193 0.2509 3.89 TGWO [24] 3504.76 45380.68 47.64 225 0.2483 3.78 IACO [25] 3575.36 46278.89 49.74 185 0.2391 3.02
下载: 导出CSV
-
[1] Faisal M A A, Mecheter I, Qiblawey Y, Fernandez J H, Chowdhury M E H, Kiranyaz S. Deep learning in automated power line inspection: A review. Applied Energy, 2025, 385: 125507 doi: 10.1016/j.apenergy.2025.125507 [2] Huang D C, Wang Y M, Li H P. Study on UAV inspection safety distance of substation high-voltage and current-carrying equipment based on power-frequency magnetic field. IEEE Transactions on Instrumentation and Measurement, 2024, 73: 1−8 doi: 10.1109/tim.2024.3476537 [3] Bai L, Zhang Y Y, Yang S H, Zhang Z, Liu Y. Multi-objective optimization of drone location-routing problem for photovoltaic power plant inspection: A MOEA/D-based approach with altitude coordination. Expert Systems with Applications, 2026, 322: 132407 doi: 10.1016/j.eswa.2026.132407 [4] Zhang H, Xu Z W, Chen B, Hua H A, Zhong H, Mo W H, et al. An adaptive nearest point routing method based on charging nest deployment optimization for UAVs power tower inspection. IEEE Transactions on Industrial Informatics, 2025, 21(10): 7881−7890 doi: 10.1109/TII.2025.3574421 [5] He K R, Zhou Q, Lian Z J, Shen Y, Gao J C, Shuai Z K. Spatiotemporal precise routing strategy for multi-UAV-based power line inspection with integrated satellite-terrestrial network. IEEE Transactions on Industry Applications, 2024, 60(6): 8418−8429 doi: 10.1109/TIA.2024.3430248 [6] He Y L, Pang Z W, Dai D R, Zheng H, Han J Y, Ji Y P, et al. Development of a dynamically conformal clamping inspection robot for overhead power lines based on infrared strand breakage detection. IEEE Robotics and Automation Letters, 2026, 11(3): 3031−3038 doi: 10.1109/LRA.2026.3654900 [7] Liu X Y, Miao X R, Jiang H, Chen J, Wu M, Chen Z H. Component detection for power line inspection using a graph-based relation guiding network. IEEE Transactions on Industrial Informatics, 2023, 19(9): 9280−9290 doi: 10.1109/TII.2022.3227638 [8] 张辉, 杜瑞, 钟杭, 曹意宏, 王耀南. 电力设施多模态精细化机器人巡检关键技术及应用. 自动化学报, 2025, 51(1): 20−42 doi: 10.16383/j.aas.c230809Zhang Hui, Du Rui, Zhong Hang, Cao Yi-Hong, Wang Yao-Nan. The key technology and application of multi-modal fine robot inspection for power facilities. Acta Automatica Sinica, 2025, 51(1): 20−42 doi: 10.16383/j.aas.c230809 [9] Gao F, Liu J M, Feng Q, Feng R, Yu B. Task allocation and route planning for UAV-based hybrid inspection of transmission towers, substations, and distribution poles from a fixed nest. Expert Systems with Applications, 2026, 313: 131625 doi: 10.1016/j.eswa.2026.131625 [10] Cao Y, Xu H, Su C, Yang Q. Accurate glass insulators defect detection in power transmission grids using aerial image augmentation. IEEE Transactions on Power Delivery, 2023, 38(2): 956−965 doi: 10.1109/TPWRD.2022.3202958 [11] Enriquez J R, Castillo-Toledo B, Di Gennaro S, García-Delgado L A. An algorithm for dynamic obstacle avoidance applied to UAVs. Robotics and Autonomous Systems, 2025, 186: 104907 doi: 10.1016/j.robot.2024.104907 [12] Wang H Y, Zhou F H, Wu Q H. A robust and intelligent obstacle avoidance method for uncrewed aerial vehicles under the complex and dynamic environment. IEEE Transactions on Vehicular Technology, 2026, 75(3): 4019−4031 doi: 10.1109/TVT.2025.3614493 [13] Ye D M, Sun Z Q, Zhong W F, Kang J W, Huang X M, Kim D I, et al. Optimal flight speed scheduling and battery swapping in UAV-enabled mobile edge computing. IEEE Transactions on Mobile Computing, 2026, 25(1): 948−960 doi: 10.1109/TMC.2025.3601743 [14] Wang W N, Qian H M. A battery-aware integrated genetic algorithm with K-means and 2-optimization for multi-UAVs discrete coverage path planning in unstructured environment. Advanced Engineering Informatics, 2026, 73: 104574 doi: 10.1016/j.aei.2026.104574 [15] Xu X J, Xie C Y, Luo Z F, Zhang C F, Zhang T. A multi-objective evolutionary algorithm based on dimension exploration and discrepancy evolution for UAV path planning problem. Information Sciences, 2024, 657: 119977 doi: 10.1016/j.ins.2023.119977 [16] 祝文杰, 李维, 王子炎. 改进A* 算法的无人机城市低空物流路径规划. 计算机工程与应用, 2025, 61(19): 302−310Zhu Wen-Jie, Li Wei, Wang Zi-Yan. UAV path planning for urban low-altitude logistics based on improved A* algorithm. Computer Engineering and Applications, 2025, 61(19): 302−310 [17] Li Y, Wang Y, Hu Q L, Han T, Li D Y. Integrated navigation and online trajectory convex optimization algorithm with single-star observation for UAVs. Chinese Journal of Aeronautics, 2026, 39(4): 103875 doi: 10.1016/j.cja.2025.103875 [18] Huang T, Fan K G, Sun W. Density gradient-RRT: An improved rapidly exploring random tree algorithm for UAV path planning. Expert Systems with Applications, 2024, 252: 12412115 [19] Lian F J, Li B J, Du D S, Zhu H W, Yang Q S. A reinforcement learning framework for energy-optimal UAV path planning in wind fields. Pattern Recognition, 2026, 173: 112912 doi: 10.1016/j.patcog.2025.112912 [20] Hu W J, Ma X L. Optimization algorithm of UAVS task assignment and path planning based on dynamic cluster particle swarm optimization. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(10): 18157−18169 doi: 10.1109/TITS.2025.3578464 [21] Liu X Y, Shao P, Wang Y, Liu Y. Navigating multi-source threats in low-altitude urban airspace: A physics-informed cyclotron meta-heuristic method. Expert Systems with Applications, 2026, 306: 130964 doi: 10.1016/j.eswa.2025.130964 [22] 朱润泽, 赵静, 陆宁云, 马亚杰, 宋来收. 多障碍场景下基于多策略进化机制的无人机三维路径规划. 自动化学报, 2026, 52(2): 335−348 doi: 10.16383/j.aas.c250319Zhu Run-Ze, Zhao Jing, Lu Ning-Yun, Ma Ya-Jie, Song Lai-Shou. Multi-strategy evolutionary mechanism for UAV 3D path planning in multi-obstacle environments. Acta Automatica Sinica, 2026, 52(2): 335−348 doi: 10.16383/j.aas.c250319 [23] 朱易凡, 裘旭冬, 李硕. 改进麻雀搜索算法的四旋翼无人机路径规划. 传感器与微系统, 2025, 44(1): 141−145 doi: 10.13873/J.1000-9787(2025)01-0141-05Zhu Yi-Fan, Qiu Xu-Dong, Li Shuo. Path planning of quadrotor UAV based on improved sparrow search algorithm. Transducer and Microsystem Technologies, 2025, 44(1): 141−145 doi: 10.13873/J.1000-9787(2025)01-0141-05 [24] 刘洋, 徐教礼, 朱作滨. 基于TGWO的无人机三维路径规划. 计算机工程与应用, 20261−15 doi: 10.3778/j.issn.1002-8331.2508-0323Liu Yang, Xu Jiao-Li, Zhu Zuo-Bin. Three-dimensional path planning for UAV based on TGWO. Computer Engineering and Applications, 20261−15 doi: 10.3778/j.issn.1002-8331.2508-0323 [25] 何海旋. 一种改进蚁群算法的无人机路径规划研究. 智能物联技术, 2026, 58(3): 65−68 doi: 10.26921/j.cnki.2096-6059.2026.03.014He Hai-Xuan. Research on UAV path planning based on an improved ant colony algorithm. Intelligent Internet of Things Technology, 2026, 58(3): 65−68 doi: 10.26921/j.cnki.2096-6059.2026.03.014 [26] Ma D P, Jiang H T, Jiang L C, Zhang C, Li C W, Zheng X, et al. An improved marine predators algorithm-based UAV path planning for 10-kV distribution networks inspection in live working scenarios. International Journal of Advanced Computer Science and Applications, 2025, 16(1). [27] 樊轶伦, 陈蕾, 张本科, 刘月娥, 李峥嵘, 孙益辉. 基于多传感器的无人机配电网架空线路自主巡检和姿态控制. 2024, 61(8): 186-194.Fan Y L, Chen L, Zhang B K, Liu Y E, Li Z R, Sun Y H. Autonomous inspection and attitude control of UAV distribution network overhead lines based on multi-sensors. Electrical Measurement & Instrumentation, 2024, 61(8): 186-194. [28] 梁文勇, 吴大伟, 谷山强, 王海涛, 严碧武, 刘辉. 输电线路多旋翼无人机精细化自主巡检航迹优化方法. 高电压技术, 2020, 46(9): 3054−3061 doi: 10.13336/j.1003-6520.hve.20200310002Liang W Y, Wu D W, Gu S Q, Wang H T, Yan B W, Liu H. Track optimization method for fine autonomous inspection of transmission lines by multi-rotor UAV. High Voltage Engineering, 2020, 46(9): 3054−3061 doi: 10.13336/j.1003-6520.hve.20200310002 [29] Datsko D, Nekovar F, Penicka R, Saska M. Energy-aware multi-UAV coverage mission planning with optimal speed of flight. IEEE Robotics and Automation Letters, 2024, 9(3): 2893−2900 doi: 10.1109/LRA.2024.3358581 -

 下载:

计量
- 文章访问数: 12
- HTML全文浏览量: 9
- 被引次数: 0
