

Formation Control for Multiple Unmanned Surface Vehicles Under Large Transmission Delays: A Collision-free Algorithm With Motion Region Constraints
-
摘要: 针对无人艇集群组网系统, 研究艇间数据传输存在长通信时延(时延不确定且长于通信触发间隔)限制的分布式编队控制问题. 在编队形成方面, 设计一种基于受限博弈理论的安全编队控制算法. 该算法提出采用不等式约束限制无人艇期望编队区域, 并采用等式约束确保最终编队精度, 能够在实现高编队精度的同时适配任意运动区域约束, 摆脱了传统方法无法实现指定区域内期望队形形成、最终编队位置严格依赖于编队初始位置以及仅适配特殊受限区域等问题. 在长通信时延方面, 设计一种基于历史触发信息记忆与加权补偿的艇间通信机制. 该机制能够通过所记忆的历史触发信息以及当前采样误差, 结合自身控制律设计相关性质, 有效估计并修正时延导致的艇间信息更新误差, 增强了所提算法在时延限制下的控制鲁棒性. 李雅普诺夫稳定性分析和仿真实验验证了所提算法的有效性.Abstract: For networked unmanned surface vehicles, we investigate the distributed formation control problem subject to large communication delays in inter-vehicle data transmission, where the delay is uncertain and longer than the communication triggering interval. For formation shaping, we develop a safe formation control algorithm based on constrained game theory. This algorithm employs inequality constraints to limit the desired formation region of unmanned surface vehicles and applies equality constraints to ensure the final formation accuracy, thus simultaneously achieving high formation accuracy and the adaptation of arbitrary motion region constraints. This algorithm overcomes the drawbacks of traditional methods, such as the inability to form the desired formation within a specified area, the strict dependence of the final formation position on the initial formation position, and the limitation of only being applicable to special restricted areas. For large transmission delays, an inter-vehicle communication mechanism based on historical triggering-information memory and weighted compensation is developed. By exploiting the memorized historical triggering information, the current sampling error, and the properties of the designed control command, such a mechanism can effectively estimate and compensate for information updating errors caused by large transmission delays, thereby enhancing system robustness under large delays. Lyapunov stability analysis and simulation results verify the effectiveness of the proposed algorithm.
-
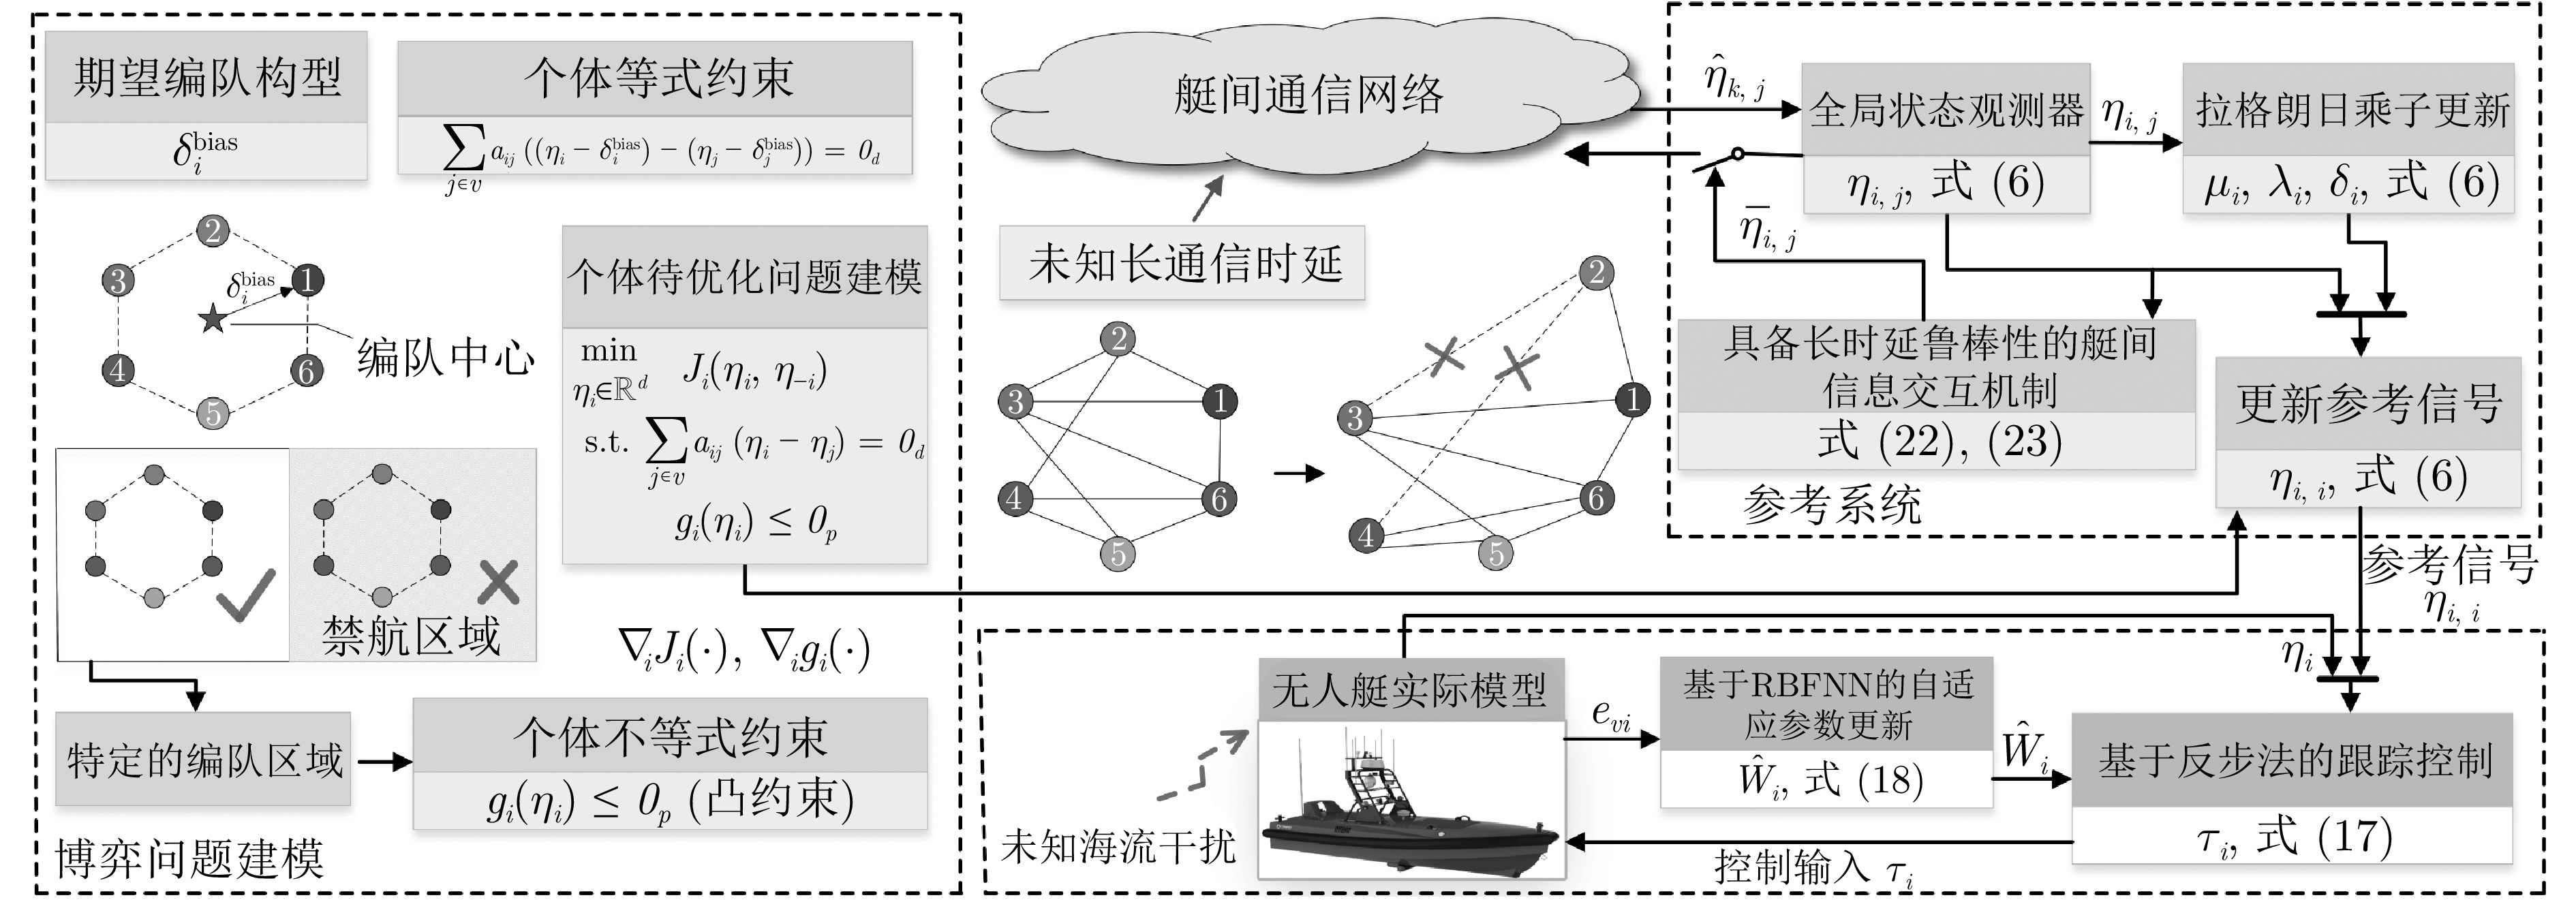
图 1 具备长通信时延鲁棒性的受限博弈集群控制算法框架
Fig. 1 Constrained game-based framework diagram for large delay-robust algorithm
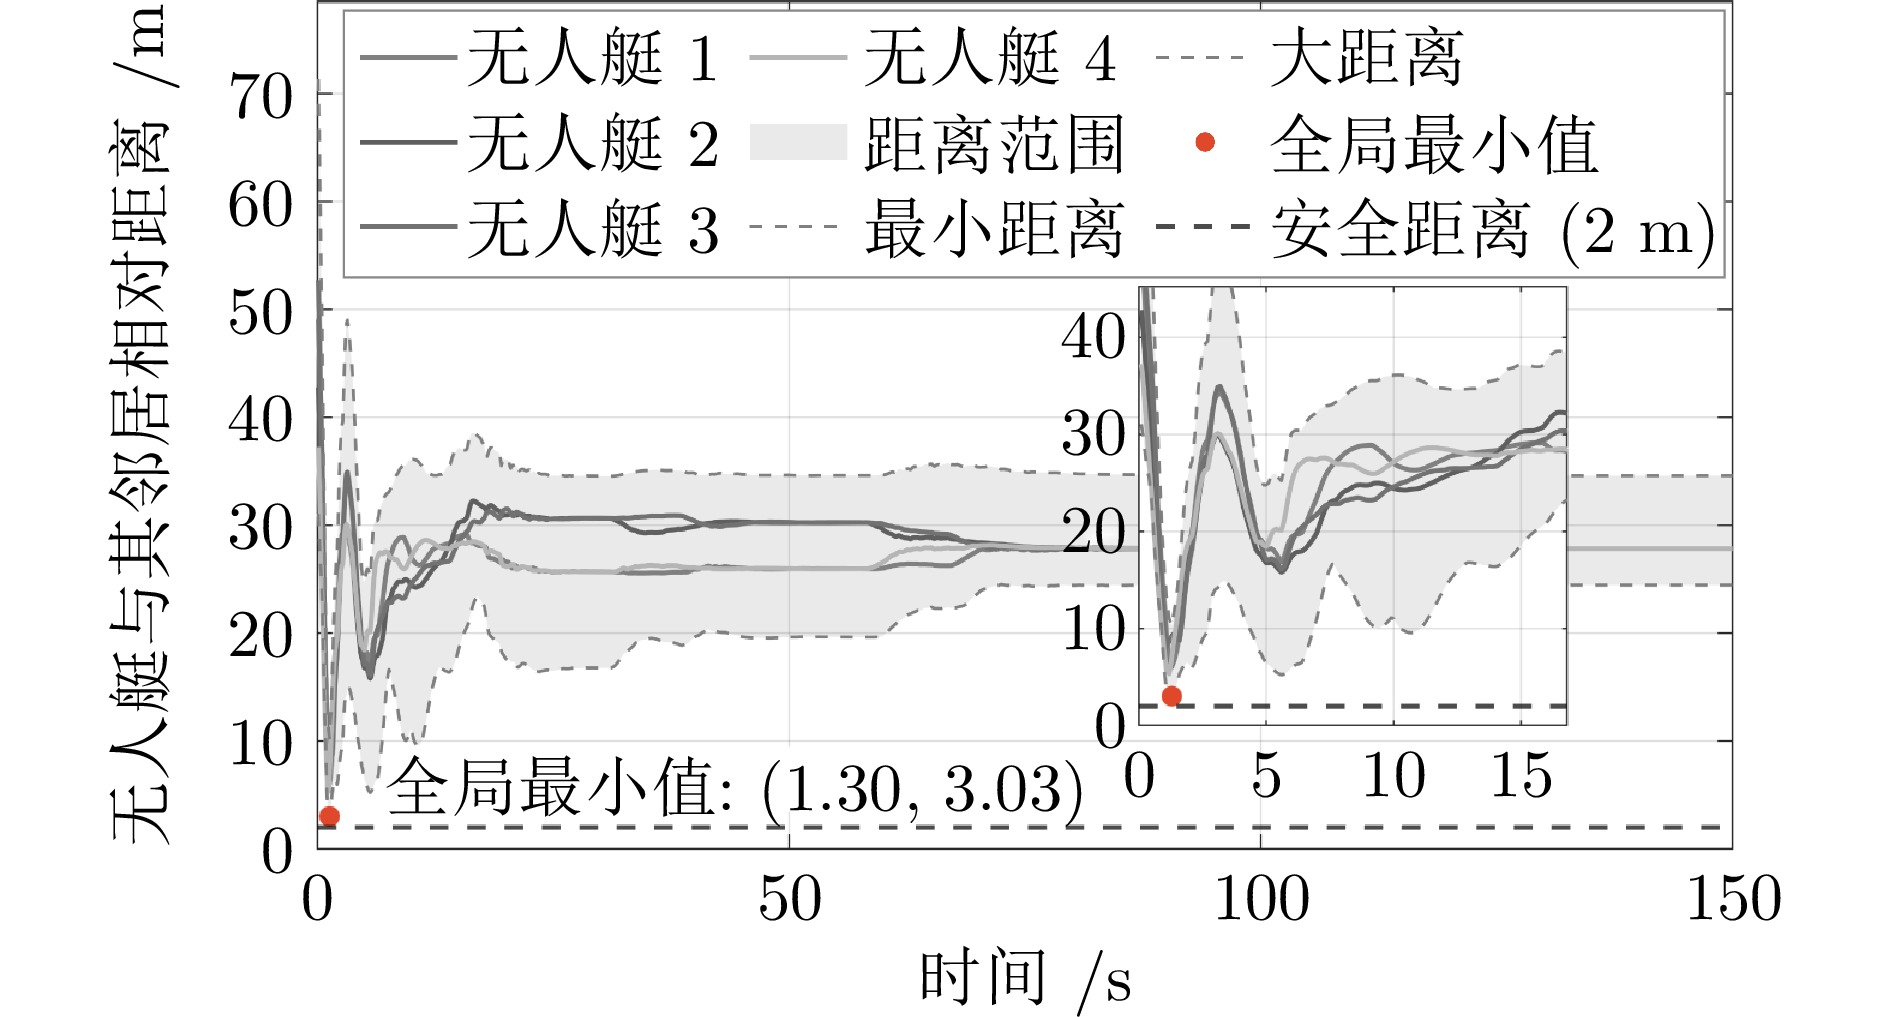
图 3 无人艇集群相对距离演化(考虑不等式约束)
Fig. 3 Inter-vehicle distance evolution of the vehicle swarm (considering inequality constraints)
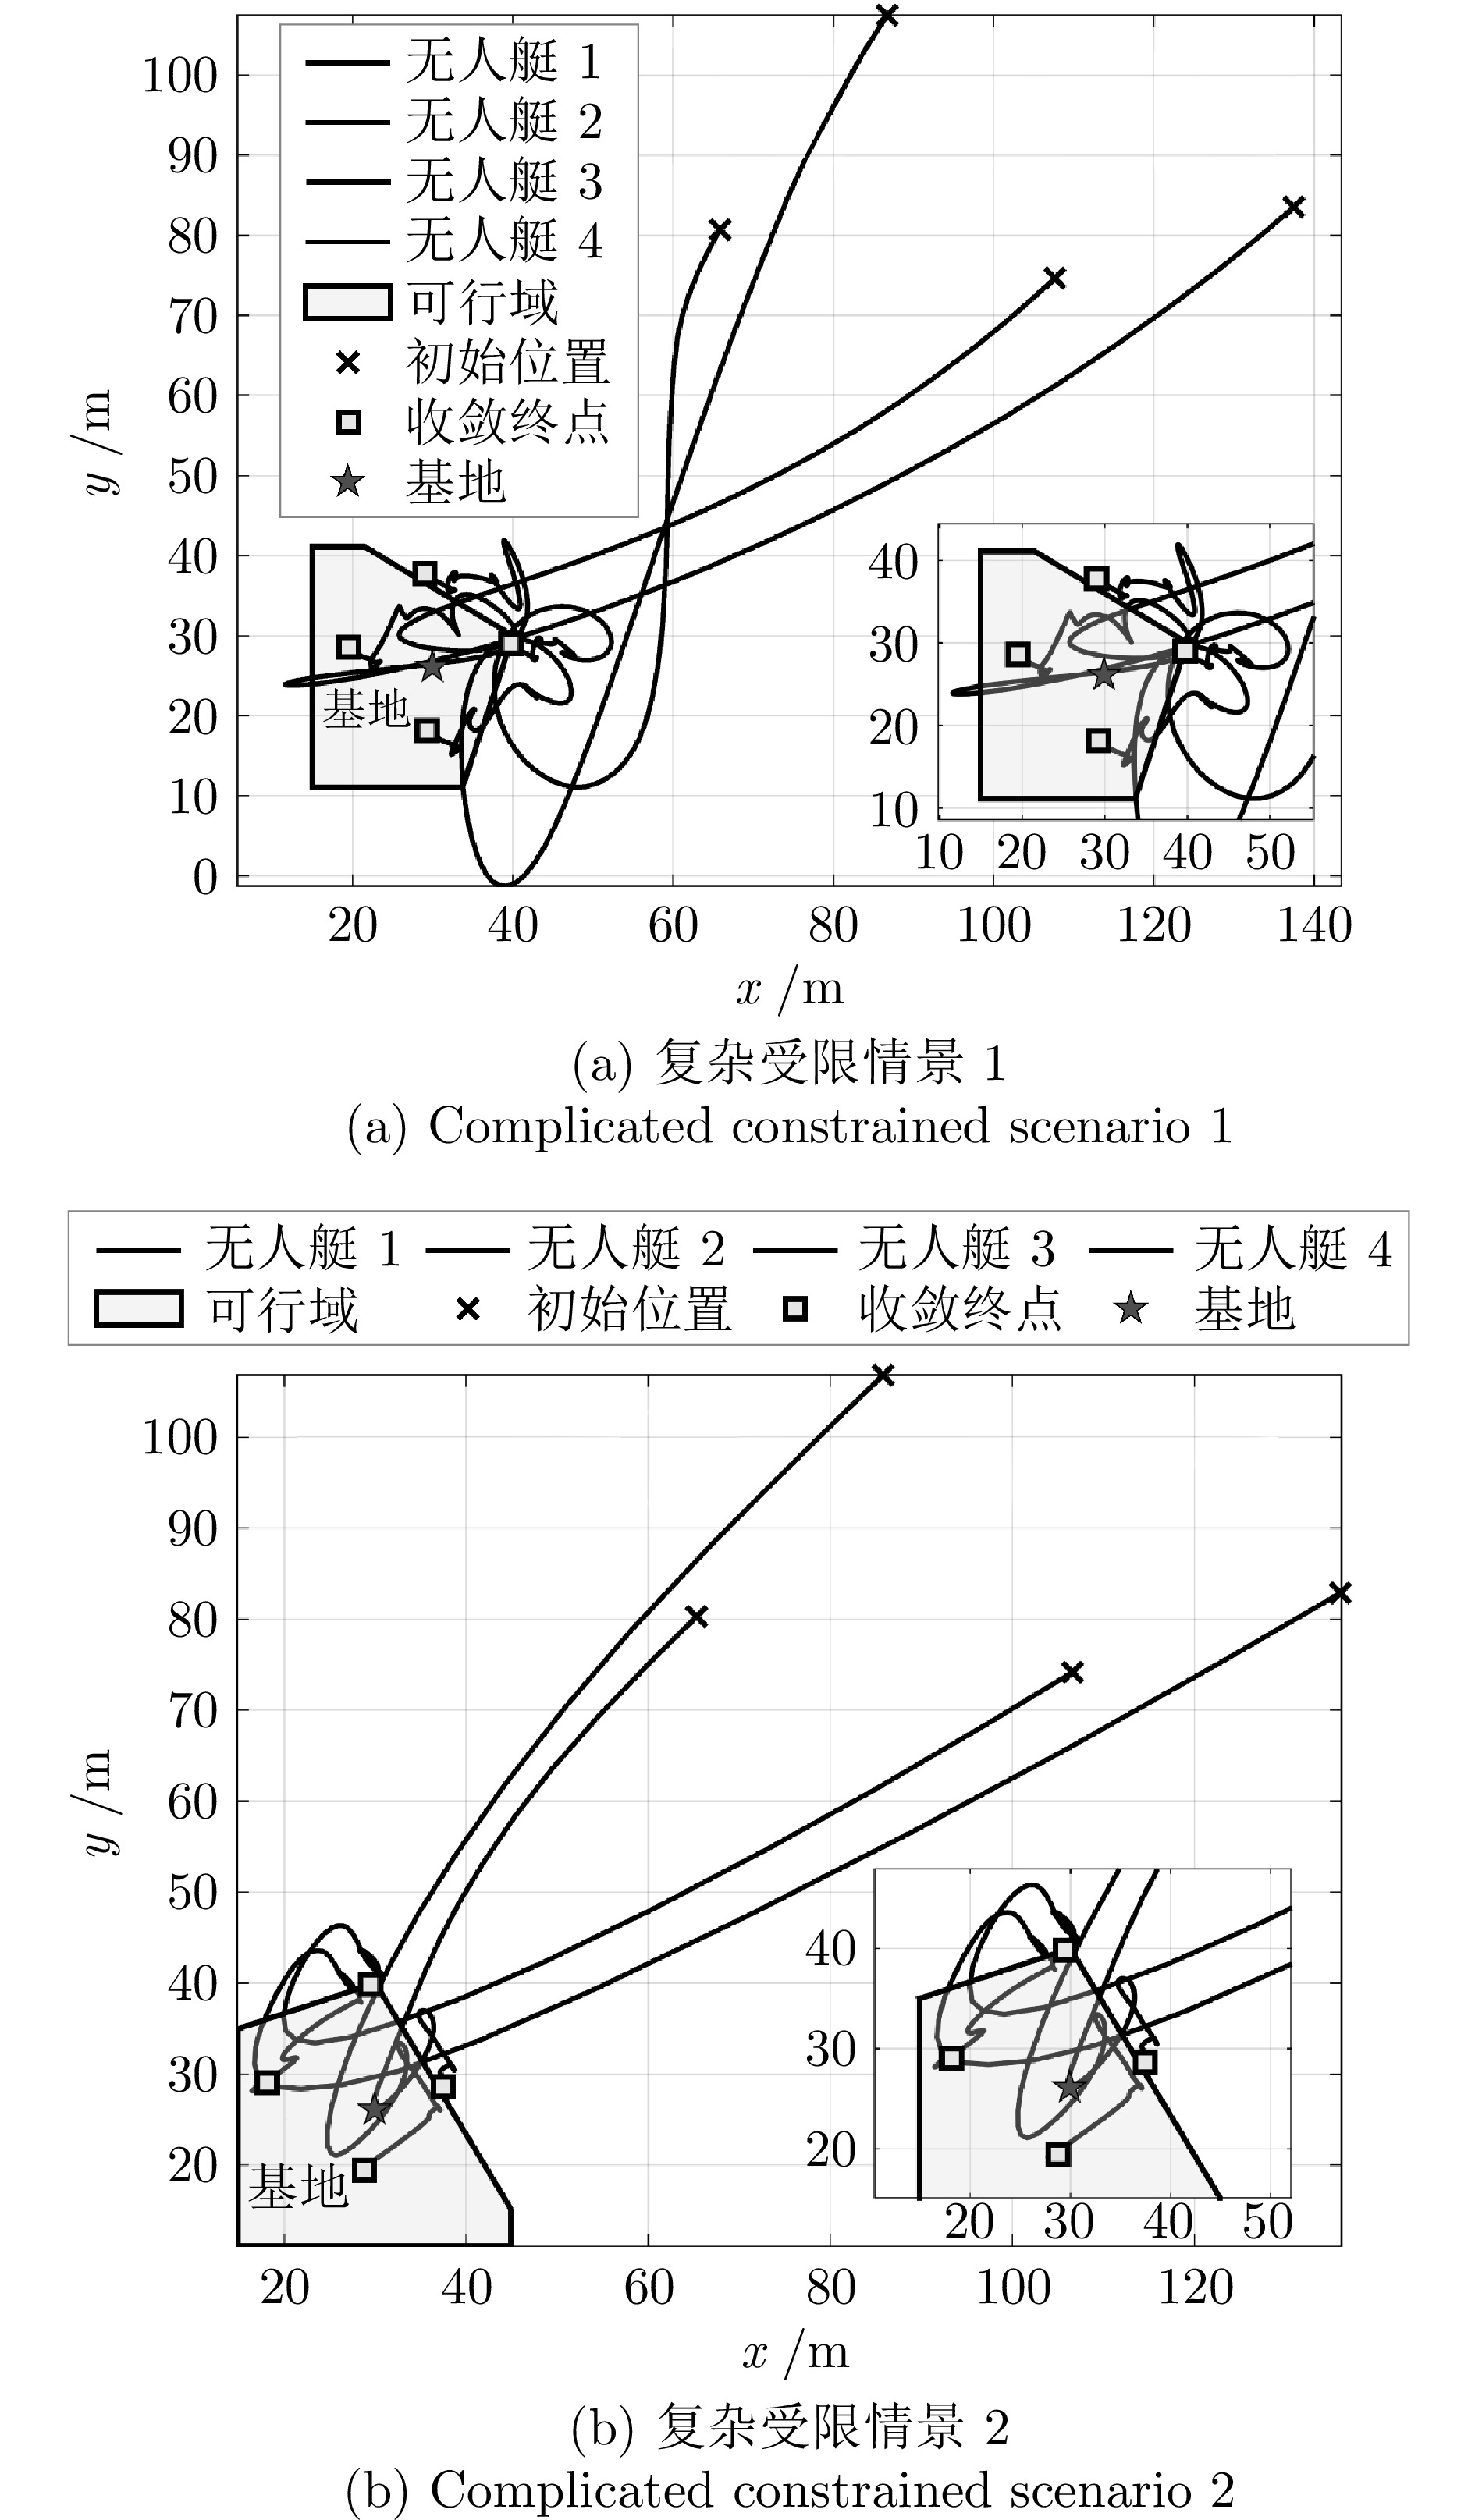
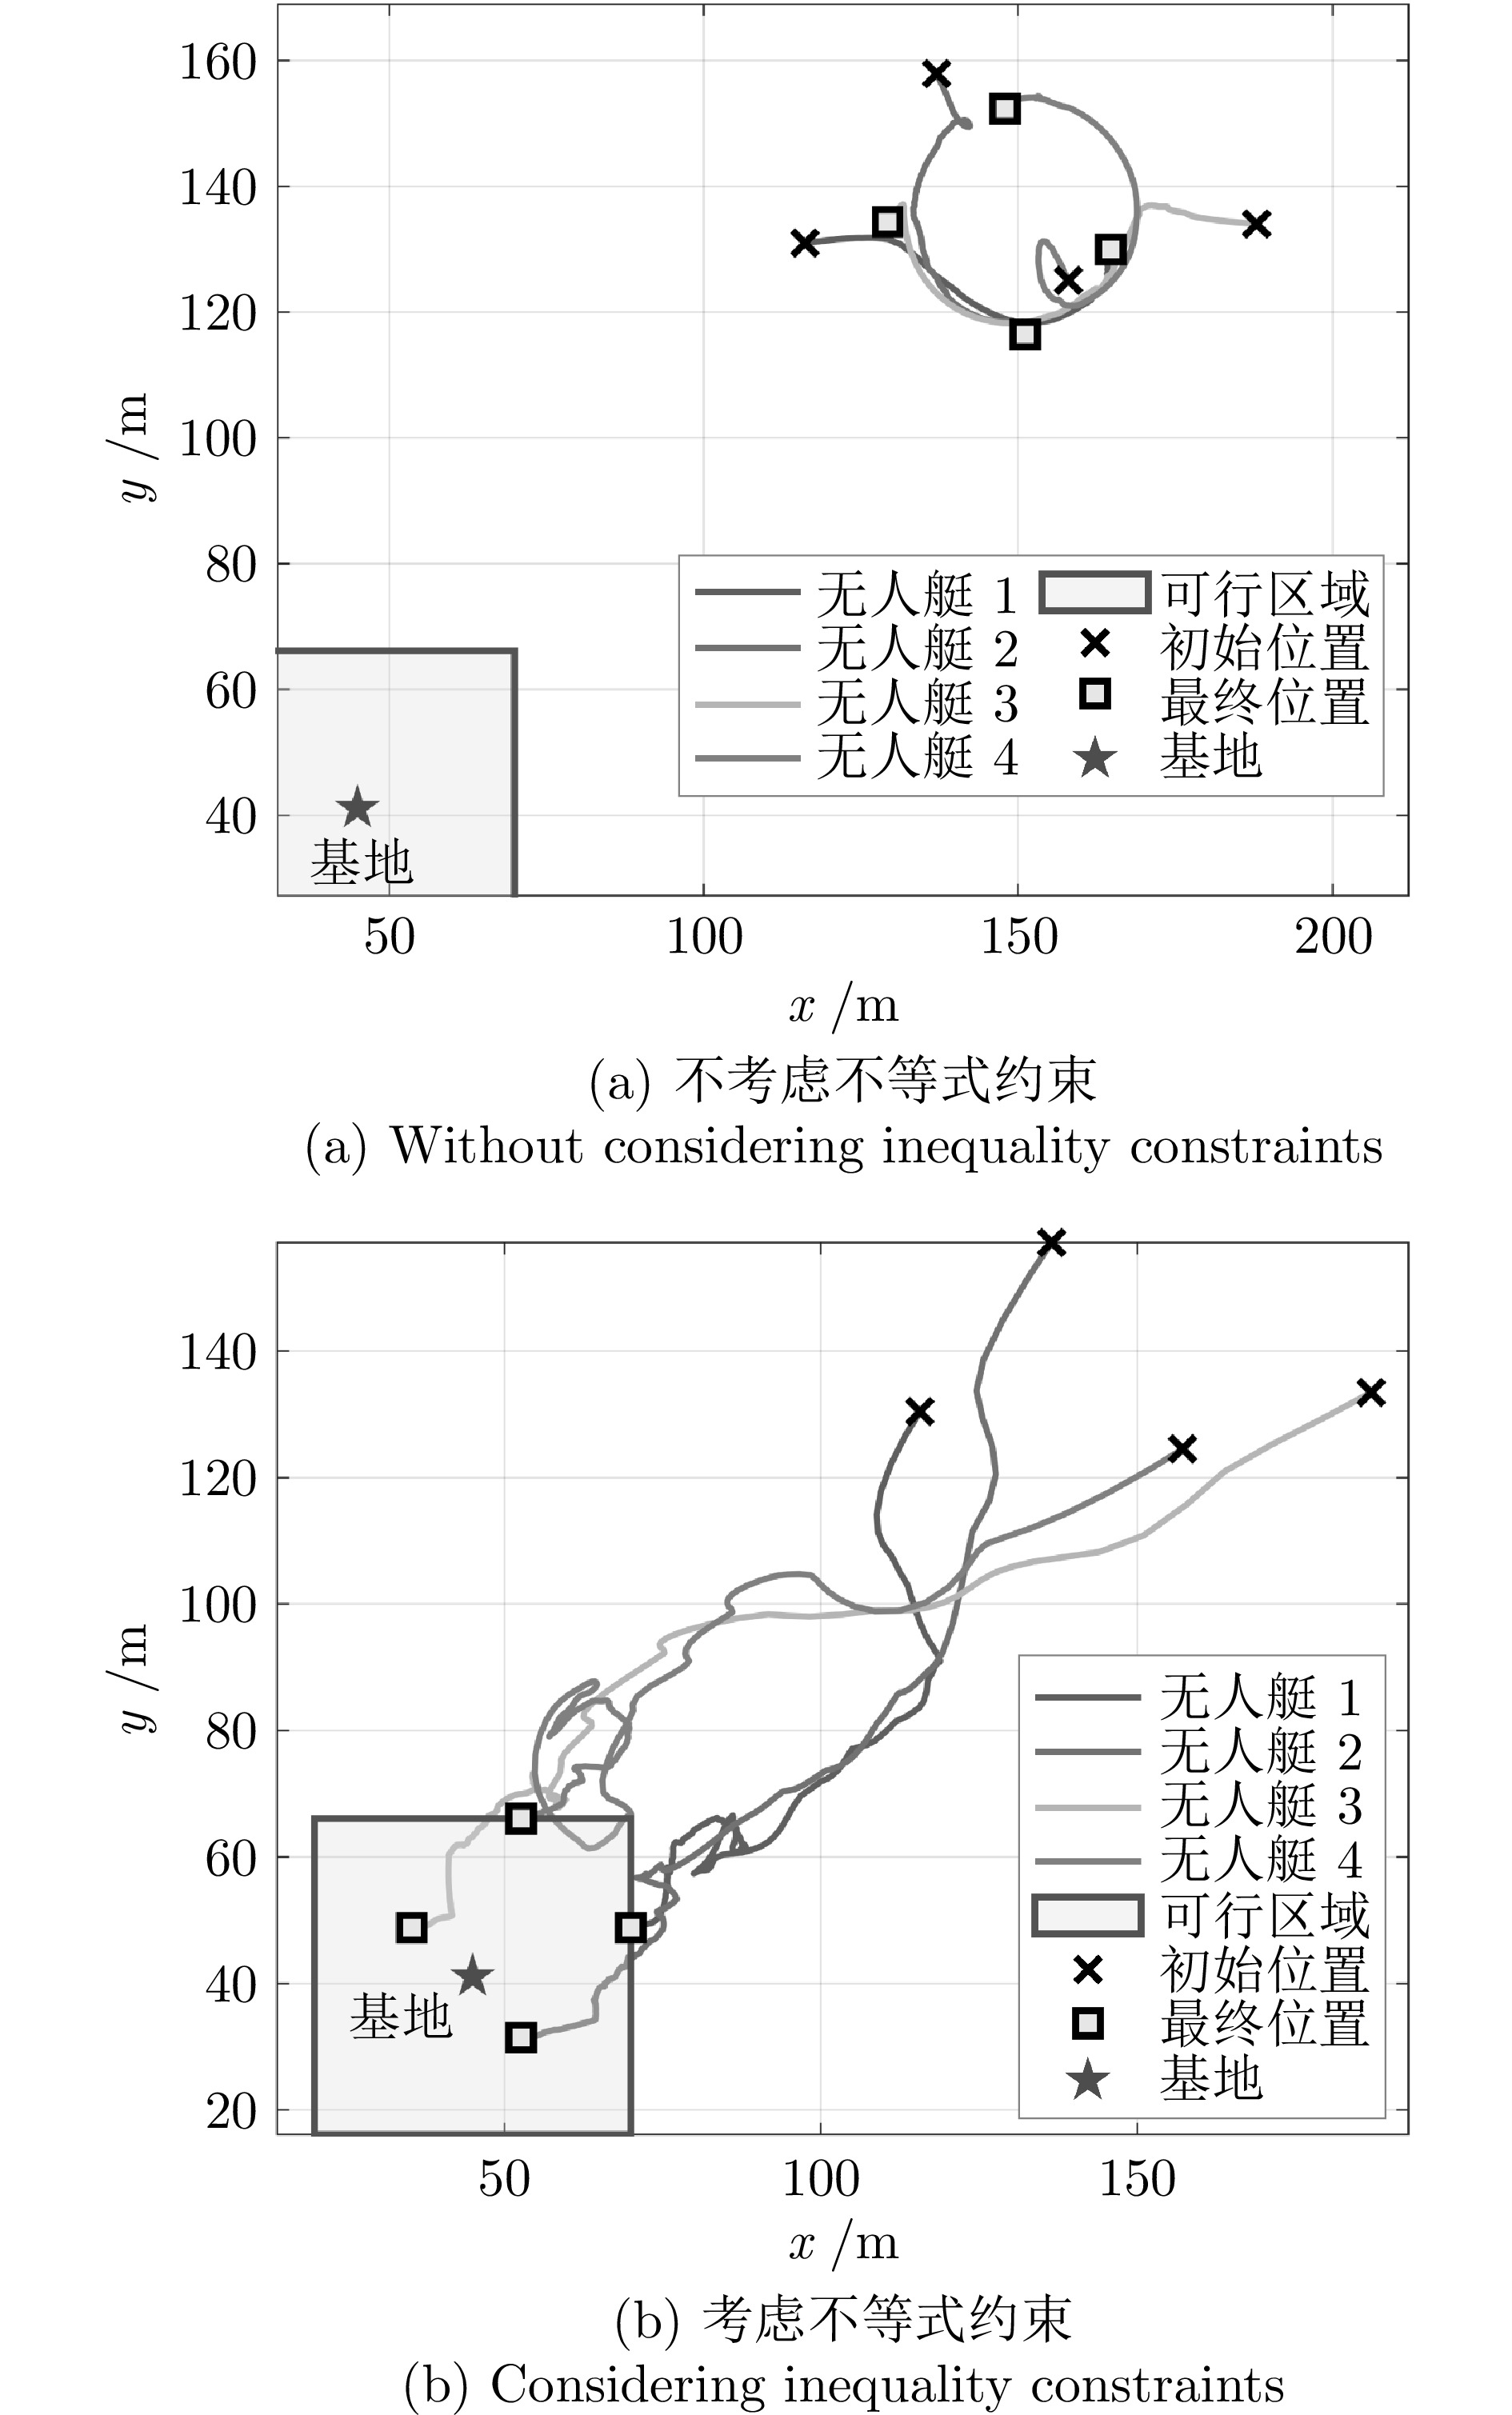
图 6 无人艇集群轨迹演化(复杂受限区域)
Fig. 6 Trajectory evolution of the unmanned surface vehicle swarm (complicated constrained area)
表 1 所提算法相关的控制参数增益
Table 1 Control parameter gains related to the proposed algorithm
Trule控制参数项 控制增益($ i \in {\cal{I}} $) 无人艇初始状态(单位: $ [ \text{m};\text{m};\text{rad} ] $) $ {{\boldsymbol{\eta}}_{1}}={{[ 18;16;{\pi }/{3}\; ]}} $, $ {{\boldsymbol{\eta}}_{2}}={{[ 0;30;{\pi }/{6}\; ]}} $, $ {{\boldsymbol{\eta}}_{3}}={{[ -24;9;-{\pi }/{2}\; ]}} $, $ {{\boldsymbol{\eta}}_{4}}={{[ 25;-18;-{\pi }/{6}\; ]}} $ 无人艇期望轨迹跟踪控制器 $ k_p = 10,\; \ k_d = 10 $ 分布式纳什均衡点搜索 $ k_1 = 10,\; \ k_2 = 3,\; \ k_3 = 1,\; \ k_4 = 1 $ 个体代价函数 $ \mu_{0i} = 0.01,\; \ \mu_{1i} = 1,\; \ \mu_{2i} = 0.3 $ 具备大时延鲁棒性的事件触发机制 $ D_i = 3,\; \ \tilde{\lambda}_i = 0.008,\; \ \gamma_{l_i,\; i} = 1,\; \ \tilde{\lambda}_{W_i} = 1.2,\; \ \bar{\rho}_i = 0.8 $ 期望编队构型设计 $ d_F = 5,\; \ \delta_i^{bias} = [\sin(2\pi i/N); \cos(2\pi i/N); 0] $ 海流干扰 波浪平均幅值$ 0.1\,\; \text{m} $, 海流速度$ 0.15\,\; \text{m/s} $, 海洋扰动方向$ 45^\circ $  下载: 导出CSV
表 2 两种通信算法下性能指标对比
Table 2 Comparison of performance indicators under two distinct communication algorithms
性能指标 LDRSEC(21) CETC(67) 时延累积误差$ E_{d} $ 7 095.411 3 14 227.619 8 触发累积误差$ E_{t} $ 3 151.231 9 9 780.934 1 平均信息新鲜度$ {F}_{d} $ 0.339 8 3.818 1 平均触发次数$ N_{t} $ 350.25 52.00 平均触发间隔$ T_{ave} $ 0.428 1 2.921 6
下载: 导出CSV
-
[1] Wen G H, Fu J J, Wang B W, Wang X D, Shen H. Robust formation tracking of ASVs with nonconservative collision avoidance: A control barrier function-based approach. IEEE Transactions on Industrial Electronics, 2026, 73(6): 9174−9186 doi: 10.1109/TIE.2025.3649849 [2] 黄兵, 赵冲, 张立川, 朱骋. 基于边分组通信机制的无人艇博弈编队控制. 自动化学报, 2026, 52(10): 1−20 doi: 10.16383/j.aas.c260075Huang B, Zhao C, Zhang L C, Zhu C. Edge-grouped communication mechanism-based game formation control for unmanned surface vehicles. Acta Automatica Sinica, 2026, 52(10): 1−20 doi: 10.16383/j.aas.c260075 [3] Zhang Q R, Pan W, Reppa V. Model-reference reinforcement learning for collision-free tracking control of autonomous surface vehicles. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(7): 8770−8781 doi: 10.1109/TITS.2021.3086033 [4] Peng Z H, Wang D, Li T S, Han M. Output-feedback cooperative formation maneuvering of autonomous surface vehicles with connectivity preservation and collision avoidance. IEEE transactions on cybernetics, 2019, 50(6): 2527−2535 [5] Wang X F, Teel A R, Liu K Z, Sun X M. Stability analysis of distributed convex optimization under persistent attacks: A hybrid systems approach. Automatica, 2020, 111: 108607 doi: 10.1016/j.automatica.2019.108607 [6] Zhu G B, Ma Y, Li Z X, Malekian R, Sotelo M. Event-triggered adaptive neural fault-tolerant control of underactuated MSVs with input saturation. IEEE Transactions on Intelligent Transportation Systems, 2021, 23(7): 7045−7057 [7] Wen G H, Fang X, Shen H, Zhou J L, Zheng D Z. Distributed leader escort control for multiple autonomous surface vessels: Utilizing signed graph to model interaction relationships. IEEE/ASME Transactions on Mechatronics, 2024, 30(4): 2574−2585 doi: 10.1109/tmech.2024.3455412 [8] 温广辉, 余星火, 黄廷文, 周艳. 模型参数不确定下多无人艇系统固定时间二分编队跟踪控制. 自动化学报, 2025, 51(3): 669−677 doi: 10.16383/j.aas.c240473Wen G H, Yu X H, Huang T W, Zhou Y. Fixed-time bipartite formation tracking control for multi-USV systems with uncertain model parameters. Acta Automatica Sinica, 2025, 51(3): 669−677 doi: 10.16383/j.aas.c240473 [9] Cui H L, Zhao G L, Hua C C, Cui R X. Distributed event-triggered control of large-scale fuzzy systems with long transmission delays. IEEE Transactions on Fuzzy Systems, 2024, 32(6): 3765−3778 doi: 10.1109/TFUZZ.2024.3382623 [10] Yu H, Chen T W. Periodic event-triggered networked control systems subject to large transmission delays. IEEE Transactions on Automatic Control, 2021, 68(1): 63−79 doi: 10.1109/tac.2021.3131146 [11] Gong S Q, Guo Z Y, Wen S P, Huang T W. Stabilization analysis for linear disturbed event-triggered control system with packet losses. IEEE Transactions on Control of Network Systems, 2022, 9(3): 1339−1347 doi: 10.1109/TCNS.2022.3147704 [12] Qian Y Y, Wan Y, Lin Z L, Shamash Y A, Davoudi A. Distributed control of physically-interconnected systems under event-triggered communication with packet loss. In: Proceedings of IEEE 17th International Conference on Control & Automation (ICCA). Naples, Italy: IEEE, 2022. 897-902 [13] Liu G L, Sun Q Y, Su H G, Wang M X. Adaptive cooperative fault-tolerant control for output-constrained nonlinear multi-agent systems under stochastic FDI attacks. IEEE Transactions on Circuits Systems I: Regular Papers, 2025, 72(10): 6025−6036 doi: 10.1109/TCSI.2025.3534194 [14] Wu W T, Zhang Y B, Li Z H, Lu J G, Zhang W D. Constrained safe cooperative maneuvering of autonomous surface vehicles: A control barrier function approach. IEEE Transactions on Systems, Man, Cybernetics: Systems, 2024, 55(1): 73−84 [15] Zhou W X, Fu J, Yan H C, Du X, Wang Y Y, Zhou H. Event-triggered approximate optimal path-following control for unmanned surface vehicles with state constraints. IEEE Transactions on Neural Networks Learning Systems, 2021, 34(1): 104−118 [16] Cao Y, Chen X K, Zhang M S, Huang J. Adaptive position constrained assist-as-needed control for rehabilitation robots. IEEE Transactions on Industrial Electronics, 2023, 71(4): 4059−4068 [17] Liu B J, Guo Y, Li A J, Di F Q. Distributed nussbaum-based finite-time containment control for multi-UAVs with actuator saturation and faults. IEEE Transactions on Aerospace Electronic Systems, 2022, 59(4): 3505−3520 [18] Moreno-Valenzuela J, Moyrón J, Montoya-Chairez J. Limited integrator antiwindup-based control of input-constrained manipulators. IEEE Transactions on Industrial Electronics, 2023, 71(2): 1738−1748 doi: 10.1109/tie.2023.3262858 [19] Dai X Y, Wen G H, Fang X, Shen H. Distributed time-varying nash equilibrium seeking algorithm for target protection of multiusvs with conflicting goals. IEEE Transactions on Industrial Informatics, 2024, 20(6): 8466−8476 doi: 10.1109/TII.2024.3363076 [20] Deng Z H, Luo J, Liu Y Y, Yu W Y. Distributed formation control algorithms for QUAVs based on aggregative games. IEEE Systems Journal, 2023, 17(3): 4419−4429 doi: 10.1109/JSYST.2023.3268160 [21] Fang X, Zhou J L, Wen G H. Location game of multiple unmanned surface vessels with quantized communications. IEEE Transactions on Circuits and Systems II: Express Briefs, 2022, 69(3): 1322−1326 doi: 10.1109/tcsii.2021.3111733 [22] Huang Y, Meng Z Y, Sun J. Distributed nash equilibrium seeking for multicluster aggregative game of Euler-Lagrange systems with coupled constraints. IEEE Transactions on Cybernetics, 2024, 54(10): 5672−5683 doi: 10.1109/TCYB.2023.3347653 [23] Zou Y, Huang B M, Meng Z Y, Ren W. Continuous-time distributed nash equilibrium seeking algorithms for non-cooperative constrained games. Automatica, 2021, 127: Article No. 109535 doi: 10.1016/j.automatica.2021.109535 [24] Zhang W A, Yu L. Stabilization of sampled-data control systems with control inputs missing. IEEE Transactions on Automatic Control, 2010, 55(2): 447−452 doi: 10.1109/TAC.2009.2036325 [25] Zhu G B, Ma Y, Hu S L. Event-sampled adaptive fuzzy control of mass via intermittent position data. IEEE Transactions on Emerging Topics in Computational Intelligence, 2025, 9(4): 3084−3096 doi: 10.1109/TETCI.2025.3526331 [26] Huang B, Peng H, Ahn C K. Endowing marine transportation systems with collision-free ability: a probability-assigned interaction approach. IEEE Transactions on Intelligent Transportation Systems, 20261−16 [27] Zhang G Q, Liu S, Zhang X K, Zhang W D. Event-triggered cooperative formation control for autonomous surface vehicles under the maritime search operation. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(11): 21392−21404 doi: 10.1109/TITS.2022.3181141 [28] Fossen T I. Guidance and Control of Ocean Vehicles. Chichester: Wiley, 1994. -

 下载:

计量
- 文章访问数: 12
- HTML全文浏览量: 5
- 被引次数: 0
