

Low-Altitude Aircraft Swarms Formation Obstacle Avoidance and Trajectory Cooperation Planning
-
摘要: 低空飞行器集群轨迹协同规划的核心挑战在于协调编队保持与避障灵活性. 同时, 现有方法因采用高维状态建模, 普遍存在计算复杂度高, 规划效率低的问题, 制约了其实际应用. 为此, 本文提出一种基于仿射A-RRT$^{\ast}$ (Accelerated-RRT$^{\ast}$)的低空飞行器集群轨迹协同规划方法. 基于三维编队仿射变换的降维方法, 将路径搜索空间从$3N$维压缩至7 维, 并提出融合双向探索与节点复用优化的A-RRT$^{\ast}$路径规划算法, 在快速生成集群全局路径的同时降低模型维数和计算负担. 在此基础上, 基于欧几里得符号距离场的梯度信息对全局路径进行安全修正, 并对修正路径进行时空参数重优化, 进而快速构建具有优化裕度的序列凸安全区域. 进一步地, 将编队保持约束以软约束惩罚项的形式引入兼顾平滑性与能耗的二次规划模型, 实现编队保持约束下的低空飞行器集群平滑轨迹生成. 仿真结果表明, 所提框架在复杂低空环境中能够兼顾编队保持, 安全避障和轨迹质量, 并降低模型复杂度与计算开销.Abstract: A core challenge in cooperative trajectory planning for low-altitude aircraft swarms lies in coordinating formation keeping with obstacle-avoidance flexibility. Meanwhile, existing methods typically rely on high-dimensional state representations, resulting in high computational complexity and low planning efficiency, which hinder practical deployment. To address this issue, an affine A-RRT$^{\ast}$ (Accelerated-RRT$^{\ast}$)-based method is proposed for formation obstacle avoidance and cooperative trajectory planning of low-altitude aircraft swarms. By introducing a three-dimensional formation affine transformation, the path-search space is reduced from $3N$ dimensions to a 7-dimensional configuration space. An A-RRT$^{\ast}$ path planner integrating bidirectional exploration and node-reuse optimization is then developed to rapidly generate global paths while reducing model dimensionality and computational burden. Furthermore, the global paths are safely refined using gradient information from the Euclidean signed distance field, followed by spatiotemporal parameter re-optimization of the corrected paths to efficiently construct sequential convex safe regions with sufficient optimization margins. Formation-keeping constraints are also incorporated into a quadratic programming formulation as soft penalty terms, together with smoothness and energy objectives, to generate smooth swarm trajectories under formation-keeping requirements. Simulation results demonstrate that the proposed framework balances formation keeping, safe obstacle avoidance, and trajectory quality in complex low-altitude environments while reducing model complexity and computational cost.
-
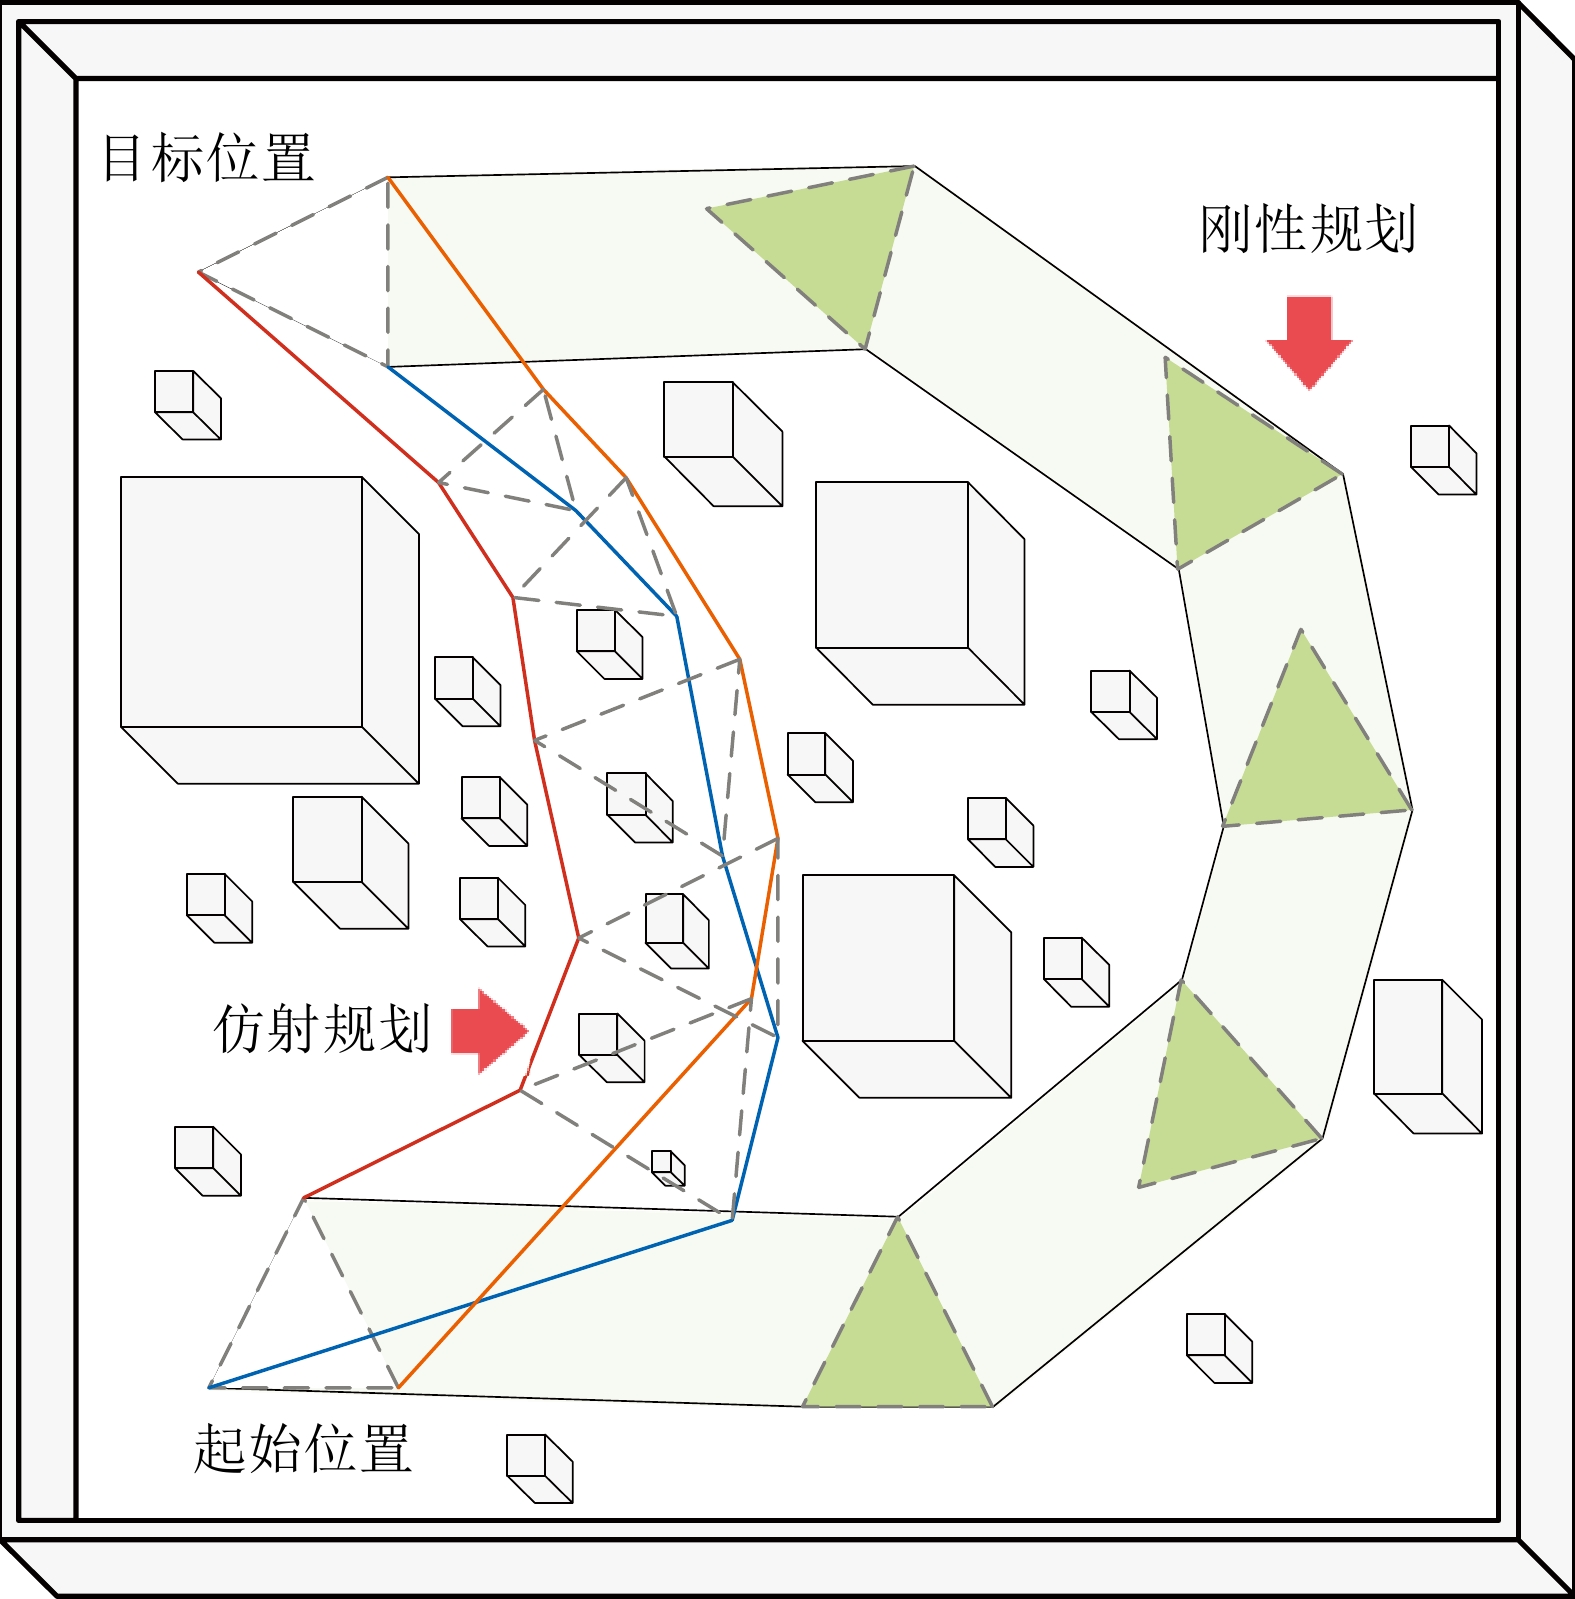
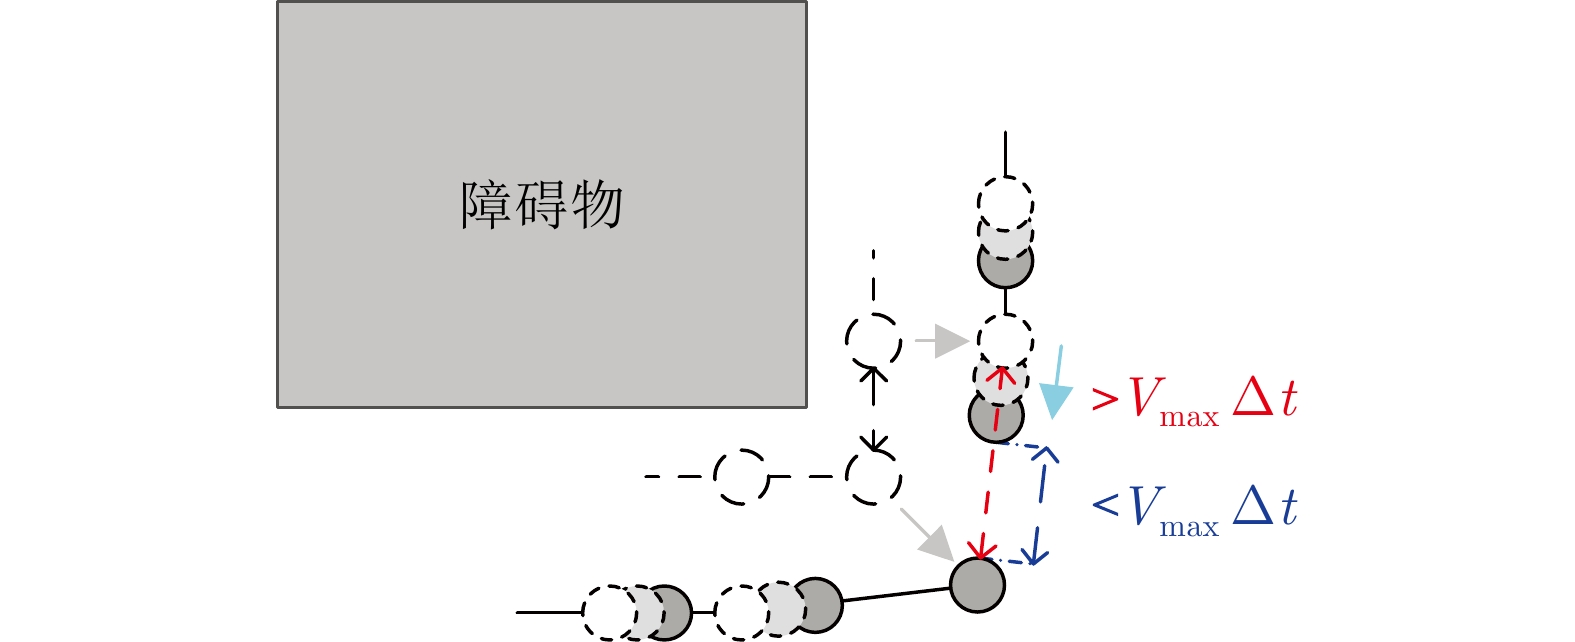
图 1 基于刚性规划和仿射规划的方法对比
Fig. 1 Comparison of rigid planning and affine transformation-based approaches
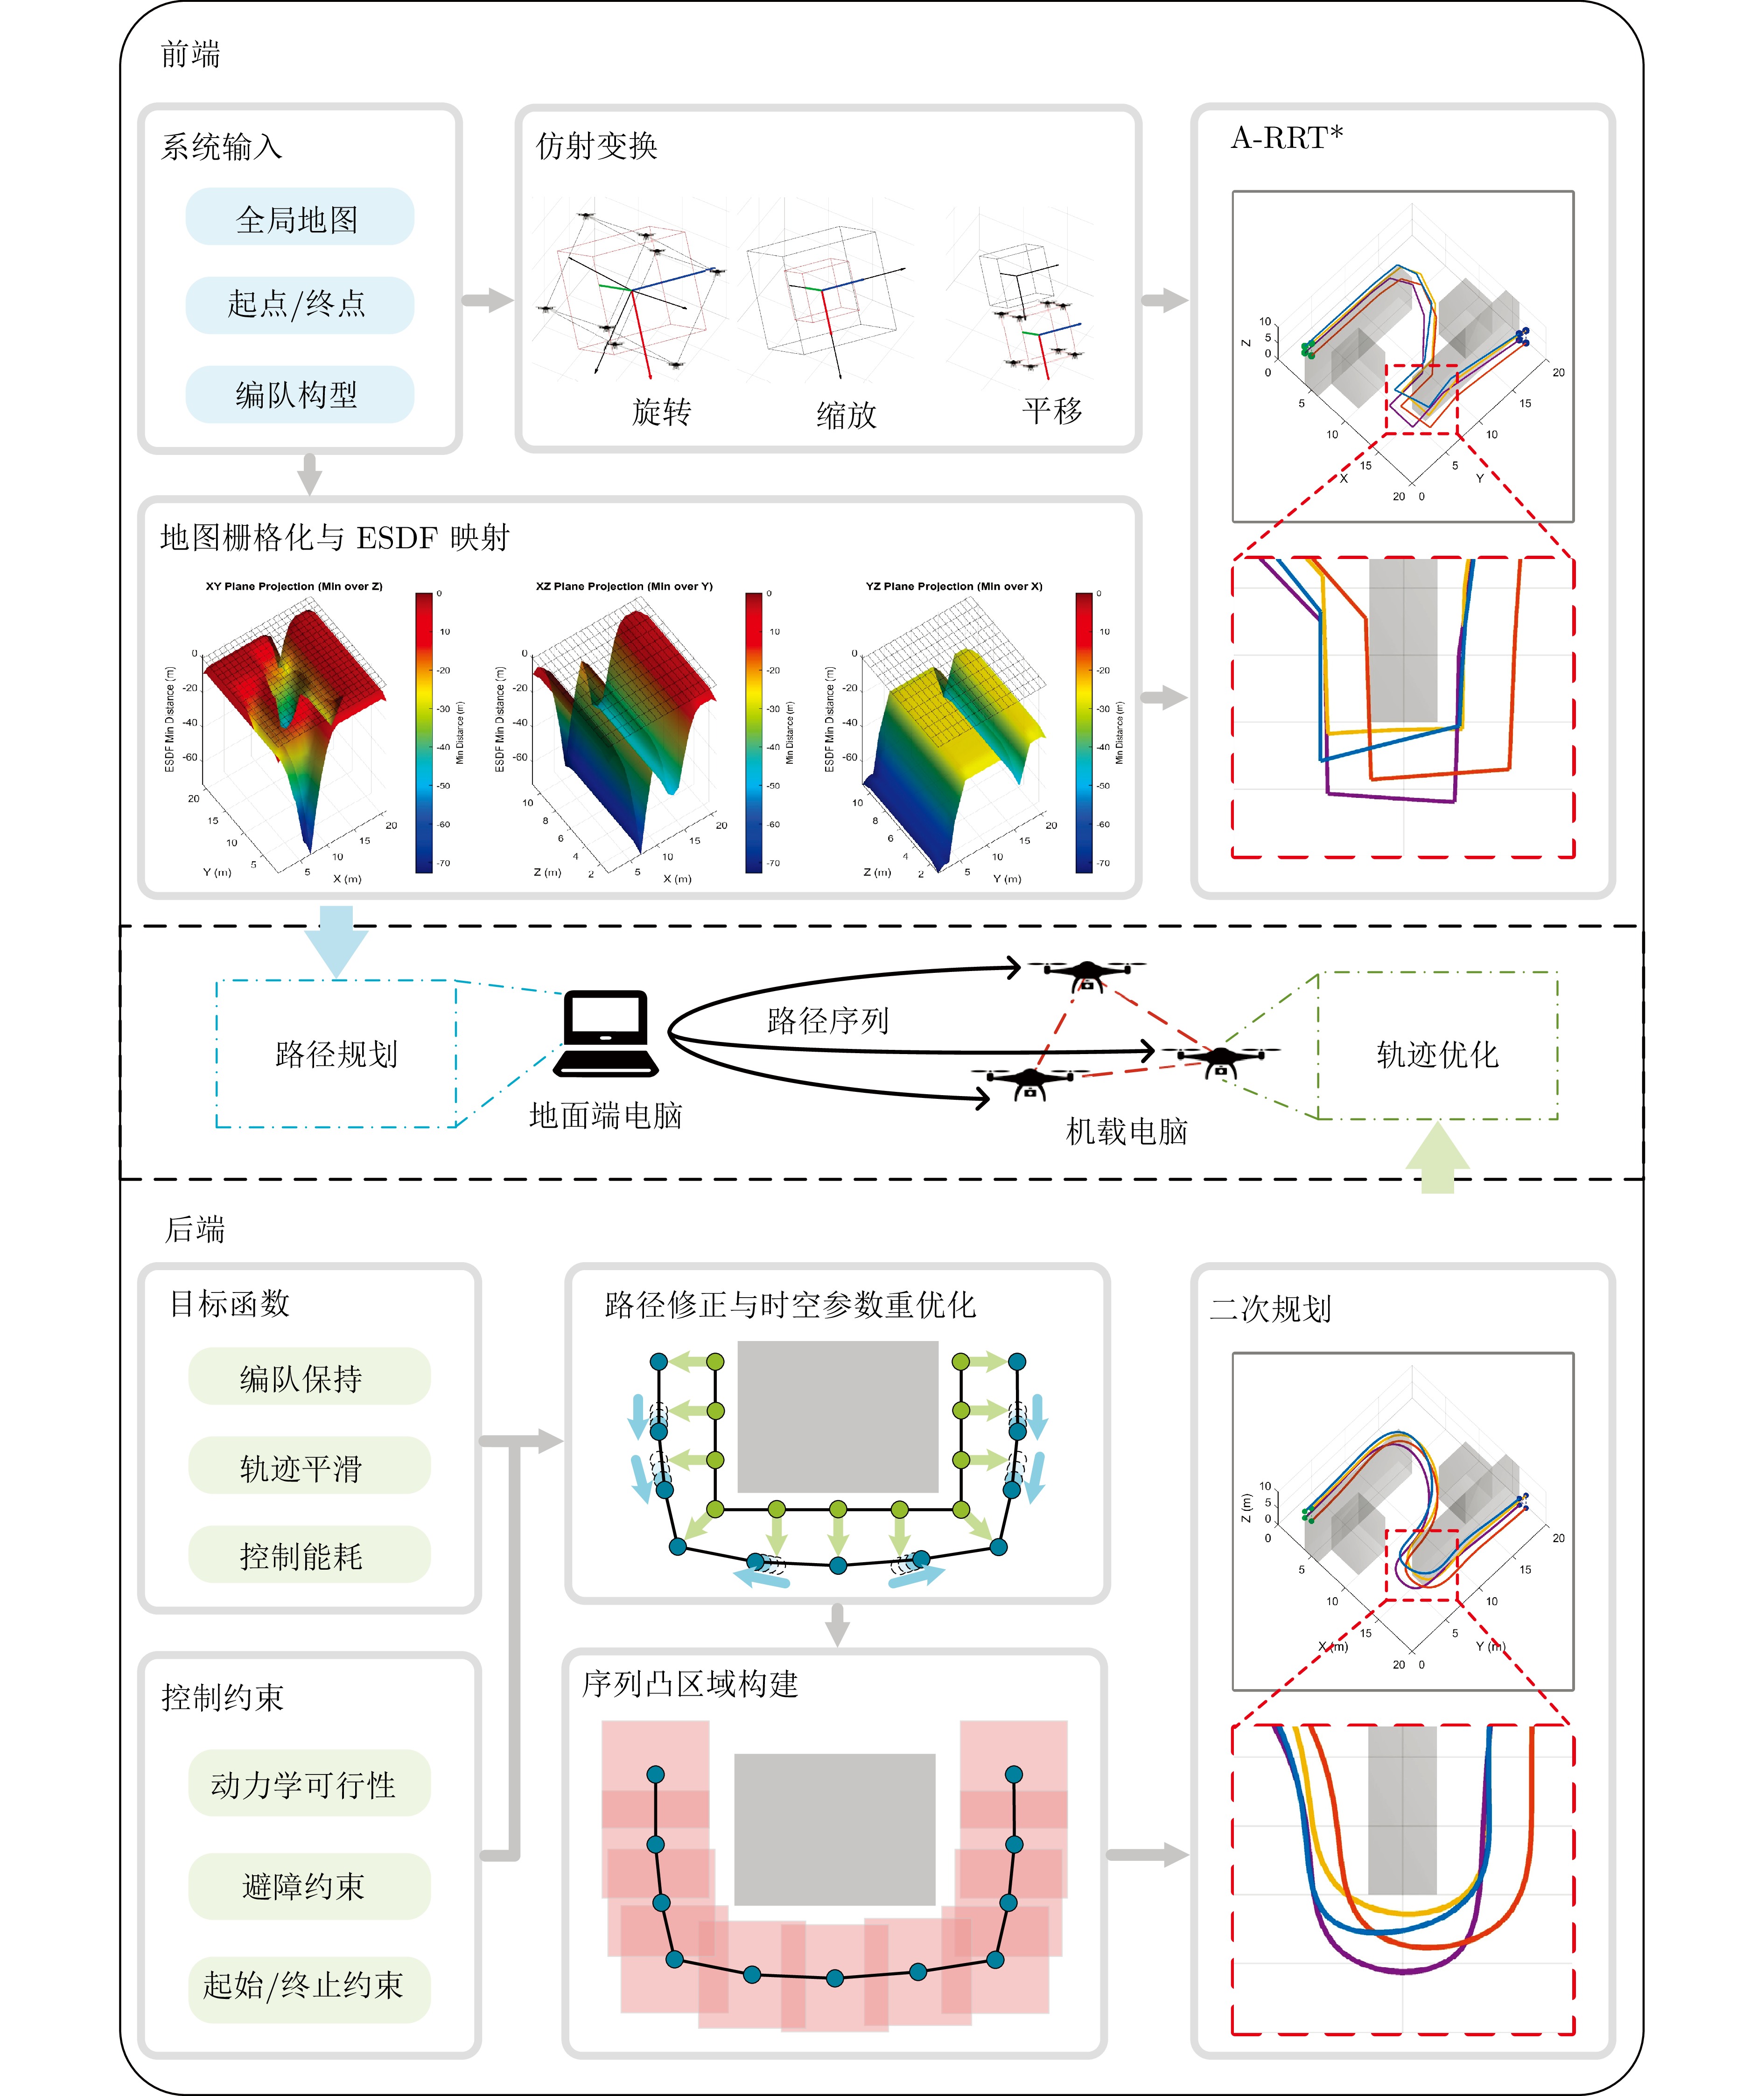
图 2 低空飞行器集群编队规划系统架构
Fig. 2 Low-altitude aircraft swarm formation planning system architecture
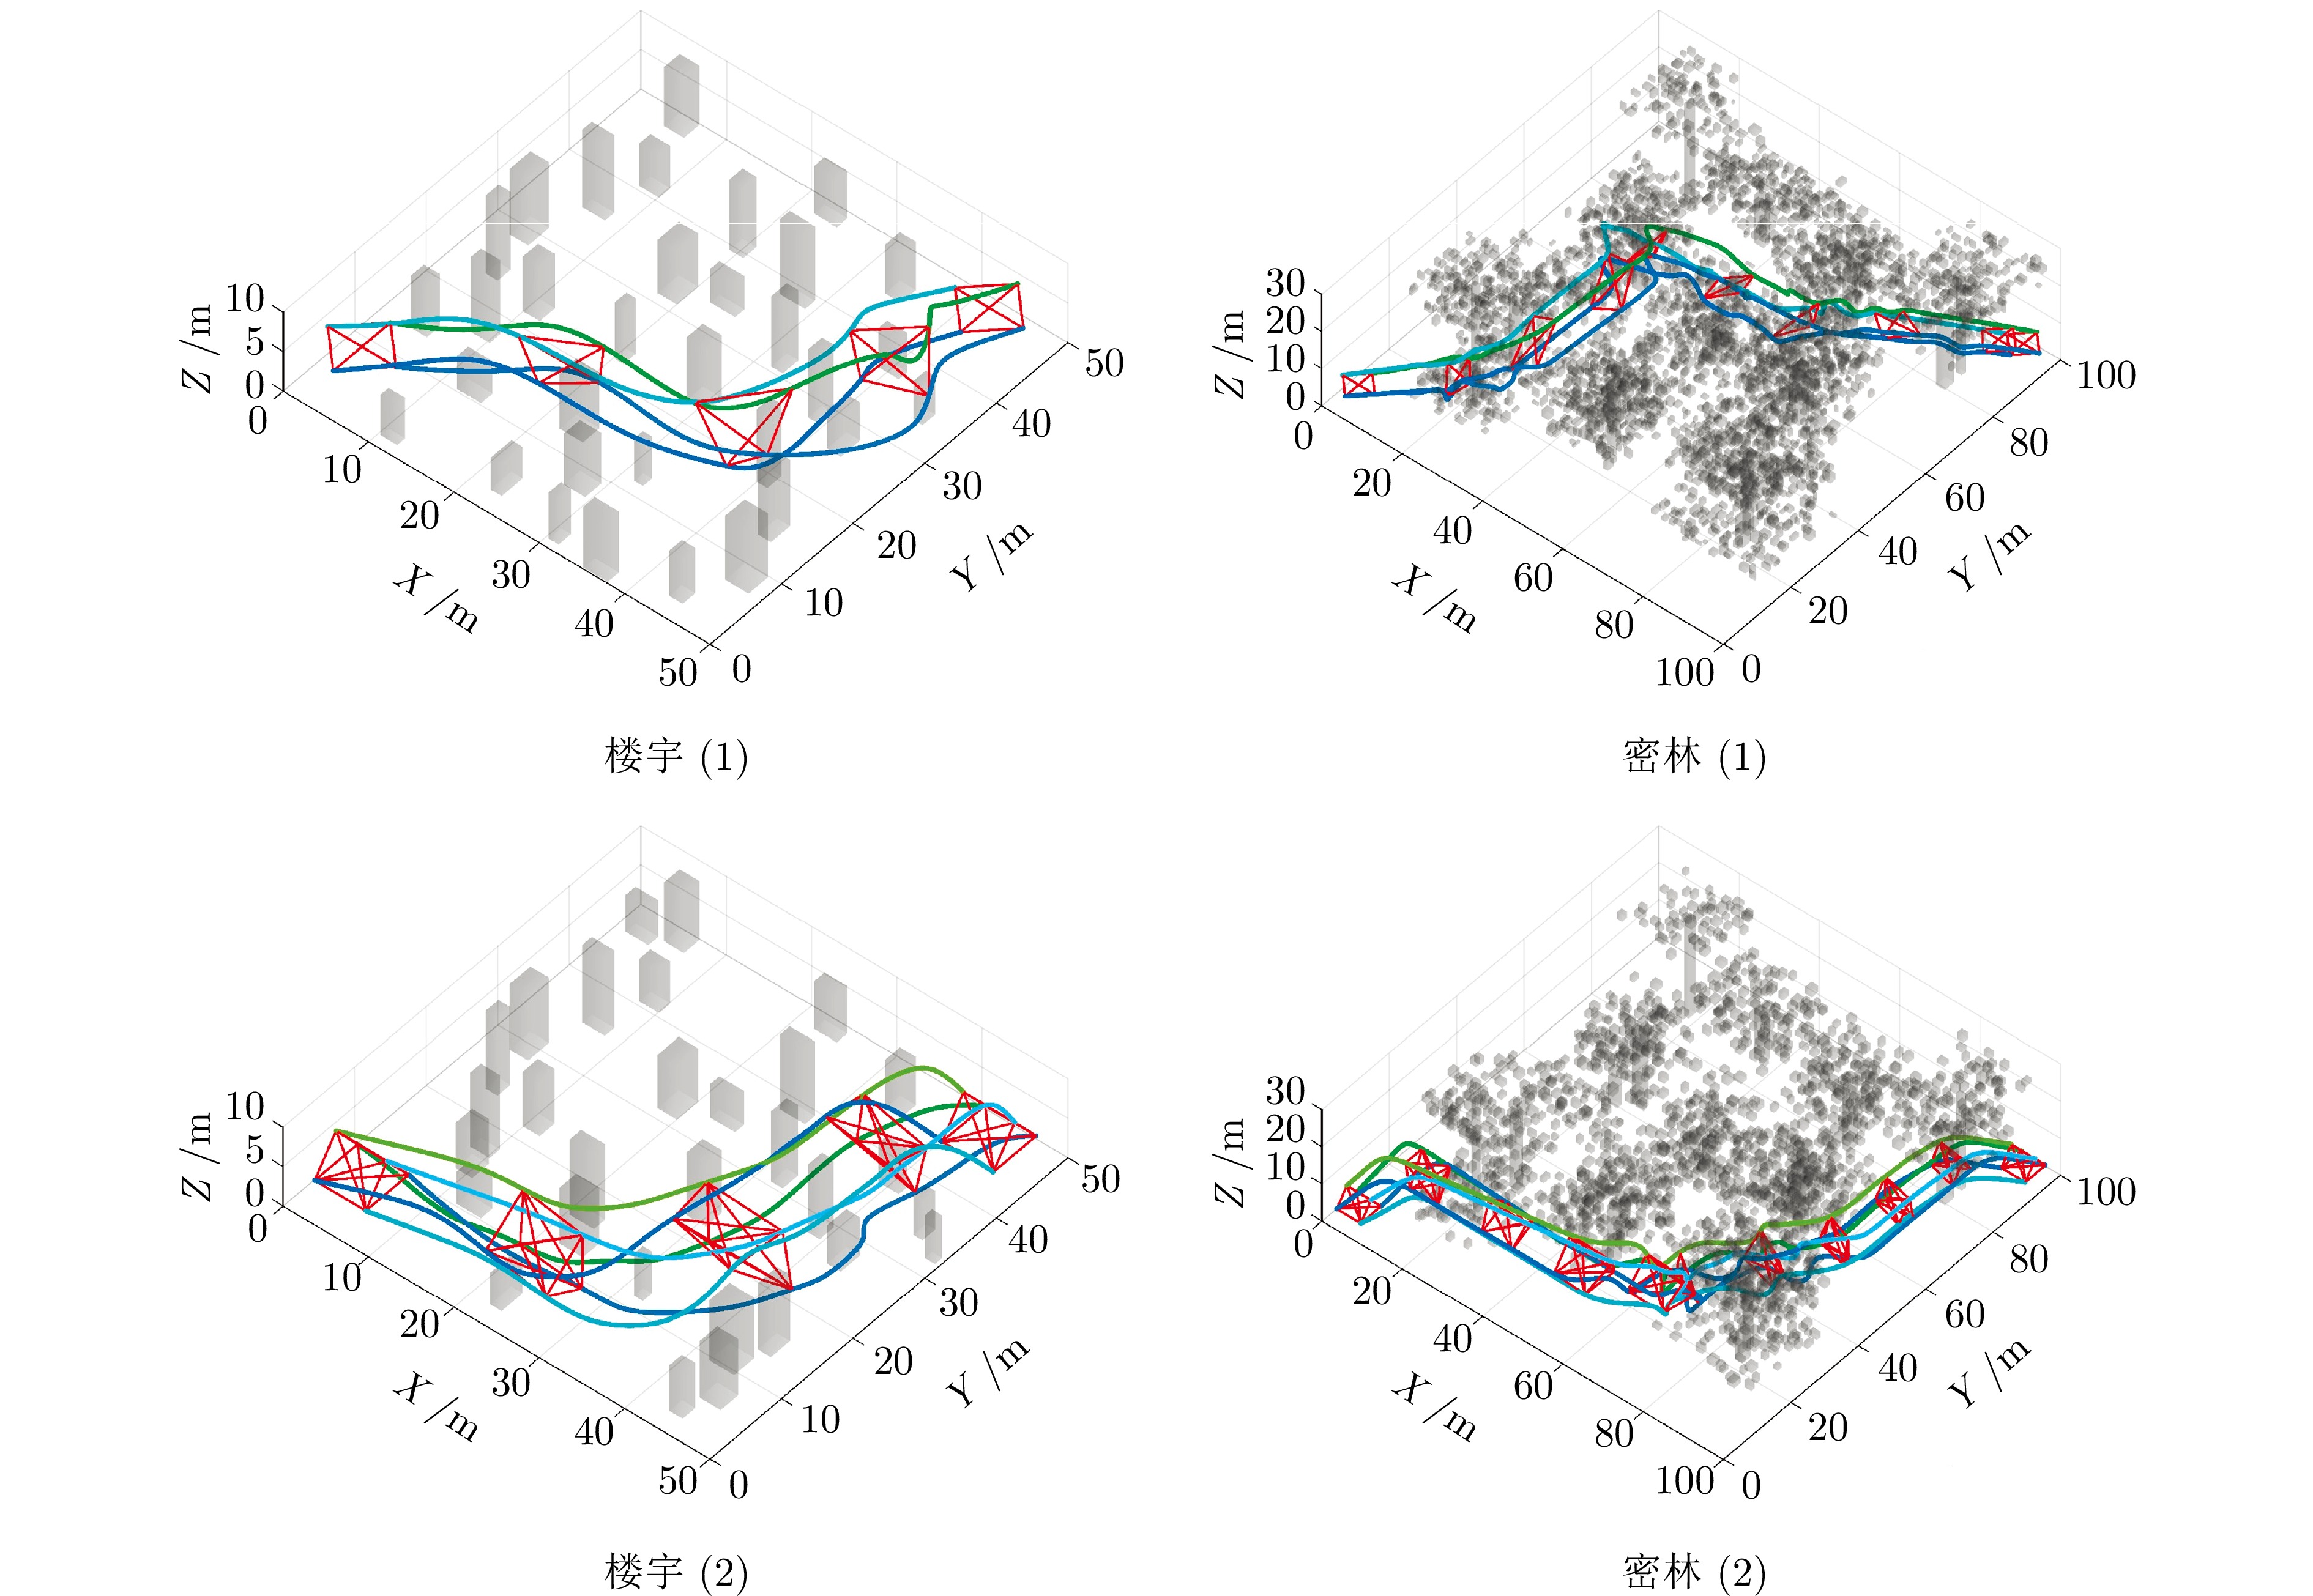
表 1 基准实验统计结果
Table 1 Statistics of baseline experiments
规划情景 前端搜索算法 后端优化算法 规划时间均值/标准差 /$\mathrm{s}$ 轨迹长度均值/标准差 /$\mathrm{m}$ 轨迹代价均值/标准差 楼宇(1) RRT-connect QP 0. 15/0. 06 314. 49/37. 92 241. 55/32. 93 RRT$^{\ast}$ QP 1. 15/0. 85 274. 74/19. 74 151. 54/69. 43 A-RRT$^{\ast}$ QP 0. 12/0. 07 284. 78/26. 22 159. 44/58. 10 A-RRT$^{\ast}$ B-spline 0. 12/0. 06 293. 37/31. 65 233. 26/78. 81 楼宇(2) RRT-connect QP 0. 43/0. 37 469. 88/31. 86 249. 85/28. 68 RRT$^{\ast}$ QP 2. 42/1. 93 426. 96/31. 77 190. 37/75. 21 A-RRT$^{\ast}$ QP 0. 37/0. 25 457. 85/48. 74 200. 80/44. 06 A-RRT$^{\ast}$ B-spline 0. 40/0. 34 480. 84/60. 23 398. 27/140. 97 密林(1) RRT-connect QP 6. 14/3. 61 783. 24/67. 28 594. 38/92. 02 RRT$^{\ast}$ QP 8. 99/3. 63 666. 52/51. 91 303. 54/34. 45 A-RRT$^{\ast}$ QP 6. 64/3. 32 660. 97/38. 13 335. 36/42. 93 A-RRT$^{\ast}$ B-spline 6. 51/3. 37 679. 02/62. 33 398. 30/108. 08 密林(2) RRT-connect QP 11. 04/7. 67 1209. 33 /69. 03610. 94/83. 71 RRT$^{\ast}$ QP 22. 68/19. 77 1036. 03 /43. 59320. 84/32. 16 A-RRT$^{\ast}$ QP 9. 88/6. 72 1058. 86 /40. 83341. 37/46. 58 A-RRT$^{\ast}$ B-spline 9. 41/7. 32 1083. 95 /51. 60516. 89/154. 76  下载: 导出CSV
-
[1] Mahdoui N, Frémont V, Natalizio E. Communicating multi-UAV system for cooperative SLAM-based exploration. Journal of Intelligent & Robotic Systems, 2020, 98(2): 325−343 doi: 10.1007/s10846-019-01062-6 [2] Dorling K, Heinrichs J, Messier G G, Magierowski S. Vehicle routing problems for drone delivery. IEEE Transactions on Systems, Man, and Cybernetics: Systems, 2017, 47(1): 70−85 doi: 10.1109/TSMC.2016.2582745 [3] Tian Y, Liu K, Ok K, Tran L, Allen D, Roy N, et al. Search and rescue under the forest canopy using multiple UAVs. The International Journal of Robotics Research, 2020, 39(10-11): 1201−1221 doi: 10.1177/0278364920929398 [4] 洪芳宇, 张涛, 杨昊, 等. 面向点与区域目标联合成像侦察的多无人机协同任务规划. 控制与决策, 2026, 41(4): 1122−1134 doi: 10.13195/j.kzyjc.2025.0827Hong F Y, Zhang T, Yang H, et al. Multi-UAV cooperative mission planning for joint imaging reconnaissance of point and area targets. Control and Decision, 2026, 41(4): 1122−1134 doi: 10.13195/j.kzyjc.2025.0827 [5] Lukina A, et al. Formation control and persistent monitoring in the OpenUAV swarm simulator on the NSF CPS-VO. In: Proceedings of the 2018 ACM/IEEE 9th International Conference on Cyber-Physical Systems (ICCPS). Porto, Portugal: IEEE, 2018. 353-354. DOI: 10. 1109/ICCPS. 2018. 00050 [6] van den Berg J P, Overmars M H. Roadmap-based motion planning in dynamic environments. IEEE Transactions on Robotics, 2005, 21(5): 885−897 doi: 10.1109/TRO.2005.851378 [7] Peasgood M, Clark C M, McPhee J. A complete and scalable strategy for coordinating multiple robots within roadmaps. IEEE Transactions on Robotics, 2008, 24(2): 283−292 doi: 10.1109/TRO.2008.918056 [8] Kloder S, Hutchinson S. Path planning for permutation-invariant multirobot formations. IEEE Transactions on Robotics, 2006, 22(4): 650−665 doi: 10.1109/TRO.2006.878952 [9] 王祝, 徐广通, 龙腾. 基于定制内点法的多无人机协同轨迹规划. 自动化学报, 2023, 49(11): 2374−2385 doi: 10.16383/j.aas.c200361Wang Z, Xu G T, Long T. Multi-UAV cooperative trajectory planning based on a customized interior-point method. Acta Automatica Sinica, 2023, 49(11): 2374−2385 doi: 10.16383/j.aas.c200361 [10] Li Y, Gupta K. Real-time motion planning of multiple formations in virtual environments: Flexible virtual structures and continuum model. In: Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). 2008. 1902-1907 [11] Roy D, Chowdhury A, Maitra M, Bhattacharya S. Multi-robot virtual structure switching and formation changing strategy in an unknown occluded environment. In: Proceedings of the IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). 2018. 4854-4861 [12] Seng W L, Barca J C, Sekercioglu Y A. Distributed formation control in cluttered environments. In: Proceedings of the 2013 IEEE/ASME International Conference on Advanced Intelligent Mechatronics (AIM). Wollongong, NSW, Australia: IEEE, 2013. 1387-1392. DOI: 10. 1109/AIM. 2013. 6584288 [13] Chi T, Zhang C, Song Y, Feng J. A strategy of multi-robot formation and obstacle avoidance in unknown environment. In: Proceedings of the 2016 IEEE International Conference on Information and Automation (ICIA). Ningbo, China: IEEE, 2016. 1455-1460. DOI: 10. 1109/ICInfA. 2016. 7832048 [14] Wen G, Chen C L P, Liu Y J. Formation control with obstacle avoidance for a class of stochastic multiagent systems. IEEE Transactions on Industrial Electronics, 2018, 65(7): 5847−5855 doi: 10.1109/TIE.2017.2782229 [15] 王耀南, 华和安, 张辉, 等. 性能函数引导的无人机集群深度强化学习控制方法. 自动化学报, 2025, 51(5): 905−916 doi: 10.16383/j.aas.c240519Wang Y N, Hua H A, Zhang H, et al. Deep reinforcement learning control method for UAV swarms guided by performance functions. Acta Automatica Sinica, 2025, 51(5): 905−916 doi: 10.16383/j.aas.c240519 [16] Rezaee H, Abdollahi F. A decentralized cooperative control scheme with obstacle avoidance for a team of mobile robots. IEEE Transactions on Industrial Electronics, 2014, 61(1): 347−354 doi: 10.1109/TIE.2013.2245612 [17] Zhou D, Wang Z, Schwager M. Agile coordination and assistive collision avoidance for quadrotor swarms using virtual structures. IEEE Transactions on Robotics, 2018, 34(4): 916−923 doi: 10.1109/TRO.2018.2857477 [18] La H M, Lim R, Sheng W. Multirobot cooperative learning for predator avoidance. IEEE Transactions on Control Systems Technology, 2015, 23(1): 52−63 doi: 10.1109/TCST.2014.2312392 [19] Bai C, Yan P, Pan W, Guo J. Learning-based multi-robot formation control with obstacle avoidance. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(8): 11811−11822 doi: 10.1109/TITS.2021.3107336 [20] 许海涛, 陈龙胜, 王宇翔, 等. 四旋翼无人机编队飞行路径规划及分布式协同控制. 控制理论与应用, 1-10[2026-03-29]Xu H T, Chen L S, Wang Y X, et al. Path planning and distributed cooperative control for quadrotor UAV formation flight. Control Theory & Applications, 1-10[2026-03-29]. [21] 王峰, 黄子路, 韩孟臣, 等. 基于KnCMPSO算法的异构无人机协同多任务分配. 自动化学报, 2023, 49(2): 399−414 doi: 10.16383/j.aas.c210696Wang F, Huang Z L, Han M C, et al. Heterogeneous UAV cooperative multi-task assignment based on KnCMPSO algorithm. Acta Automatica Sinica, 2023, 49(2): 399−414 doi: 10.16383/j.aas.c210696 [22] 周宏宇, 王小刚, 单永志, 等. 基于改进粒子群算法的飞行器协同轨迹规划. 自动化学报, 2022, 48(11): 2670−2676 doi: 10.16383/j.aas.c190865Zhou H Y, Wang X G, Shan Y Z, et al. Cooperative trajectory planning of aircraft based on an improved particle swarm optimization algorithm. Acta Automatica Sinica, 2022, 48(11): 2670−2676 doi: 10.16383/j.aas.c190865 [23] Xing X, Zhou Z, Li Y, Xiao B, Xun Y. Multi-UAV adaptive cooperative formation trajectory planning based on an improved MATD3 algorithm of deep reinforcement learning. IEEE Transactions on Vehicular Technology, 2024, 73(9): 12484−12499 doi: 10.1109/TVT.2024.3389555 [24] Zhao S. Affine formation maneuver control of multiagent systems. IEEE Transactions on Automatic Control, 2018, 63(12): 4140−4155 doi: 10.1109/TAC.2018.2798805 [25] Alonso-Mora J, Baker S, Rus D. Multi-robot formation control and object transport in dynamic environments via constrained optimization. The International Journal of Robotics Research, 2017, 36(9): 1000−1021 doi: 10.1177/0278364917719333 [26] Sha H, et al. Efficient global trajectory planning for multi-robot system with affinely deformable formation. In: Proceedings of the 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Abu Dhabi, United Arab Emirates: IEEE, 2024. 14148-14155. DOI: 10. 1109/IROS58592. 2024. 10802518 [27] Ye H, Pan N, Wang Q, Xu C, Gao F. Efficient sampling-based multirotors kinodynamic planning with fast regional optimization and post refining. In: Proceedings of the 2022 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Kyoto, Japan: IEEE, 2022. 3356-3363. DOI: 10. 1109/IROS47612. 2022. 9981707 [28] Campos-Macías L, Gómez-Gutiérrez D, Aldana-López R, de la Guardia R, Parra-Vilchis J I. A hybrid method for online trajectory planning of mobile robots in cluttered environments. IEEE Robotics and Automation Letters, 2017, 2(2): 935−942 doi: 10.1109/LRA.2017.2655145 [29] Zhou B, Gao F, Wang L, Liu C, Shen S. Robust and efficient quadrotor trajectory generation for fast autonomous flight. IEEE Robotics and Automation Letters, 2019, 4(4): 3529−3536 doi: 10.1109/LRA.2019.2927938 [30] Xie Y J, Yu X, Qiao J Z, Zhang K W, Shi Y, Guo L. Composite anti-disturbance control with disturbance prediction and utilization: A tube MPC approach. Automatica, 2026, 184: 112700 doi: 10.1016/j.automatica.2025.112700 [31] Wang L, Wen G, Zhou J, Zhu H. Event-triggered finite-time attitude control for multiple rigid spacecraft with user-defined attitude constraints. IEEE Transactions on Aerospace and Electronic Systems, 2025, 61(3): 6885−6896 doi: 10.1109/TAES.2025.3533459 [32] Wang L, Wen G, Du H, Zhou J. Finite-time complementary filter-based attitude control of autonomous aerial vehicles with gyro bias. IEEE Transactions on Aerospace and Electronic Systems, 2025, 61(2): 4707−4718 doi: 10.1109/TAES.2024.3507775 -

 下载:

计量
- 文章访问数: 11
- HTML全文浏览量: 8
- 被引次数: 0
