

Adaptive Dynamic Event-Triggered Optimal Control for Vehicle Platoon System under Jointly Connected Switching Topology
-
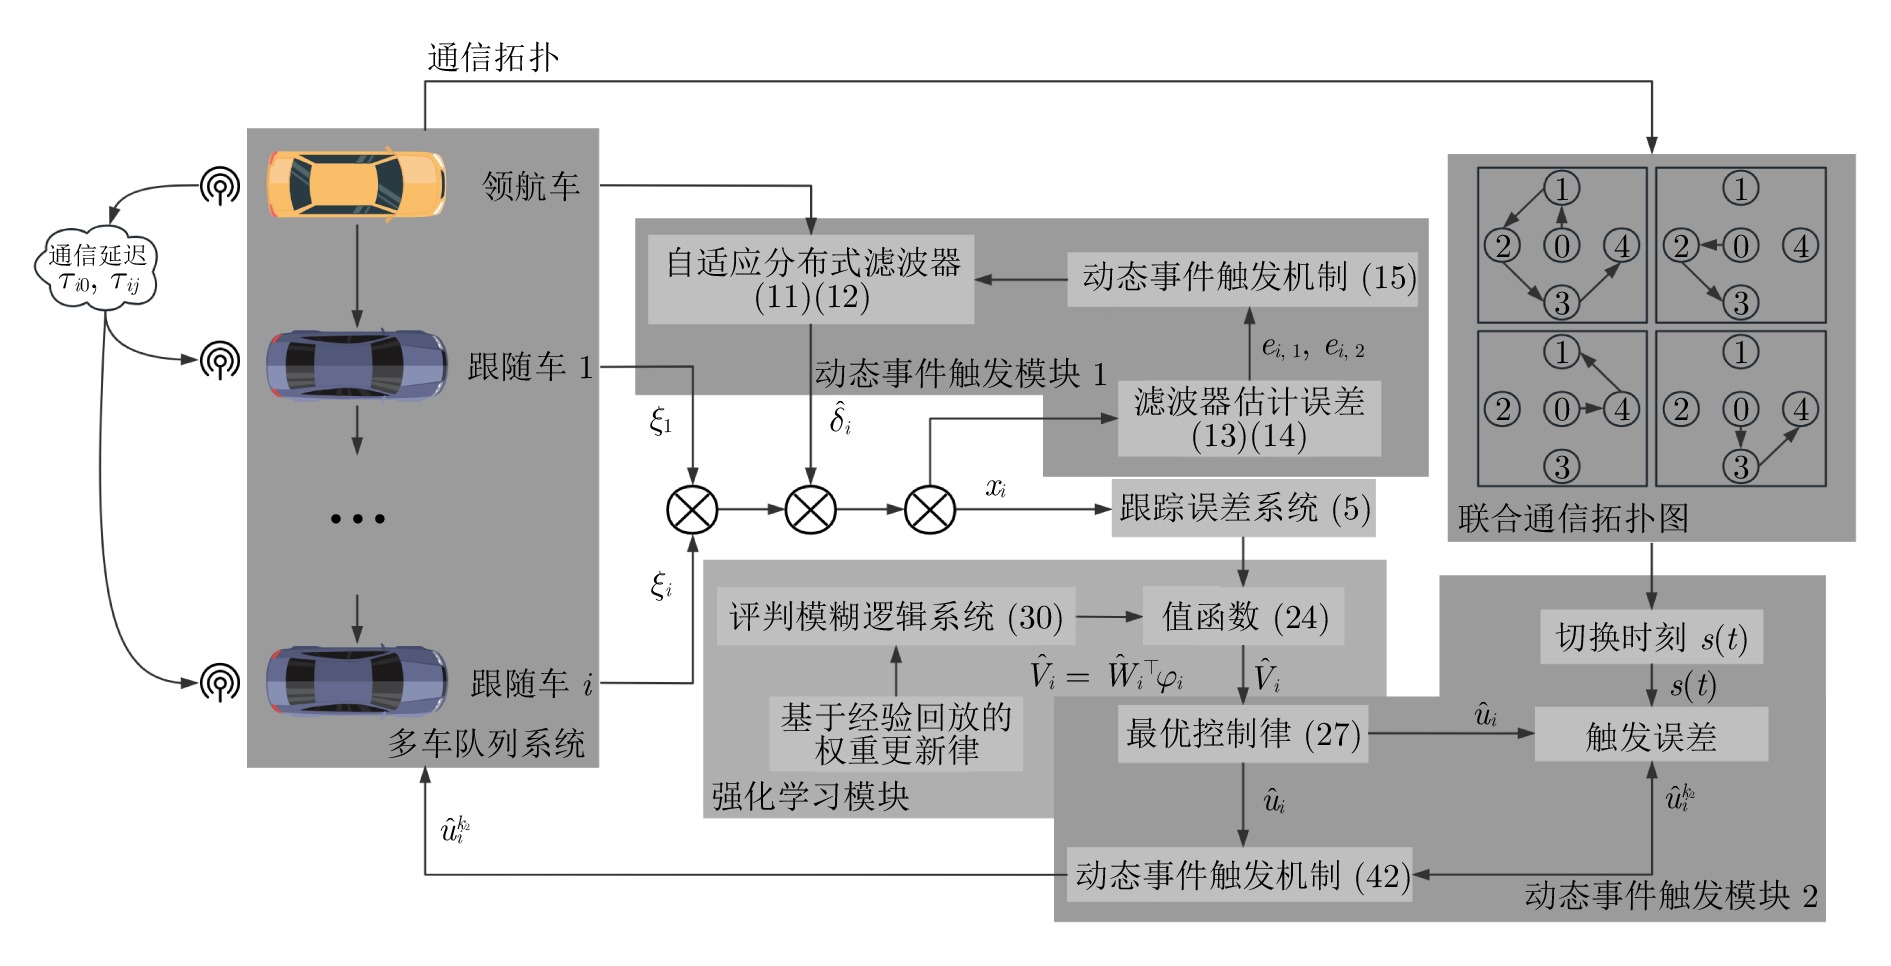
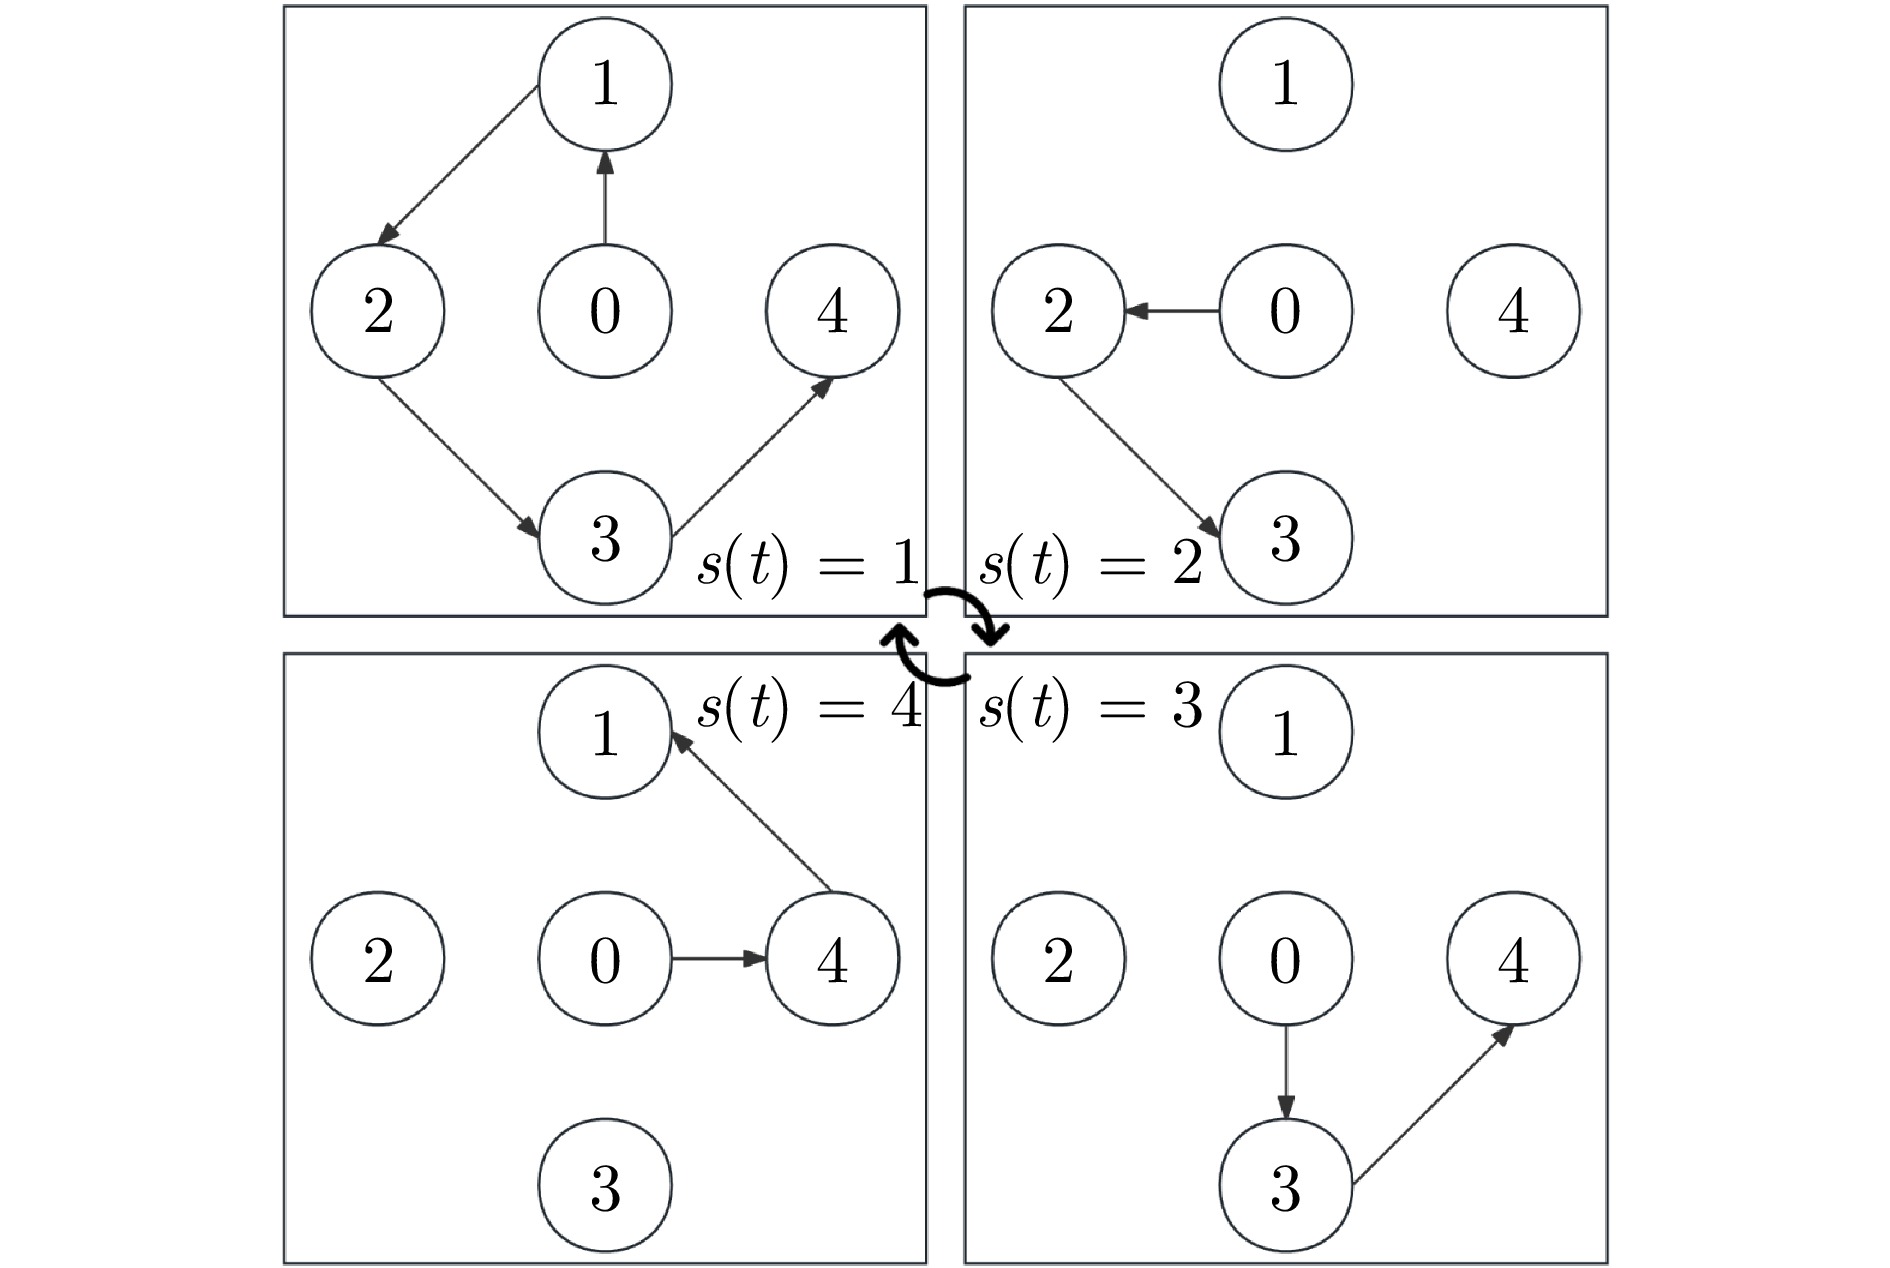
摘要: 针对通信带宽有限且存在输入饱和的非线性多车队列系统, 本文研究联合切换拓扑与通信延迟下模糊自适应动态事件触发最优控制设计问题. 首先, 为具有输入饱和的队列系统构建新的性能指标函数. 其次, 采用积分强化学习方法在线求解最优控制中的哈密顿-雅可比-贝尔曼方程, 并针对积分强化学习中对于持续激励条件的严格要求, 提出基于经验回放机制的梯度下降以更新模糊逻辑系统权重, 进而放宽传统积分强化学习对持续激励条件的严格要求. 在此基础上, 本文分别在通信端与控制端引入双重动态事件触发机制, 有效节省车载资源. 通过构造李雅普诺夫函数并结合平均驻留时间方法, 证明闭环系统中所有信号最终一致有界. 与现有的事件触发机制相比, 所提出双重事件触发机制可节省60.81%资源. 数值仿真结果进一步验证上述所提出动态事件触发最优控制方法的有效性.Abstract: For nonlinear vehicle platoon systems with limited communication bandwidth and input saturation, this paper investigates the issue of fuzzy adaptive dynamic event-triggered optimal control under jointly switching topologies and communication delays. Firstly, a novel performance index function is constructed for the platoon system with input saturation. Furthermore, an integral reinforcement learning method is employed to online solve the Hamilton-Jacobi-Bellman equation in the optimal control. To address the strict requirement of the persistence of excitation condition in integral reinforcement learning, a gradient descent method based on an experience replay mechanism is proposed to update the weights of the fuzzy logic system, thereby relaxing the strict persistence of excitation condition required by traditional integral reinforcement learning. On this basis, a dual dynamic event-triggered mechanism is introduced at both the communication and control ends which can effectively save on-board resources. By constructing a Lyapunov function and employing the average dwell time method, it is proven that all signals in the closed-loop system are uniformly ultimately bounded. Compared with the existing event triggered mechanisms, the proposed dual event-triggered mechanism saves 60.81% resources. Numerical simulation results further verify the effectiveness of the developed dynamic event-triggered optimal control method.
-
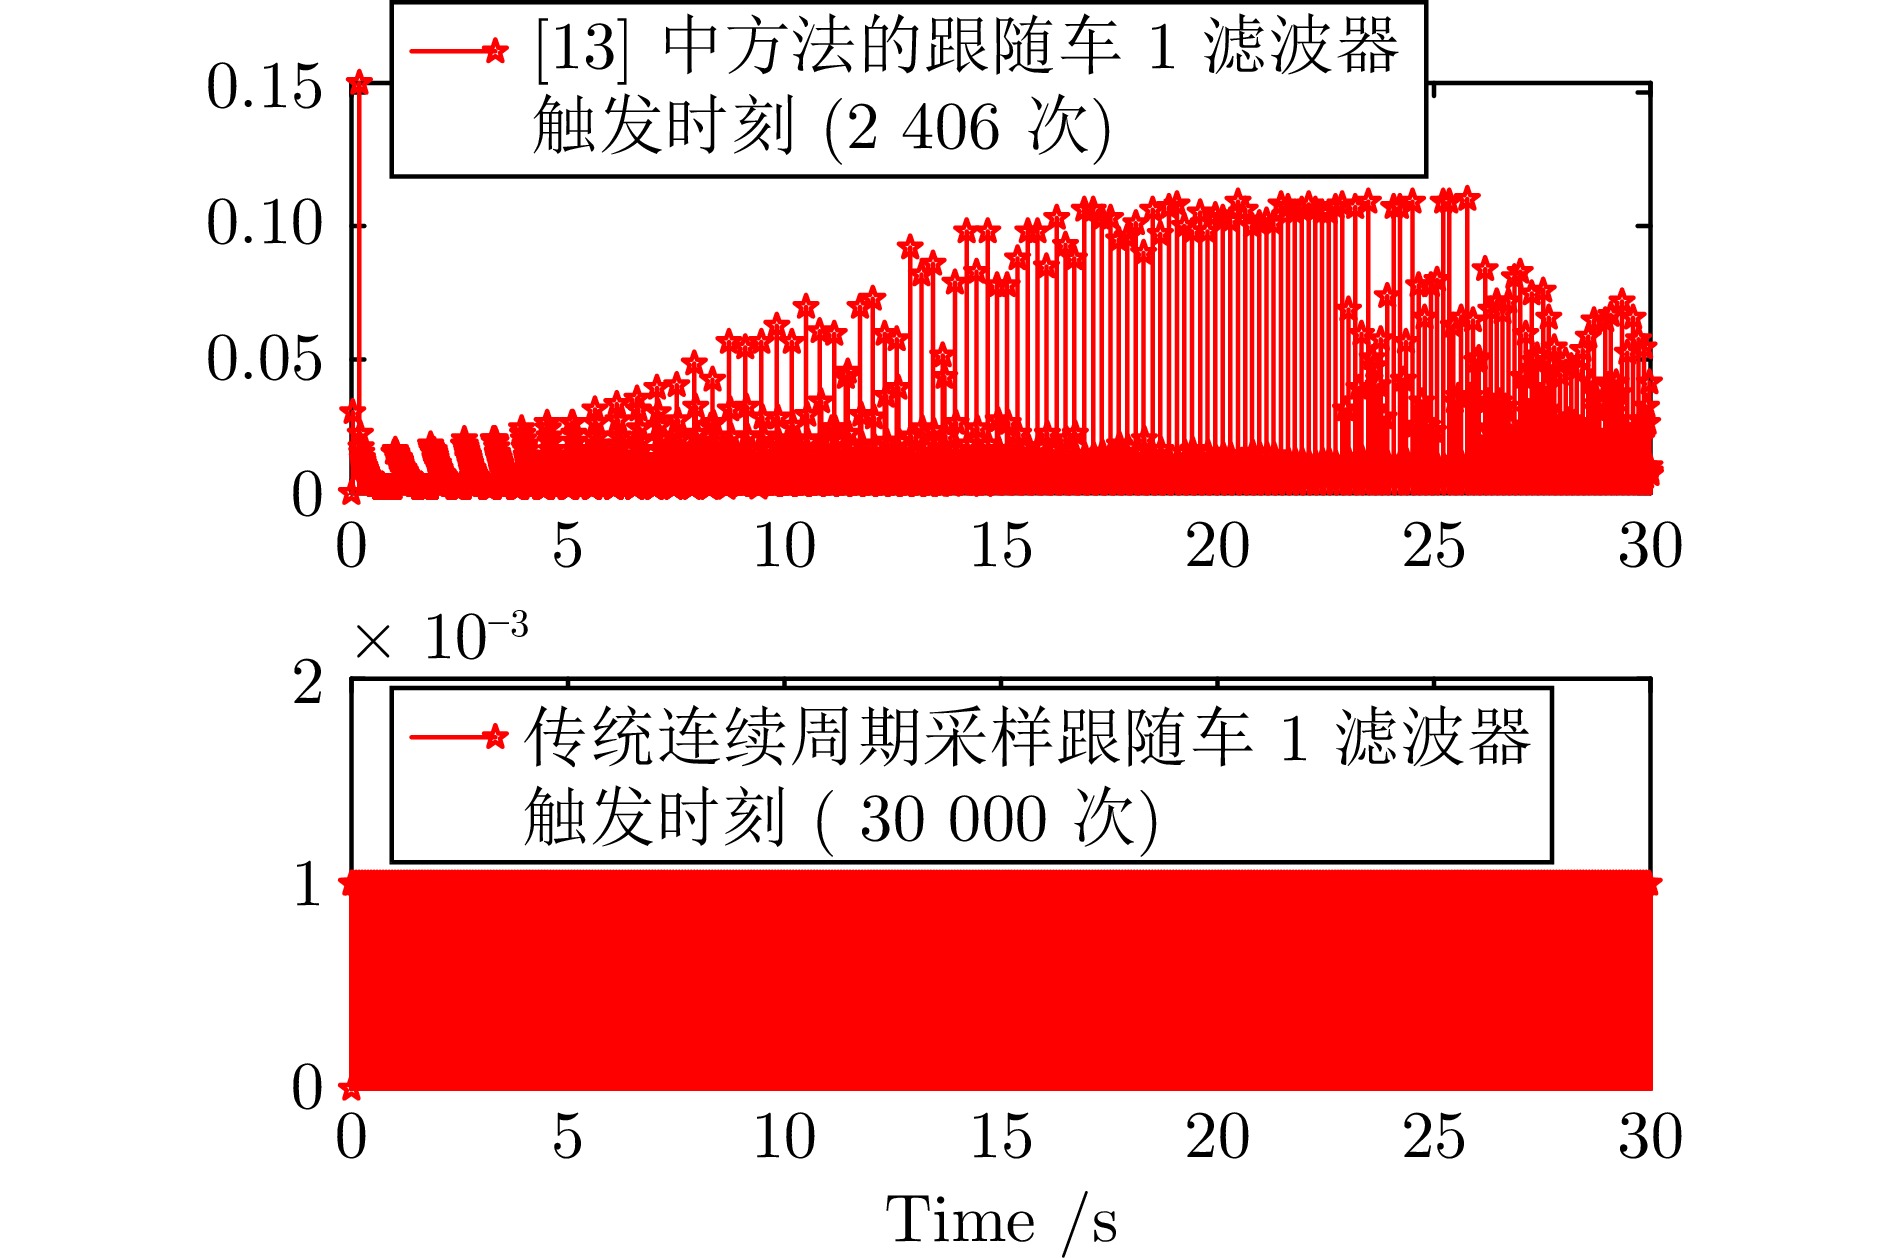
表 1 跟随车的参数
Table 1 The parameters of the followers
车辆$ i $ 跟随车1 跟随车2 跟随车3 跟随车4 $ l_i({\rm{m}}) $ 2.3 3.4 2.4 3.2 $ A_i({\rm{m}}^2) $ 0.21 0.3 0.25 0.27 $ m_i({\rm{kg}}) $ 1100 1050 1200 1300 $ r_i $ 0.01 0.02 0.015 0.02 $ \tau_i $ 0.4 0.3 0.4 0.45  下载: 导出CSV
表 2 队列系统的初始状态
Table 2 Initial status of the platoon system
车辆$ i $ $ p_i(0)({\rm{m}}) $ $ v_i(0)({\rm{m/s}}) $ $ a_i(0)({\rm{m/s}}^2) $ 领航车0 22 15 0 跟随车1 16.5 14.5 0 跟随车2 11.2 14 0 跟随车3 6.1 13.5 0 跟随车4 0.8 13 0
下载: 导出CSV
表 3 部分仿真参数
Table 3 Partial simulation parameters
参数 值 参数 值 $ Q_i $ 1 $ {\rm{P}}_i $ 0.9 $ R_{ii} $ 1 $ \alpha_{i,\;1} $ 1 $ R_{ij} $ 1 $ \alpha_{i,\;2} $ 8 $ \alpha_i^c $ 1.4 $ \alpha_{i,\;3} $ 0.1 $ \lambda_{i,\;2}(0) $ 5 $ \alpha_{i,\;4} $ 0.3 $ \Phi_i $ 0.4 $ \alpha_{i,\;5} $ 2 $ \varphi_i $ 5 $ \alpha_{i,\;6} $ 0.02 $ \omega_i $ 0.9 $ \bar{\varepsilon} $ 0.001
下载: 导出CSV
-
[1] Li Y M, Zhao Y Y, Liu W, Hu J. Adaptive fuzzy predefined-time control for third-order heterogeneous vehicular platoon systems with dead zone. IEEE Transactions on Industrial Informatics, 2023, 19(9): 9525−9534 doi: 10.1109/TII.2022.3221220 [2] 丁飞, 张楠, 李升波, 边有钢, 童恩, 李克强. 智能网联车路云协同系统架构与关键技术研究综述. 自动化学报, 2022, 48(12): 2863−2885 doi: 10.16383/j.aas.c211108Ding Fei, Zhang Nan, Li Sheng-Bo, Bian You-Gang, Tong En, Li Ke-Qiang. A survey of architecture and key technologies of intelligent connected vehicle-road-cloud cooperation system. Acta Automatica Sinica, 2022, 48(12): 2863−2885 doi: 10.16383/j.aas.c211108 [3] 宋秀兰, 李洋阳, 何德峰. 外部干扰和随机DoS攻击下的网联车安全 $H\infty $队列控制. 自动化学报, 2024, 50(02): 348−355Song Xiu-Lan, Li Yang-Yang, He De-Feng. Secure $H\infty $ platooning control for connected vehicles subject to external disturbance and random DoS attacks. Acta Automatica Sinica, 2024, 50(02): 348−355 [4] 朱永薪, 李永福, 朱浩, 于树友. 通信延时环境下基于观测器的智能网联车辆队列分层协同纵向控制. 自动化学报, 2023, 49(8): 1785−1798 doi: 10.16383/j.aas.c210311Zhu Yong-Xin, Li Yong-Fu, Zhu Hao, Yu Shu-You. Observer-based longitudinal control for connected and automated vehicles platoon subject to communication delay. Acta Automatica Sinica, 2023, 49(8): 1785−1798 doi: 10.16383/j.aas.c210311 [5] 陈瀅媛, 董振江, 董建阔, 徐敏杰. 车联网安全防护技术综述. 电信科学, 2023, 39(3): 1−15Chen Fu-Yuan, Dong Zhen-Jiang, Dong Jian-Kuo, Xu Min-Jie. A review of security protection technology for internet of vehicles. Telecommunications Science, 2023, 39(3): 1−15 [6] Chen J C, Zhang H, Yin G D. Distributed dynamic event-triggered secure model predictive control of vehicle platoon against DoS attacks. IEEE Transactions on Vehicular Technology, 2022, 72(3): 2863−2877 doi: 10.1109/tvt.2022.3215966 [7] Han Q, et. al. Resilient event-triggered control of vehicle platoon under DoS attacks and parameter uncertainty. IEEE Transactions on Intelligent Vehicles, 2025, 10(1): 2863−2877 [8] Ge X, Han Q L, Wu Q, et. al. Resilient and safe platooning control of connected automated vehicles against intermittent denial-of-service attacks. IEEE/CAA Journal of Automatica Sinica, 2022, 10(5): 1234−1251 doi: 10.1109/jas.2022.105845 [9] Ding S B, Ai H P, Xie X P, et. al. Distributed adaptive platooning control of connected vehicles with Markov switching topologies. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(11): 18421−18432 doi: 10.1109/TITS.2024.3412171 [10] Wen S, Guo G. Sampled-data control for connected vehicles with Markovian switching topologies and communication delay. IEEE Transactions on Intelligent Transportation Systems, 2019, 21(7): 2930−2942 doi: 10.1109/tits.2019.2921781 [11] Yan Y, Du H, Han Q L, et. al. Discrete Multi-Objective Switching Topology Sliding Mode Control of Connected Autonomous Vehicles With Packet Loss. IEEE Transactions on Intelligent Vehicles, 2023, 8(4): 2926−2938 doi: 10.1109/TIV.2022.3215139 [12] Tian Z X, Li Y M, Tong S C. Adaptive NN event-triggered output feedback control for heterogeneous vehicular platoon systems with switching topologies. IEEE Transactions on Intelligent Vehicles, DOI: 10.1109/TIV.2024.3447653. [13] Zhang H, Liu J, Wang Z P, et. al. Distributed adaptive event-triggered control and stability analysis for vehicular platoon. IEEE Transactions on Intelligent Transportation Systems, 2021, 22(3): 1627−1638 doi: 10.1109/TITS.2020.2974280 [14] Zhang Z R, Wen C Y, Xing L T, et. al. Adaptive event-triggered control of uncertain nonlinear systems using intermittent output only. IEEE Transactions on Automatic Control, 2022, 67(8): 4218−4225 doi: 10.1109/TAC.2021.3115435 [15] Zhu P P, Jin S T, Bu X H, et. al. Distributed data-driven event-triggered fault-tolerant control for a connected heterogeneous vehicle platoon with sensor faults. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(6): 5498−5509 doi: 10.1109/TITS.2023.3335227 [16] Zhang Y H, Niu B, Zhao X D, et. al. Dynamic event-triggered nonsingular predefined-time tracking control for fully heterogeneous vehicle platoon with spacing constraints. IEEE Transactions on Cybernetics, 2025, 55(8): 3651−3662 doi: 10.1109/TCYB.2025.3568813 [17] Chen J C, Zhang H, Yin G D. Distributed dynamic event-triggered secure model predictive control of vehicle platoon against DoS attacks. IEEE Transactions on Vehicular Technology, 2023, 72(3): 2863−2877 doi: 10.1109/TVT.2022.3215966 [18] Jiang Y, Chai T, Chen G. Output feedback based adaptive optimal output regulation for continuous-time strict-feedback nonlinear systems. IEEE Transactions on Automatic Control, 2025, 70(2): 767−782 doi: 10.1109/TAC.2024.3441668 [19] Jiang Y, Fan J, Gao W, et. al. Cooperative adaptive optimal output regulation of nonlinear discrete-time multi-agent systems. Automatica, 2020, 121: 109149 doi: 10.1016/j.automatica.2020.109149 [20] Tian Z X, Li Y M, Tong S C. Distributed adaptive NN resilient optimal control for heterogeneous vehicular platoon systems under DoS attacks. IEEE Transactions on Network Science and Engineering, 2025, 12(4): 3299−3310 doi: 10.1109/TNSE.2025.3559130 [21] Wang Z, Na J, Taghavifar H, et. al. Event-triggered adaptive optimal control of vehicular platoons via fuzzy ADP with prescribed performance. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(11): 19398−19412 doi: 10.1109/TITS.2025.3600180 [22] Bejarbaneh E Y, Du H, Shen J. A robust reinforcement learning framework for platoon control of heterogeneous vehicles under uncertain dynamics. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(12): 22031−22044 doi: 10.1109/TITS.2025.3613589 [23] Basar T, Olsder G J. Dynamic noncooperative game theory. Soc. Ind. Appl. Math., 1998. [24] Gao W N, Jiang Z P. Learning-based adaptive optimal tracking control of strict-feedback nonlinear systems. IEEE Transactions on Neural Networks and Learning Systems, 2018, 29(6): 2614−2624 doi: 10.1109/TNNLS.2017.2761718 [25] Li Y M, Zhao Y Y, Tong S C. Adaptive fuzzy control for heterogeneous vehicular platoon systems with collision avoidance and connectivity preservation. IEEE Transactions on Fuzzy Systems, 2023, 31(11): 3934−3943 doi: 10.1109/TFUZZ.2023.3271904 [26] Wang L X. Adaptive fuzzy systems and control: design and stability analysis. Hoboken NJ, USA: Prentice-Hall, 1994. [27] Moreau L. Stability of continuous-time distributed consensus algorithms. In: Proceedings of the 43rd IEEE Conference on Decision and Control (CDC), Nassau, Bahamas, Dec. 14-17, 2004, 4: 3998-4003. [28] Vamvoudakis K G, Lewis F L, Hudas G R. Multi-agent differential graphical games: online adaptive learning solution for synchronization with optimality. Automatica, 2012, 48(8): 1598−1611 doi: 10.1016/j.automatica.2012.05.074 [29] Hao Y H, Zhang J, and Liu L. Fully distributed event-triggered cooperative output regulation of multiagent systems under jointly connected digraphs. IEEE Transactions on Automatic Control, 2023, 68(7): 4241−4248 doi: 10.1109/tac.2022.3200961 -

 下载:

计量
- 文章访问数: 16
- HTML全文浏览量: 11
- 被引次数: 0
