

Clustered Robot Collaborative Scheduling and Planning Control Method for Large-Scale Equipment Manufacturing
-
摘要: 随着大型装备制造向集群化与智能化发展, 集群机器人在强时序耦合与共享空间约束下的调度与管控面临挑战. 现有研究多采用调度−规划分层解耦建模, 难以刻画机器人动态交互引发的时空约束变化, 导致计划与执行存在偏差和不确定事件下高成本重调度. 为此, 本文提出基于数字孪生的调度−规划闭环管控方法: 将轨迹预测引入调度决策, 预测并量化动态交互引发的时空成本. 将其作为调度决策依据, 减小计划与执行之间的偏差. 进一步构建了动态重调度机制, 利用数字孪生的实时感知与推演能力, 实现对设备故障等突发事件的快速局部响应. 以飞机蒙皮−长桁自动化装配场景为典型案例验证所提方法. 结果表明, 在不同规模扰动场景下, 该方法可将执行偏差稳定控制在2%以内. 在保证系统可靠性的同时, 提升调度方案的执行一致性与环境适应能力. 本文研究为构建高可靠、强自适应的大型装备集群机器人智能制造系统提供了有效支撑.Abstract: As large-equipment manufacturing moves toward clustering and intelligence, scheduling and control of clustered robots under tight temporal coupling and shared spatial constraints face challenges. Existing studies mostly use hierarchically decoupled scheduling-planning modeling, struggling to capture spatiotemporal constraint changes from dynamic robot interactions. This leads to plan-execution deviations and costly rescheduling under uncertain events. To this end, this paper proposes a digital twin-based scheduling-planning closed-loop control method: trajectory prediction is introduced into scheduling decisions to predict and quantify spatiotemporal costs from dynamic interactions. These costs guide scheduling decisions to reduce plan-execution deviations. A dynamic rescheduling mechanism is further built, using digital twin real-time perception and simulation for rapid local responses to sudden events such as equipment failures. The method is validated in a typical aircraft skin-stringer automated assembly scenario. Results show that under disturbances of different scales, execution deviation remains within 2%. While ensuring system reliability, it improves scheduling solutions' execution consistency and environmental adaptability. This provides effective support for building highly reliable, strongly adaptive intelligent manufacturing systems for large-equipment cluster robots.
-
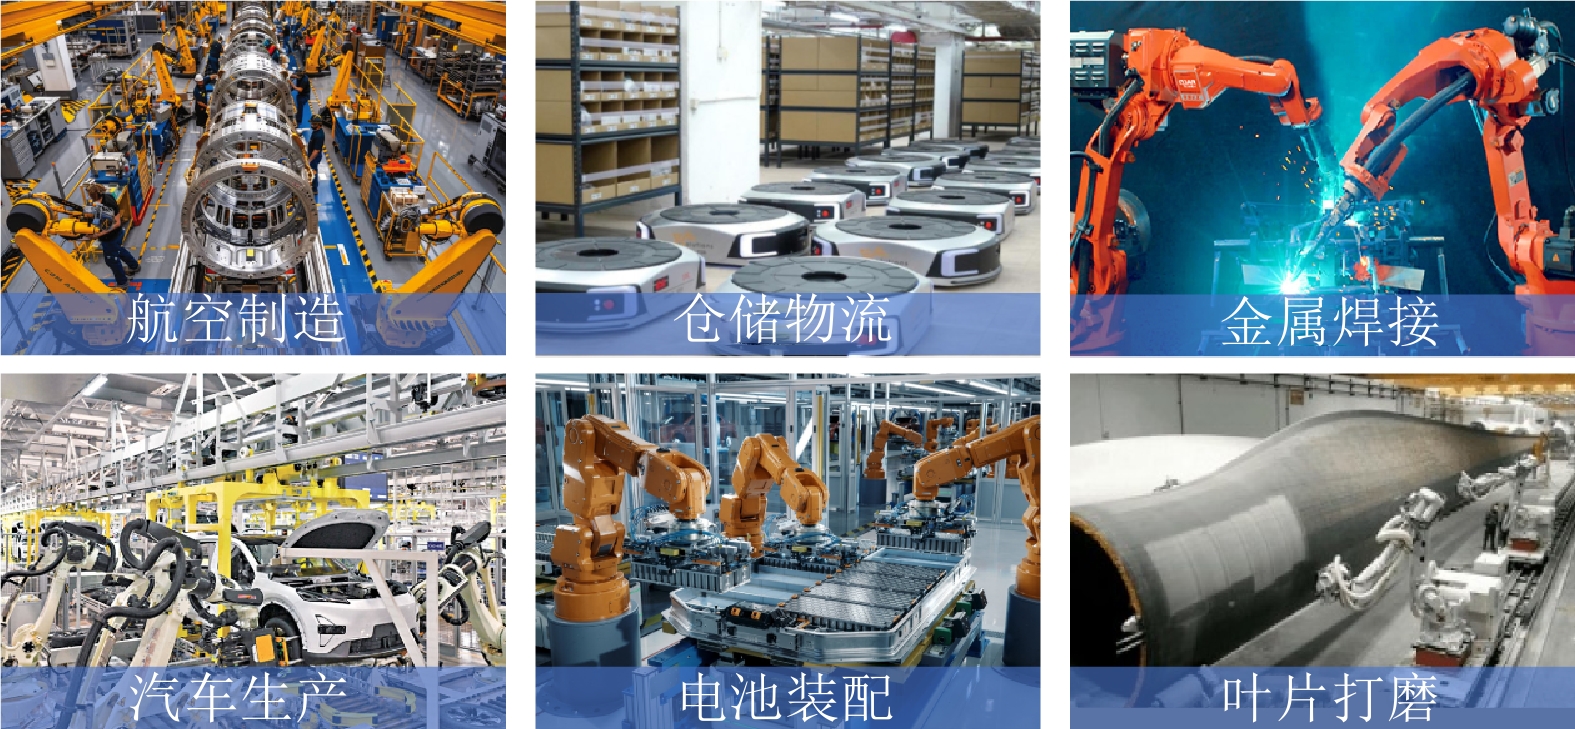
图 1 重大装备机器人协同制造场景
Fig. 1 Collaborative manufacturing scenarios for major equipment robots
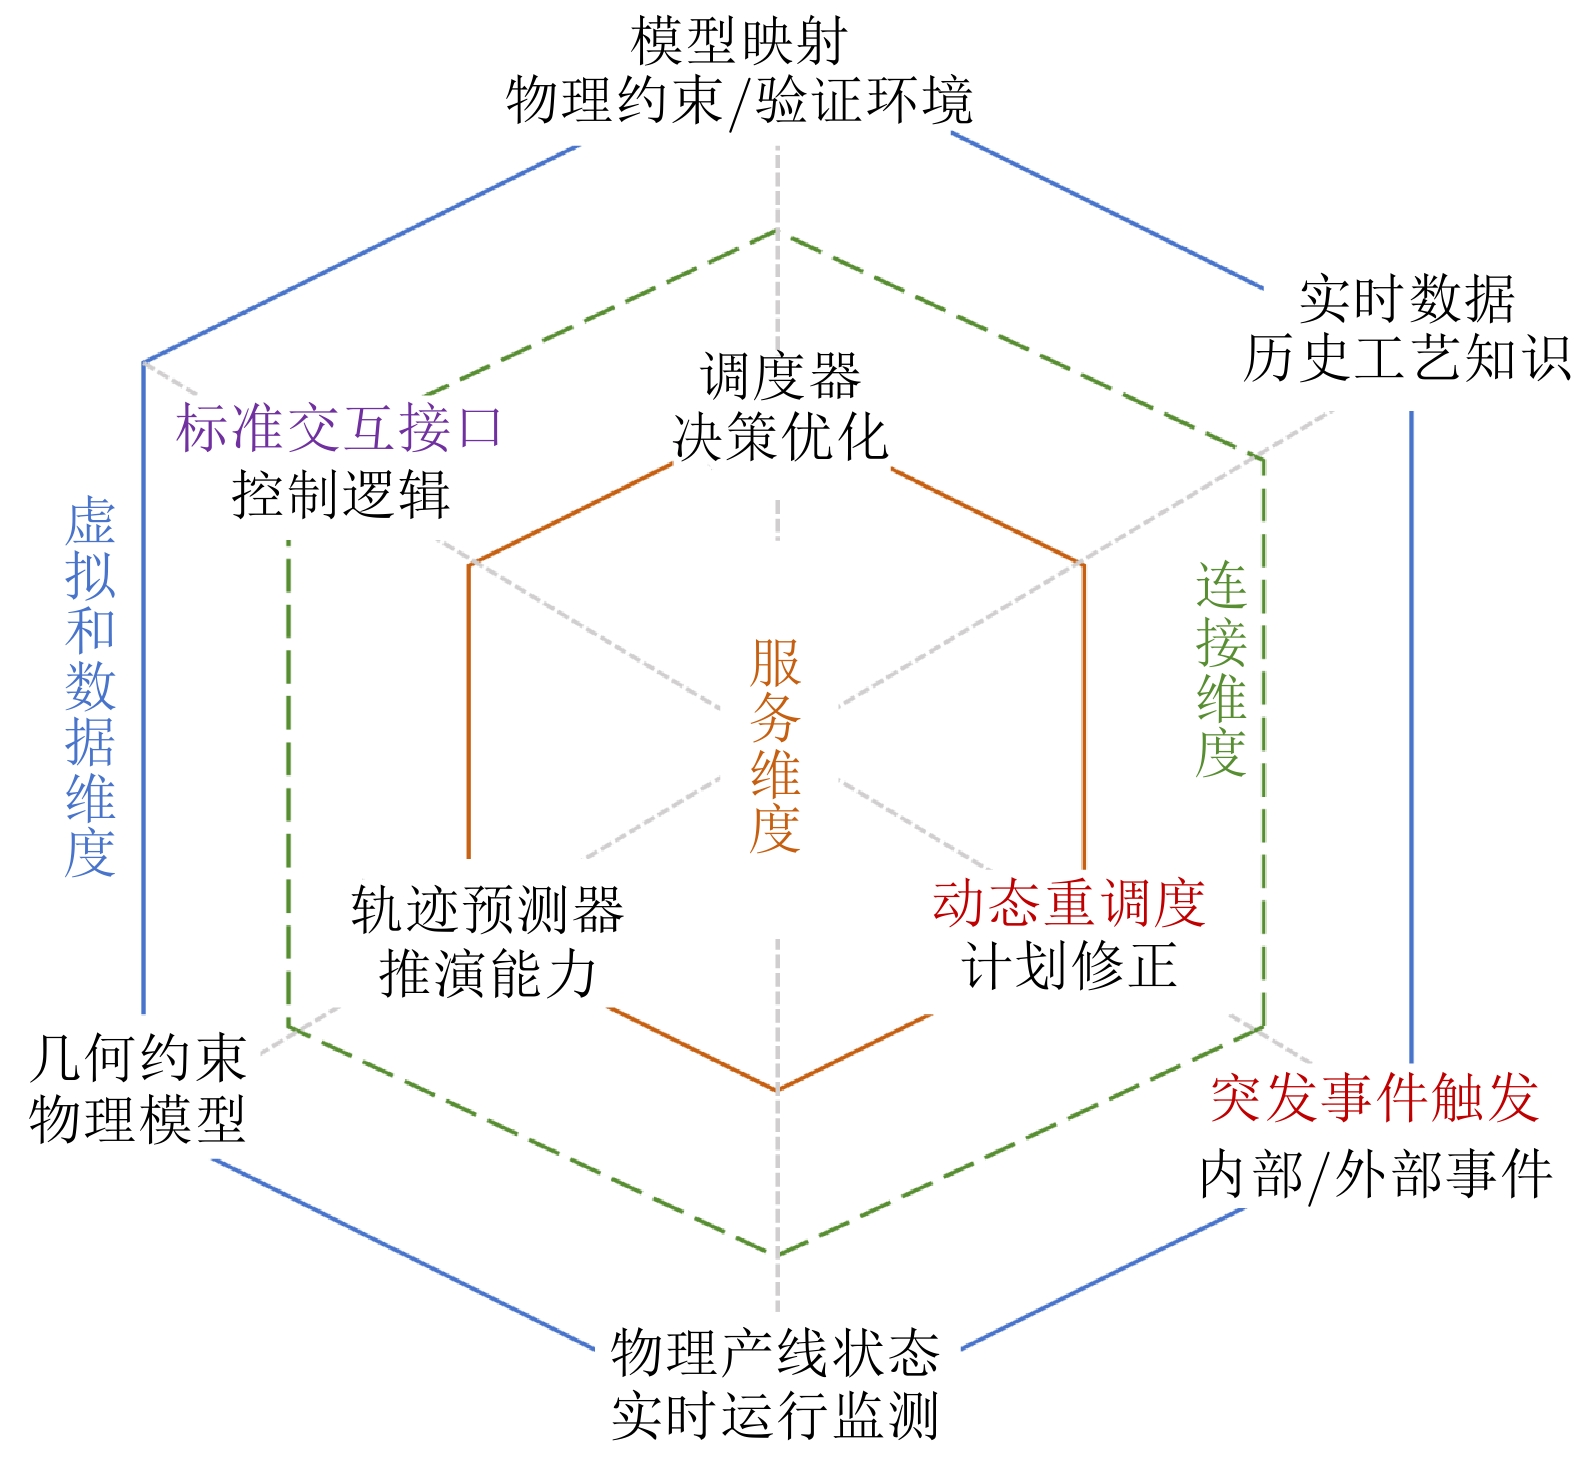
图 2 面向数字孪生的调度-规划方法多维映射拓扑
Fig. 2 Multi-dimensional mapping topology of scheduling and planning methods for digital twins
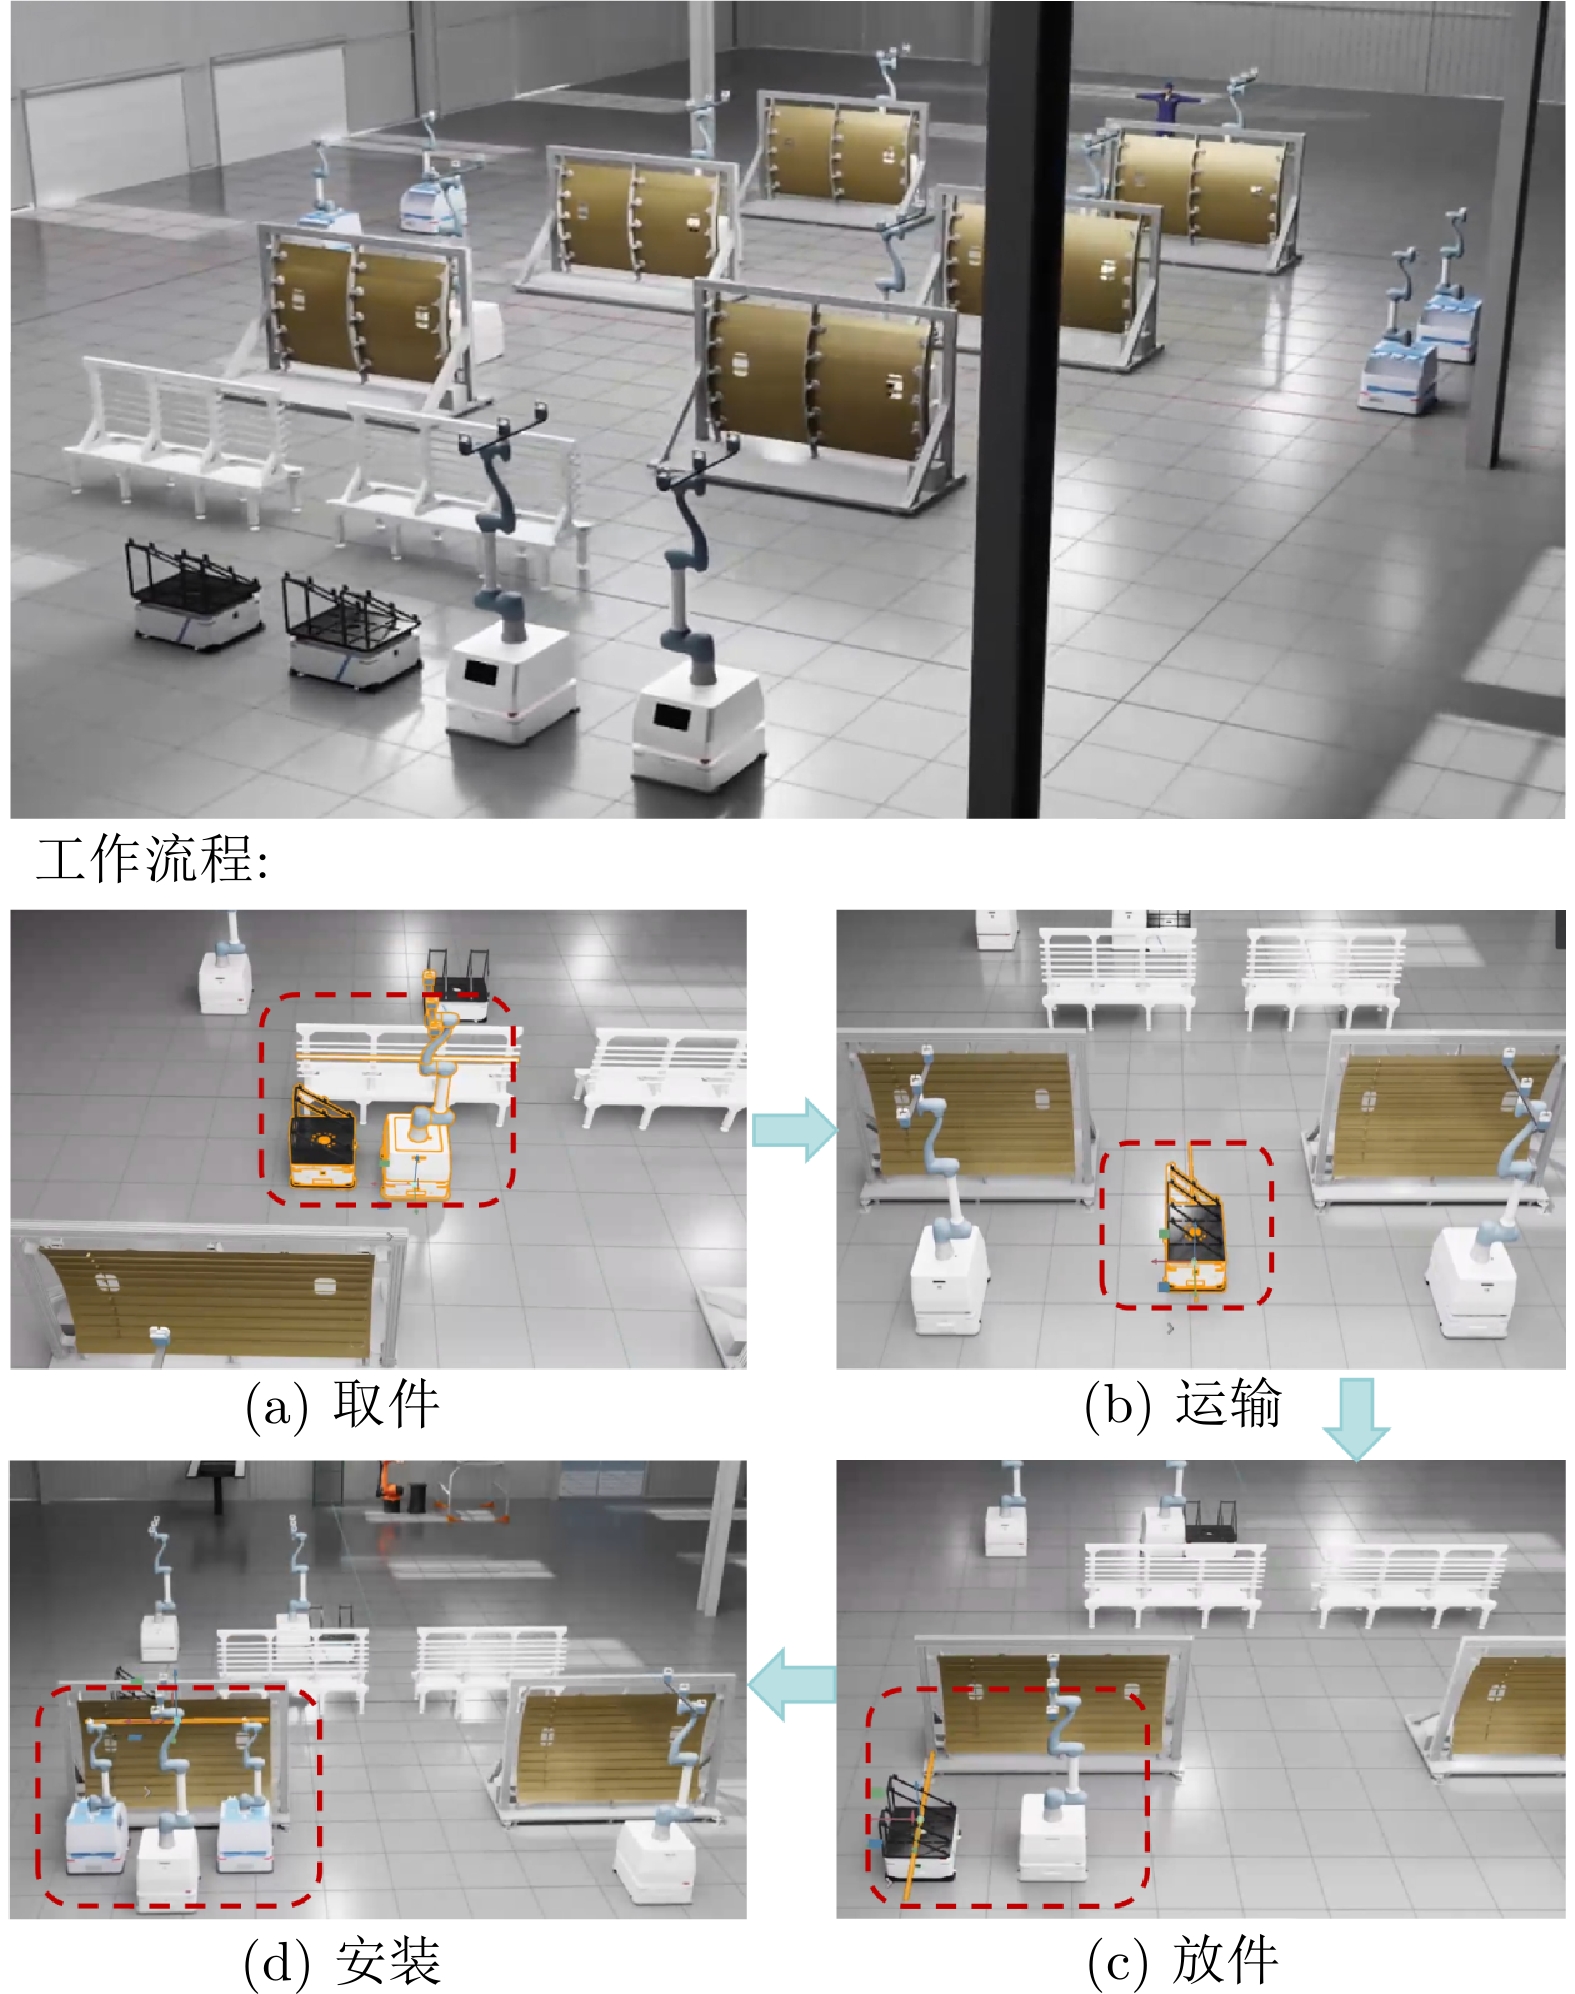
图 3 飞机装配单元物理布局与机器人系统示意图及典型工艺流程
Fig. 3 Schematic diagram of the physical layout, robotic system, and typical process flow of an aircraft assembly unit
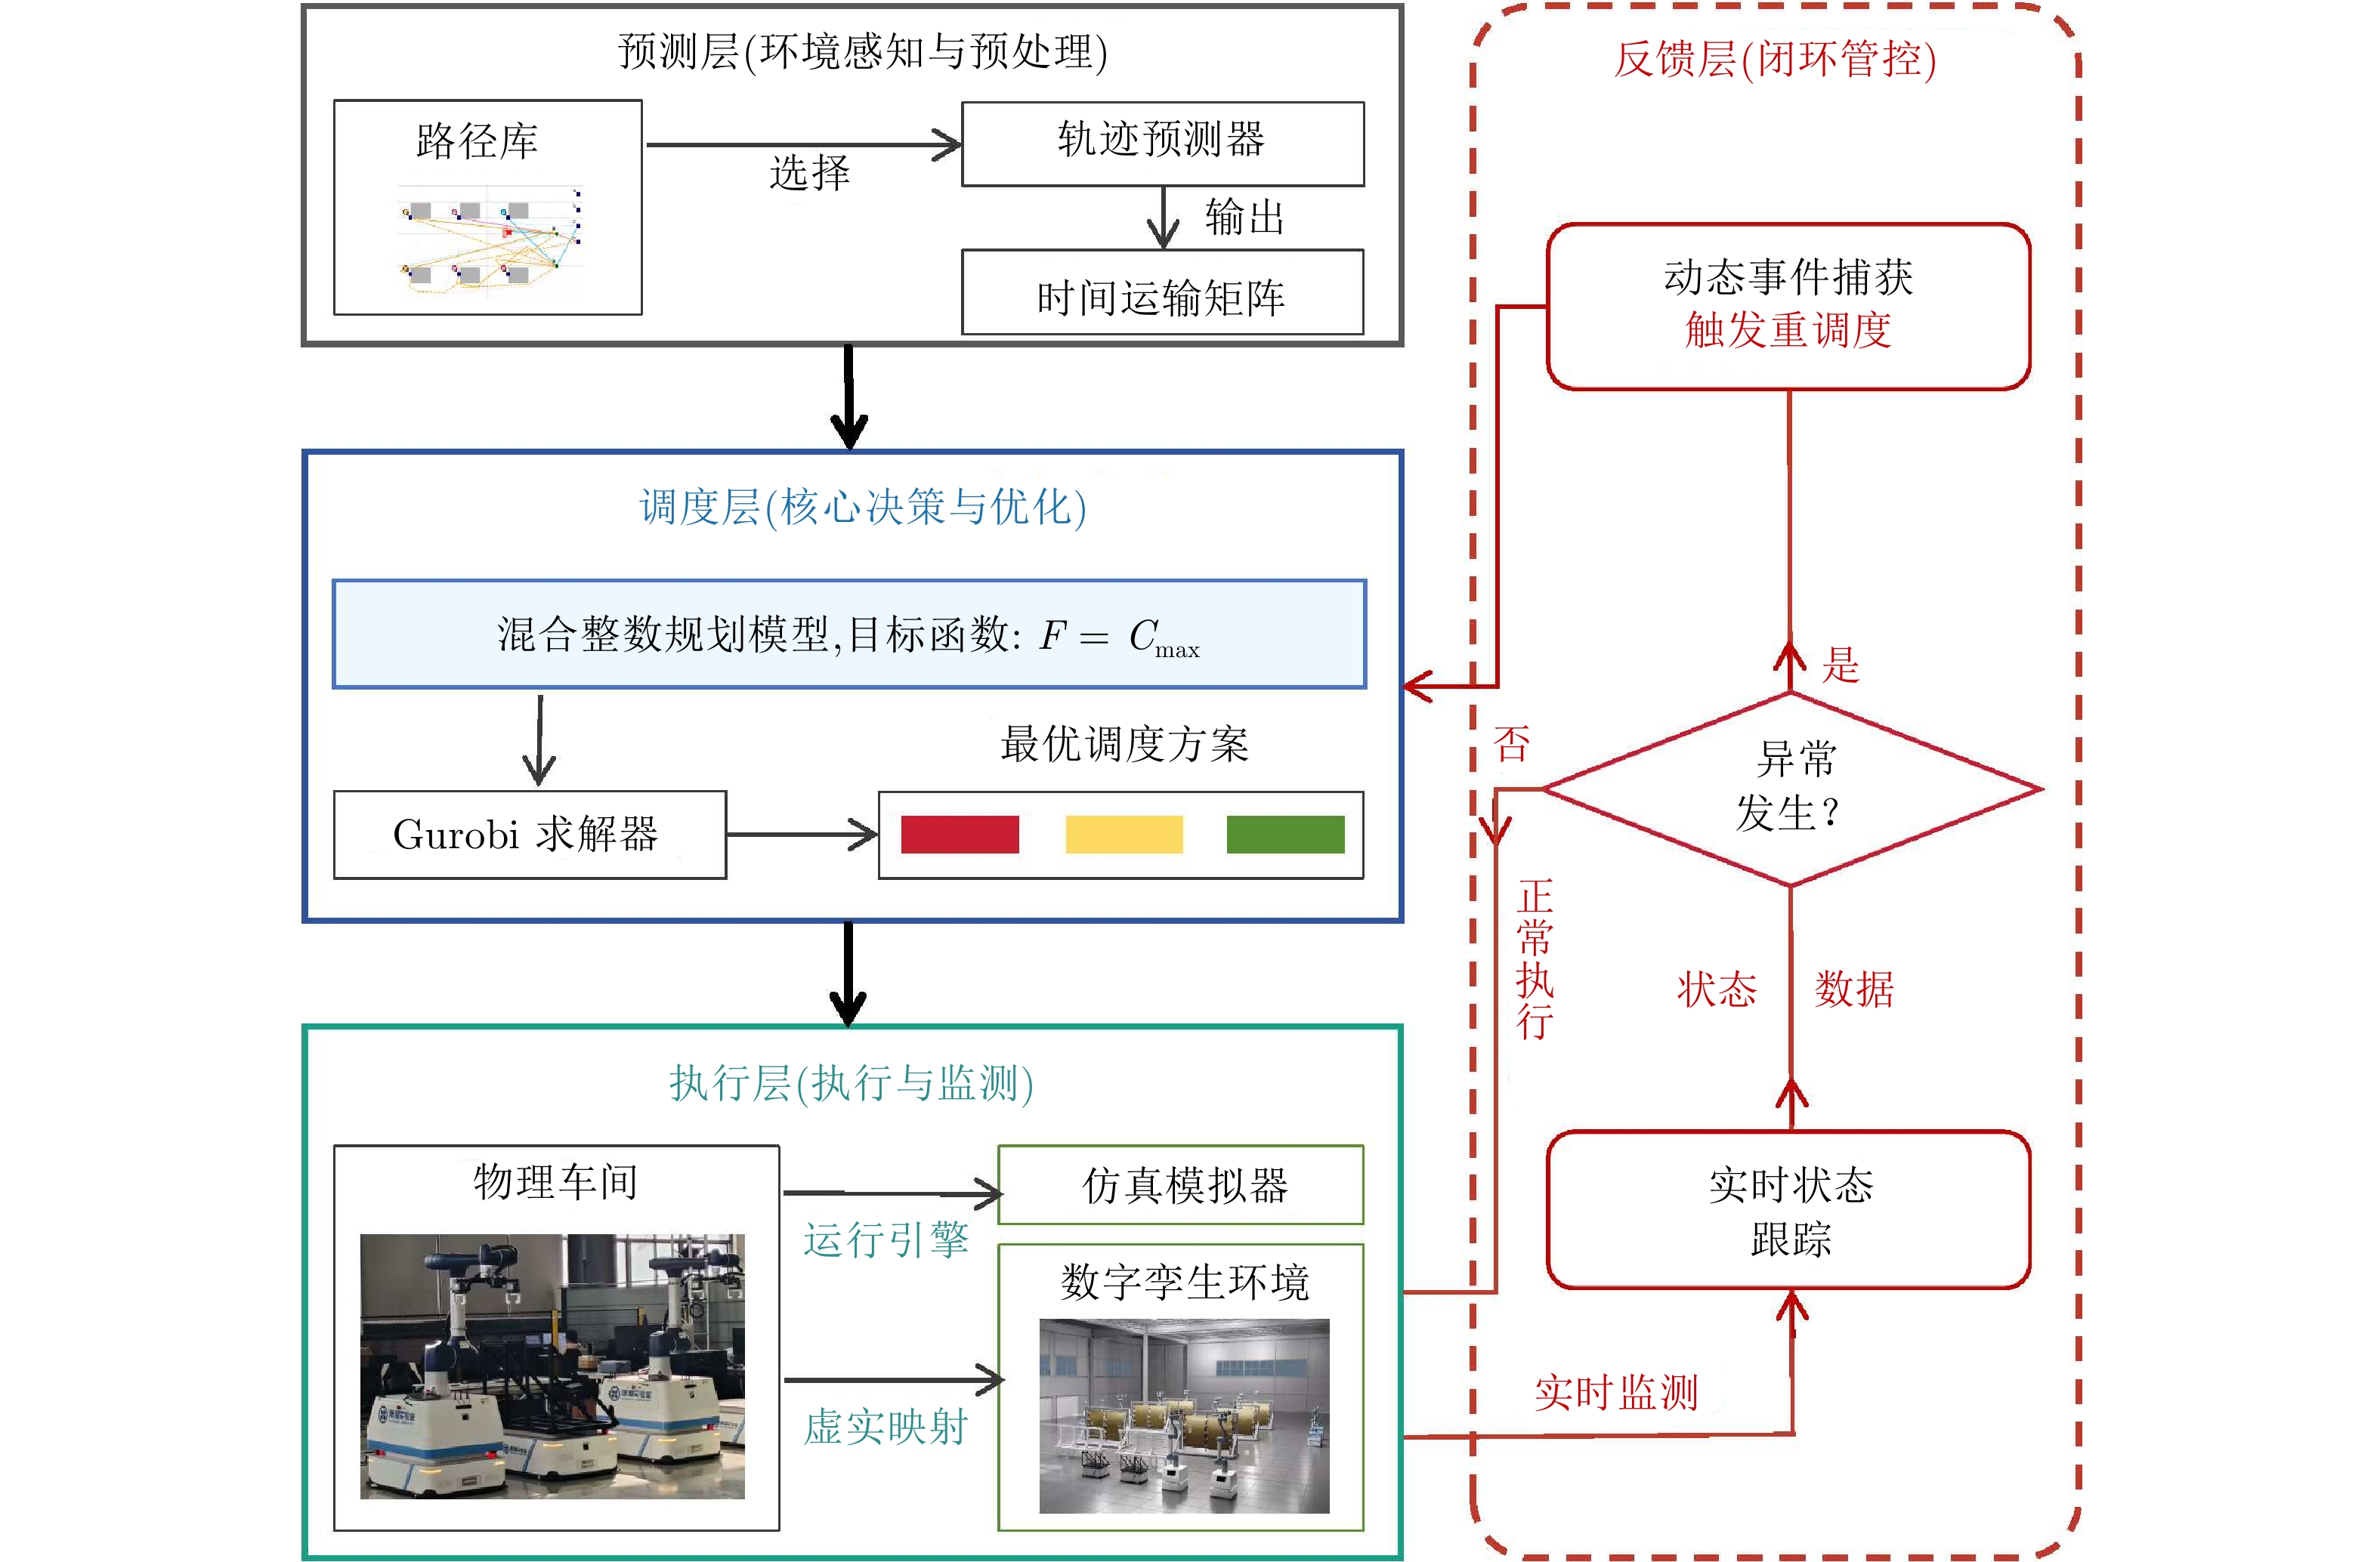
图 4 集群机器人协同调度-规划管控方法
Fig. 4 Collaborative scheduling and planning control method for clustered robots
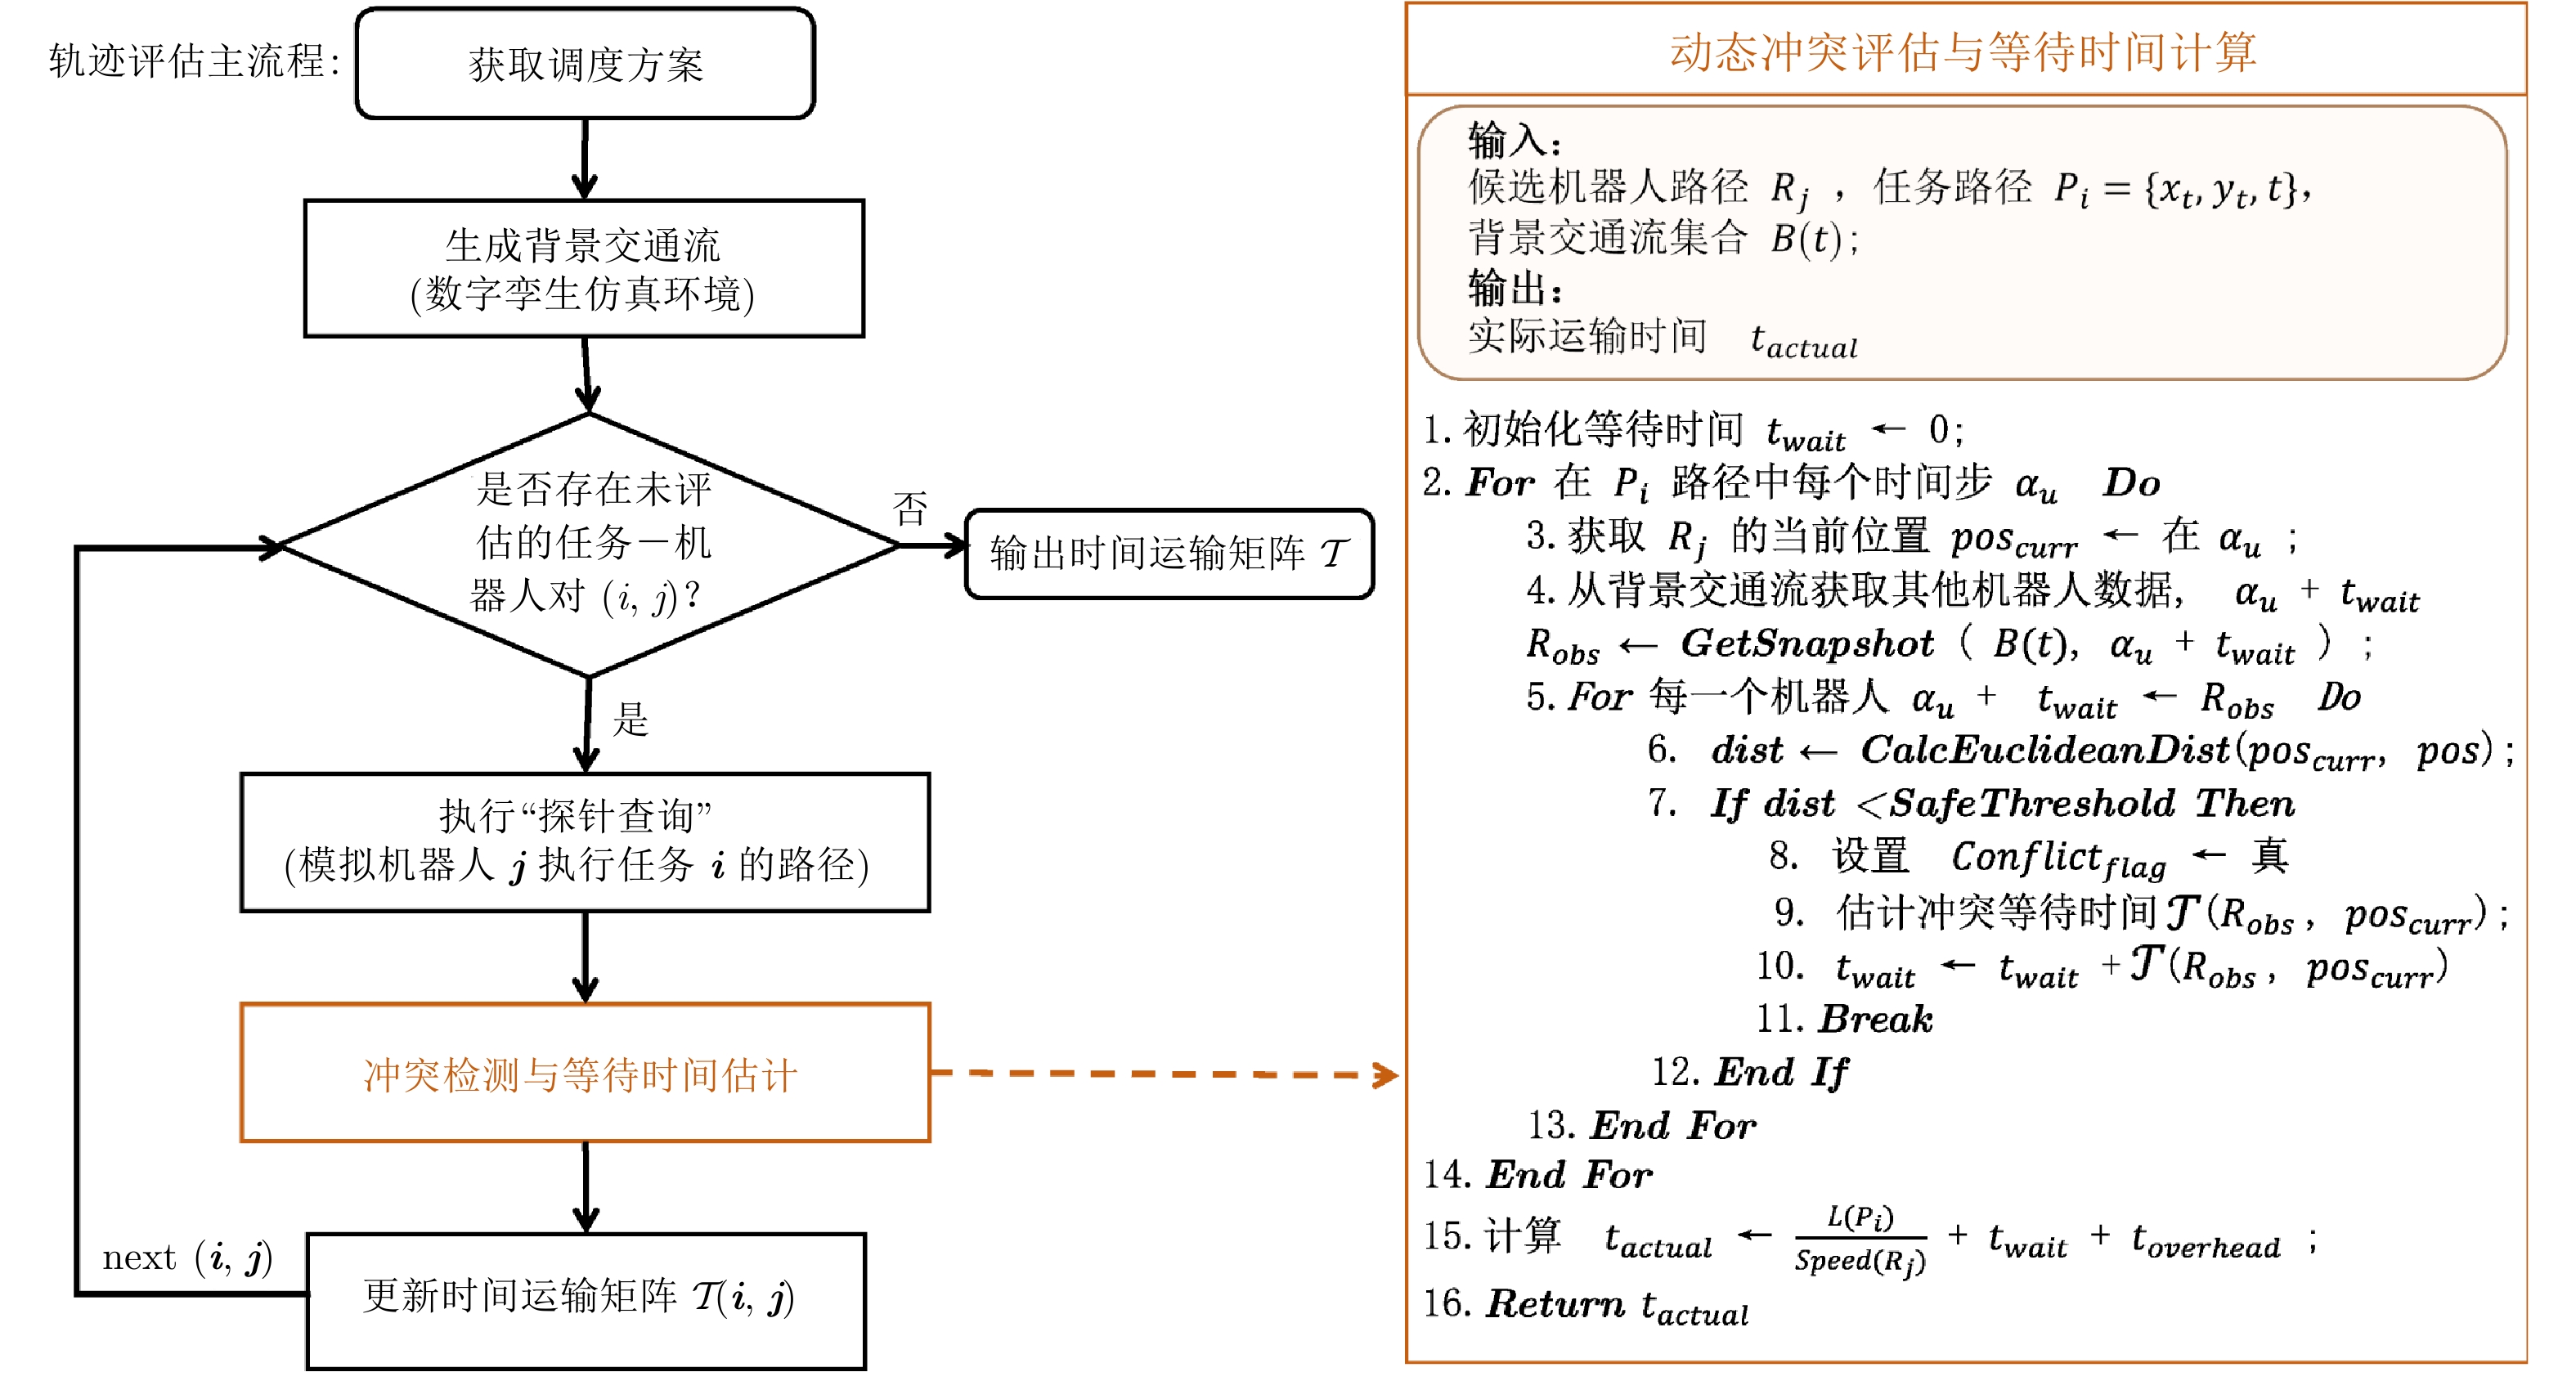
图 5 轨迹预测器流程及冲突检测算法
注: $ {next}(i,\;j) $为循环控制语句, 表示返回并评估下一个未评估的任务−机器人对$ (i,\;j) $; $ \alpha_u $为路径上第$ u $个时间步; $ {pos}_{{curr}} $为候选机器人在该时间步的位置; $ {GetSnapshot} $为从背景交通流快照中获取其他机器人状态的函数; $ R_{{obs}} $为其他机器人在当前时刻的状态集合; $ {pos} $为其他机器人在该时刻的位置; $ {dist} $为候选机器人与其他机器人之间的欧氏距离; $ {CalcEuclidDist} $为欧氏距离计算函数; $ {SafeThreshold} $为机器人间安全距离阈值; $ {Conflict}_{{\rm{flag}}} $为冲突触发标志; $ L_{(P_i)} $为任务路径长度; $ t_{{overhead}} $为任务固定开销时间.
Fig. 5 Trajectory predictor process and conflict detection algorithm
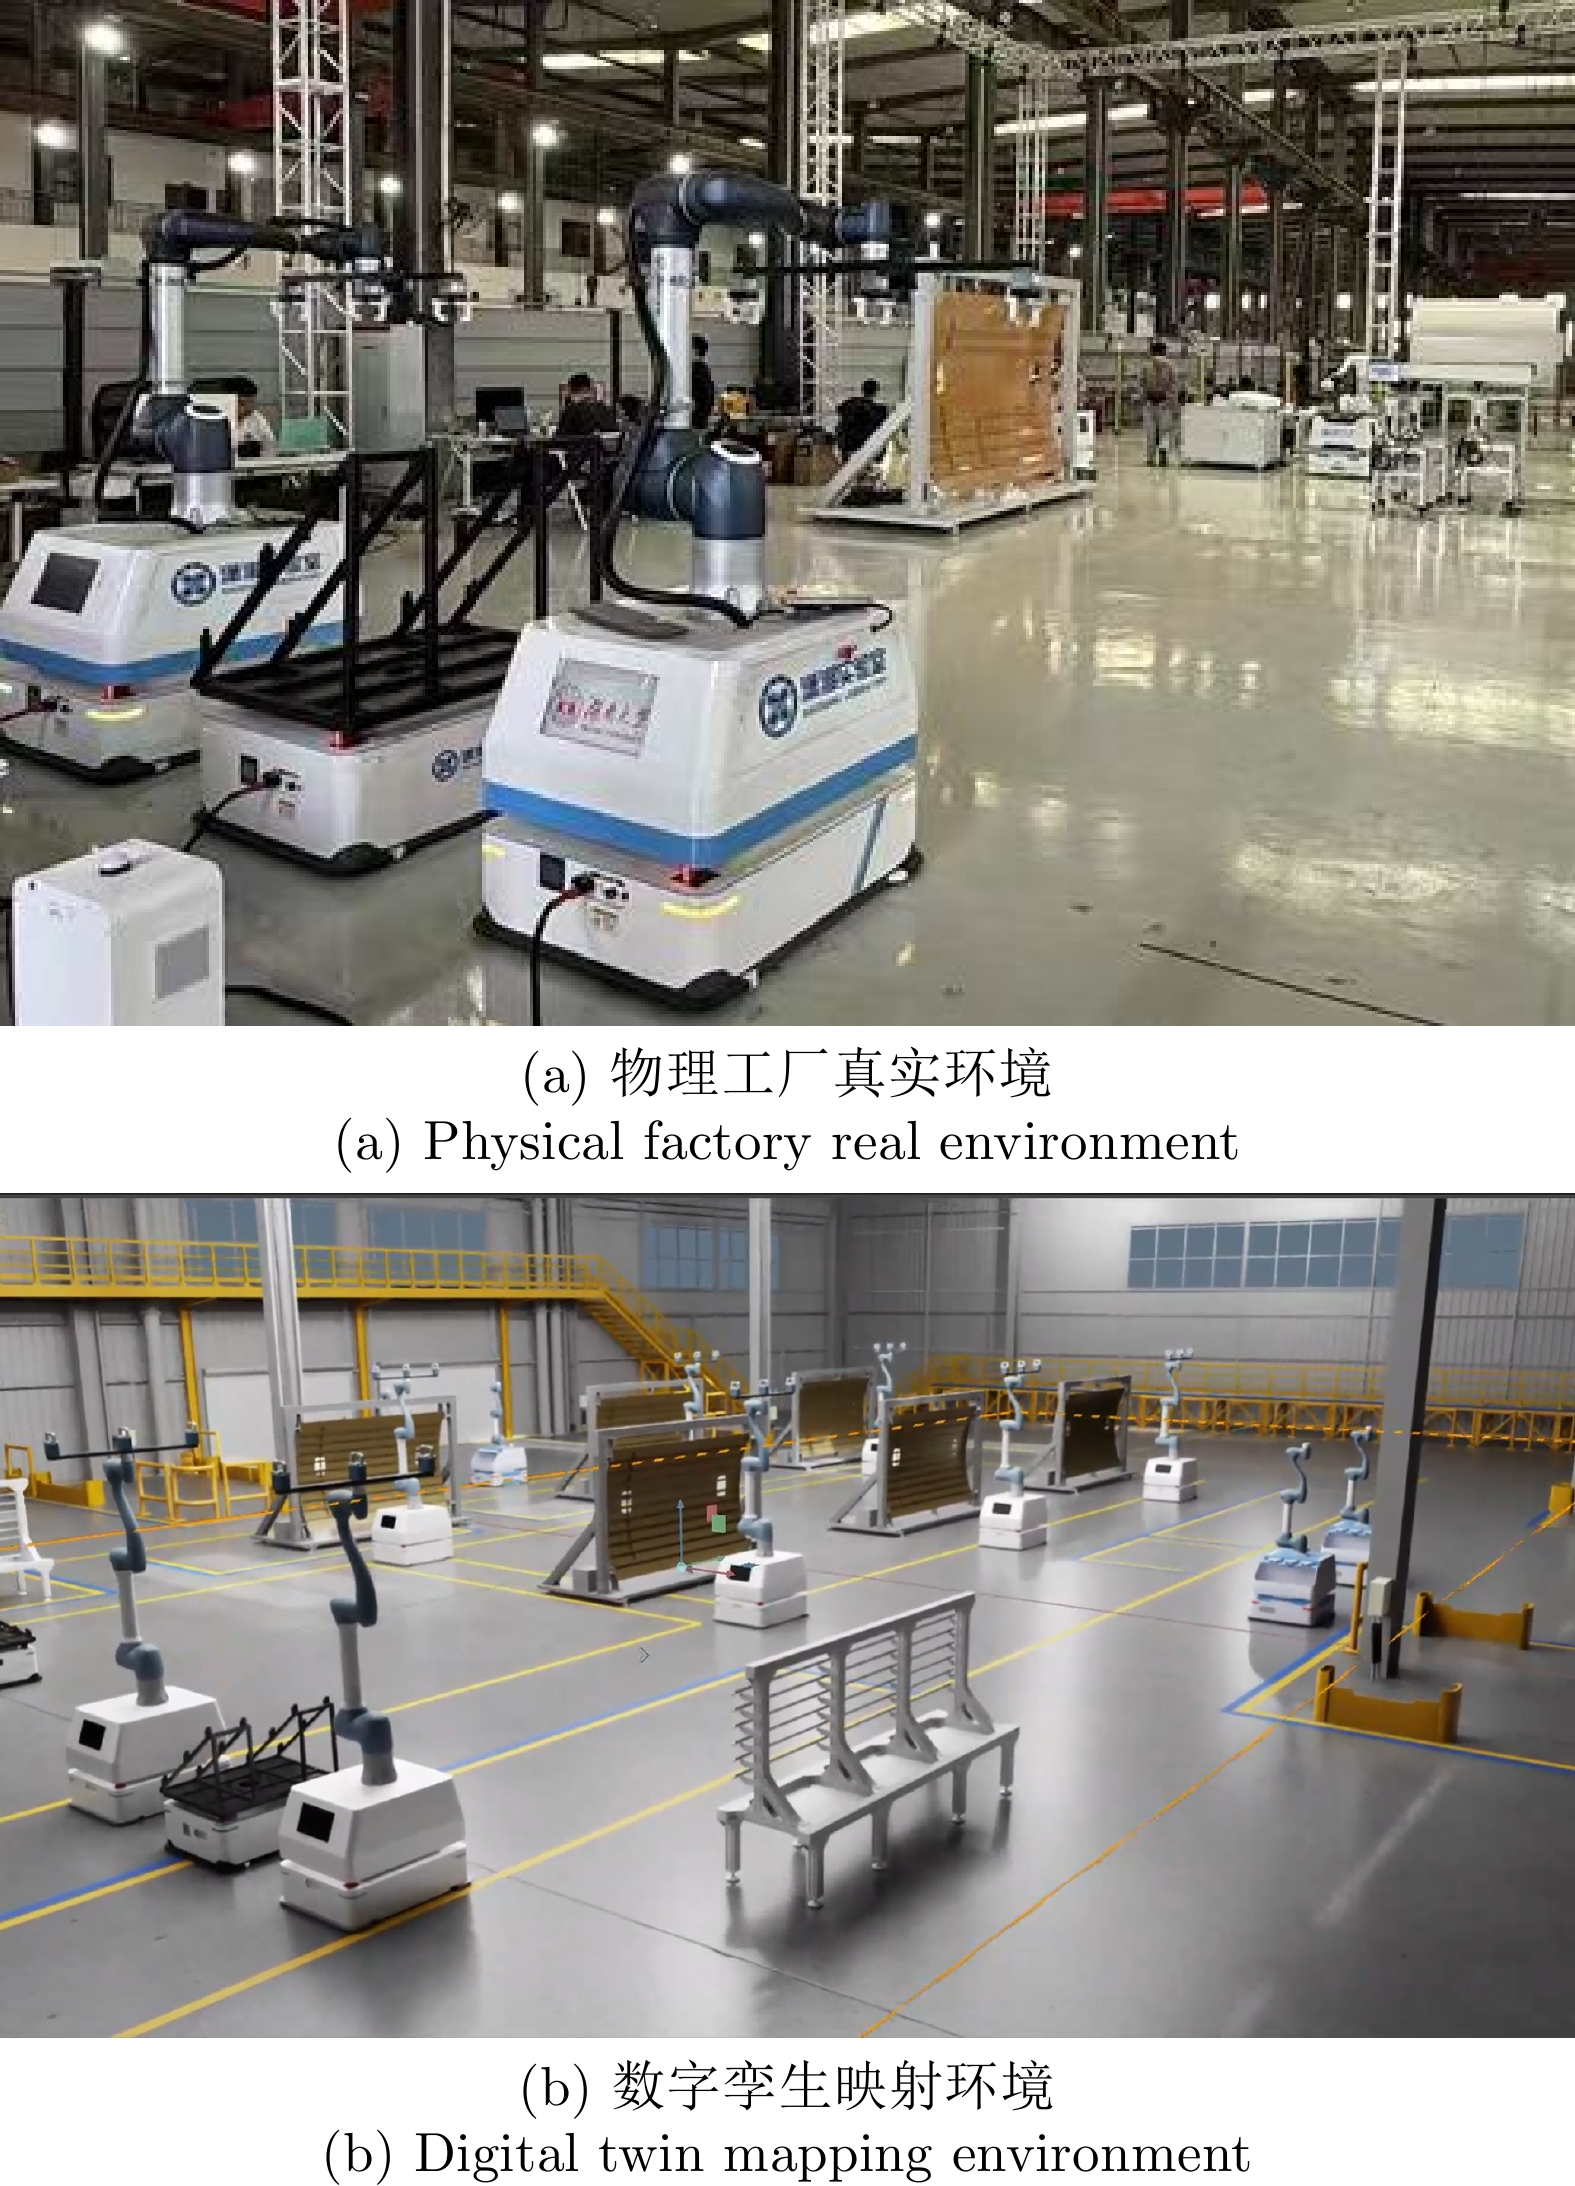
图 6 物理工厂与数字孪生实验场景映射示意图
Fig. 6 Schematic diagram of the mapping between physical factory and digital twin experimental scenarios
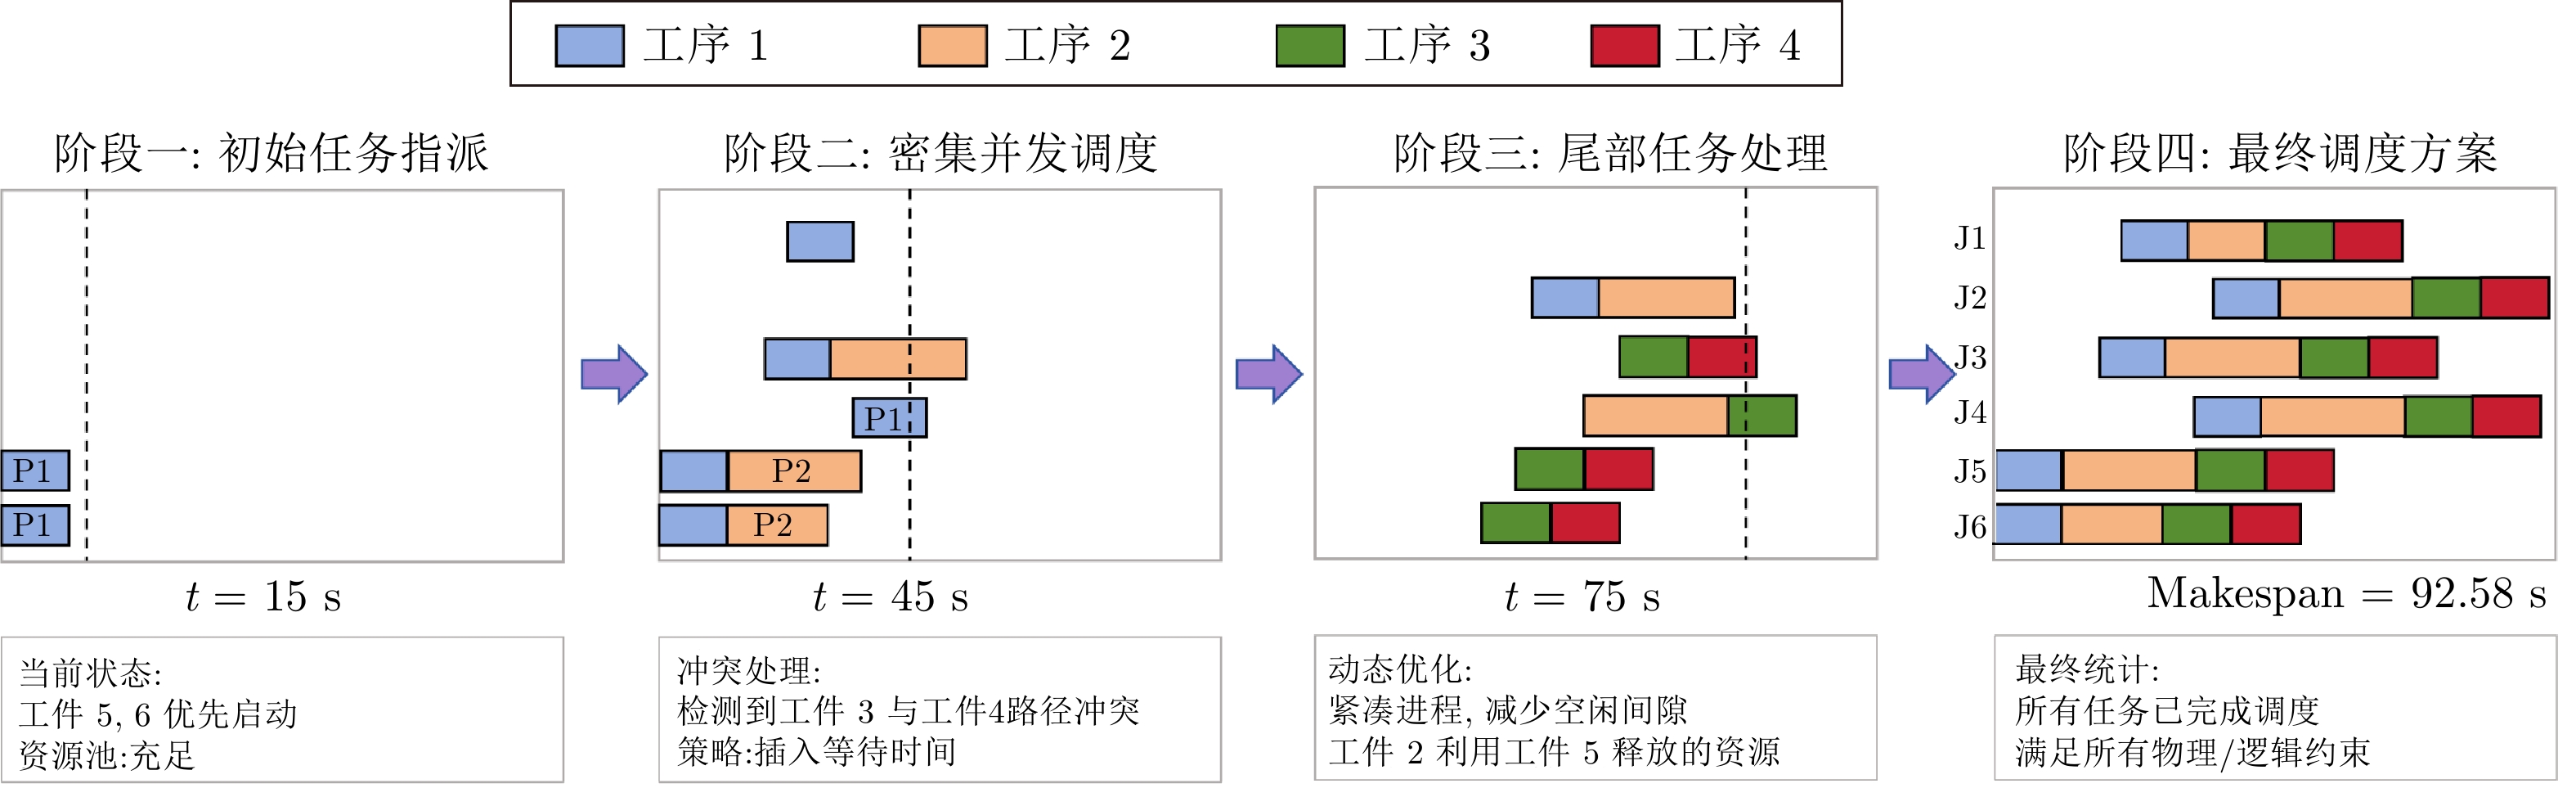
图 7 本文方法调度方案演进过程
Fig. 7 Evolution process of the method scheduling scheme in this paper
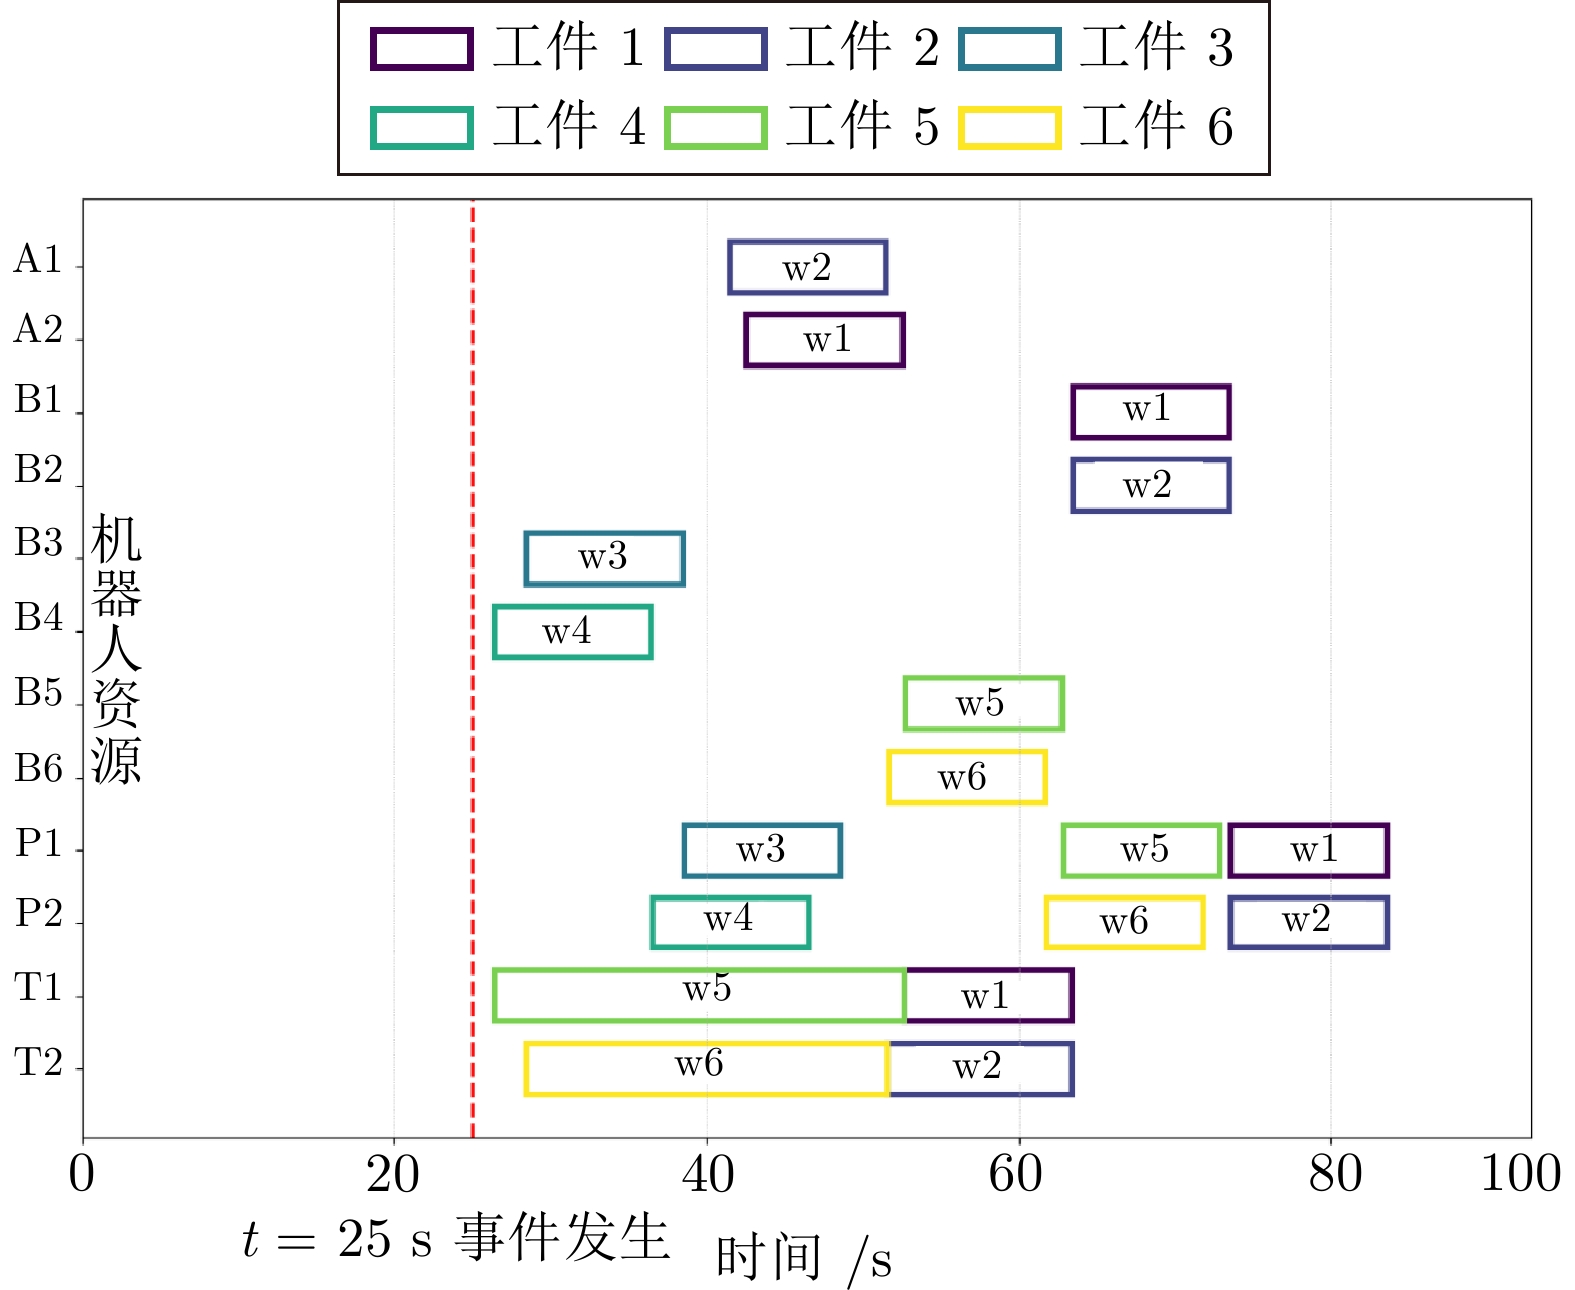
图 8 本文方法延迟事件按机器人资源调度方案
Fig. 8 Delayed event scheduling scheme by robot resource of the proposed method.
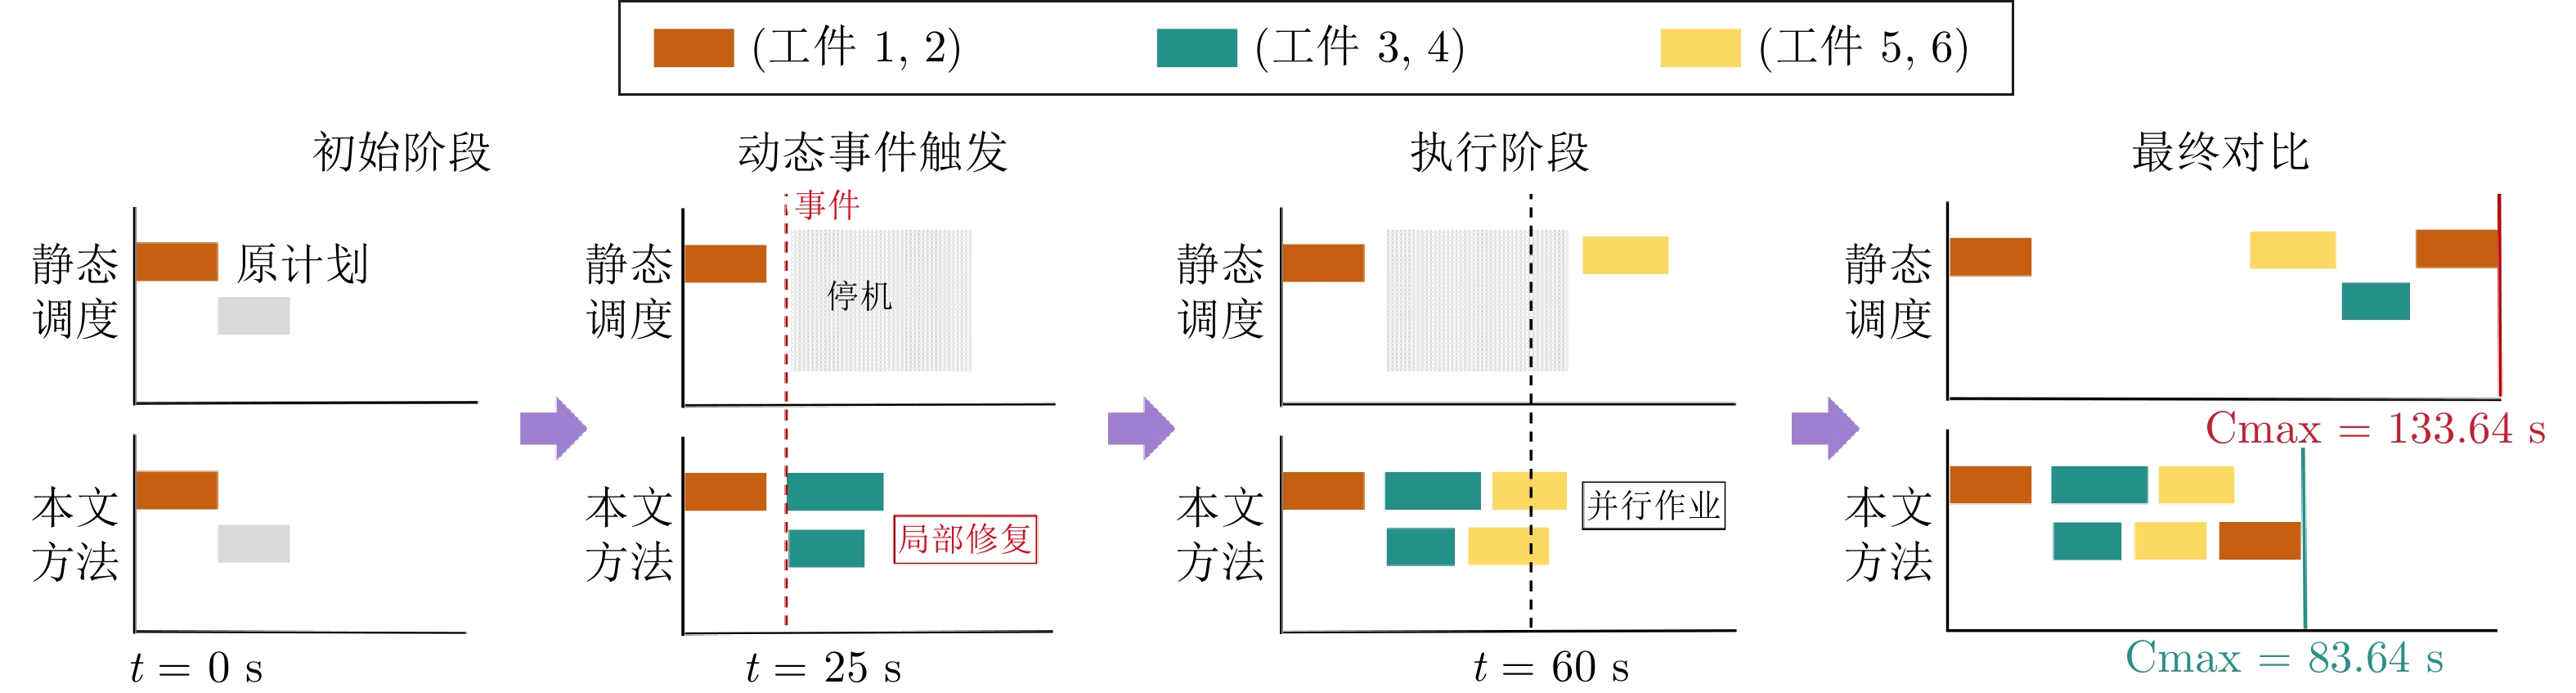
图 9 延迟事件调度方案演进对比
Fig. 9 Comparison of the evolution of delayed event scheduling schemes
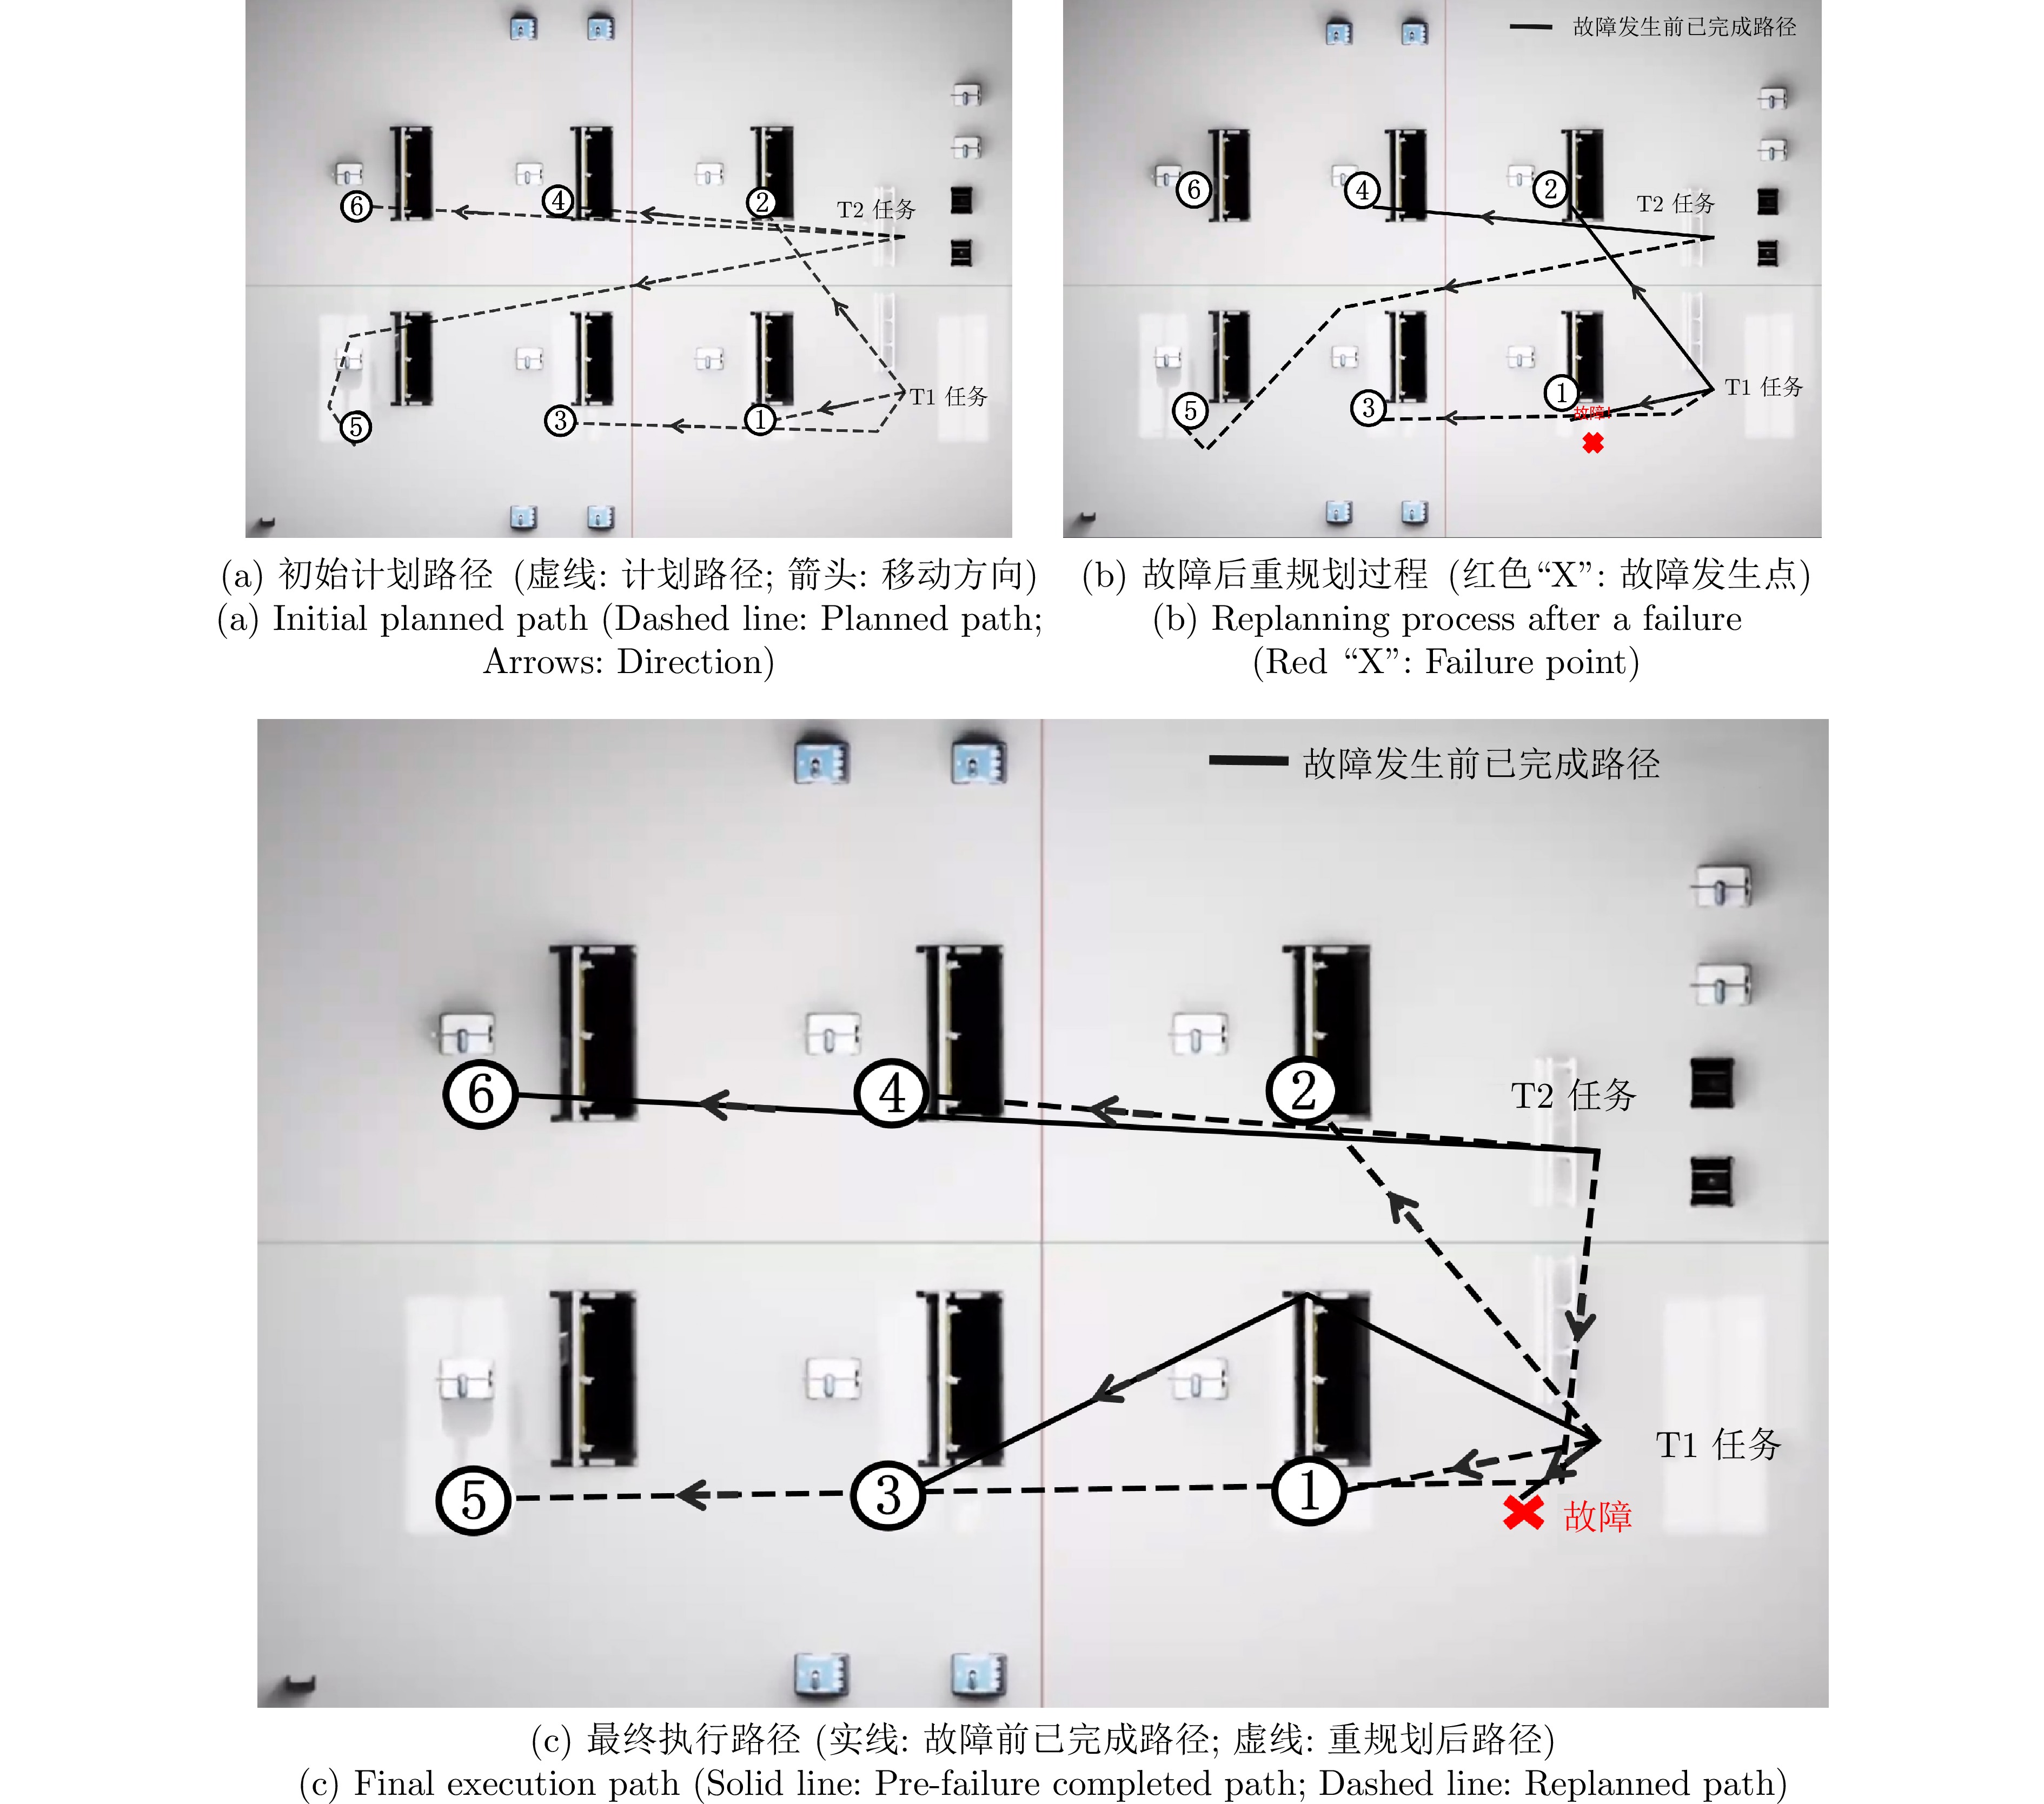
图 10 数字孪生环境中的路径动态重规划过程
Fig. 10 The process of dynamic path replanning in digital twin environments
表 1 不同方法的调度性能对比
Table 1 Performance comparison of different scheduling methods
方法 调度预计
$ C_{\max} $ (s)调度实际
$ C_{\max} $ (s)执行差值
(s)预测误差率
(%)欧氏距离 74.87 104.87 +30 40.07 RRT
静态调度89.54 149.54 +60 67.01 本文方法 89.54 89.54 0 0  下载: 导出CSV
表 2 不同规模下调度方案的预测完工时间与实际完工时间的对比
Table 2 Comparison of predicted and actual completion times for scheduling plans at different scales
场景 方法 调度预计
$ C_{\max} $ (s)调度实际
$ C_{\max} $ (s)执行偏差
(%)小规模 RRT静态调度 81.84 107.68 31.58 本文方法 81.84 82.71 1.06 中规模 RRT静态调度 85.00 181.90 113.99 本文方法 83.08 84.47 1.67 大规模 RRT静态调度 90.61 313.15 245.60 本文方法 87.39 88.92 1.75 注: 执行偏差= $ \dfrac{\left|{{调度实际}}\,\;C_{\max} - {{调度预计}}\,\;C_{\max}\right|}{{{调度预计}}\,\;C_{\max}} \times 100\% $, 其中“调度预计$ C_{\max} $”为调度算法在规划阶段计算得到的理论完工时间, “调度实际$ C_{\max} $”为考虑机器人动态交互和扰动后记录的实际完工时间.
下载: 导出CSV
表 3 动态事件响应结果对比
Table 3 Comparison of dynamic event response outcomes
事件类型 本文方法预计
$ C_{\max} $ (s)RRT静态调度
预计$ C_{\max} $ (s)指标提升
(%)本文方法
重调度耗时(s)紧急任务插入 108.86 139.54 22.0 0.1151 机器人故障 131.45 执行失败 / 0.0295 主要任务延迟 89.54 139.54 35.8 0.0395
下载: 导出CSV
-
[1] Zahid A, Leclaire P, Affonso R C, Hammadi L, Elballouti A. Towards Smart Scheduling in the Era of Industry 4.0 for Sustainable Manufacturing. In: Proceedings of 2024 IEEE 15th International Colloquium on Logistics and Supply Chain Management (LOGISTIQUA). Sousse, Tunisia: IEEE, 2024. 1-7 [2] Pupa A, Comari S, Arrfou M, Andreoni G, Carapia A, Carricato M, et al. Enhancing Performance in Human-Robot Collaboration: A Modular Architecture for Task Scheduling and Safe Trajectory Planning. IEEE Transactions on Automation Science and Engineering, 2025, 22: 17535−17551 doi: 10.1109/TASE.2025.3574627 [3] 冯运, 童翊轩, 王耀南, 唐永鹏, 吴昊天, 谭浩然, 等. 重大装备集群机器人协同制造数字孪生技术综述. 自动化学报, 2025, 51(7): 1463−1479 doi: 10.16383/j.aas.c240707FENG Yun, TONG Yi-Xuan, WANG Yao-Nan, TANG Yong-Peng, WU Hao-Tian, TAN Hao-Ran, et al. Survey on digital twin technology for cluster-robot cooperative manufacturing of major equipment. Acta Automatica Sinica, 2025, 51(7): 1463−1479 doi: 10.16383/j.aas.c240707 [4] 张振国, 毛建旭, 谭浩然, 王耀南, 张雪波, 江一鸣. 重大装备制造多机器人任务分配与运动规划技术研究综述. 自动化学报, 2024, 50(1): 21−41 doi: 10.16383/j.aas.c220957ZHANG Zhen-Guo, MAO Jian-Xu, TAN Hao-Ran, WANG Yao-Nan, ZHANG Xue-Bo, JIANG Yi-Ming. Survey on multi-robot task allocation and motion planning for major equipment manufacturing. Acta Automatica Sinica, 2024, 50(1): 21−41 doi: 10.16383/j.aas.c220957 [5] 王耀南, 江一鸣, 姜娇, 张辉, 谭浩然, 彭伟星, 等. 机器人感知与控制关键技术及其智能制造应用. 自动化学报, 2023, 49(3): 494−513 doi: 10.16383/j.aas.c220995WANG Yao-Nan, JIANG Yi-Ming, JIANG Jiao, ZHANG Hui, TAN Hao-Ran, PENG Wei-Xing, et al. Key technologies of robot perception and control and their applications in intelligent manufacturing. Acta Automatica Sinica, 2023, 49(3): 494−513 doi: 10.16383/j.aas.c220995 [6] Xu K, Xu B, Huang D, Wang C. A Rule and Network Dual-Driven Dynamic Scheduling Approach for Complex Flexible Manufacturing Job Shop. In: Proceedings of 2024 7th International Conference on Robotics, Control and Automation Engineering (RCAE). Wuhu, China: IEEE, 2024. 469−473 [7] Cao B, Liu Z, Han X, Zhou S, Zhang H, Han L, et al. Foresee and Act Ahead: Task Prediction and Pre-Scheduling Enabled Efficient Robotic Warehousing. In: Proceedings of 2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, GA, USA: IEEE, 2025. 2079−2085 [8] Johannsmeier L, Haddadin S. A Hierarchical Human-Robot Interaction-Planning Framework for Task Allocation in Collaborative Industrial Assembly Processes. IEEE Robotics and Automation Letters, 2017, 2(1): 41−48 doi: 10.1109/LRA.2016.2535907 [9] Ning Z, Sun S, Zhou M, Hu X, Wang X, Guo L, et al. Online Scheduling and Route Planning for Shared Buses in Urban Traffic Networks. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(4): 3430−3444 doi: 10.1109/TITS.2020.3036396 [10] Sun Y, Zhao N, Tang L, Luo L. Breaking the Limit on the Number of Robots Through the Conflict-Free Scheduling in Robotic Mobile Fulfillment Systems. IEEE Transactions on Automation Science and Engineering, 2025, 22: 7324−7334 doi: 10.1109/TASE.2024.3420107 [11] Zhang C, Wen X, Li C, Zheng W, Yu L, Lu Z. Dynamic Rapid Scheduling Algorithm for Vehicle Time Sensitive Communication Based on CILP and AGA. IEEE Transactions on Vehicular Technology, 2023, 72(11): 15014−15027 doi: 10.1109/tvt.2023.3287645 [12] Zhang C, Yang J, Wang N. Multitree Genetic Programming With Rule Reconstruction for Dynamic Task Scheduling in Integrated Cloud-Edge Satellite-Terrestrial Networks. IEEE Internet of Things Journal, 2025, 12(12): 21429−21442 doi: 10.1109/JIOT.2025.3546867 [13] He Z, Li Z, Giua A. Optimization of Deterministic Timed Weighted Marked Graphs. IEEE Transactions on Automation Science and Engineering, 2017, 14(2): 1084−1095 doi: 10.1109/TASE.2015.2490538 [14] Carlucci D, Renna P, Materi S. A Job-Shop Scheduling Decision-Making Model for Sustainable Production Planning With Power Constraint. IEEE Transactions on Engineering Management, 2023, 70(5): 1923−1932 doi: 10.1109/TEM.2021.3103108 [15] Huang C, Liang J, Chang Y, Xu J, Li J. Automated Hybrid Reward Scheduling Via Large Language Models for Robotic Skill Learning. In: Proceedings of 2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, GA, USA: IEEE, 2025. 8242−8248 [16] Cella C, Robin M B, Faroni M, Zanchettin A M, Rocco P. Digital Model-Driven Genetic Algorithm for Optimizing Layout and Task Allocation in Human-Robot Collaborative Assemblies. In: Proceedings of 2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, GA, USA: IEEE, 2025. 3103−3109 [17] Li X, Gao J. Research on Deadlock-Free Scheduling of Flexible Manufacturing Systems Based on Reinforcement Learning. In: Proceedings of 2024 4th International Symposium on Artificial Intelligence and Intelligent Manufacturing (AⅡM). Chengdu, China: IEEE, 2024. 64−73 [18] Nouiri M, Bekrar A, Jemai A, Trentesaux D, Ammari A C, Niar S. Two stage particle swarm optimization to solve the flexible job shop predictive scheduling problem considering possible machine breakdowns. Computers & Industrial Engineering, 2017, 112: 595−606 doi: 10.1016/j.cie.2017.03.006 [19] Jensen J H, Bak Sørensen K P, Sejersen J L F, Sarabakha A. Multi-Agent Path Planning in Complex Environments using Gaussian Belief Propagation with Global Path Finding. In: Proceedings of 2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, GA, USA: IEEE, 2025. 4359−4365 [20] Florencia J, Moyaux T, Trilling L, Bouleux G, Cheutet V. Toward Improving Dynamic Resource Scheduling in the Context of Digital Twin of Emergency Department. IEEE Transactions on Automation Science and Engineering, 2025, 22: 7255−7267 doi: 10.1109/TASE.2024.3463489 [21] Kinugawa J, Kanazawa A, Arai S, Kosuge K. Adaptive Task Scheduling for an Assembly Task Coworker Robot Based on Incremental Learning of Human's Motion Patterns. IEEE Robotics and Automation Letters, 2017, 2(2): 856−863 doi: 10.1109/LRA.2017.2655565 [22] Huang C M, Mutlu B. Anticipatory robot control for efficient human-robot collaboration. In: Proceedings of 2016 11th ACM/IEEE International Conference on Human-Robot Interaction (HRI). Christchurch, New Zealand: IEEE, 2016. 83−90 [23] Li M, Qu T, Liu B, Luo Q, Yan M, Li M, et al. Out-of-Order Architecture for Real-Time Data-Driven Resilient Planning and Scheduling of Cyber-Physical Manufacturing Systems. IEEE Transactions on Automation Science and Engineering, 2026, 23: 2983−2994 doi: 10.1109/TASE.2025.3563084 [24] Yelisetty S R, Kuriakose A. Autonomous Air Traffic Management Scheduling System. In: Proceedings of 2024 IEEE International Conference on Electronics, Computing and Communication Technologies (CONECCT). Bangalore, India: IEEE, 2024. 1−6 [25] Tao F, Qi Q L. Make more digital twins. Nature, 2019, 573(7775): 490−491 doi: 10.1038/d41586-019-02849-1 [26] 陶飞, 刘蔚然, 张萌, 胡天亮, 戚庆林, 张贺, 等. 数字孪生五维模型及十大领域应用. 计算机集成制造系统, 2019, 25(1): 1−18 doi: 10.13196/j.cims.2019.01.001TAO Fei, LIU Wei-Ran, ZHANG Meng, HU Tian-Liang, QI Qing-Lin, ZHANG He, et al. Five-dimension digital twin model and its ten applications. Computer Integrated Manufacturing Systems, 2019, 25(1): 1−18 doi: 10.13196/j.cims.2019.01.001 [27] ZHANG Meng, TAO Fei, Nee A Y C. Digital Twin Enhanced Dynamic Job-Shop Scheduling. Journal of Manufacturing Systems, 2021, 58: 146−156 doi: 10.1016/j.jmsy.2020.04.008 [28] ZHANG Wen-Quan, PENG Zhao-Xian, ZHAO Fei, FENG Bo, MEI Xue-Song. A novel deep reinforcement learning framework based on digital twins for dynamic job shop scheduling problems. Expert Systems with Applications, 2026, 296: 128708 doi: 10.1016/j.eswa.2025.128708 [29] GUO Ming-Yi, FANG Xi-Feng, WU Qi, ZHANG Sheng-Wen, LI Qun. Joint multi-objective dynamic scheduling of machine tools and vehicles in a workshop based on digital twin. Journal of Manufacturing Systems, 2023, 70: 345−358 doi: 10.1016/j.jmsy.2023.07.011 [30] Lin W D. An Integrated Digital Twin Simulation and Scheduling System under Cyber-physical Digital Twin Environment. In: Proceedings of 2022 IEEE International Conference on Industrial Engineering and Engineering Management (IEEM). Kuala Lumpur, Malaysia: IEEE, 2022. 0231−0235 [31] Gerkey B P, Matarić M J. A Formal Analysis and Taxonomy of Task Allocation in Multi-Robot Systems. The International Journal of Robotics Research, 2004, 23(9): 939−954 doi: 10.1177/0278364904045564 -

 下载:

计量
- 文章访问数: 13
- HTML全文浏览量: 6
- 被引次数: 0
