

-
摘要: 针对具有多个运行点的非线性离散时间多变量强耦合系统, 提出一种最优切换解耦控制方法. 首先, 将非线性系统在多个运行点附近泰勒展开, 得到多个近似线性模型, 通过引入开关函数, 并利用矩阵分解方法建立控制器设计模型; 然后, 基于考虑耦合影响的复合型性能指标, 利用嵌入转换技术、极小值原理及二次规划技术, 推导出最优切换准则函数及最优切换解耦控制器, 并设计鲁棒补偿器以提升控制系统性能; 最后, 进行数值仿真实验, 实验结果验证了所提方法的有效性及优越性.Abstract: An optimal switching decoupling control method is proposed for nonlinear discrete-time multivariable systems with multiple operating points and strong coupling. First, the nonlinear system is approximated by several local linear models obtained via Taylor expansion around multiple operating points. A switching function is introduced, and a controller design model is established using matrix decomposition techniques. Then, based on a composite performance index that takes coupling effects into account, the optimal switching criterion function and the optimal switching decoupled controller are derived using embedding transformation technique, the minimum principle, and quadratic programming technique. A robust compensator is further designed to enhance the performance of the control system. Finally, numerical simulations are conducted, and the results verify the effectiveness and superiority of the proposed method.
-
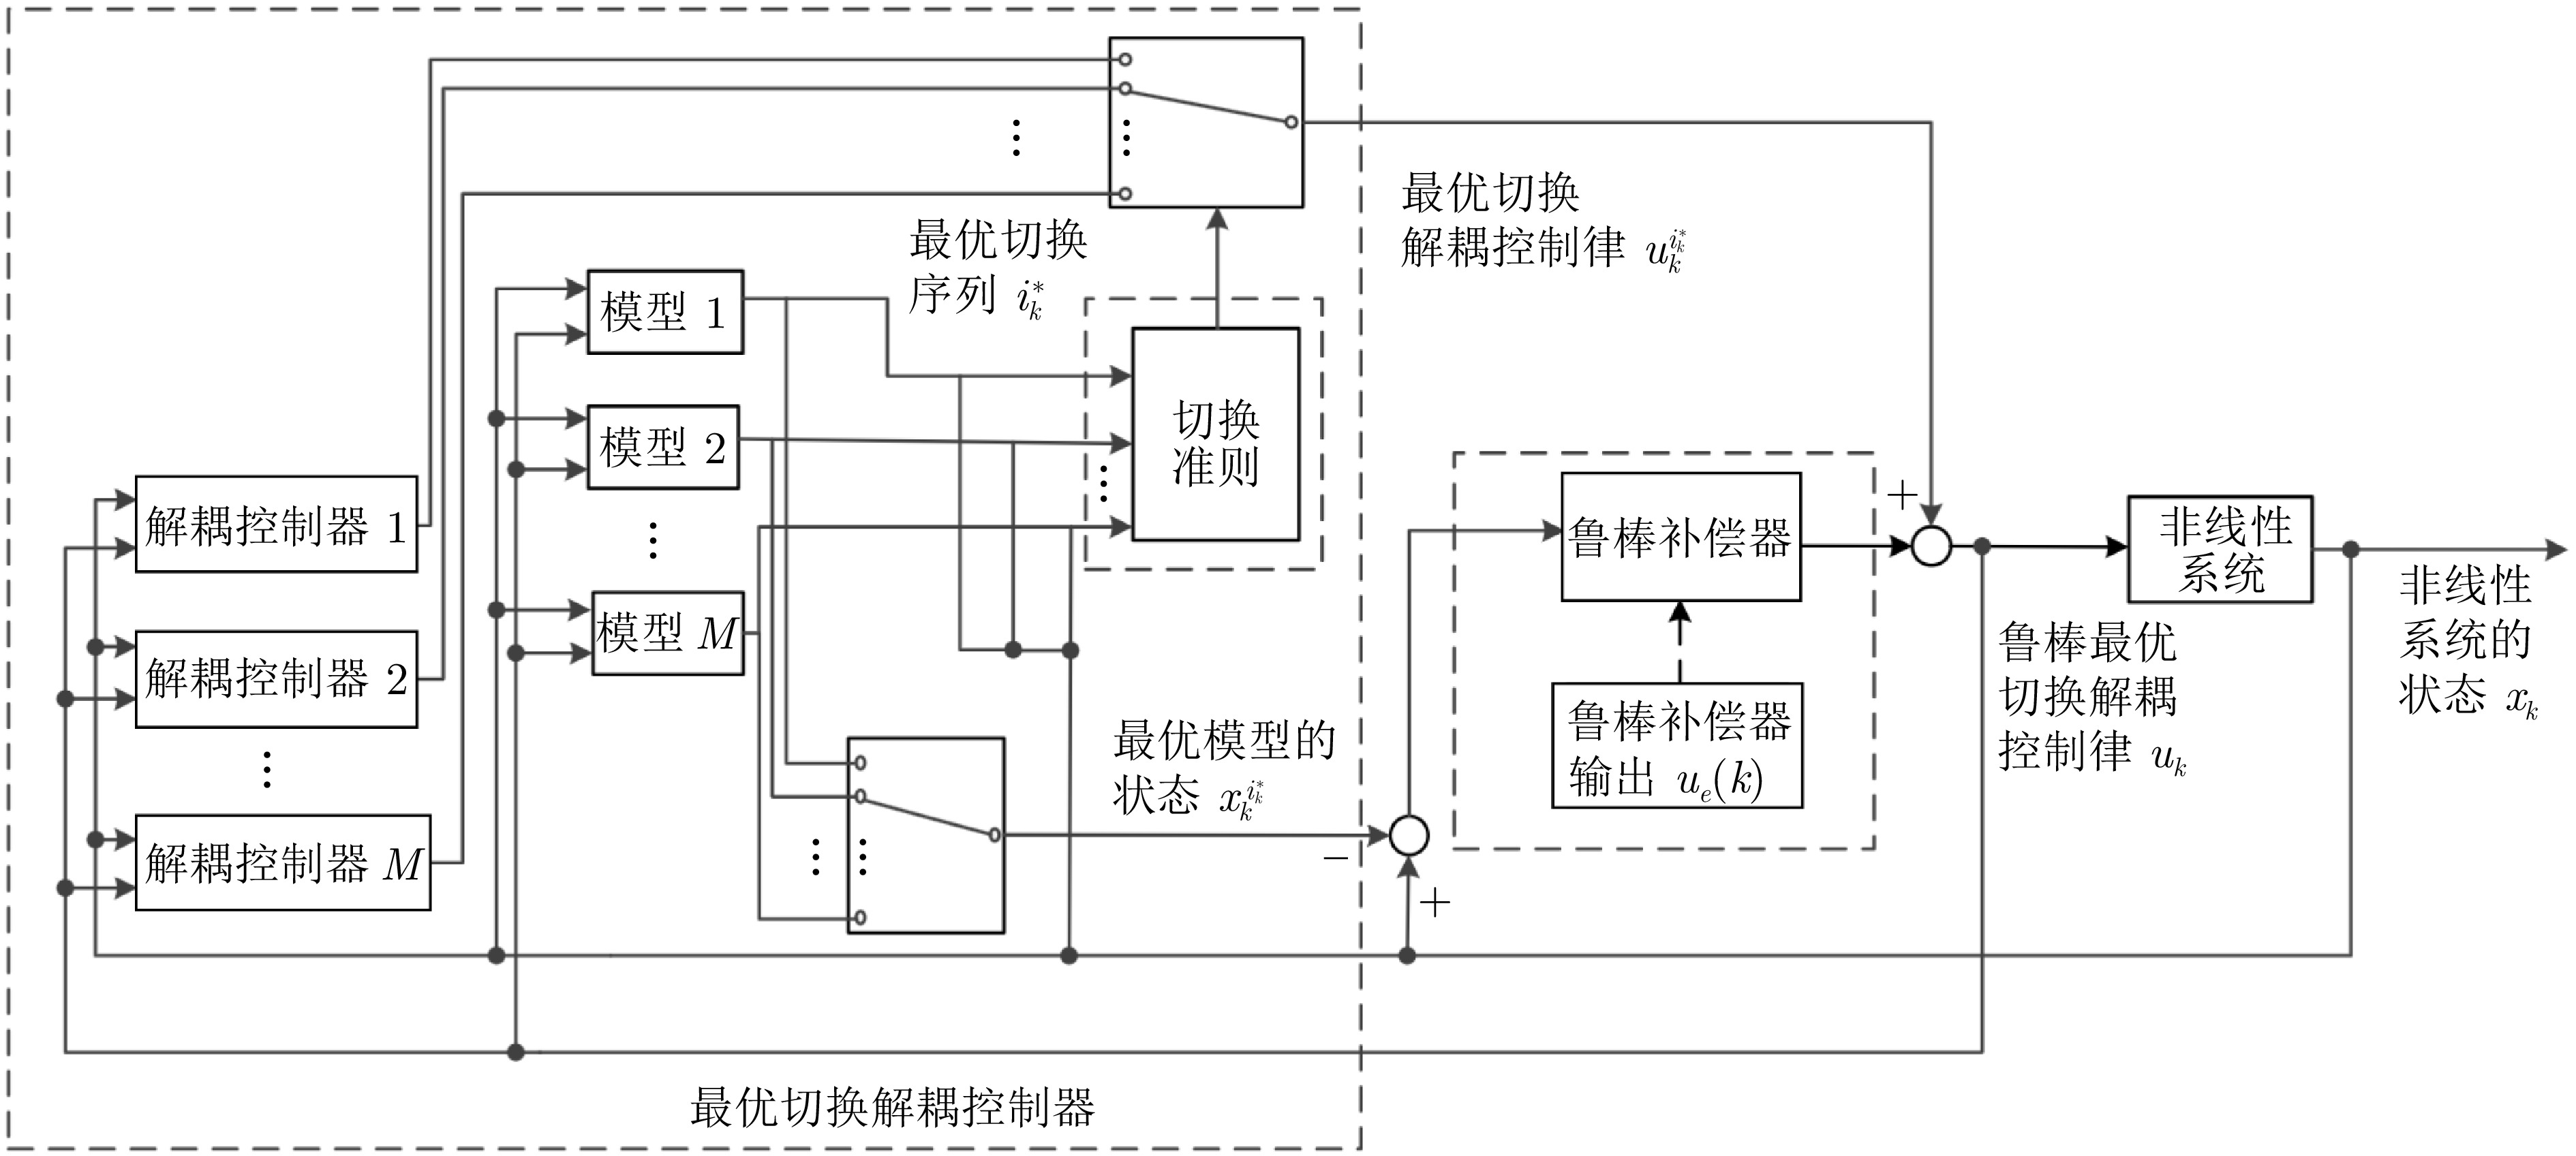
图 1 具有鲁棒特性的最优切换解耦控制系统结构
Fig. 1 Structure of the robust optimal switching decoupling control system
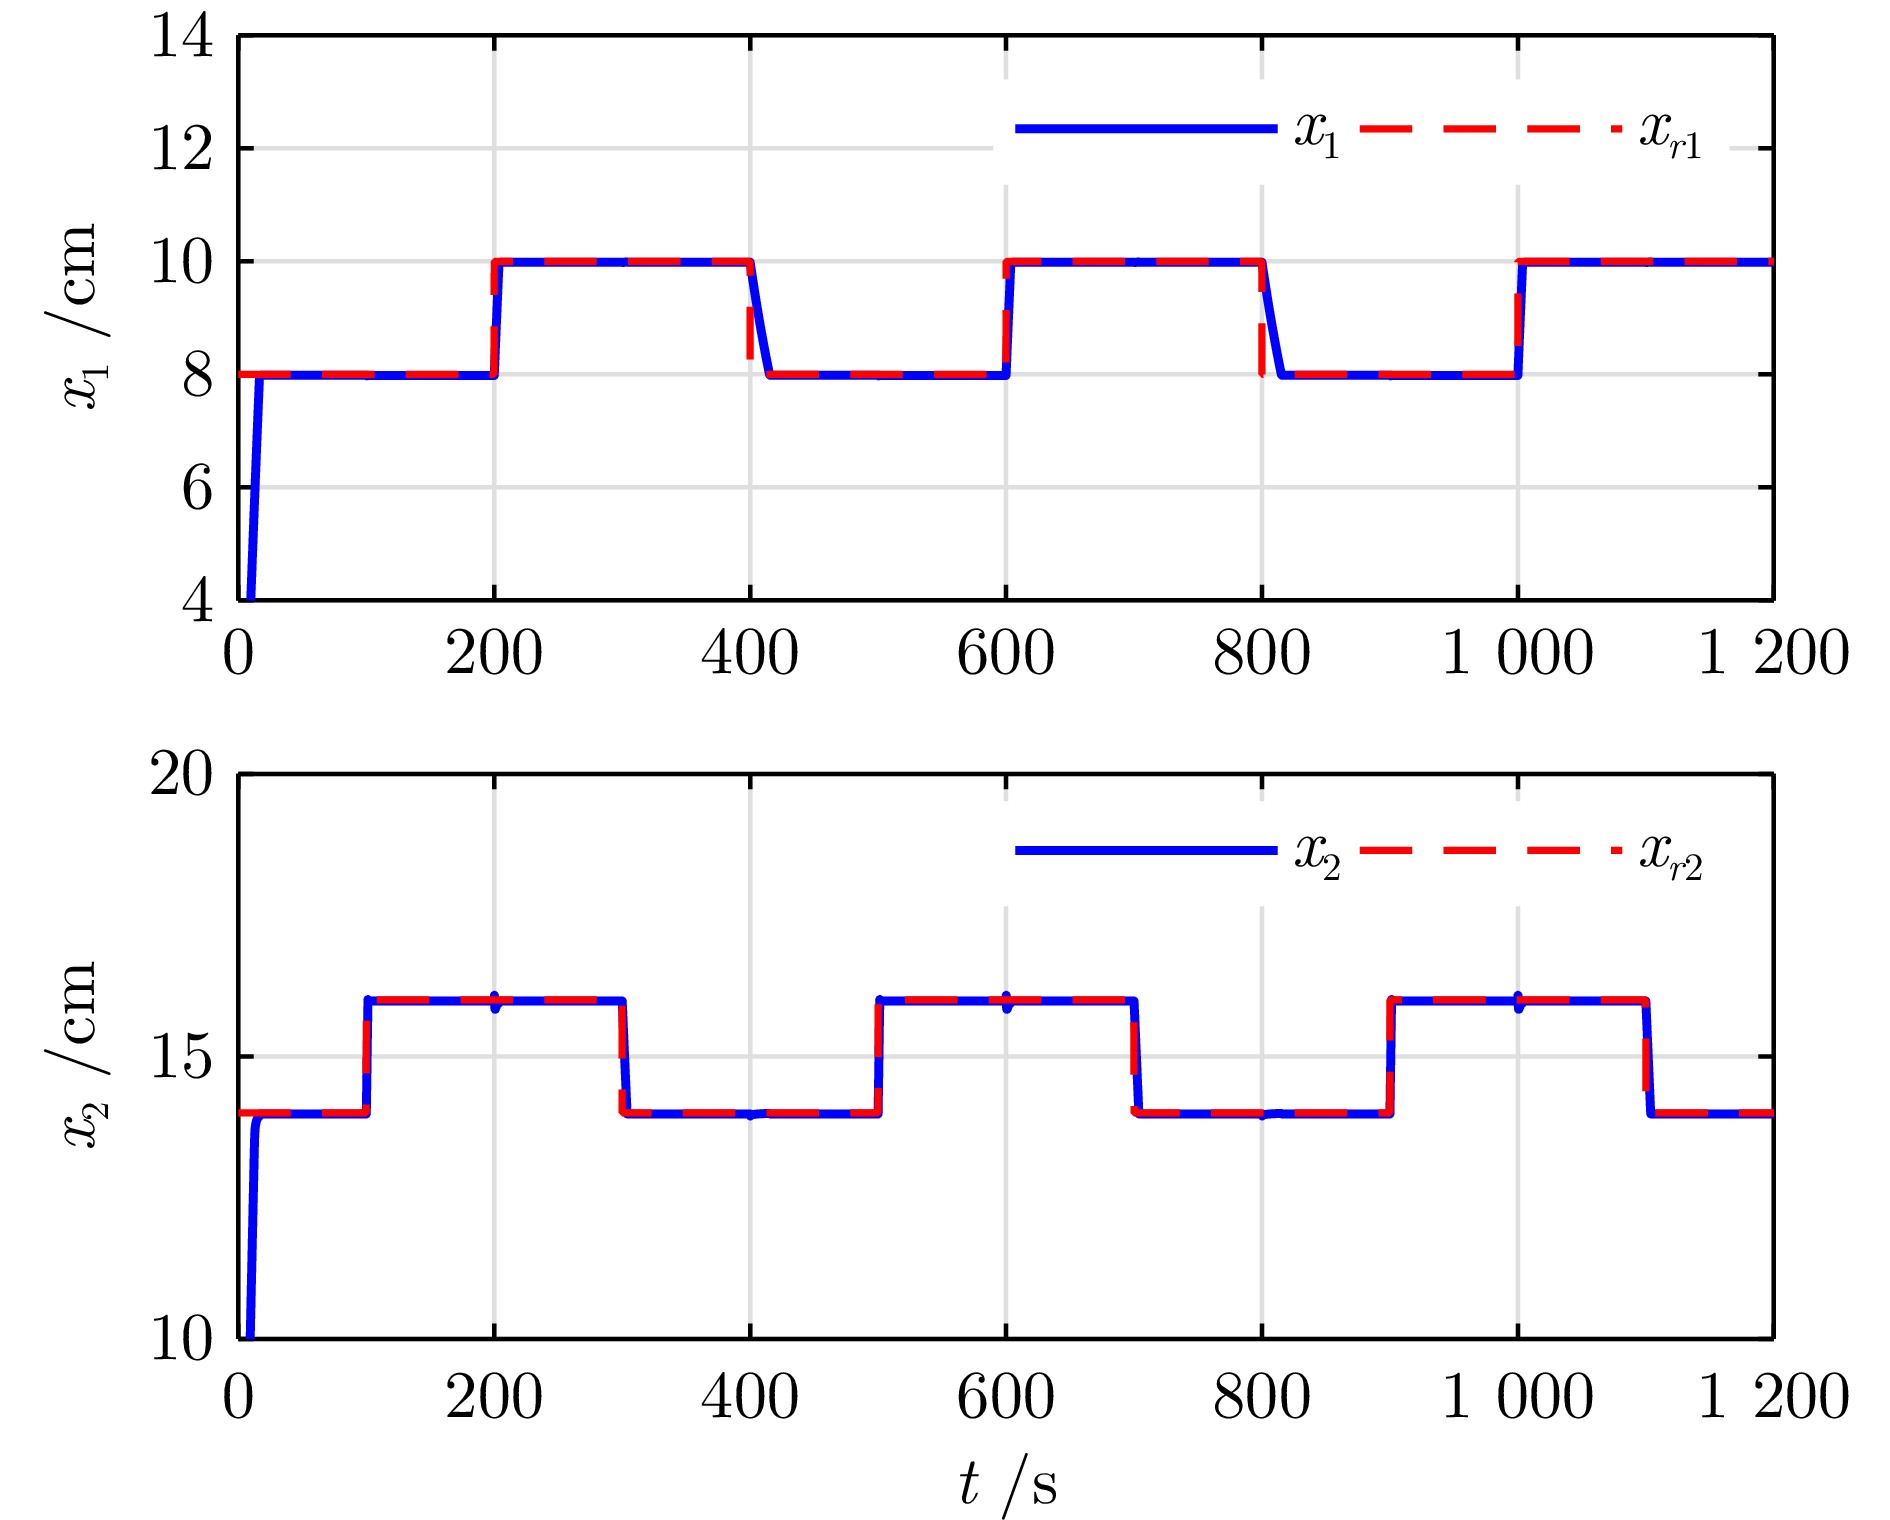
图 2 采用本文所提方法时系统的液位
Fig. 2 Liquid levels of the system using the method proposed in this paper
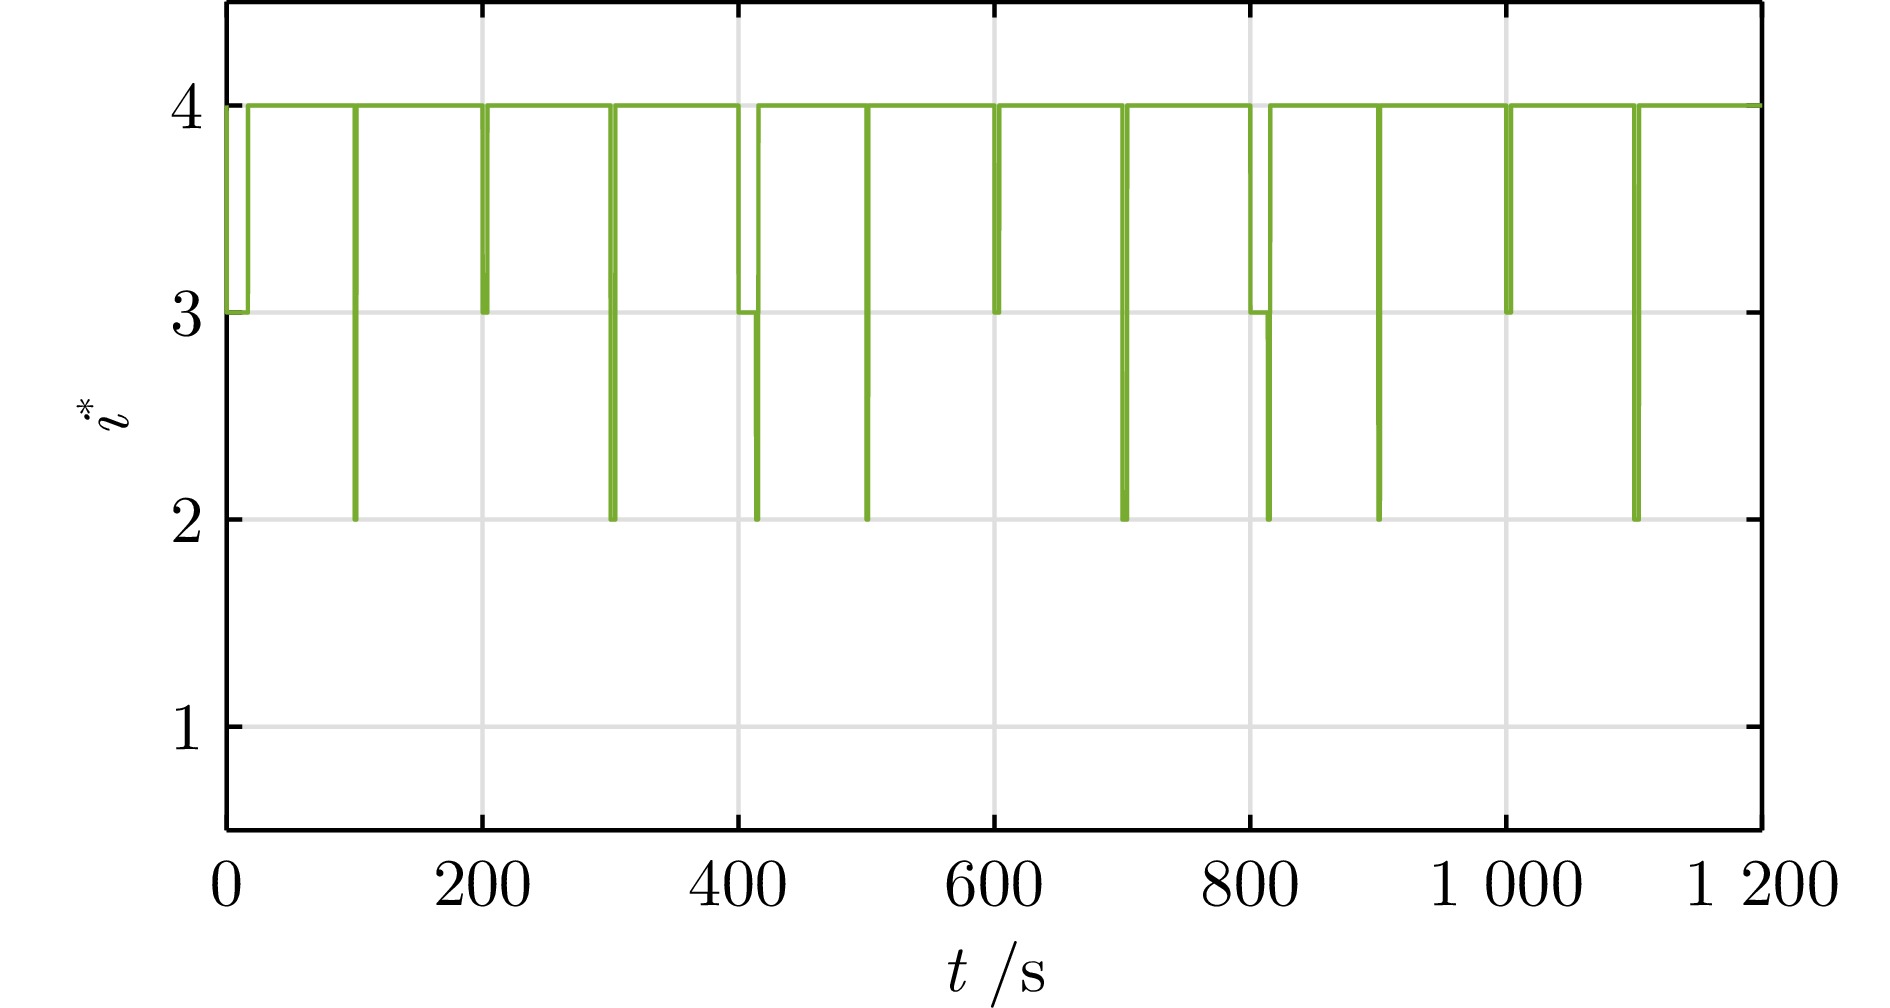
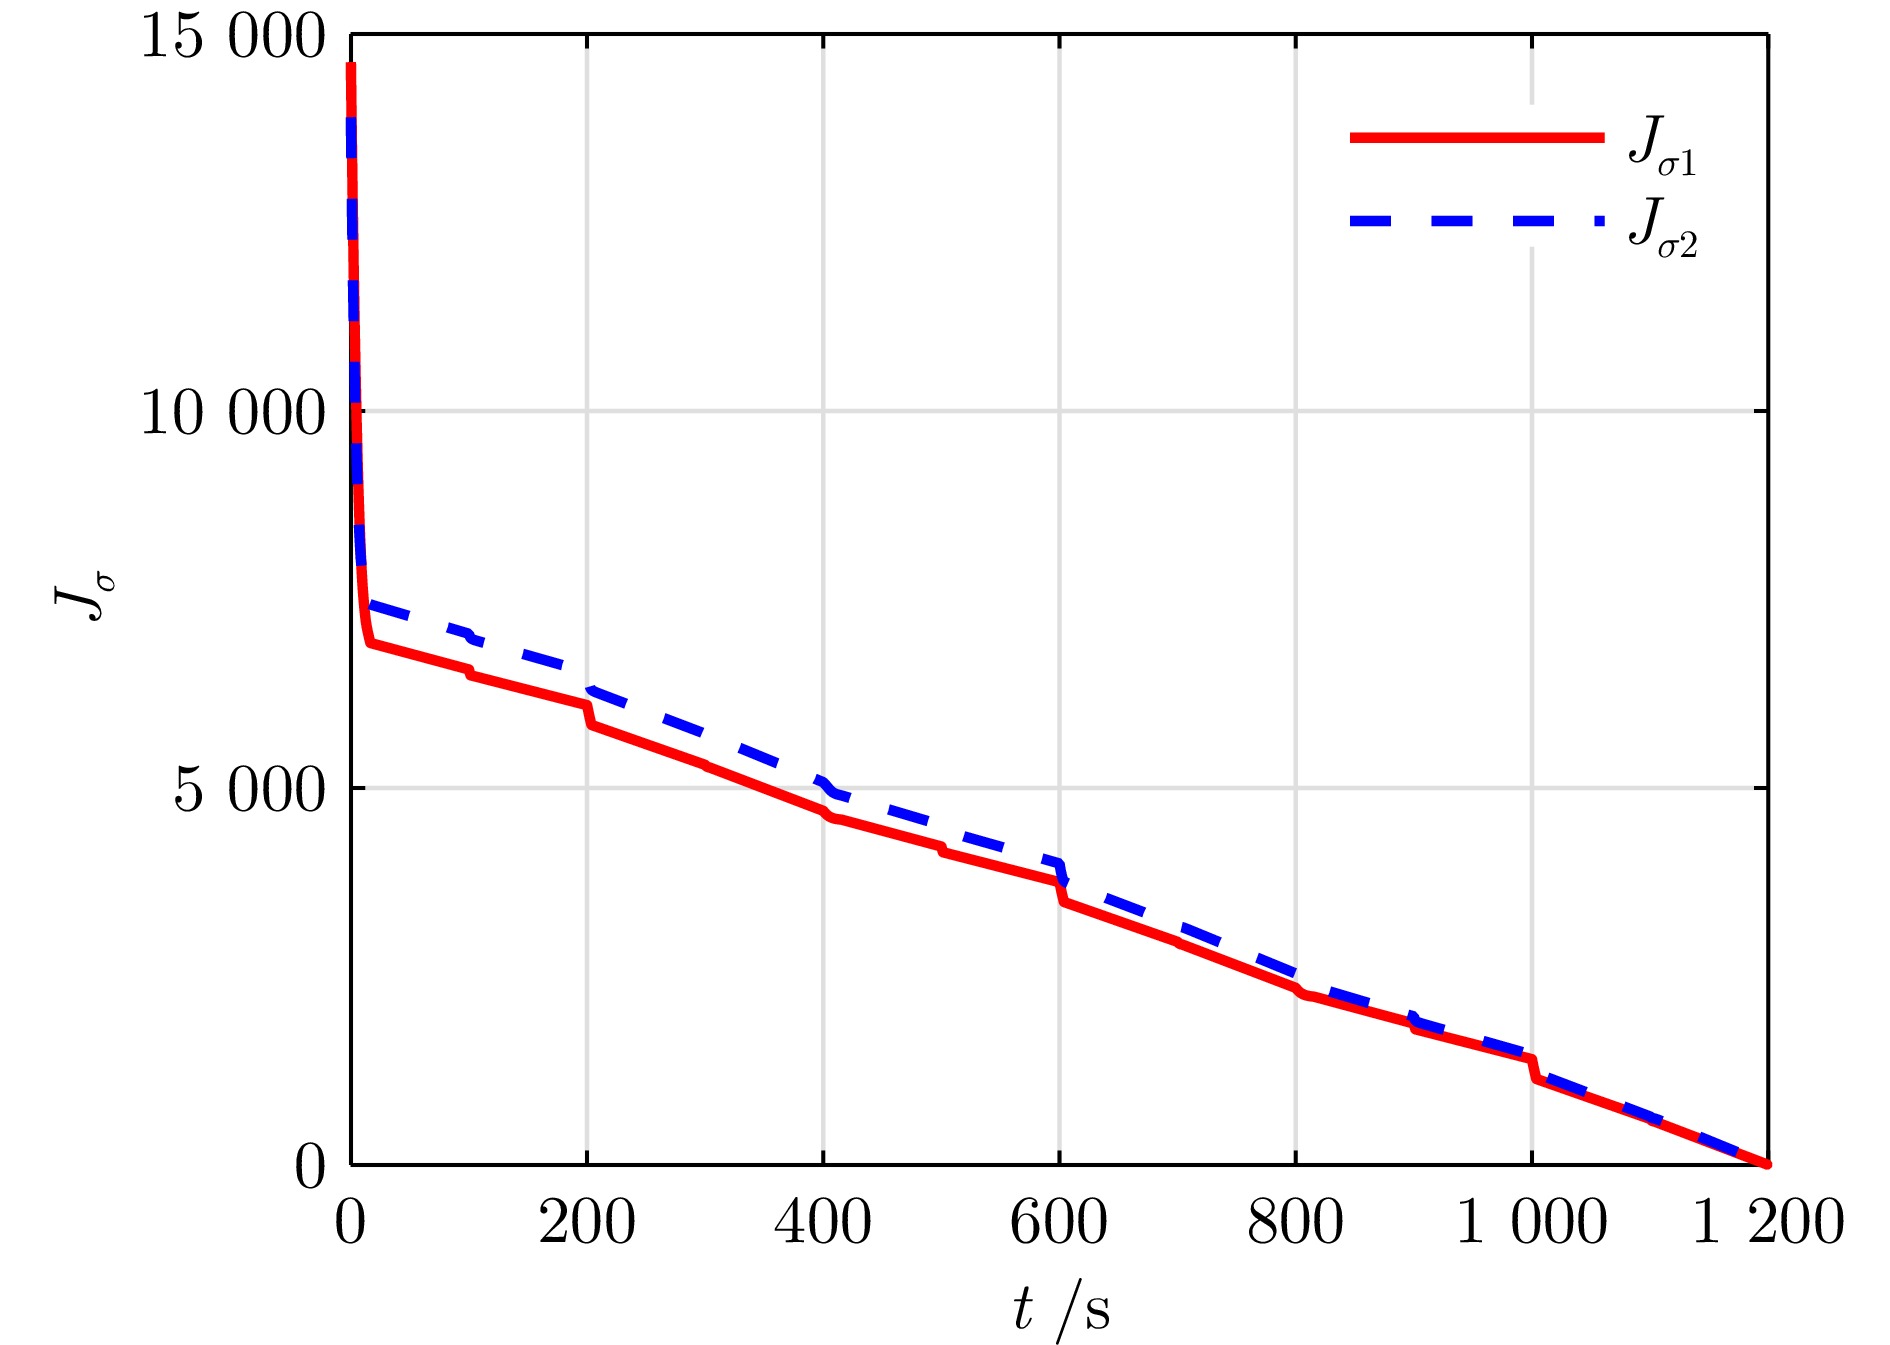
图 4 采用本文所提方法时系统的切换序列
Fig. 4 Switching sequence of the system using the method proposed in this paper
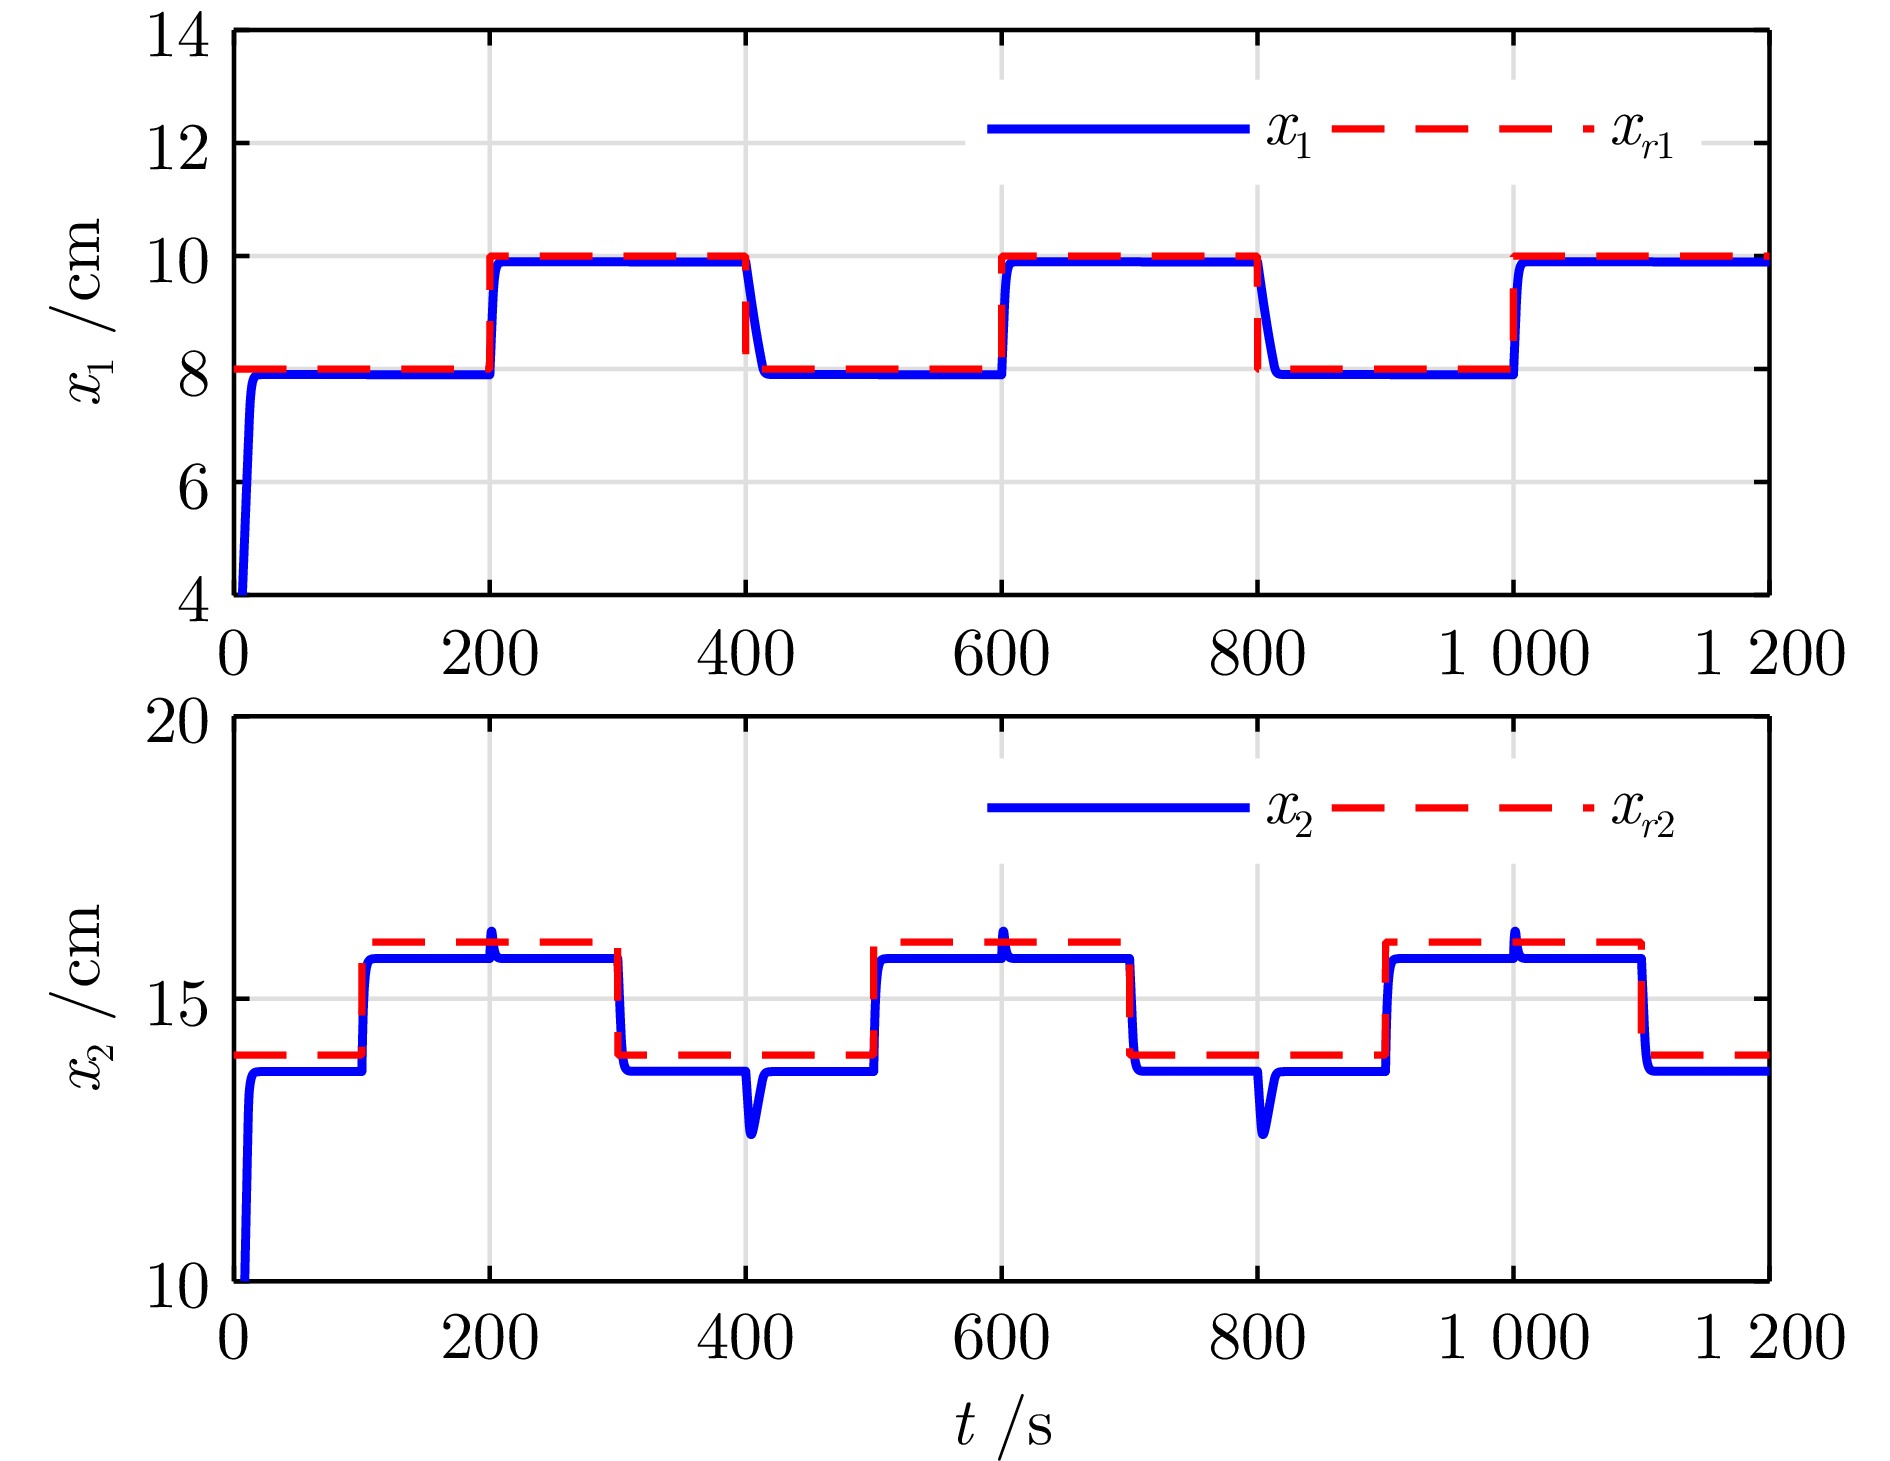
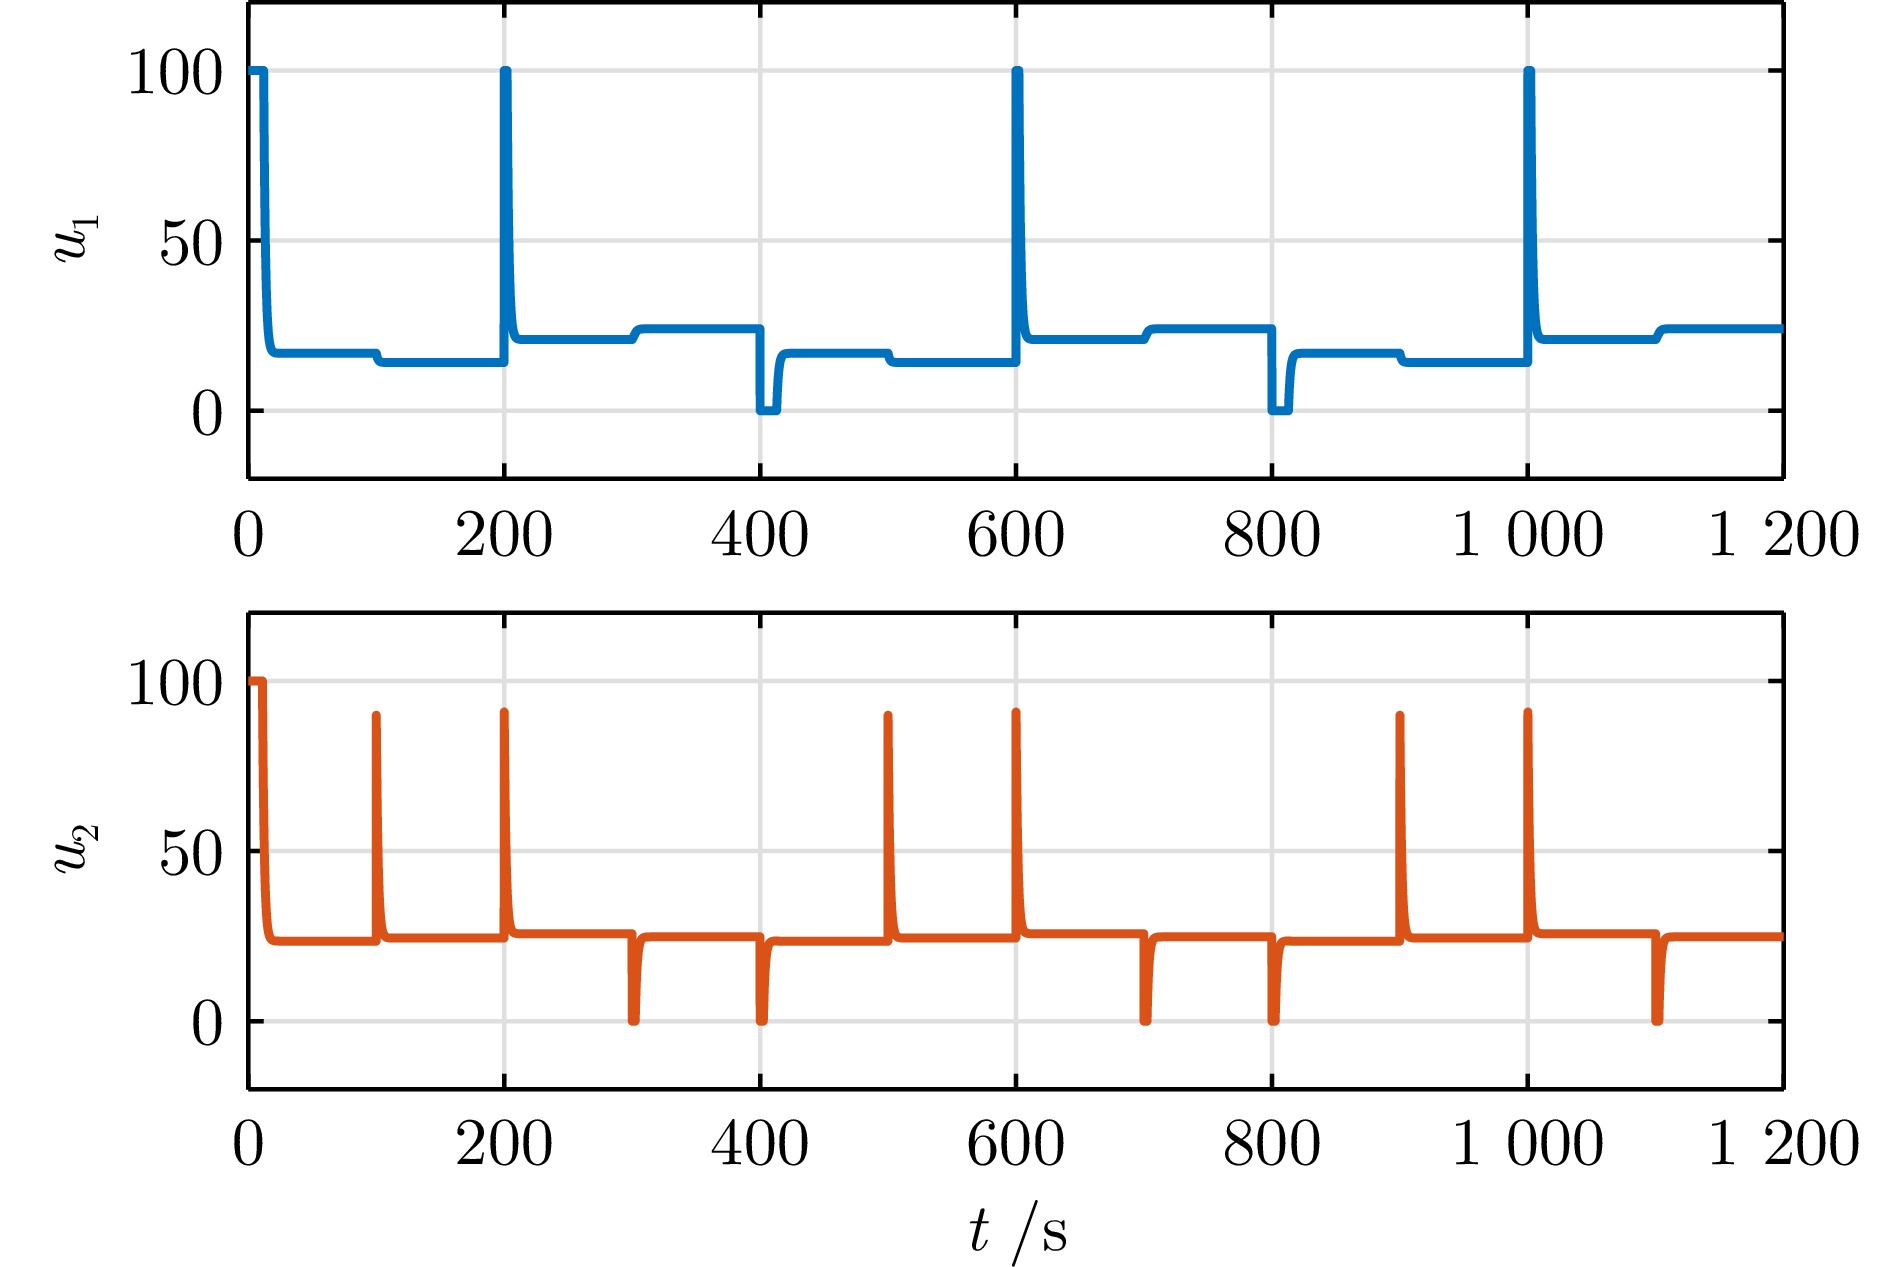
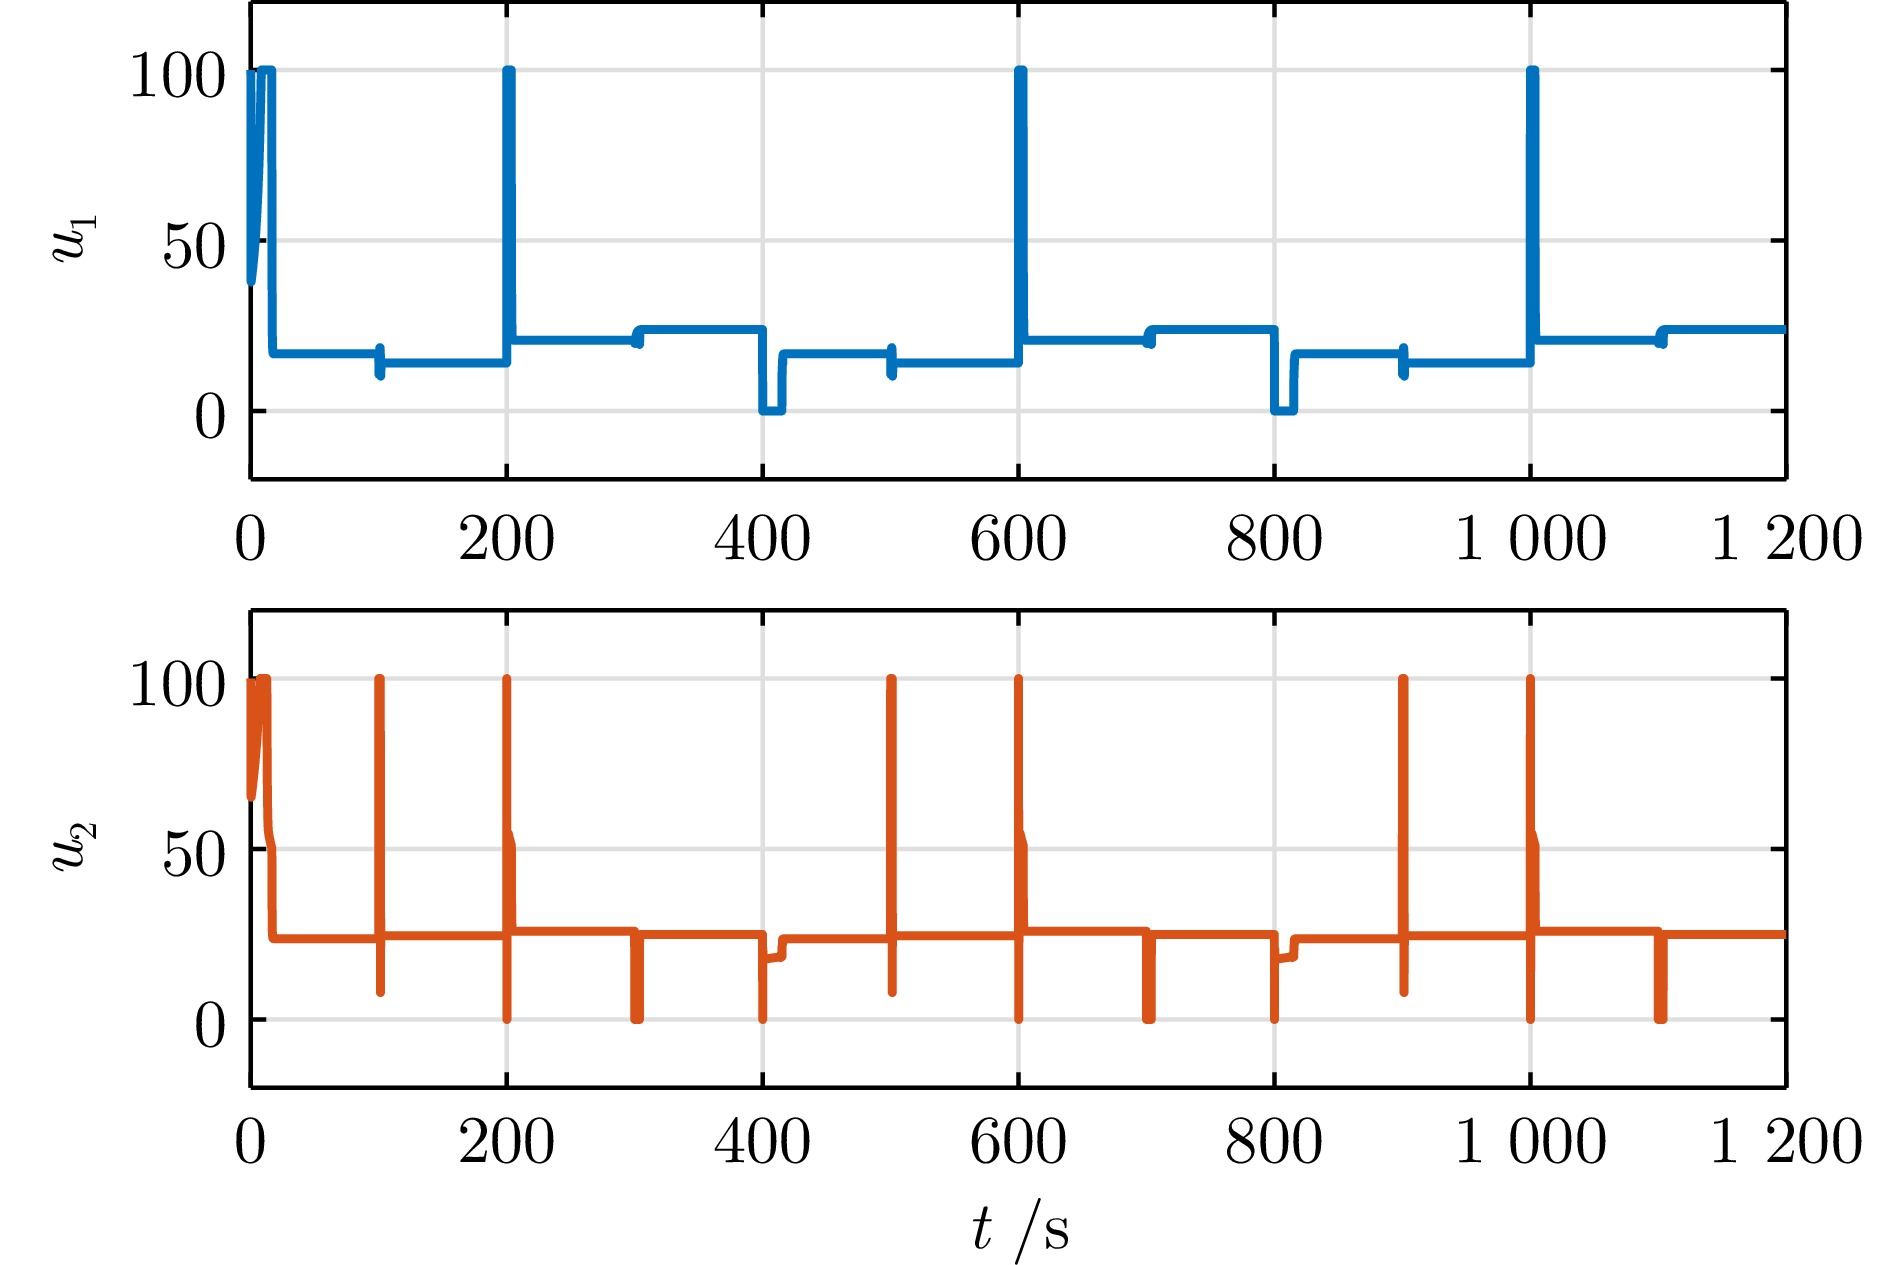
图 3 采用本文所提方法时系统的控制输入
Fig. 3 Control inputs of the system using the method proposed in this paper
-
[1] Hu C, Wang Z, Bu X W, Zhao J, Na J, Gao H. Optimal tracking control for autonomous vehicle with prescribed performance via adaptive dynamic programming. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(9): 12437−12449 doi: 10.1109/TITS.2024.3384113 [2] Wang E H, Liu Y J, Xie C L. Optimal control of intelligent vehicle path tracking. IEEE Access, 2025, 13: 60148−60157 doi: 10.1109/ACCESS.2025.3557215 [3] Sun W, Xie S Y, Su S F. Learning-based adaptive optimal tracking control for flexible-joint robots with quantized states: Theory and experiment. IEEE Transactions on Industrial Electronics, 2025, 72(8): 8230−8239 doi: 10.1109/TIE.2024.3522518 [4] Wang D, Ma H Y, Qiao J F. Multilayer adaptive critic design with digital twin for data-driven optimal tracking control and industrial applications. Engineering Applications of Artificial Intelligence, 2024, 133: Article No. 108228 doi: 10.1016/j.engappai.2024.108228 [5] Wang D, Zhao M M, Ha M M, Ren J. Neural optimal tracking control of constrained nonaffine systems with a wastewater treatment application. Neural Networks, 2021, 143: 121−132 doi: 10.1016/j.neunet.2021.05.027 [6] Tan H H, Shu S L, Lin F. An optimal control approach to robust tracking of linear systems. International Journal of Control, 2009, 82(3): 525−540 doi: 10.1080/00207170802187239 [7] Lewis F, Vrabie D, Syrmos V. Optimal control. Hoboken: John Wiley & Sons, 2012. 177−212 [8] 刘越, 周平, 孙霄阳. 基于Krotov方法的Markov跳变双线性系统最优跟踪控制及应用. 中国科学: 信息科学, 2025, 55: 582−600 doi: 10.1360/SSI-2024-0190Liu Yue, Zhou Ping, Sun Xiao-Yang. Optimal tracking control of Markov jump bilinear system based on Krotov' s method and its application. Scientia Sinica Informationis, 2025, 55: 582−600 doi: 10.1360/SSI-2024-0190 [9] Xia R S, Wu Q X, Chen M. Disturbance observer-based optimal longitudinal trajectory control of near space vehicle. Scientia Sinica Informationis, 2019, 62(5): Article No. 050212 [10] 毛艳岭, 富月. 非线性系统自适应最优切换控制方法. 自动化学报, 2023, 49(10): 2122−2135 doi: 10.16383/j.aas.c220180Mao Yan-Ling, Fu Yue. Adaptive optimal switching control of nonlinear systems. Acta Automatica Sinica, 2023, 49(10): 2122−2135 doi: 10.16383/j.aas.c220180 [11] Wang W Z, Fu Y, Fu J. Indirect adaptive optimal tracking switching control of nonlinear systems. IEEE Transactions on Automatic Control, 2024, 69(6): 4142−4149 doi: 10.1109/TAC.2024.3351590 [12] Wang W Z, Fu Y. Robust adaptive optimal tracking switching control of nonlinear systems using embedding transformation and approximate dynamic programming. International Journal of Adaptive Control and Signal Processing, 2025, 39(5): 1079−1090 doi: 10.1002/acs.3993 [13] Lu J W, Wei Q L, Wang F Y. Parallel control for optimal tracking via adaptive dynamic programming. IEEE/CAA Journal of Automatica Sinica, 2020, 7(6): 1662−1674 doi: 10.1109/jas.2020.1003426 [14] Wei Q L, Jiao S S, Wang F Y, Dong Q. Robust optimal parallel tracking control based on adaptive dynamic programming. IEEE Transactions on Cybernetics, 2024, 54(7): 4308−4321 [15] Liu K X, Song F Z, Dong Y, Liu Y, Tan J B. Data-based dynamic decoupling control for MIMO precision motion stages with position-dependent disturbances. IEEE Transactions on Automation Science and Engineering, 2025, 22: 6122−6133 doi: 10.1109/TASE.2024.3439102 [16] Li M, Mao C H, Zhu Y, Yang K M, Li X. Data-based iterative dynamic decoupling control for precision MIMO motion systems. IEEE Transactions on Industrial Informatics, 2020, 16(3): 1668−1676 [17] Liu Y C, Huang C Y. DDPG-based adaptive robust tracking control for aerial manipulators with decoupling approach. IEEE Transactions on Cybernetics, 2022, 52(8): 8258−8271 doi: 10.1109/tcyb.2021.3049555 [18] Zhao H Y, Wan Y, Li L, Dong Y, Cui N. Iterative control decoupling tuning for precision MIMO motion systems: A matrix update method. ISA Transactions, 2024, 155: 398−413 doi: 10.1016/j.isatra.2024.10.003 [19] Zhao C, Yu C G, Yao J Y. Dynamic decoupling based robust synchronous control for a hydraulic parallel manipulator. IEEE Access, 2019, 7: 30548−30562 doi: 10.1109/ACCESS.2019.2894134 [20] Ji C, Zhang Z Q, Cheng G G, Kong M X, Li R F. Decoupled robust backstepping tracking control for variable stiffness actuated robot with input saturation. ISA Transactions, 2025, 156: 109−122 doi: 10.1016/j.isatra.2024.10.027 [21] Fu Y, Chen W, Fu J. A new optimal tracking controller of linear strongly coupled systems and its applications. IEEE Transactions on Circuits and Systems II: Express Briefs, 2022, 69(3): 1387−1391 doi: 10.1109/tcsii.2021.3122434 [22] 富月, 陈威. 具有解耦性能的离散时间线性多变量系统最优跟踪控制. 自动化学报, 2022, 48(8): 1931−1939Fu Yue, Chen Wei. Optimal tracking control method for discrete-time linear multivariable systems with decoupling performance. Acta Automatica Sinica, 2022, 48(8): 1931−1939 [23] 宋君男. 双容水箱系统自适应解耦切换控制 [硕士学位论文], 东北大学, 中国, 2012.Song Jun-Nan. Adaptive Decoupling Switching Control on a Dual-tank Water System [Master thesis], Northeastern University, China, 2012. -

 下载:

计量
- 文章访问数: 114
- HTML全文浏览量: 62
- 被引次数: 0
