

Human-like Whole-body Motion Control for Humanoid Robot With Integrated Virtual Waist Joints
-
摘要: 复杂运动的稳定性与社会环境的适应性是人形机器人实现自然交互与任务执行的核心能力, 而高质量、高协调的仿人运动是保障其高效稳定运行的基础. 腰部自由度作为上下肢协调控制的关键枢纽, 对整体动态稳定性与动作流畅性具有显著影响. 然而, 现有研究在腰部自由度建模与控制方面关注不足, 导致机器人在仿人行走中易出现姿态畸变甚至运动失稳. 为此, 提出一种融合腰部虚拟关节的人形机器人仿人全身运动控制框架. 该框架首先利用动作捕捉系统采集人体多维关节点数据, 并通过关节空间映射实现运动风格的高保真迁移. 随后, 针对人体腰部与机器人结构间的自由度差异, 构建融合俯仰与滚转虚拟关节的上下肢动力学模型, 提出多关节主动补偿机制以实现对虚拟腰部自由度的协同补偿. 进一步地, 将虚拟关节引入特权观测空间, 构建对抗式动作先验风格奖励与任务奖励的可变融合策略, 从而实现全身协调的仿人运动控制. 实验基于Isaac Gym训练平台与MuJoCo仿真环境, 在多种行走速率 (0.2 ~ 1.6 m/s) 下开展测试, 结果表明所提方法能显著提升人形机器人的仿人运动自然度与泛化能力.Abstract: The stability of complex motion and the adaptability to social environments are core capabilities for humanoid robots to achieve natural interaction and task execution, where high-quality and highly coordinated human-like motion serves as the foundation for their efficient and stable operation. As the key hub for upper-lower limb coordination control, the waist degrees of freedom (DOFs) play a critical role in maintaining overall dynamic stability and motion fluency. However, limited attention to waist DOF modeling and control in existing studies often leads to posture distortion or instability during human-like walking. To address this issue, this paper proposes a human-like whole-body motion control framework for humanoid robot with integrated virtual waist joints. The framework first employs a motion capture system to acquire multi-dimensional human joint data, which are mapped into the humanoid robot's joint space to achieve high-fidelity transfer of motion style. Then, considering the DOF discrepancy between the human waist and the robot structure, a coupled upper-lower limb dynamic model incorporating virtual pitch and roll waist joints is constructed, and a multi-joint active compensation mechanism is developed to realize coordinated compensation for the virtual waist DOFs. Furthermore, the virtual joints are incorporated into the privileged observation space, and a variable fusion strategy combining adversarial motion prior style rewards and task rewards is designed to achieve whole-body coordinated human-like motion control. Experiments conducted in the Isaac Gym training platform and MuJoCo simulation environment demonstrate that the proposed method significantly improves the naturalness and generalization of humanoid robots' human-like motion under various walking speeds (0.2 ~ 1.6 m/s).
-
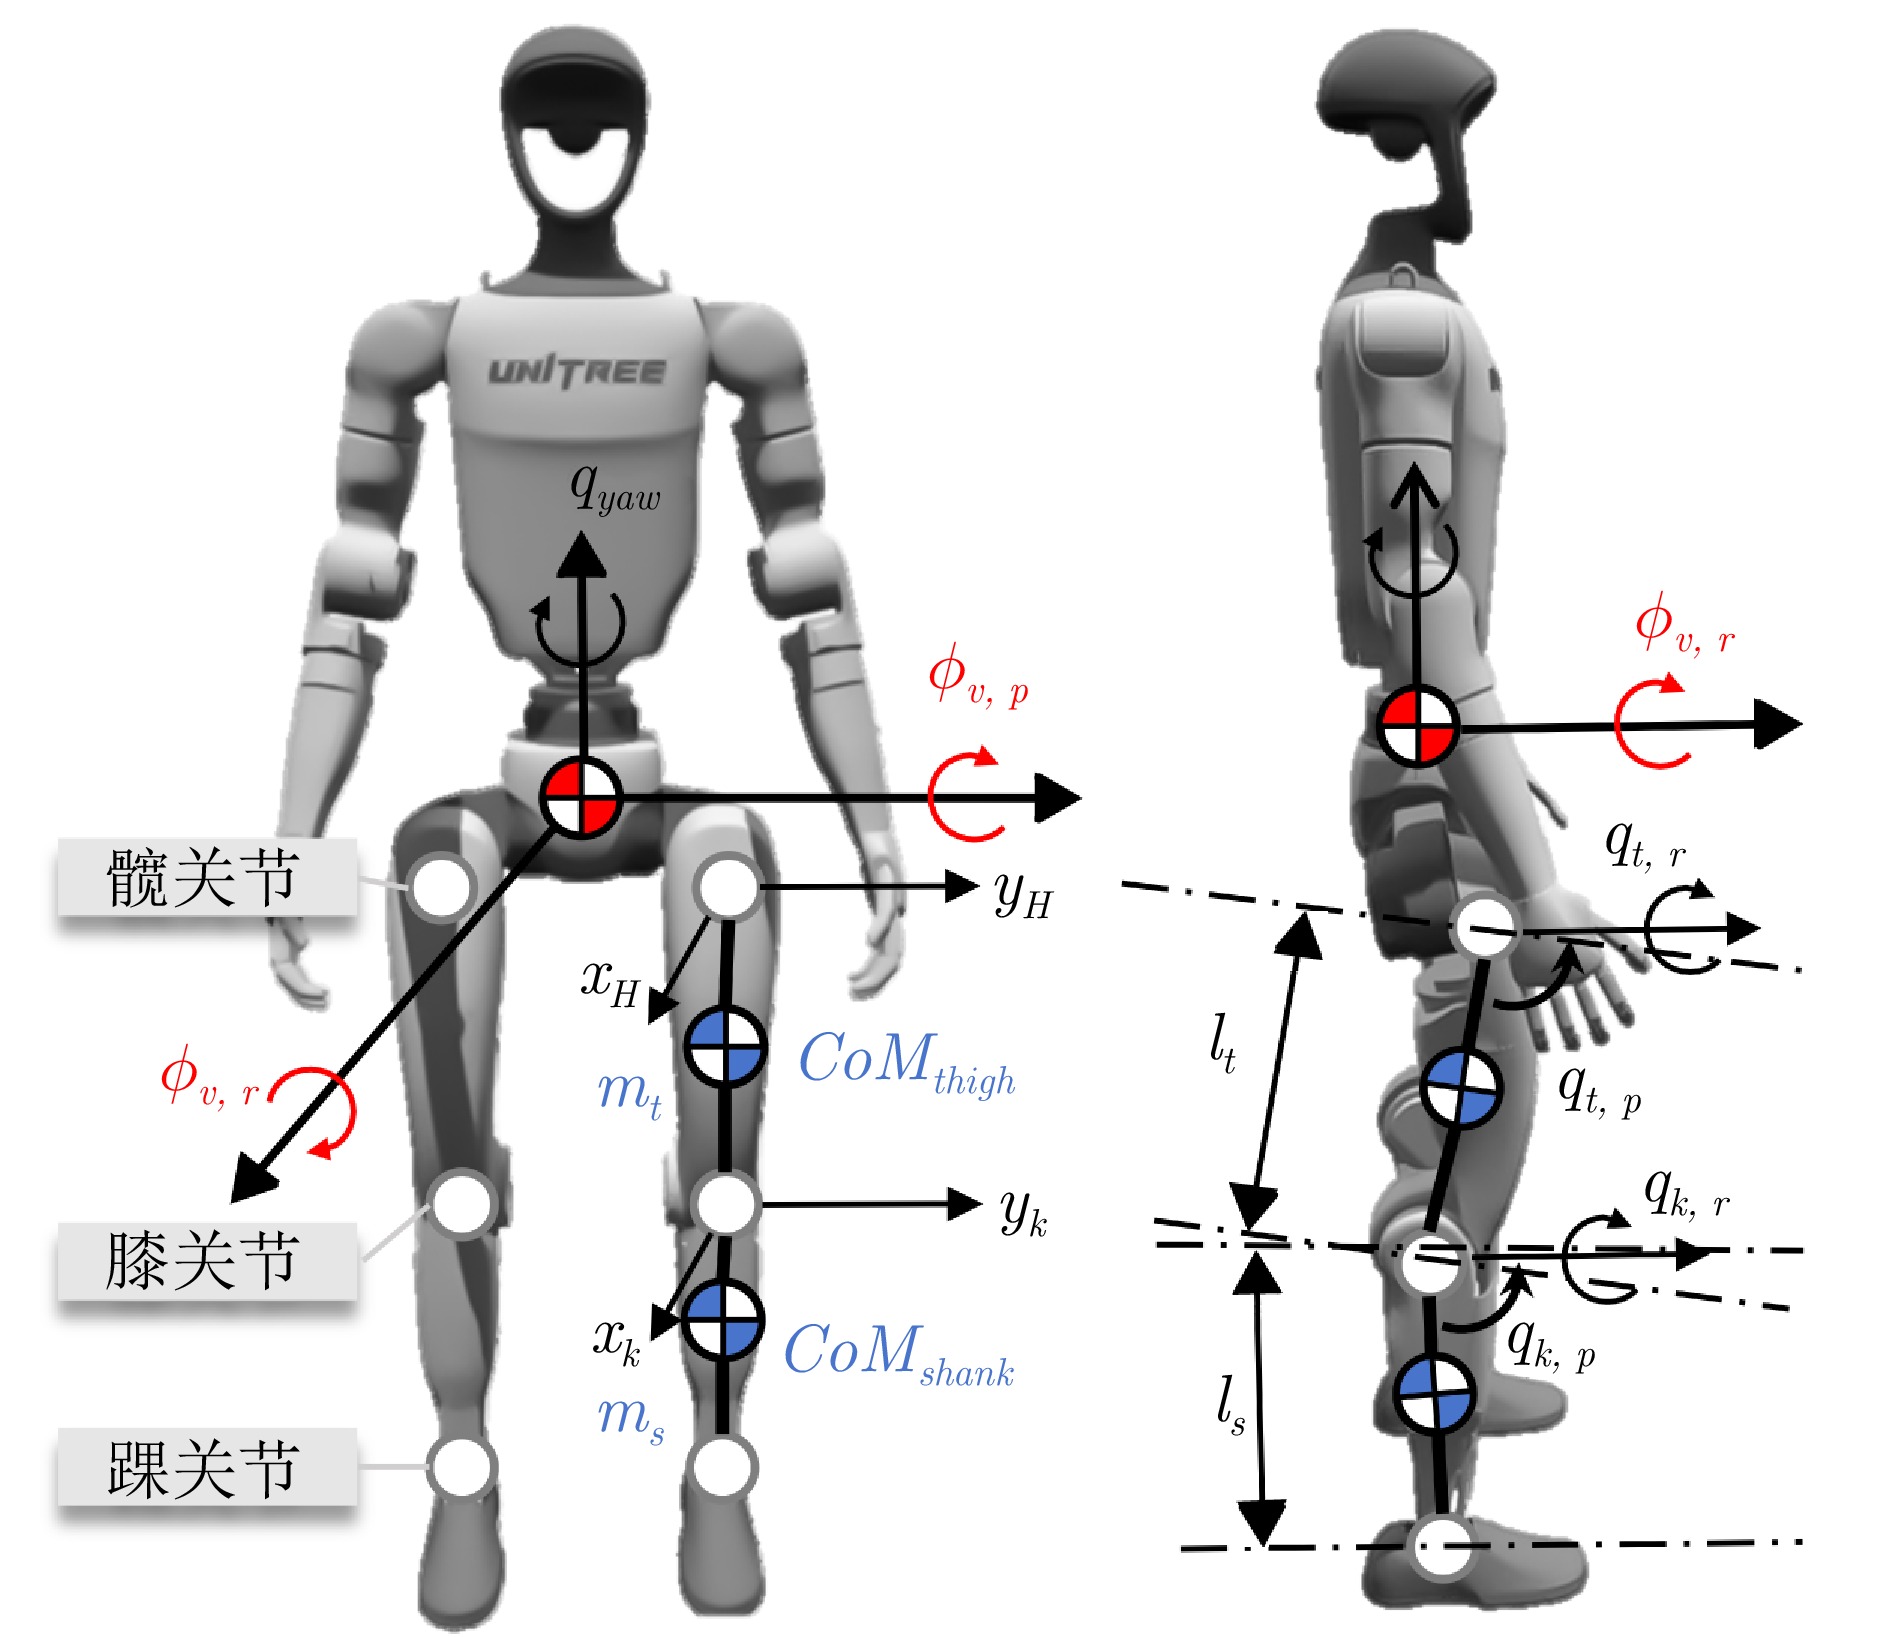
图 3 带有虚拟腰部关节的机器人动力学模型
注: ${{q}}_{{yaw}} $为腰部关节偏航角度; $x_H $、$y_H $为髋关节坐标系; $x_k $、 $y_k $为膝关节坐标系; $q_{k, r} $为膝关节滚转角, 对应图2中膝 关节俯仰角.
Fig. 3 Robot dynamic model with a virtual waist joint
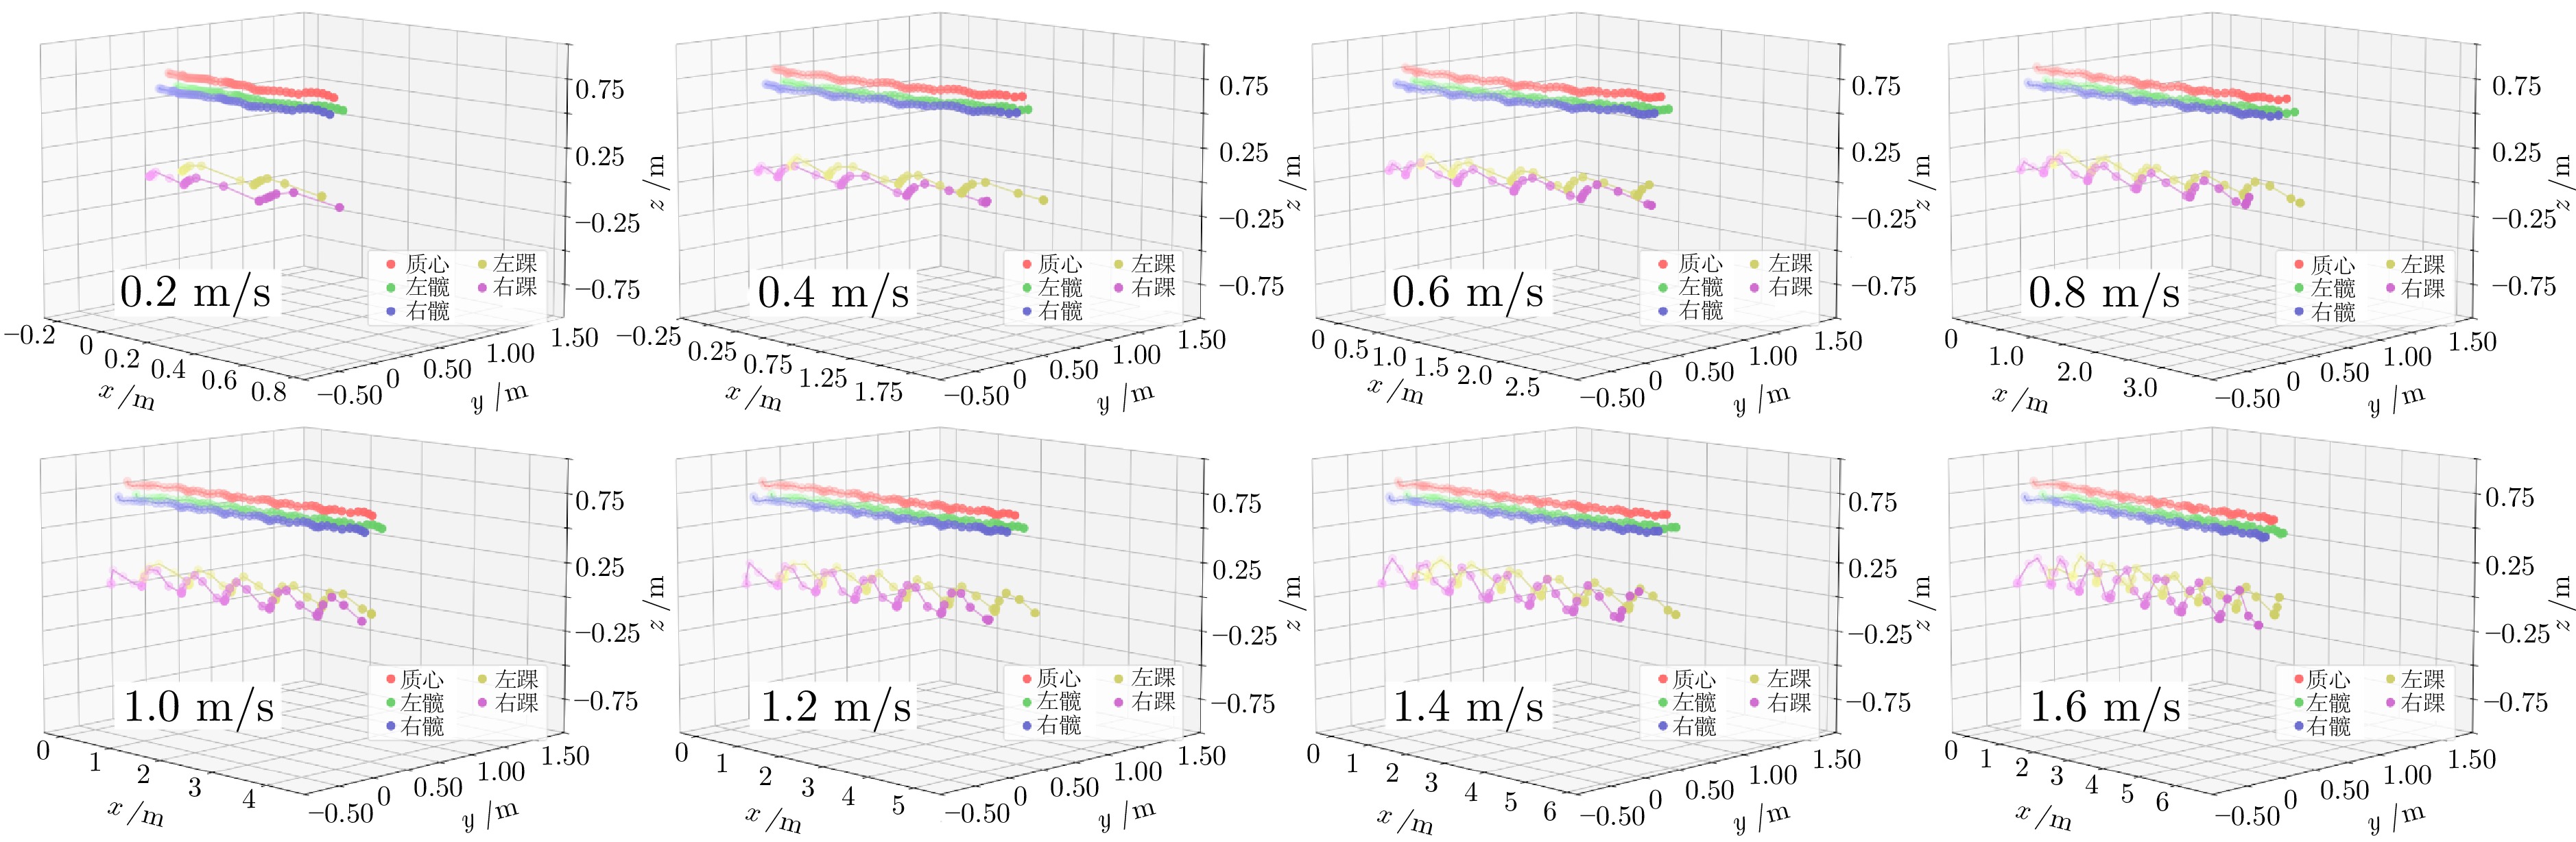
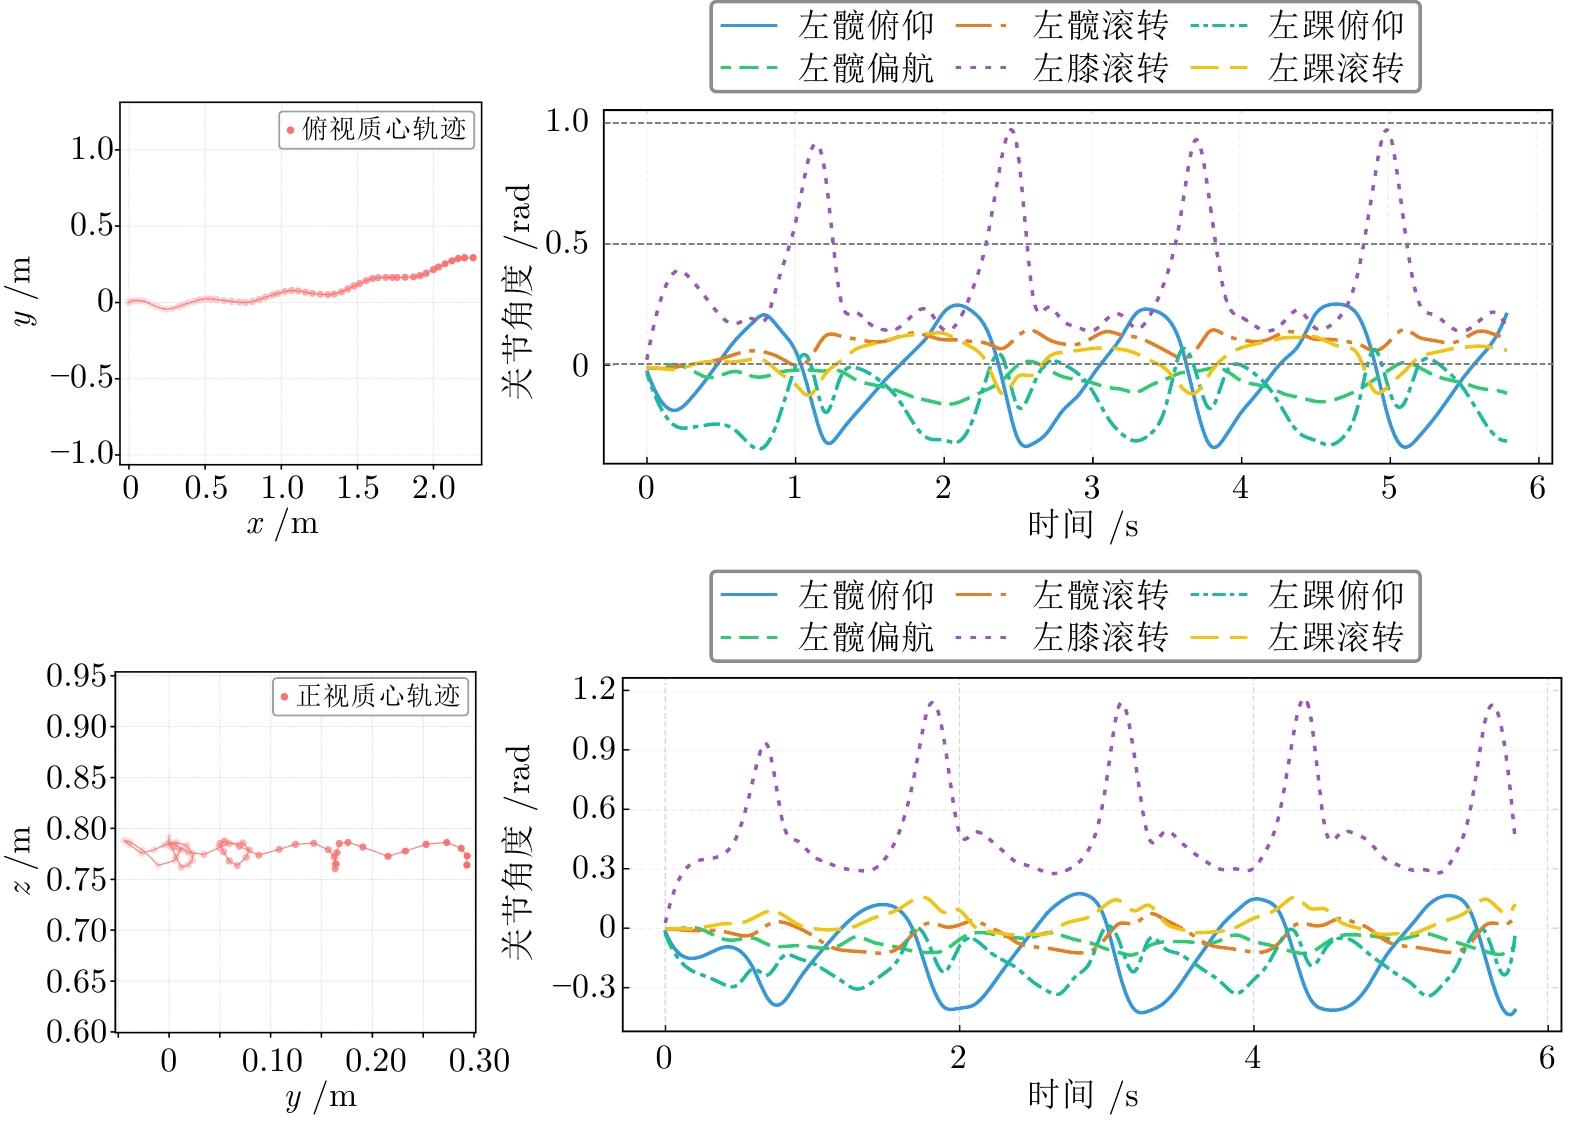
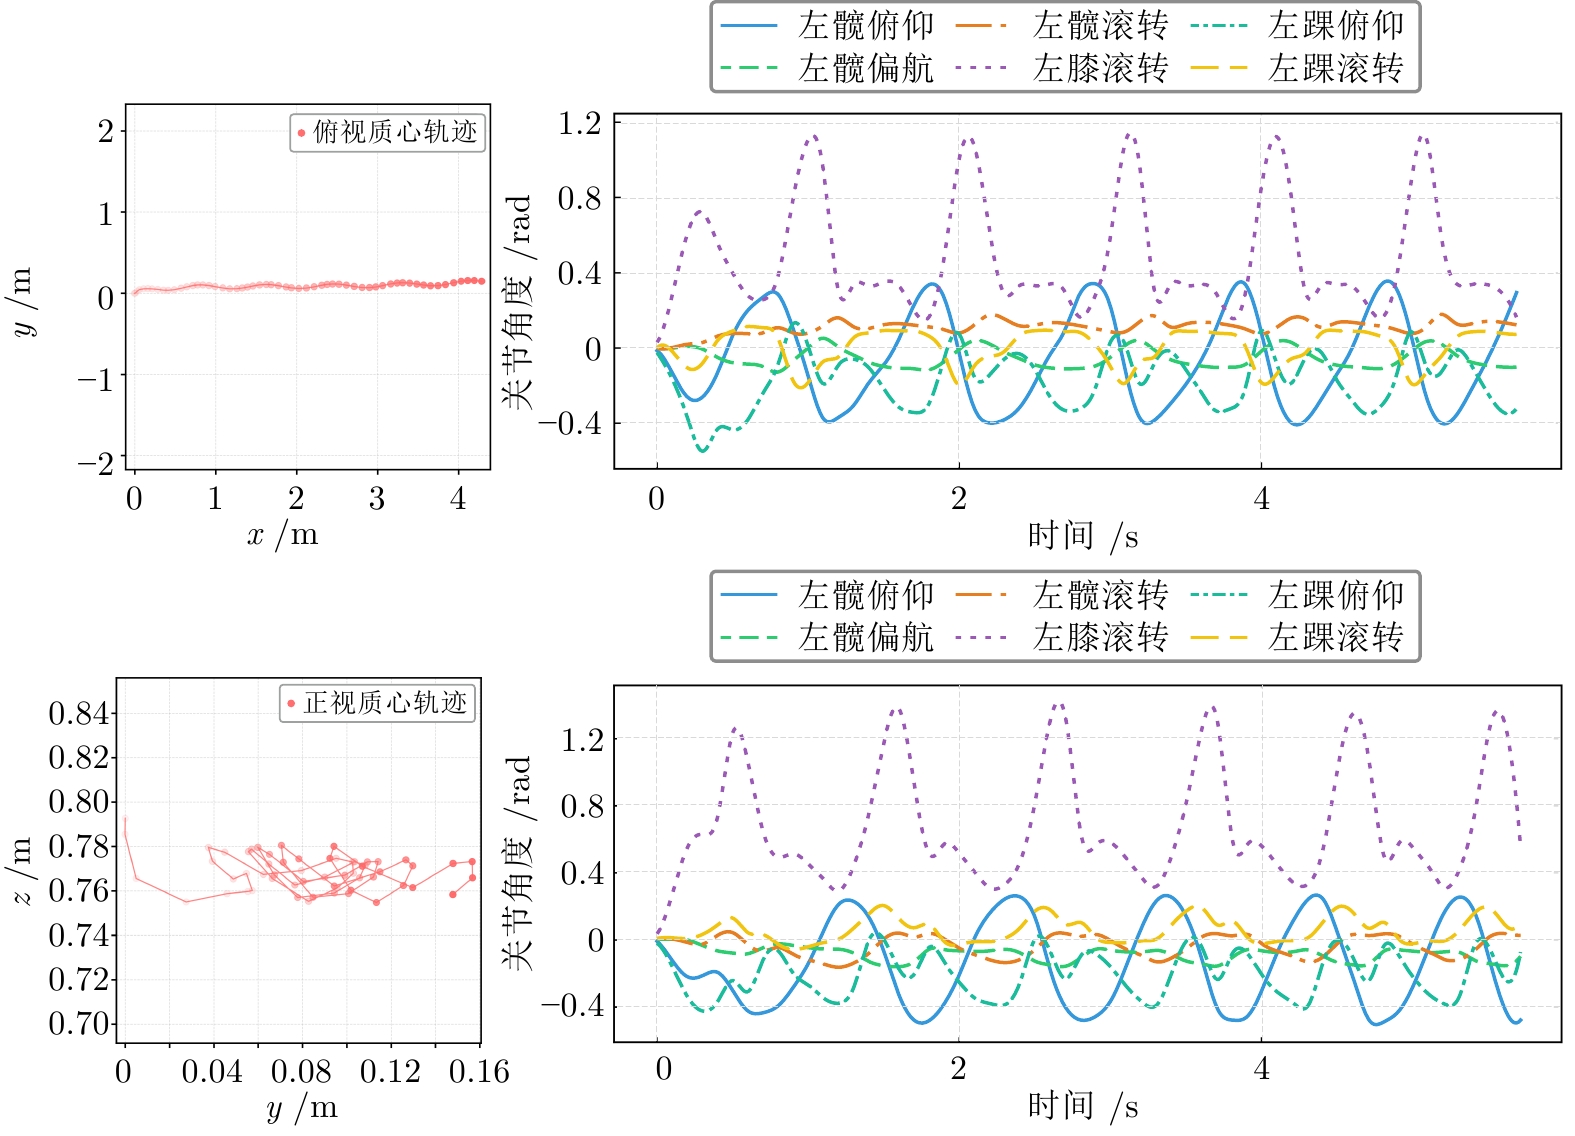
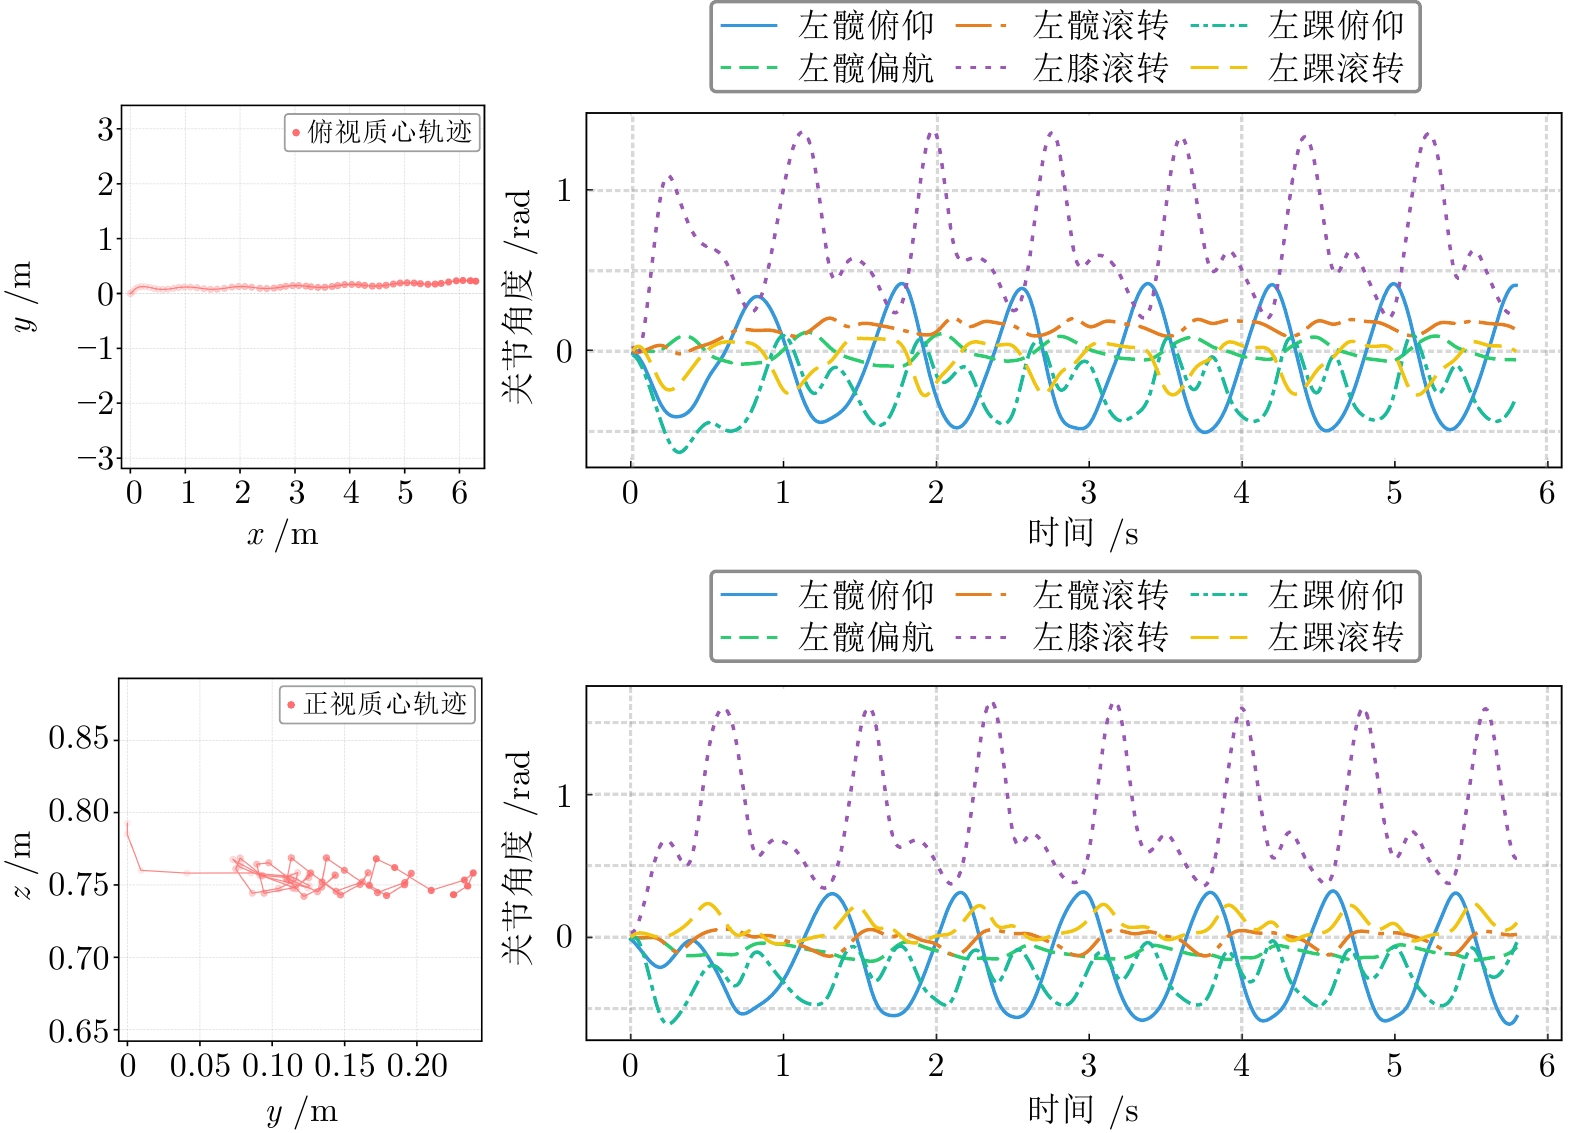
图 4 离散速度指令下机器人质心、髋关节及踝关节空间轨迹
Fig. 4 Spatial trajectories of the robot's center of mass, hip joints, and ankle joints under discrete velocity commands
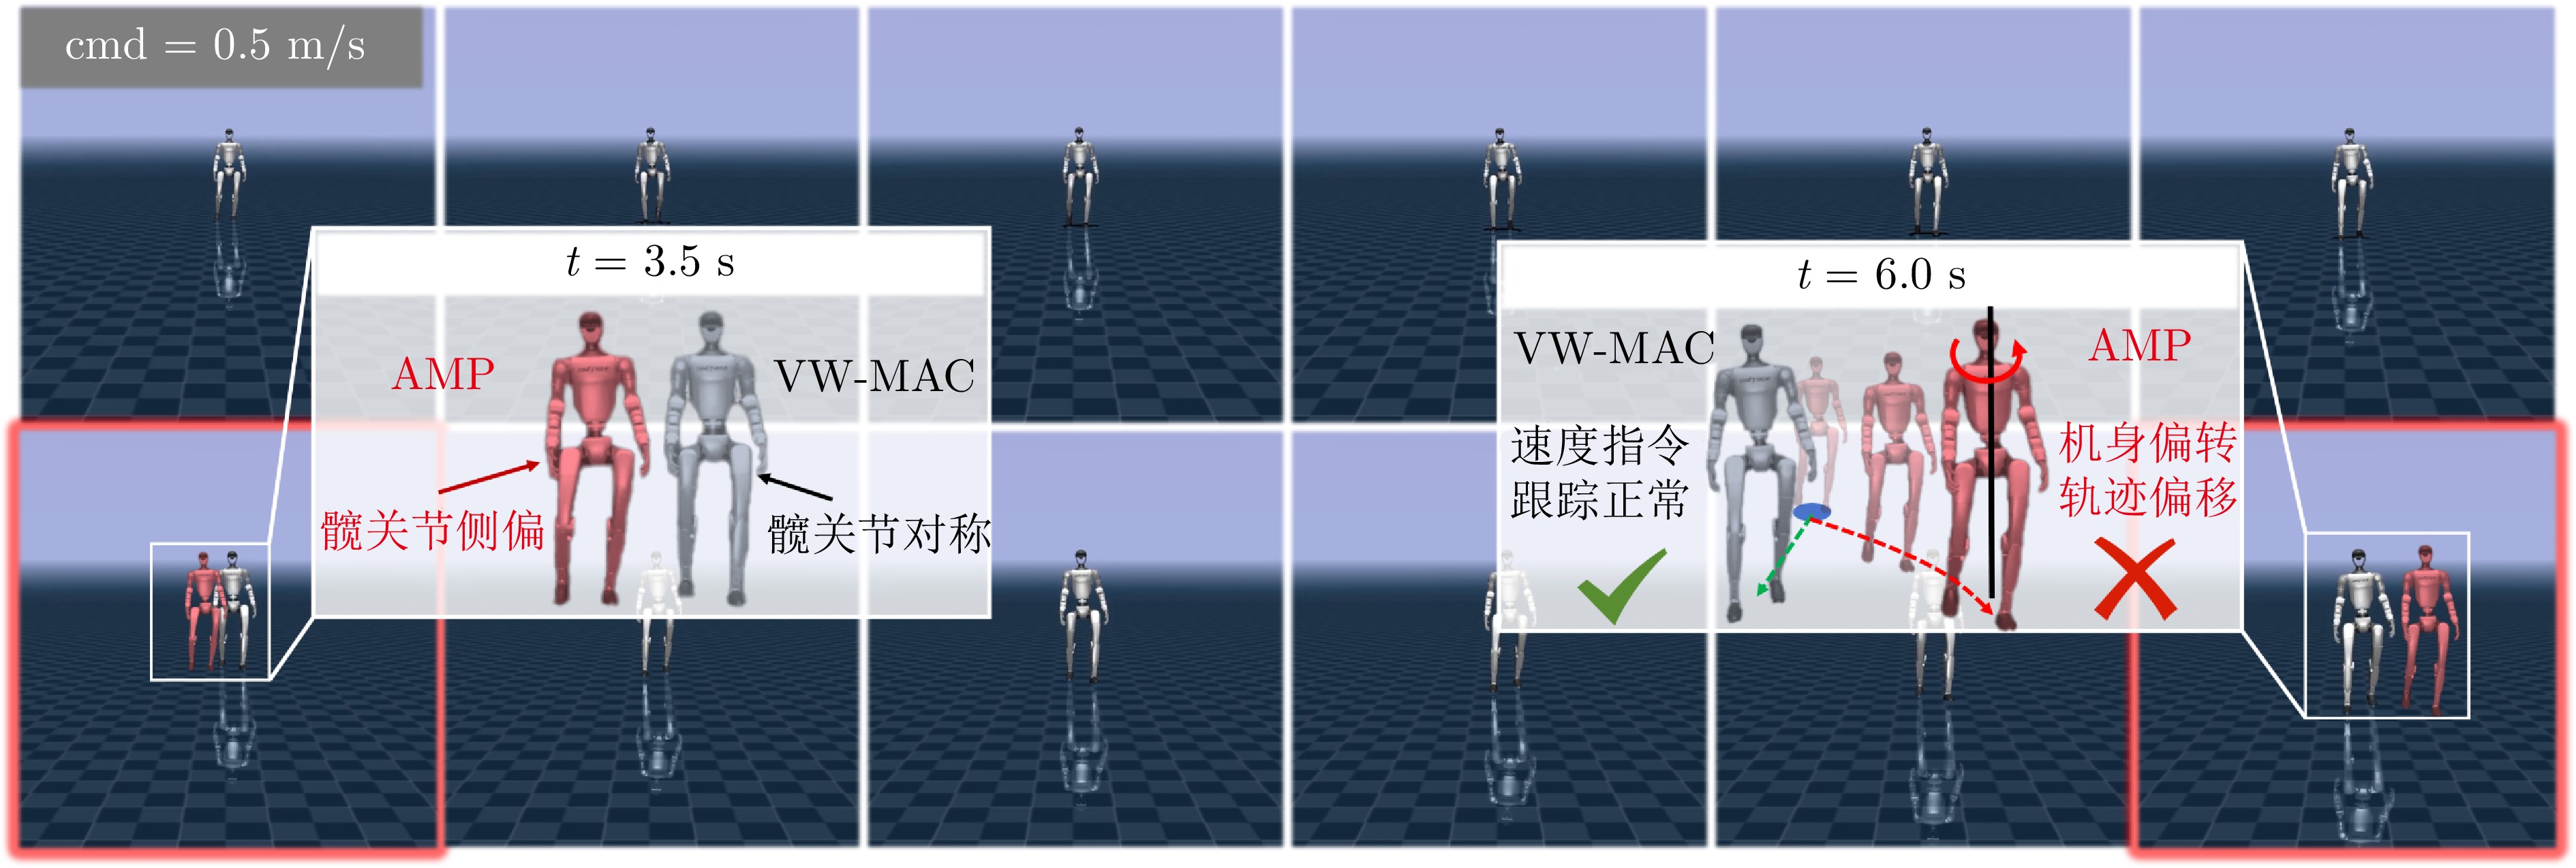
图 9 速度指令0.5 m/s下人形机器人行走关键帧切片
Fig. 9 Keyframe slices of humanoid robot walking at a 0.5 m/s velocity command
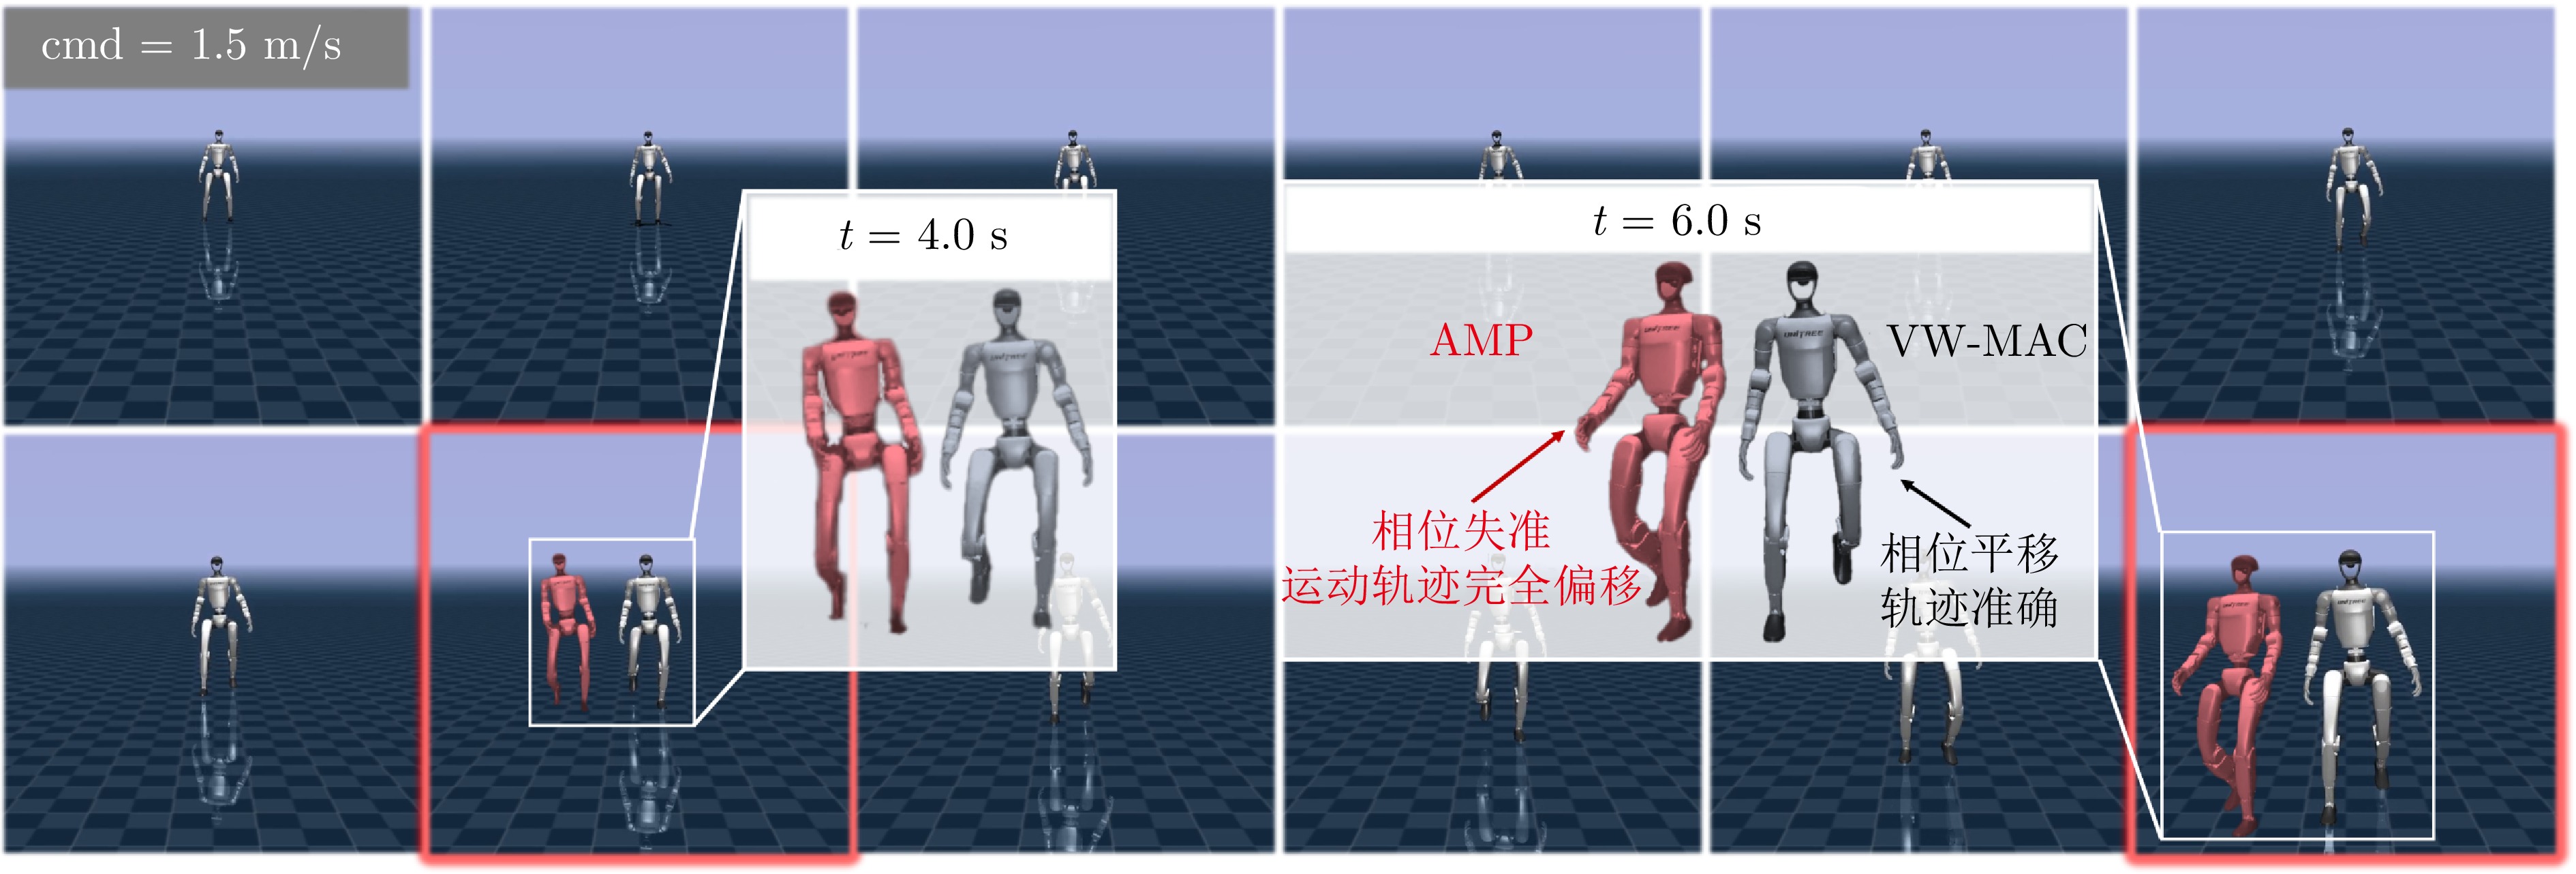
图 8 速度指令1.5 m/s下人形机器人行走关键帧切片
Fig. 8 Keyframe slices of humanoid robot walking at a 1.5 m/s velocity command
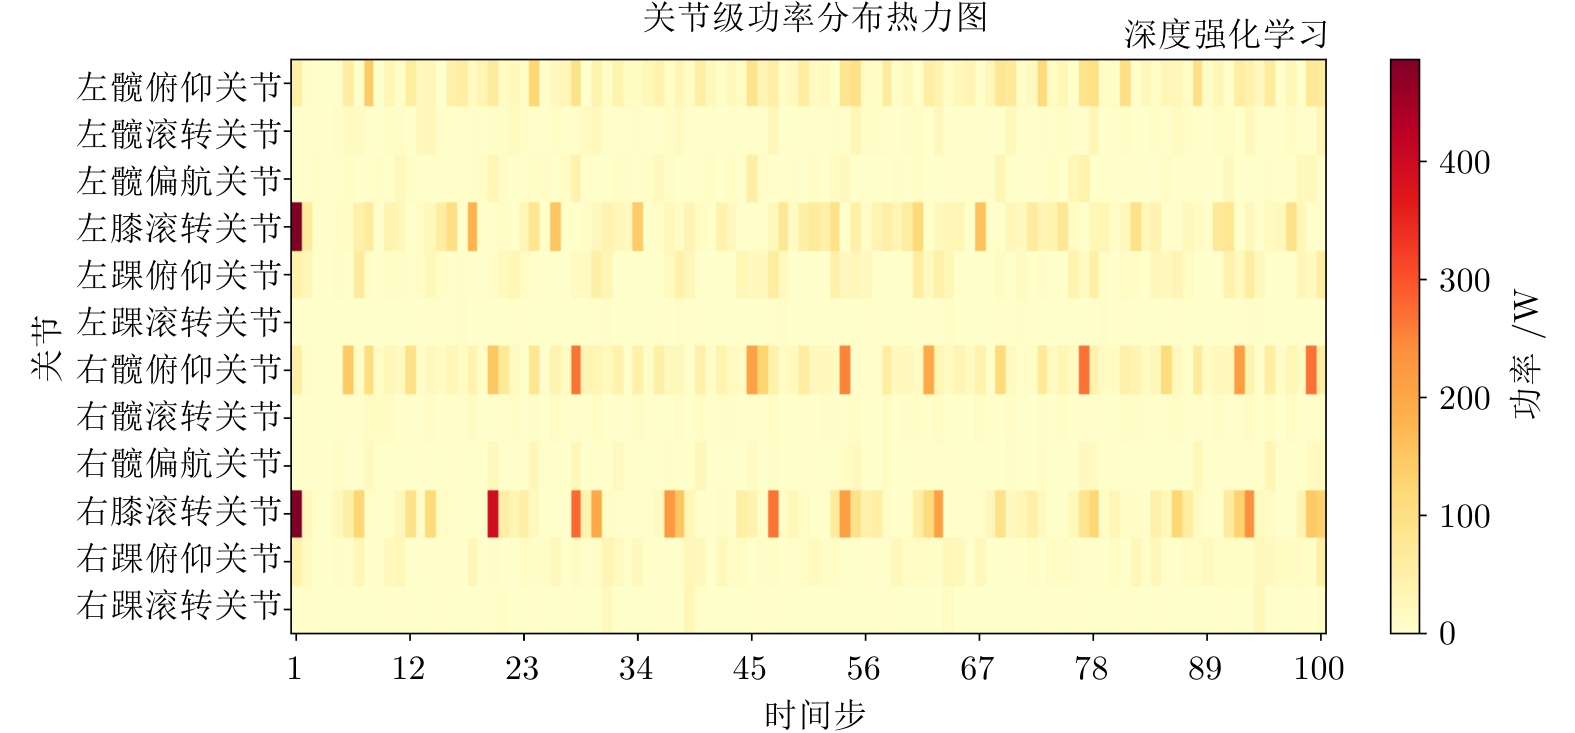
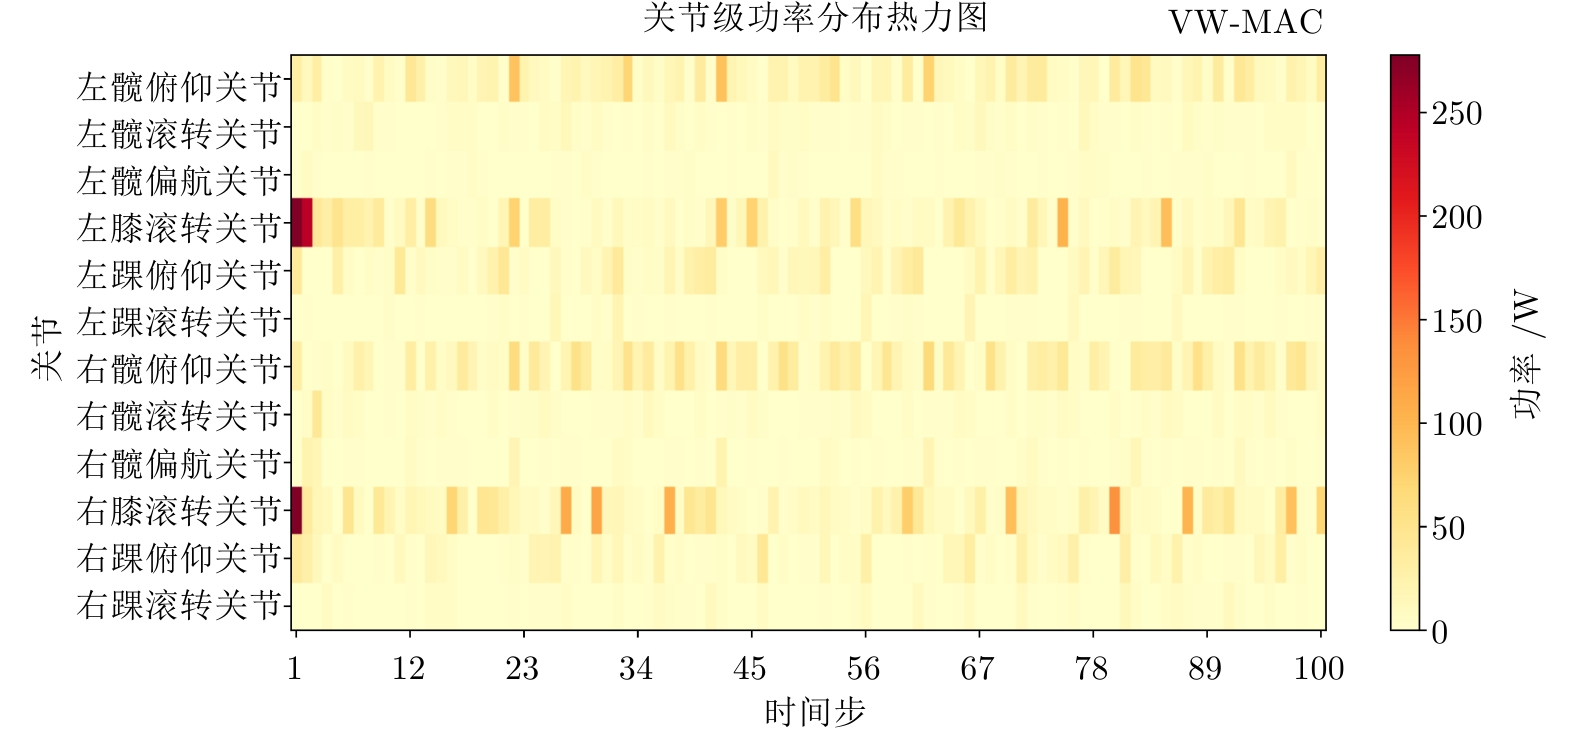
图 10 基于深度强化学习的关节能耗分布
Fig. 10 Joint power consumption distribution based on deep reinforcement learning
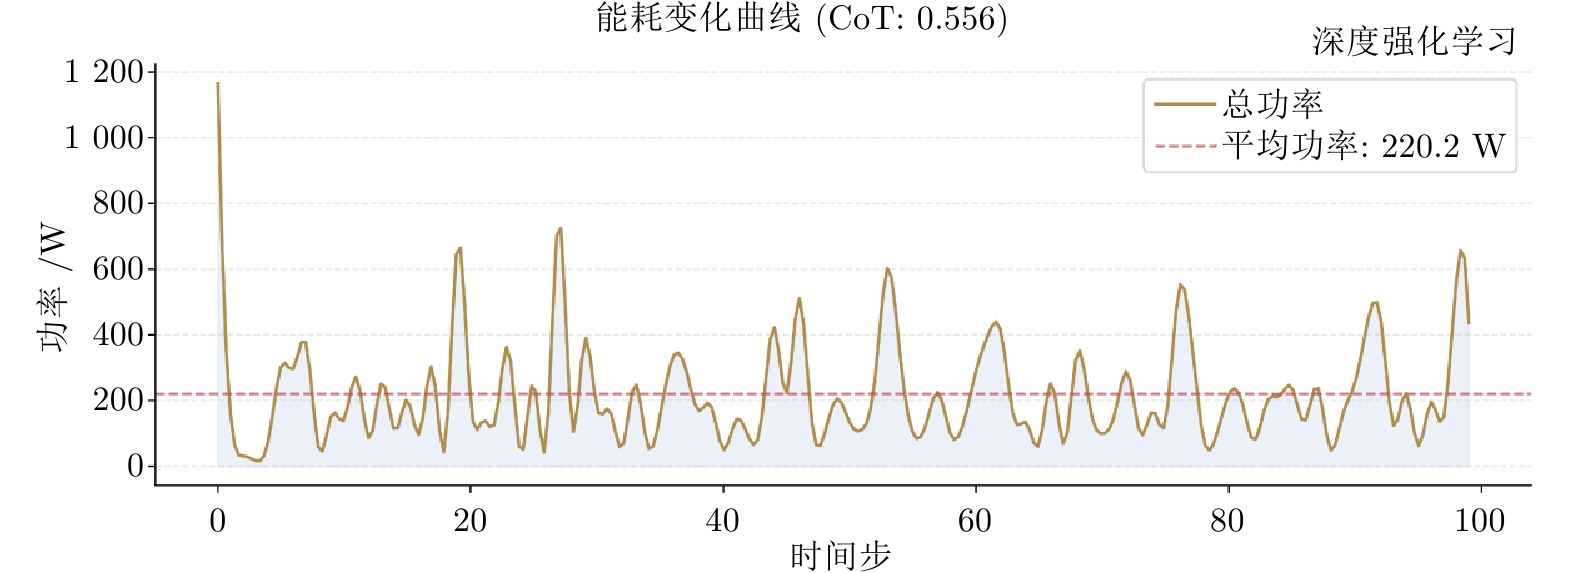
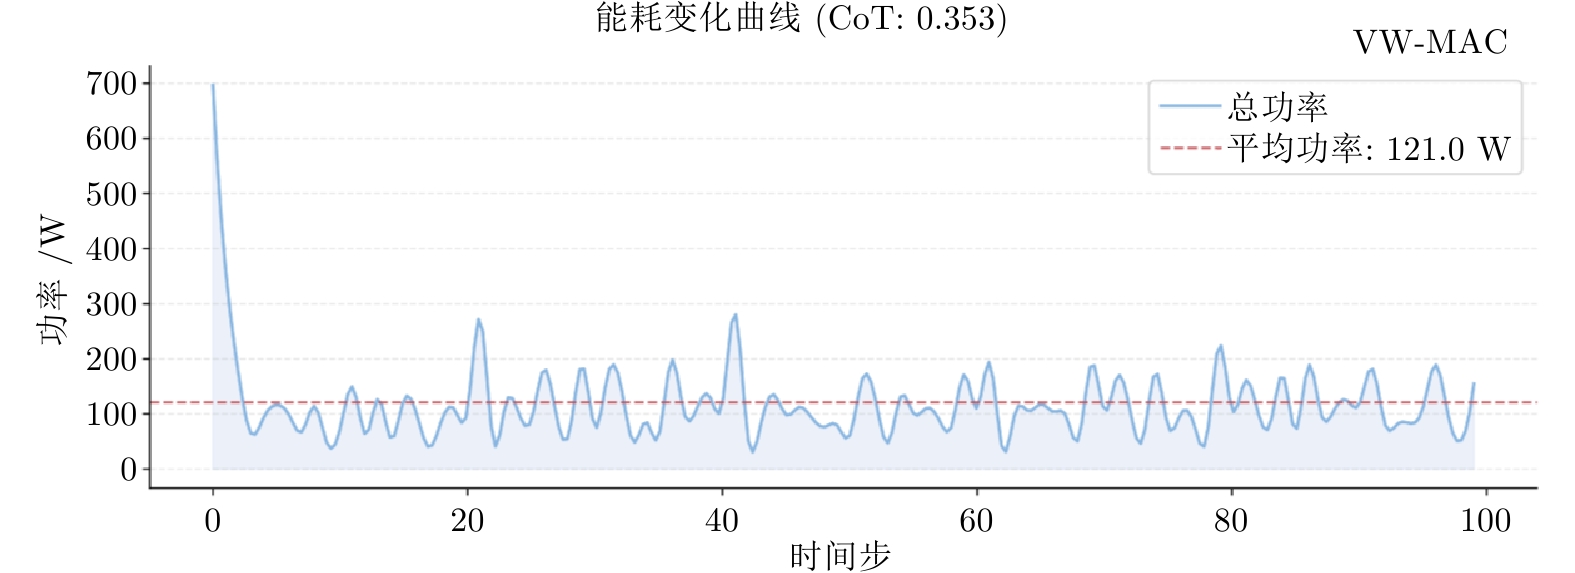
图 12 基于深度强化学习的总能耗
Fig. 12 Total power consumption based on deep reinforcement learning
表 1 AMP[30]与VW-MAC在人形机器人行走动作中的左右腿对称性误差对比 (rad)
Table 1 Comparison of left-right leg symmetry error between AMP[30] and VW-MAC during humanoid robot walking (rad)
有无可变融合机制 运动速度指令 算法 髋关节俯仰↓ 髋关节滚转↓ 髋关节偏航↓ 膝关节滚转↓ 踝关节俯仰↓ 踝关节滚转↓ 有可变融合机制 cmd = 0.5 m/s AMP 0.029943 0.038185 0.038442 0.167267 0.049829 0.064260 VW-MAC 0.008752 0.025621 0.025128 0.028924 0.016321 0.019843 cmd = 1.0 m/s AMP 0.006264 0.015836 0.024013 0.232104 0.248462 0.052555 VW-MAC 0.005491 0.014215 0.011845 0.119843 0.135621 0.048926 cmd = 1.5 m/s AMP 0.021222 0.029997 0.034885 0.241722 0.186154 0.067396 VW-MAC 0.019843 0.027621 0.032128 0.128924 0.175321 0.062843 无可变融合机制 cmd = 0.5 m/s AMP 0.013942 0.045621 0.048166 0.188946 0.065191 0.072661 VW-MAC 0.011667 0.041237 0.042465 0.178993 0.058221 0.068186 cmd = 1.0 m/s AMP 0.009331 0.022136 0.034272 0.262222 0.279343 0.074722 VW-MAC 0.008541 0.026443 0.031635 0.249911 0.266621 0.068837 cmd = 1.5 m/s AMP 0.029396 0.039741 0.052112 0.263180 0.211401 0.092015 VW-MAC 0.026962 0.035516 0.047535 0.257881 0.203851 0.082095  下载: 导出CSV
-
[1] Agravante D J, Cherubini A, Sherikov A, Wieber P-B, Kheddar A. Human-humanoid collaborative carrying. IEEE Transactions on Robotics, 2019, 35(4): 833−846 doi: 10.1109/TRO.2019.2914350 [2] Ding J, Santina C D, Lam T L, Pang J, Xiao X, Tsagarakis N G, et al. Robust humanoid locomotion via sequential stepping and angular momentum optimization. IEEE Transactions on Industrial Electronics, 2025, 72(3): 2779−2789 doi: 10.1109/TIE.2024.3433451 [3] 韩连强, 陈学超, 余张国, 高志发, 黄岩, 黄强. 面向离散地形的欠驱动双足机器人平衡控制方法. 自动化学报, 2022, 48(9): 2164−2174 doi: 10.16383/j.aas.c211008Han Lian-Qiang, Chen Xue-Chao, Yu Zhang-Guo, Gao Zhi-Fa, Huang Yan, Huang Qiang. Balance control of underactuated biped robot for discrete terrain. Acta Automatica Sinica, 2022, 48(9): 2164−2174 doi: 10.16383/j.aas.c211008 [4] Dallard A, Benallegue M, Scianca N, Kanehiro F, Kheddar A. Robust bipedal walking with closed-loop MPC: Adios stabilizers. IEEE Transactions on Robotics, 2025, 41: 4679−4698 doi: 10.1109/TRO.2025.3588452 [5] Kim M-J, Lim D, Park G, Lee K, Park J. A model predictive capture point control framework for robust humanoid balancing via ankle, hip, and stepping strategies. IEEE Transactions on Robotics, 2025, 41: 3297−3316 doi: 10.1109/TRO.2025.3567546 [6] 辛亚先, 李贻斌, 柴汇, 荣学文, 李彬. 基于全身力矩控制的双腿轮机器人跳跃方法研究. 自动化学报, 2023, 49(8): 1635−1644 doi: 10.16383/j.aas.c200486Xin Ya-Xian, Li Yi-Bin, Chai Hui, Rong Xue-Wen, Li Bin. Research on jumping method of two wheeled-leg robot based on whole-body torque control. Acta Automatica Sinica, 2023, 49(8): 1635−1644 doi: 10.16383/j.aas.c200486 [7] Li G, Ijspeert A, Hayashibe M. AI-CPG: Adaptive imitated central pattern generators for bipedal locomotion learned through reinforced reflex neural networks. IEEE Robotics and Automation Letters, 2024, 9(6): 5190−5197 doi: 10.1109/LRA.2024.3388842 [8] Tong Y, Liu H, Zhang Z. Advancements in humanoid robots: A comprehensive review and future prospects. IEEE/CAA Journal of Automatica Sinica, 2024, 11(2): 301−328 doi: 10.1109/JAS.2023.124140 [9] Zhang C, Bai J, Chen Z, Gao J, Qiao H. Hierarchical control for robust standing stability and fall recovery of task-performing humanoid robots. IEEE Transactions on Automation Science and Engineering, 2025, 22: 20920−20933 doi: 10.1109/TASE.2025.3608186 [10] 张楠杰, 陈玉全, 季茂沁, 孙运康, 王冰. 面向不同粗糙程度地面的四足机器人自适应控制方法. 自动化学报, 2025, 51(7): 1585−1598 doi: 10.16383/j.aas.c240738Zhang Nan-Jie, Chen Yu-Quan, Ji Mao-Qin, Sun Yun-Kang, Wang Bing. Adaptive control method for quadruped robot facing floors of different roughness. Acta Automatica Sinica, 2025, 51(7): 1585−1598 doi: 10.16383/j.aas.c240738 [11] 吴晓光, 刘绍维, 杨磊, 邓文强, 贾哲恒. 基于深度强化学习的双足机器人斜坡步态控制方法. 自动化学报, 2021, 47(8): 1976−1987 doi: 10.16383/j.aas.c190547Wu Xiao-Guang, Liu Shao-Wei, Yang Lei, Deng Wen-Qiang, Jia Zhe-Heng. A gait control method for biped robot on slope based on deep reinforcement learning. Acta Automatica Sinica, 2021, 47(8): 1976−1987 doi: 10.16383/j.aas.c190547 [12] Wu F, Nal X, Jang J, Zhu W, Gu Z, Wu A, et al. Learn to teach: Sample-efficient privileged learning for humanoid locomotion over real-world uneven terrain. IEEE Robotics and Automation Letters, 2025, 10(9): 9048−9055 doi: 10.1109/LRA.2025.3592131 [13] Rozlivek J, Roncone A, Pattacini U, Hoffmann M. Harmonious: Human-like reactive motion control and multimodal perception for humanoid robots. IEEE Transactions on Robotics, 2025, 41: 378−393 doi: 10.1109/TRO.2024.3502216 [14] Gu Z, Li J, Shen W, Yu W, Xie Z, McCrory S, et al. Humanoid locomotion and manipulation: Current progress and challenges in control, planning, and learning [Online], available: https://arxiv.org/abs/2501.02116, April 19, 2025 [15] Viceconte P M, Camoriano R, Romualdi G, Ferigo D, Dafarra S, Traversaro S, et al. Adherent: Learning human-like trajectory generators for whole-body control of humanoid robots. IEEE Robotics and Automation Letters, 2022, 7(2): 2779−2786 doi: 10.1109/LRA.2022.3141658 [16] Oh J, Sim O, Cho B, Lee K, Oh J-H. Online delayed reference generation for a humanoid imitating human walking motion. IEEE/ASME Transactions on Mechatronics, 2021, 26(1): 102−112 doi: 10.1109/tmech.2020.3002396 [17] Ji M, Peng X, Liu F, Li J, Yang G, Cheng X, et al. ExBody2: Advanced expressive humanoid whole-body control. In: Proceedings of the RSS 2025 Workshop on Whole-body Control and Bimanual Manipulation: Applications in Humanoids and Beyond. Los Angeles, USA: OpenReview.net, 2025. [18] Huang P, Hu Y, Nechyporenko N, Kim D, Talbott W, Zhang J. EMOTION: Expressive motion sequence generation for humanoid robots with in-context learning. IEEE Robotics and Automation Letters, 2025, 10(8): 7699−7706 doi: 10.1109/LRA.2025.3575983 [19] Wang Y, Li W, Togo S, Yokoi H, Jiang Y. Design of a 3-DOF coupled tendon-driven waist joint. In: Proceedings of the 2021 IEEE International Conference on Robotics and Automation (ICRA). Xi'an, China: IEEE, 2021. 7046–7051 [20] Tian Y, Su X, Shen C, Ma X. Exponentially extended dissipativity-based filtering of switched neural networks. Automatica, 2024, 161: Article No. 111465 doi: 10.1016/j.automatica.2023.111465 [21] Tian Y, Su X, Kwong S K, Shen C. A hybrid output feedback control scheme of Markovian jump systems via partly transition rates/probabilities design. Science China Information Sciences, 2026, 69(1): Article No. 112206 doi: 10.1007/s11432-024-4655-1 [22] Li Q, Meng F, Yu Z, Chen X, Huang Q. Dynamic torso compliance control for standing and walking balance of position-controlled humanoid robots. IEEE/ASME Transactions on Mechatronics, 2021, 26(2): 679−688 doi: 10.1109/TMECH.2021.3061825 [23] Prasad V, Heitlinger L, Koert D, Stock-Homburg R, Peters J, Chalvatzaki G. Learning multimodal latent dynamics for human-robot interaction. IEEE Transactions on Robotics, 2025, 41: 4418−4438 doi: 10.1109/TRO.2025.3582829 [24] Tang A, Hiraoka T, Hiraoka N, Shi F, Kawaharazuka K, Kojima K, et al. HumanMimic: Learning natural locomotion and transitions for humanoid robot via Wasserstein adversarial imitation. In: Proceedings of the 2024 IEEE International Conference on Robotics and Automation (ICRA). Yokohama, Japan: IEEE, 2024. 13107–13114 [25] Tazaki Y. Key pose-based dynamic humanoid motion generation using parallel multi-fidelity model predictive control. IEEE Robotics and Automation Letters, 2025, 10(12): 12979−12986 doi: 10.1109/LRA.2025.3625499 [26] Dong R, Chang Q, Er M J, Zhong J, Ikuno S. Motion capture-based robotic imitation: A keyframeless implementation method using multivariate empirical mode decomposition. IEEE/ASME Transactions on Mechatronics, 2025, 30(3): 1947−1958 doi: 10.1109/TMECH.2024.3440642 [27] Ju F, Jin H, Yin H, Liu J, Zhang X, Zhao M, et al. A joint-space humanoid robot torso motion planning method based on spiking neural networks. IEEE/ASME Transactions on Mechatronics, 2026, 31(2): 1377−1387 [28] Zambella G, Caporale D, Grioli G, Pallottino L, Bicchi A. Composite whole-body control of two-wheeled robots. IEEE Transactions on Robotics, 2025, 41: 2301−2321 doi: 10.1109/TRO.2025.3548494 [29] Beranek R, Karimi M, Ahmadi M. A behavior-based reinforcement learning approach to control walking bipedal robots under unknown disturbances. IEEE/ASME Transactions on Mechatronics, 2022, 27(5): 2710−2720 doi: 10.1109/TMECH.2021.3120628 [30] Peng X B, Ma Z, Abbeel P, Levine S, Kanazawa A. AMP: Adversarial motion priors for stylized physics-based character control. ACM Transactions on Graphics, 2021, 40(4): 1−20 -

 下载:

计量
- 文章访问数: 214
- HTML全文浏览量: 318
- PDF下载量: 2
- 被引次数: 0
