

Low-altitude Intelligence: From Low-altitude Foundation Models to 3D Parallel Intelligent Transportation Systems
-
摘要: 低空空域为无人系统提供了独特的感知、通信与机动优势, 在赋能交通、物流与农业等场景中展现出巨大潜力. 然而, 现阶段低空系统多依赖人工操控且应用分散. 随着低空系统向全天候、全时段、规模化运行演进, 节点与任务规模的扩张将显著提升系统复杂度, 进而对管控效率与运行自主性提出更高要求. 聚焦低空系统的管控智能与自主智能, 从低空感知、规划、协同与管控几方面系统梳理关键进展. 在此基础上, 进一步分析低空智能发展的关键瓶颈与未来方向. 面向自主智能, 提出低空基础大模型参考架构; 面向管控智能, 探讨立体智能交通背景下的平行管控思路, 从而为大规模低空系统的高效、安全运行提供统一技术参考.Abstract: Low-altitude airspace endows unmanned systems with distinctive advantages in sensing, communications, and maneuverability, unlocking substantial potential in transportation, logistics, agriculture, and other scenarios. However, current deployments largely rely on manual operation and remain fragmented. As operations progress toward all-weather, around-the-clock, and at-scale settings, growth in node and task counts will markedly increase system complexity, elevating requirements for governance efficiency and operational autonomy. Focusing on governance intelligence and autonomous intelligence for low-altitude systems, this paper systematically reviews key advances in perception, planning, coordination, and governance. On this basis, the major bottlenecks and future directions of low-altitude intelligence are further analyzed. From the perspective of autonomous intelligence, a reference architecture for low-altitude foundation models is proposed. From the perspective of management intelligence, a parallel management and control paradigm is discussed under the framework of 3D intelligent transportation. The overall analysis is intended to provide a unified technical reference for the efficient and safe operation of large-scale low-altitude systems.
-
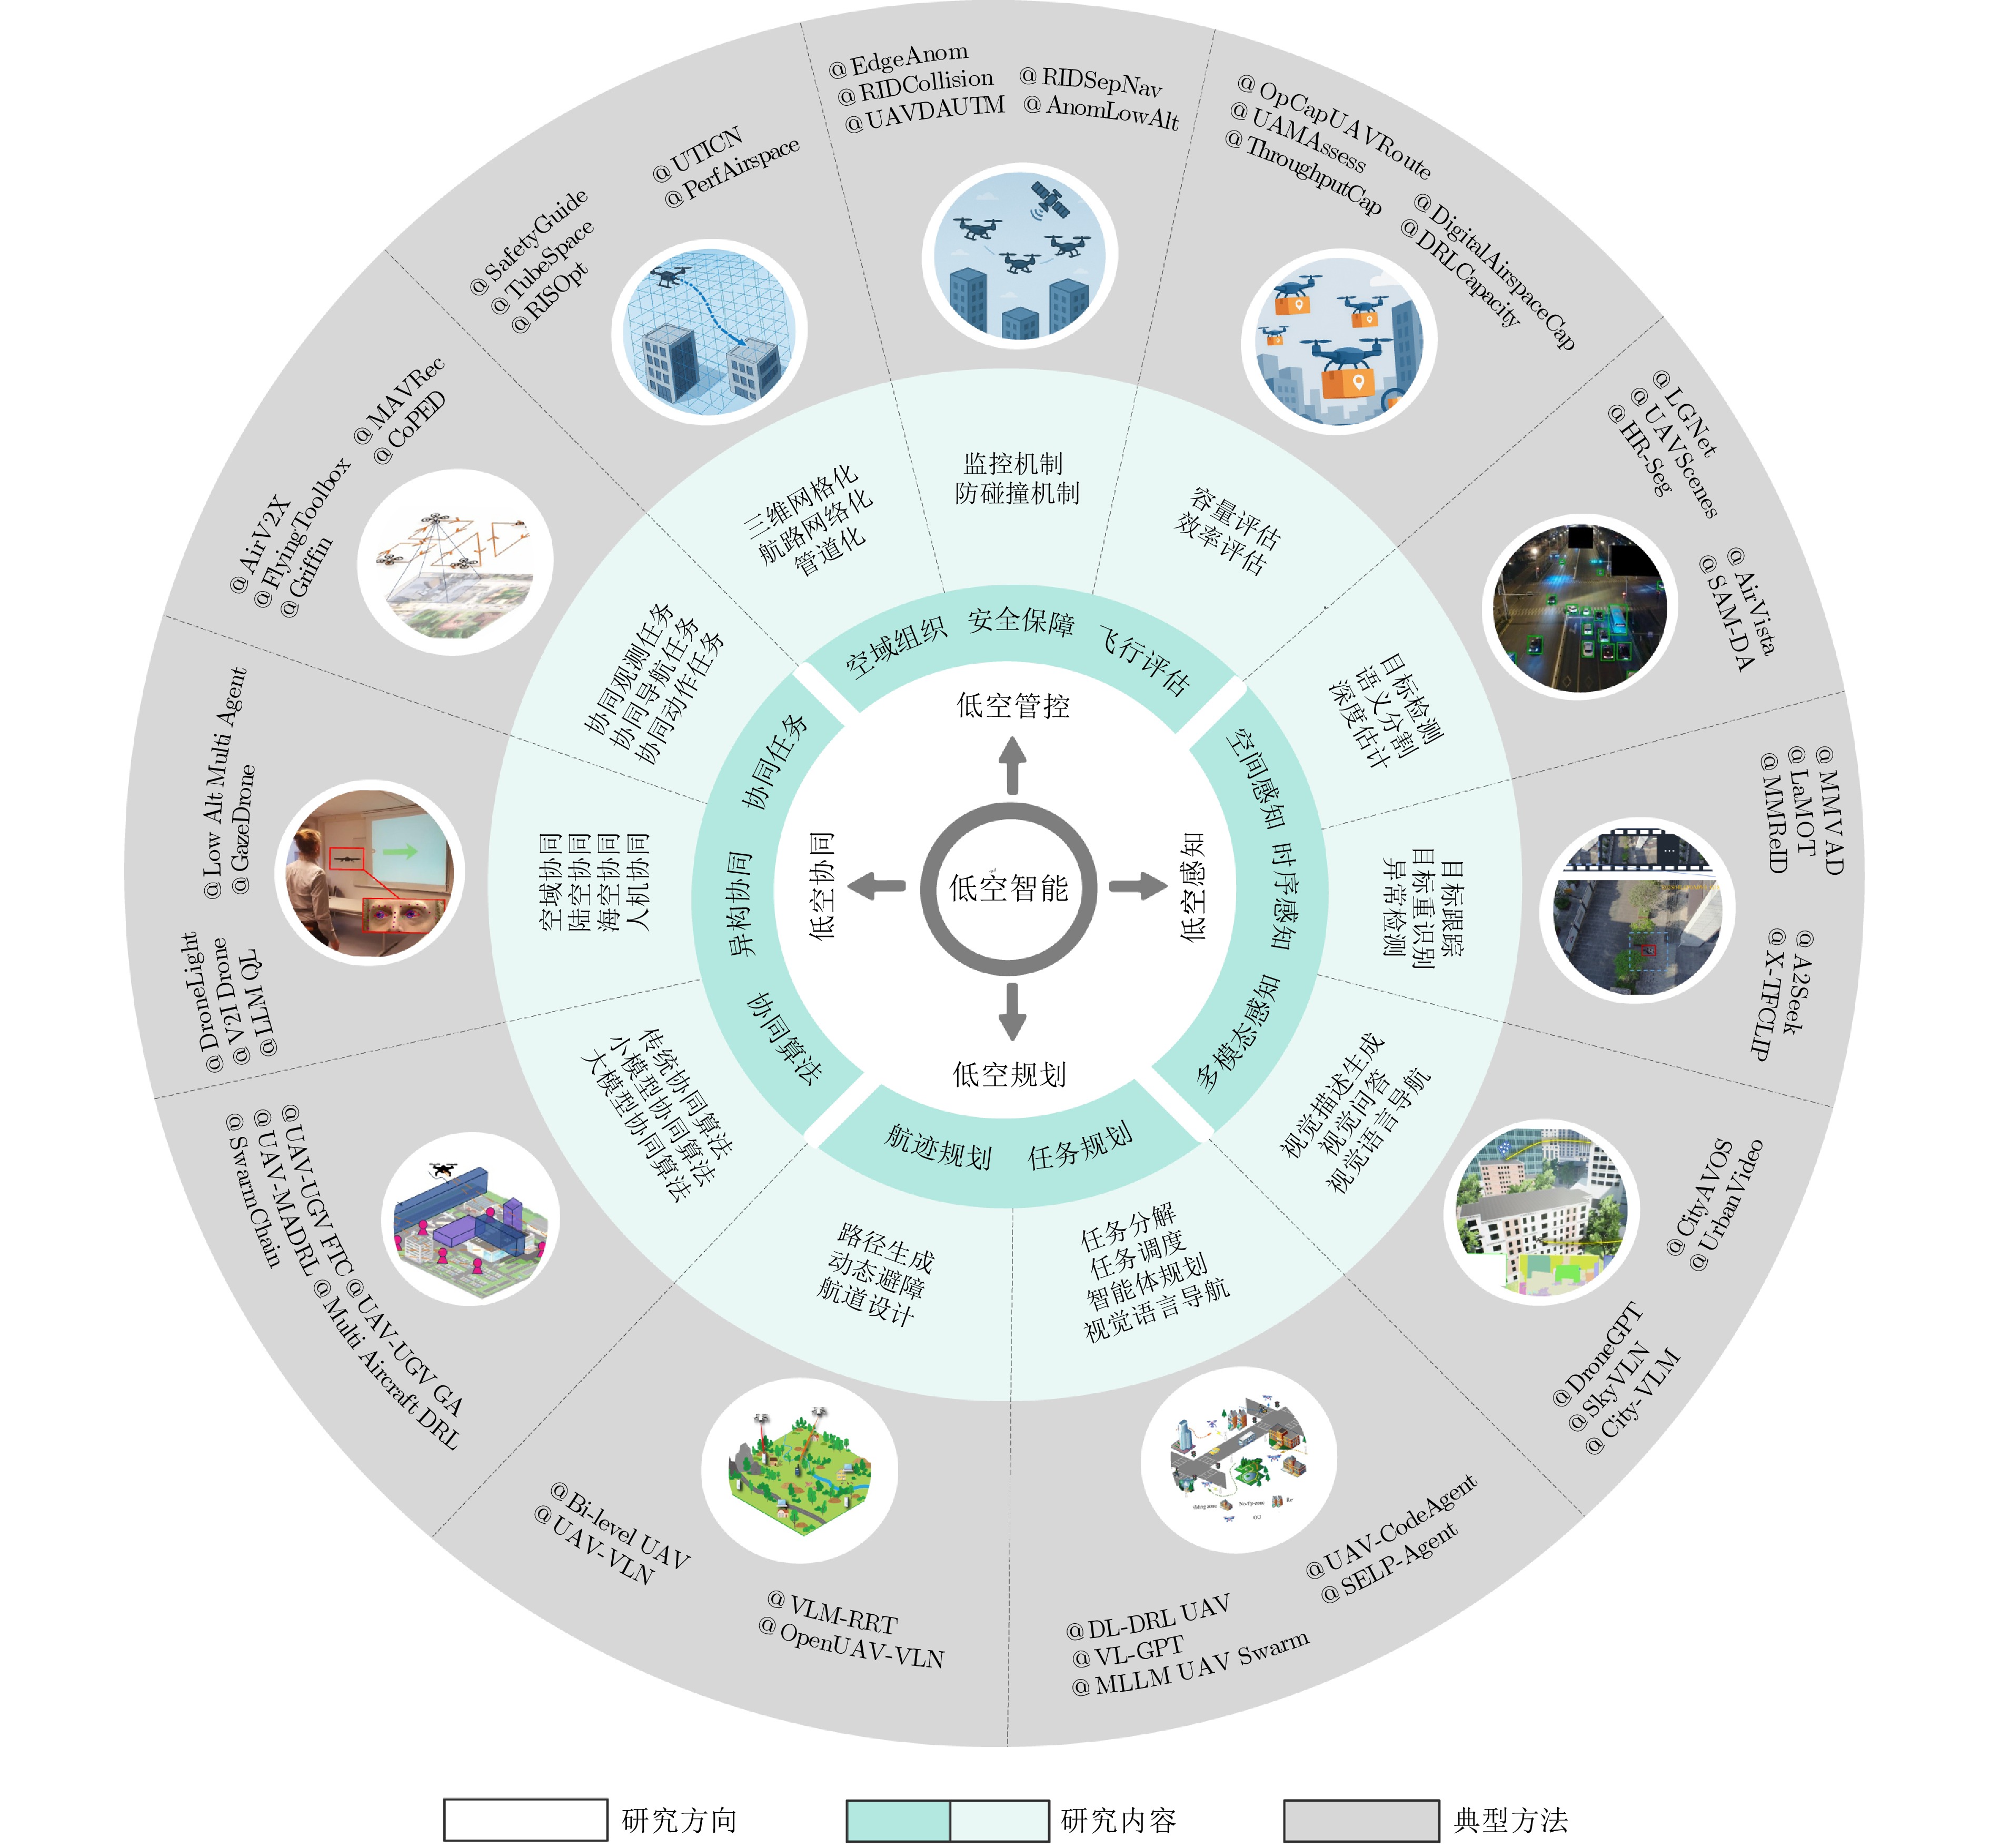
图 1 低空智能代表性任务及研究进展
注: 空域组织: SafetyGuide[22], TubeSpace[23], UTICN[24], PerfAirspace[25], RISOpt[26]; 安全保障: UAVDAUTM[27], RIDCollision[28], AnomLowAlt[29], EdgeAnom[30], RIDSepNav[31]; 飞行评估: ThroughputCap[32], UAVAccess[33], OpCapUAVRoute[34], DigitalAirspace[35], DRLCapacity[36]; 空间感知: LGNet[37], UAVScenes[38], HR-Seg[39], AirVista[40], SAM-DA[41]; 时序感知: MMVAD[42], LaMOT[1], A2Seek[43], MMReID[44], X-TFCLIP[45]; 多模态感知: DroneGPT[46], SkyVLN[47], CityAVOS[48], UrbanVideo[49], City-VLM[50]; 航迹规划: VLM-RRT[51], UAV-VLN[52], Bi-level UAV[53], OpenUAV-VLN[54]; 任务规划: DL-DRL UAV[55], VL-GPT[56], SELP-Agent[57], MLLM UAV Swarm[58], UAV-CodeAgent[59]; 协同算法: UAV-UGV FTC[60], UAV-UGV GA[61], UAV-MADRL[62], Multi Aircraft DRL[63], SwarmChain[64]; 异构协同: Low Alt Multi Agent[65], LLM-QL[66], V2I Drone[67], GazeDrone[68], DroneLight[69]; 协同任务: FlyingToolbox[70], Griffin[71], CoPED[72], AirV2X[73], MAVRec[74]
Fig. 1 Representative tasks and research advances in low-altitude intelligence
-
[1] Li Y, Liu X, Liu L, Fan H, Zhang L. LaMOT: language-guided multi-object tracking. In: Proceedings of 2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, GA, USA: IEEE, 2025. 6816-6822 DOI: 10.1109/icra55743.2025.11128553 [2] Wang Z, Cheng P, Chen M, Tian P, Wang Z, Li X, et al. Drones help drones: a collaborative framework for multi-drone object trajectory prediction and beyond. In: Proceedings of Advances in Neural Information Processing Systems 37. Vancouver, BC, Canada: Neural Information Processing Systems Foundation, Inc. (NeurIPS), 2024. 64604-64628 DOI: 10.52202/079017-2061 [3] Novák F, Báča T, Saska M. Collaborative object manipulation on the water surface by a UAV-USV team using tethers. In: Proceedings of 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Abu Dhabi, United Arab Emirates: IEEE, 2024. 3425-3432 DOI: 10.1109/iros58592.2024.10802469 [4] Zhang G, Liu Y, Yang X, Huang H, Huang C. TrafficNight: an aerial multimodal benchmark for nighttime vehicle surveillance. In: Proceedings of the European Conference on Computer Vision. Cham, Switzerland: Springer Nature Switzerland, 2024. 36-48. [5] Du D, Zhu P, Wen L, Bian X, Lin H, Hu Q, et al. VisDrone-DET2019: the vision meets drone object detection in image challenge results. In: Proceedings of the 2019 IEEE/CVF International Conference on Computer Vision Workshop (ICCVW). Seoul, Republic of Korea: IEEE, 2019. 213-226. DOI: 10.1109/ICCVW.2019.00030. [6] Florea H, Miclea V C, Nedevschi S. WildUAV: monocular UAV dataset for depth estimation tasks. In: Proceedings of 2021 IEEE 17th International Conference on Intelligent Computer Communication and Processing (ICCP). Cluj-Napoca, Romania: IEEE, 2021. 291-298 DOI: 10.1109/iccp53602.2021.9733671 [7] Liu S, Zhang H, Qi Y, Wang P, Zhang Y, Wu Q. AerialVLN: vision-and-language navigation for UAVs. In: Proceedings of 2023 IEEE/CVF International Conference on Computer Vision (ICCV). Paris, France: IEEE, 2023. 15338-15348 DOI: 10.1109/iccv51070.2023.01411 [8] Bogyrbayeva A, Meraliyev M, Mustakhov T, Dauletbayev B. Machine learning to solve vehicle routing problems: a survey. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(6): 4754−4772 doi: 10.1109/tits.2023.3334976 [9] Alqahtani H, Kumar G. Efficient routing strategies for electric and flying vehicles: a comprehensive hybrid metaheuristic review. IEEE Transactions on Intelligent Vehicles, 2024, 9(9): 5813−5852 doi: 10.1109/tiv.2024.3358872 [10] Guan X, Shi H, Xu D, Zhang B, Wei J, Chen J. The exploration and practice of low-altitude airspace flight service and traffic management in china. Green Energy and Intelligent Transportation, 2024, 3(2): Article No. 100149 doi: 10.1016/j.geits.2024.100149 [11] Butt M Z, Nasir N, A. Rashid R B. A review of perception sensors, techniques, and hardware architectures for autonomous low-altitude UAVs in non-cooperative local obstacle avoidance. Robotics and Autonomous Systems, 2024, 173: Article No. 104629 doi: 10.1016/j.robot.2024.104629 [12] Hu Y, Zheng S, Zhang Z, Wang S, Ye D, Wu M, et al. Leveraging LLMs in cloud-edge networks for traffic risk prediction and accident severity analysis. IEEE Transactions on Network Science and Engineering, 2026, 13: 438−453 doi: 10.1109/TNSE.2025.3584432 [13] Tian Y, Lin F, Zhang X, Ge J, Wang Y, Dai X, et al. LogisticsVISTA: 3D terminal delivery services with UAVs, UGVs and usvs based on foundation models and scenarios engineering. In: Proceedings of 2024 IEEE International Conference on Service Operations and Logistics, and Informatics (SOLI). Macau, China: IEEE, 2024. 2-7 DOI: 10.1109/soli63266.2024.10956119 [14] Zhang T, Tian Y, Lin F, Huang J, Süli P P, Ni Q, et al. CoordField: coordination field for agentic UAV task allocation in low-altitude urban scenarios. In: Proceedings of 2025 IEEE 28th International Conference on Intelligent Transportation Systems (ITSC). Gold Coast, Australia: IEEE, 2025. 4403-4408 DOI: 10.1109/itsc60802.2025.11423685 [15] Döschl B, Kiam J J. Say-REAPEx: An LLM-Modulo UAV online planning framework for search and rescue. In: 2nd CoRL Workshop on Learning Effective Abstractions for Planning. 2024. [16] 李庚松, 刘艺, 郑奇斌, 杨国利, 刘坤, 王强, 等. 无人机多传感器数据融合研究综述. 软件学报, 2025, 36(4): 1881−1905 doi: 10.13328/j.cnki.jos.007273Li Geng-Song, Liu Yi, Zheng Qi-Bin, Yang Guo-Li, Liu Kun, Wang Qiang, et al. Review on multi-sensor data fusion research for unmanned aerial vehicles. Journal of Software, 2025, 36(4): 1881−1905 doi: 10.13328/j.cnki.jos.007273 [17] 於志文, 孙卓, 程岳, 等. 智能无人机集群协同感知计算研究综述. 航空学报, 2024, 45(20): 630912 doi: 10.7527/S1000-6893.2024.30912Yu Zhi-Wen, Sun Zhuo, Cheng Yue, et al. A review of intelligent UAV swarm collaborative perception and computation. Acta Aeronautica et Astronautica Sinica, 2024, 45(20): 630912 doi: 10.7527/S1000-6893.2024.30912 [18] Zhou Y, Li J, Ou C, Yan D, Zhang H, Xue X. Open-Vocabulary object detection in UAV imagery: a review and future perspectives. Drones, 2025, 9(8): Article No. 557 doi: 10.3390/drones9080557 [19] Chen J, Wang Q, Cheng H H, Peng W, Xu W. A review of vision-based traffic semantic understanding in itss. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(11): 19954−19979 doi: 10.1109/tits.2022.3182410 [20] Kabore R, Kouassi A, N’goran R, Asseu O, Kermarrec Y, Lenca P. Review of anomaly detection systems in industrial control systems using deep feature learning approach. Engineering, 2021, 13(01): 30−44 doi: 10.4236/eng.2021.131003 [21] Peng W, Wang D, Yin Y, Cheng T. Multi-agent deep reinforcement learning-based truck-drone collaborative routing with dynamic emergency response. Transportation Research Part E: Logistics and Transportation Review, 2025, 195: Article No. 103974 doi: 10.1016/j.tre.2025.103974 [22] Wu P, Yang X, Wei P, Chen J. Safety assured online guidance with airborne separation for urban air mobility operations in uncertain environments. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(10): 19413−19427 doi: 10.1109/tits.2022.3163657 [23] Sarim M, Radmanesh M, Dechering M, Kumar M, Pragada R, Cohen K. Distributed detect-and-avoid for multiple unmanned aerial vehicles in national air space. Journal of Dynamic Systems, Measurement, and Control, 2019, 141(7). DOI: 10.1115/1.4043190 [24] Luo G, Li J, Zhang Q, Feng Z, Yuan Q, Lin Y, et al. Toward low-altitude airspace management and UAV operations: requirements, architecture and enabling technologies. IEEE Wireless Communications, 2026, 33(1): 45−55 doi: 10.1109/mwc.2025.3630114 [25] Pongsakornsathien N, Bijjahalli S, Gardi A, Symons A, Xi Y, Sabatini R, et al. A performance-based airspace model for unmanned aircraft systems traffic management. Aerospace, 2020, 7(11): Article No. 154 doi: 10.3390/aerospace7110154 [26] Xiong K, Leng S, Chen L, Zhang D, Huang C, Yuen C. RIS-Aided trajectory optimization in layered urban air mobility. IEEE Internet of Things Journal, 2025, 12(2): 2188−2202 doi: 10.1109/jiot.2024.3468888 [27] Lin C E, Shao P C, Bai J Y, Lin Y Y, Bui H T. UAV detect and avoid from utm-dependent surveillance. International Journal of Aerospace Engineering, 2024, 2024: 1−22 doi: 10.1155/2024/7328971 [28] JIA Z, ZHU Y, WU Q, WU Y, ZHANG L, YANG S, et al. Remote id based UAV collision avoidance optimization for low-altitude airspace safety. Chinese Journal of Aeronautics, 2025Article No. 103841 doi: 10.1016/j.cja.2025.103841 [29] Bozcan I, Kayacan E. Context-dependent anomaly detection for low altitude traffic surveillance. In: 2021 IEEE International Conference on Robotics and Automation (ICRA). IEEE, 2021: 224-230. [30] Patrikar D R, Parate M R. Anomaly detection using edge computing in video surveillance system: review. International Journal of Multimedia Information Retrieval, 2022, 11(2): 85−110 doi: 10.1007/s13735-022-00227-8 [31] Vinogradov E, Sai Bhargav Kumar A V S, Minucci F, Pollin S, Natalizio E. Remote id for separation provision and multi-agent navigation. In: Proceedings of 2023 IEEE/AIAA 42nd Digital Avionics Systems Conference (DASC). Barcelona, Spain: IEEE, 2023. 1-10 DOI: 10.1109/dasc58513.2023.10311133 [32] Bulusu V, Sengupta R, Mueller E R, Xue M. A throughput based capacity metric for low-altitude airspace. In: Proceedings of 2018 Aviation Technology, Integration, and Operations Conference. Atlanta, Georgia: American Institute of Aeronautics and Astronautics, 2018. DOI: 10.2514/6.2018-3032 [33] Abdellaoui R, Naser F, Velieva A, Peinecke N, Moolchandani K, Lee C H, et al. Applying a comparative performance assessment framework to different airspace management concepts for urban air mobility. CEAS Aeronautical Journal, 2025, 16(3): 827−847 doi: 10.1007/s13272-025-00835-0 [34] Yi J, Zhang H, Wang F, Wang D. An operational capacity assessment method for an urban low-altitude unmanned aerial vehicle logistics route network. Drones, 2023, 7(9): Article No. 582 doi: 10.3390/drones7090582 [35] Feng O, Zhang H, Tang W, Liu X. Digital low-altitude airspace unmanned aerial vehicle path planning and operational capacity assessment in urban risk environments. Drones, 2025, 9(5): Article No. 320 doi: 10.3390/drones9050320 [36] Mehditabrizi A, Samadzad M, Sabzekar S. A deep reinforcement learning approach to assess the low-altitude airspace capacity for urban air mobility. arXiv preprint arXiv: 2301.09758, 2023. [37] Liu J, Cui J, Ye M, Zhu X, Tang S. Shooting condition insensitive unmanned aerial vehicle object detection. Expert Systems with Applications, 2024, 246: Article No. 123221 doi: 10.1016/j.eswa.2024.123221 [38] Wang S, Li S, Zhang Y, Yu S, Yuan S, She R, et al. UAVScenes: a multi-modal dataset for UAVs. In: Proceedings of 2025 IEEE/CVF International Conference on Computer Vision (ICCV). Honolulu, HI, USA: IEEE, 2025. 28946-28958 DOI: 10.1109/iccv51701.2025.02688 [39] Chen Z, Xie Y, Wei Y. Toward high-resolution UAV imagery open-vocabulary semantic segmentation. Drones, 2025, 9(7): Article No. 470 doi: 10.3390/drones9070470 [40] Lin F, Tian Y, Wang Y, Zhang T, Zhang X, Wang F Y. AirVista: empowering UAVs with 3D spatial reasoning abilities through a multimodal large language model agent. In: Proceedings of 2024 IEEE 27th International Conference on Intelligent Transportation Systems (ITSC). Edmonton, AB, Canada: IEEE, 2024. 476-481 DOI: 10.1109/itsc58415.2024.10919532 [41] Fu C, Yao L, Zuo H, Zheng G, Pan J. SAM-DA: UAV tracks anything at night with sam-powered domain adaptation. In: Proceedings of 2024 International Conference on Advanced Robotics and Mechatronics (ICARM). Tokyo, Japan: IEEE, 2024. 31-38 DOI: 10.1109/icarm62033.2024.10715901 [42] Biswas D, Tesic J. MMVAD: a vision-language model for cross-domain video anomaly detection with contrastive learning and scale-adaptive frame segmentation. Expert Systems with Applications, 2025, 285: Article No. 127857 doi: 10.1016/j.eswa.2025.127857 [43] Mo M, Tong X, Tan M, Leng J, Zheng J, Liu Y, et al. A2Seek: towards reasoning-centric benchmark for aerial anomaly understanding. In: Proceedings of Advances in Neural Information Processing Systems 38. San Diego, California, USA and Mexico City, Mexico: Neural Information Processing Systems Foundation, Inc. (NeurIPS), 2025. 167887-167920 DOI: 10.52202/085713-5057 [44] Li J, Chen Z, Deng L, Wang C, Zhai G. MMReID-Bench: unleashing the power of MLLMs for effective and versatile person re-identification. arXiv preprint arXiv: 2508.06908, 2025. [45] Nguyen K, Fookes C, Sridharan S, Nguyen H, Liu F, Liu X, et al. AG-VPReID 2025: aerial-ground video-based person re-identification challenge results. In: Proceedings of 2025 IEEE International Joint Conference on Biometrics (IJCB). Osaka, Japan: IEEE, 2025. 1-10 DOI: 10.1109/ijcb65343.2025.11410726 [46] Qiu H, Li J, Gan J, Zheng S, Yan L. DroneGPT: zero-shot video question answering for drones. In: Proceedings of the International Conference on Computer Vision and Deep Learning. Changsha China: ACM, 2024. 1-6 DOI: 10.1145/3653804.3654608 [47] Li T, Huai T, Li Z, Gao Y, Li H, Zheng X. SkyVLN: vision-and-language navigation and NMPC control for UAVs in urban environments. In: Proceedings of 2025 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Hangzhou, China: IEEE, 2025. 17199-17206 DOI: 10.1109/iros60139.2025.11247609 [48] Ji Y, Zhu Z, Zhao Y, Liu B, Gao C, Zhao Y, et al. Towards autonomous UAV visual object search in city space: benchmark and agentic methodology. Proceedings of the AAAI Conference on Artificial Intelligence, 2026, 40(22): 18342−18350 doi: 10.1609/aaai.v40i22.38898 [49] Zhao B, Fang J, Dai Z, Wang Z, Zha J, Zhang W, et al. UrbanVideo-Bench: benchmarking vision-language models on embodied intelligence with video data in urban spaces. In: Proceedings of the 63rd Annual Meeting of the Association for Computational Linguistics (Volume 1: Long Papers). Vienna, Austria: Association for Computational Linguistics, 2025. 32400-32423 DOI: 10.18653/v1/2025.acl-long.1558 [50] Sun P, Song Y, Zhu X, Liu X, Wang Q, Liu Y, et al. City-VLM: towards multidomain perception scene understanding via multimodal incomplete learning. In: Proceedings of the 33rd ACM International Conference on Multimedia. Dublin Ireland: ACM, 2025. 3448-3457 DOI: 10.1145/3746027.3755088 [51] Ye J, Papaioannou S, Kolios P. VLM-RRT: vision language model guided RRT search for autonomous UAV navigation. In: Proceedings of 2025 International Conference on Unmanned Aircraft Systems (ICUAS). Charlotte, NC, USA: IEEE, 2025. 633-640 DOI: 10.1109/icuas65942.2025.11007837 [52] Saxena P, Raghuvanshi N, Goveas N. UAV-VLN: end-to-end vision language guided navigation for UAVs. In: Proceedings of 2025 European Conference on Mobile Robots (ECMR). Padova, Italy: IEEE, 2025. 1-6 DOI: 10.1109/ecmr65884.2025.11163198 [53] Li B, Wang S, Ge C, Fan Q, Temuer C. Bi-level intelligent dynamic path planning for an UAV in low-altitude complex urban environment. Transactions of the Institute of Measurement and Control, 2023, 46(1): 39−57 doi: 10.1177/01423312231167200 [54] Wang X, Yang D, Wang Z, Kwan H, Chen J, Wu W, et al. Towards realistic UAV vision-language navigation: platform, benchmark, and methodology. In: Proceedings of the International Conference on Learning Representations. Singapore, 2025. [55] Gong Y, Fan J, Zhang R, Niyato D, Yao Y, Chang X. Safe and economical UAV trajectory planning in low-altitude airspace: a hybrid DRL-LLM algorithm with compliance awareness. IEEE Transactions on Mobile Computing, 2026, 25(8): 12041−12057 doi: 10.1109/tmc.2026.3668209 [56] Zhu, Jinguo, Ding, Xiaohan, Ge, Yixiao, Ge, Yuying, Zhao, Sijie, Zhao, Hengshuang, Wang, Xiaohua, and Shan, Ying. ``VL-GPT: A Generative Pre-trained Transformer for Vision and Language Understanding and Generation.'' arXiv preprint arXiv: 2312.09251, 2023. [57] Wu Y, Xiong Z, Hu Y, Iyengar S S, Jiang N, Bera A, et al. SELP: generating safe and efficient task plans for robot agents with large language models. In: Proceedings of 2025 IEEE International Conference on Robotics and Automation (ICRA). Atlanta, GA, USA: IEEE, 2025. 2599-2605 DOI: 10.1109/icra55743.2025.11128420 [58] Liu J, Li H, Chai C, Chen K, Wang D. A llm-informed multi-agent ai system for drone-based visual inspection for infrastructure. Advanced Engineering Informatics, 2025, 68: Article No. 103643 doi: 10.1016/j.aei.2025.103643 [59] Sautenkov, Oleg, Yaqoot, Yasheerah, Mustafa, Muhammad Ahsan, et al. Uav-codeagents: Scalable uav mission planning via multi-agent react and vision-language reasoning, arXiv preprint arXiv: 2505.07236, 2025. [60] 马亚杰, 王娟, 姜斌, 龚建业. 一种无人机-无人车编队系统容错控制方法. 航空学报, 2023, 44(8): 327216 doi: 10.7527/S1000-6893.2022.27216Ma Ya-Jie, Wang Juan, Jiang Bin, Gong Jian-Ye. A fault-tolerant control scheme for UAVs-UGVs formation systems. Acta Aeronautica et Astronautica Sinica, 2023, 44(8): 327216 doi: 10.7527/S1000-6893.2022.27216 [61] 陶灿灿, 韩旭, 周锐. 基于DTC和遗传算法的无人机-无人车任务规划方法. 无线电通信技术, 2022, 48(6): 1019−1026 doi: 10.3969/j.issn.1003-3114.2022.06.008Tao Can-Can, Han Xu, Zhou Rui. Mission planning of UAV-UGV based on DTC and genetic algorithm. Radio Communications Technology, 2022, 48(6): 1019−1026 doi: 10.3969/j.issn.1003-3114.2022.06.008 [62] Ding R, Xu Y, Gao F, Shen X. Trajectory design and access control for air-ground coordinated communications system with multiagent deep reinforcement learning. IEEE Internet of Things Journal, 2022, 9(8): 5785−5798 doi: 10.1109/jiot.2021.3062091 [63] 施伟, 冯旸, 程光权, 黄海心, 黄剑, 刘忠, 等. 基于深度强化学习的多机协同空战方法研究. 自动化学报, 2021, 47(7): 1610−1623 doi: 10.16383/j.aas.c201059Shi Wei, Feng Yang, Cheng Guang-Quan, Huang Hai-Xin, Huang Jian, Liu Zhong, et al. Research on multi-aircraft cooperative air combat method based on deep reinforcement learning. Acta Automatica Sinica, 2021, 47(7): 1610−1623 doi: 10.16383/j.aas.c201059 [64] Han B, Chen Y, Li J, Li J, Su J. SwarmChain: collaborative LLM inference for UAV swarm control. IEEE Internet of Things Magazine, 2025, 8(5): 64−71 doi: 10.1109/miot.2025.3575886 [65] 冯斯梦, 张云弈, 刘凯, 李宝龙, 董超, 张磊, 等. 低空混合障碍下无人机协同多智能体航迹规划. 电子与信息学报, 2025, 47(5): 1291−1300 doi: 10.11999/JEIT250012Feng Si-Meng, Zhang Yun-Yi, Liu Kai, Li Bao-Long, Dong Chao, Zhang Lei, et al. Collaborative multi-agent trajectory optimization for unmanned aerial vehicles under low-altitude mixed-obstacle airspace. Journal of Electronics and Information Technology, 2025, 47(5): 1291−1300 doi: 10.11999/JEIT250012 [66] Zhou Q, Wu J, Zhu M, Zhou Y, Xiao F, Zhang Y. LLM-QL: a llm-enhanced q-learning approach for scheduling multiple parallel drones. IEEE Transactions on Knowledge and Data Engineering, 2025, 37(9): 5393−5406 doi: 10.1109/tkde.2025.3579386 [67] 于静茹, 姚升悦, 陈喜群, 林懿伦, 王飞跃. 面向网联自动驾驶部署的车-路-无人机跨域协同技术. 中国图象图形学报, 2024, 29(11): 3293−3304 doi: 10.11834/jig.230786Yu Jing-Ru, Yao Sheng-Yue, Chen Xi-Qun, Lin Yi-Lun, Wang Fei-Yue. Cross-domain collaborative technology among vehicles, infrastructure, and drones for connected and autonomous driving deployment. Journal of Image and Graphics, 2024, 29(11): 3293−3304 doi: 10.11834/jig.230786 [68] Khamis M, Kienle A, Alt F, Bulling A. GazeDrone: mobile eye-based interaction in public space without augmenting the user. In: Proceedings of the 4th ACM Workshop on Micro Aerial Vehicle Networks, Systems, and Applications. Munich, Germany: ACM, 2018. 66-71. DOI: 10.1145/3213526.3213539 [69] Ibrahimov R, Zherdev N, Tsetserukou D. DroneLight: drone draws in the air using long exposure light painting and ml. In: Proceedings of 2020 29th IEEE International Conference on Robot and Human Interactive Communication (RO-MAN). Naples, Italy: IEEE, 2020. DOI: 10.1109/ro-man47096.2020.9223601 [70] Cao H, Shen J, Zhang Y, Fu Z, Liu C, Sun S, et al. Proximal cooperative aerial manipulation with vertically stacked drones. Nature, 2025, 646(8085): 576−583 doi: 10.1038/s41586-025-09575-x [71] Wang J, Cao X, Zhong J, Zhang Y, Han Z, Yu H, et al. Griffin: aerial-ground cooperative detection and tracking dataset and benchmark. Proceedings of the AAAI Conference on Artificial Intelligence, 2026, 40(12): 9867−9875 doi: 10.1609/aaai.v40i12.37951 [72] Zhou Y, Quang L, Nieto-Granda C, Loianno G. CoPeD-Advancing multi-robot collaborative perception: a comprehensive dataset in real-world environments. IEEE Robotics and Automation Letters, 2024, 9(7): 6416−6423 doi: 10.1109/lra.2024.3406207 [73] Gao X, Wu Y, Yang F, et al. Airv2x: Unified air-ground vehicle-to-everything collaboration. arXiv preprint arXiv: 2506.19283, 2025. [74] Dutta A, Das S, Nielsen J, Chakraborty R, Shah M. Multiview aerial visual recognition (MAVREC): can multi-view improve aerial visual perception?. In: Proceedings of 2024 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Seattle, WA, USA: IEEE, 2024. 22678-22690 DOI: 10.1109/cvpr52733.2024.02140 [75] Lee U J, Ahn S J, Choi D Y, Chin S M, Jang D S. Airspace designs and operations for UAS traffic management at low altitude. Aerospace, 2023, 10(9): Article No. 737 doi: 10.3390/aerospace10090737 [76] Belwafi K, Alkadi R, Alameri S A, Hamadi H A, Shoufan A. Unmanned aerial vehicles’ remote identification: a tutorial and survey. IEEE Access, 2022, 10: 87577−87601 doi: 10.1109/access.2022.3199909 [77] Saeed Z, Yousaf M H, Ahmed R, Velastin S A, Viriri S. On-Board small-scale object detection for unmanned aerial vehicles (UAVs). Drones, 2023, 7(5): Article No. 310 doi: 10.3390/drones7050310 [78] Huang S, Zhang H, Huang Z. Multi-UAV collision avoidance using multi-agent reinforcement learning with counterfactual credit assignment. arXiv preprint arXiv: 2204.08594, 2022. [79] Zhong G, Liu Y, Du S, Wang F, Zhou J, Zhang H. 3D rvo-enhanced multi-agent deep reinforcement learning for collision avoidance in urban structured airspace. Aerospace Science and Technology, 2025, 164: Article No. 110378 doi: 10.1016/j.ast.2025.110378 [80] Yang J, Jia N, Liu X, Fan R, Sun Y, Zhao W. Zone-YOLO: vision-language object detection using zone prompt. IEEE Transactions on Intelligent Transportation Systems, 2025, 26(10): 17510−17521 doi: 10.1109/tits.2024.3510117 [81] Zhou W, Zheng N, Wang C. Synthesizing realistic traffic events from UAV perspectives: a mask-guided generative approach based on style-modulated transformer. IEEE Transactions on Intelligent Vehicles, 2025, 10(11): 5008−5022 doi: 10.1109/tiv.2024.3510563 [82] Shang L, Min C, Wang J, Xiao L, Zhao D, Nie Y. Aerial-Ground cross-view vehicle re-identification: a benchmark dataset and baseline. Remote Sensing, 2025, 17(15): Article No. 2653 doi: 10.3390/rs17152653 [83] Sakaino H. Refined and enriched physics-based captions for unseen dynamic changes. In: Proceedings of the Workshop on New Frontiers in Adversarial Machine Learning at the International Conference on Machine Learning. Honolulu, USA, 2023. [84] Sun N, Zhao J, Shi Q, Liu C, Liu P. Moving target tracking by unmanned aerial vehicle: a survey and taxonomy. IEEE Transactions on Industrial Informatics, 2024, 20(5): 7056−7068 doi: 10.1109/tii.2024.3363084 [85] Sun W, Dai L, Zhang X, Chang P, He X. RSOD: real-time small object detection algorithm in uav-based traffic monitoring. Applied Intelligence, 2021, 52(8): 8448−8463 doi: 10.1007/s10489-021-02893-3 [86] Radford A, Kim J W, Hallacy C, Ramesh A, Goh G, Agarwal S, et al. Learning transferable visual models from natural language supervision. In: Proceedings of the 38th International Conference on Machine Learning. PMLR, 2021. 8748-8763. [87] Liu S, Zeng Z, Ren T, Li F, Zhang H, Yang J, et al. Grounding DINO: marrying DINO with grounded pre-training for open-set object detection. In: Proceedings of the European Conference on Computer Vision. Cham, Switzerland: Springer Nature Switzerland, 2024. 38-55. [88] Ultralytics. Ultralytics YOLOv8 official documentation and GitHub[Online]. Available: https://docs.ultralytics.com/models/yolov8/, 2023-01-10. [89] Li Y, Guo W, Yang X, Liao N, He D, Zhou J, et al. Toward open vocabulary aerial object detection with clip-activated student-teacher learning. In: Proceedings of Lecture Notes in Computer Science. Springer Nature Switzerland, 2024. 431-448. DOI: 10.1007/978-3-031-73016-0_25 [90] Pan J, Liu Y, Fu Y, Ma M, Li J, Paudel D P, et al. Locate anything on earth: advancing open-vocabulary object detection for remote sensing community. Proceedings of the AAAI Conference on Artificial Intelligence, 2025, 39(6): 6281−6289 doi: 10.1609/aaai.v39i6.32672 [91] Bisio I, Garibotto C, Haleem H, Lavagetto F, Sciarrone A. Traffic analysis through deep-learning-based image segmentation from UAV streaming. IEEE Internet of Things Journal, 2023, 10(7): 6059−6073 doi: 10.1109/jiot.2022.3223283 [92] Lyu Y, Vosselman G, Xia G S, Yilmaz A, Yang M Y. UAVid: a semantic segmentation dataset for UAV imagery. ISPRS Journal of Photogrammetry and Remote Sensing, 2020, 165: 108−119 doi: 10.1016/j.isprsjprs.2020.05.009 [93] Wang L, Li R, Zhang C, Fang S, Duan C, Meng X, et al. UNetFormer: a unet-like transformer for efficient semantic segmentation of remote sensing urban scene imagery. ISPRS Journal of Photogrammetry and Remote Sensing, 2022, 190: 196−214 doi: 10.1016/j.isprsjprs.2022.06.008 [94] Kirillov A, Mintun E, Ravi N, Mao H, Rolland C, Gustafson L, et al. Segment anything. In: Proceedings of 2023 IEEE/CVF International Conference on Computer Vision (ICCV). Paris, France: IEEE, 2023. 3992-4003 DOI: 10.1109/iccv51070.2023.00371 [95] Dong X, Garratt M A, Anavatti S G, Abbass H A. Towards real-time monocular depth estimation for robotics: a survey. IEEE Transactions on Intelligent Transportation Systems, 2022, 23(10): 16940−16961 doi: 10.1109/tits.2022.3160741 [96] Miclea V C, Nedevschi S. Monocular depth estimation with improved long-range accuracy for UAV environment perception. IEEE Transactions on Geoscience and Remote Sensing, 2022, 60: 1−15 doi: 10.1109/tgrs.2021.3060513 [97] Chang R, Yu K, Yang Y. Self-Supervised monocular depth estimation using global and local mixed multi-scale feature enhancement network for low-altitude UAV remote sensing. Remote Sensing, 2023, 15(13): Article No. 3275 doi: 10.3390/rs15133275 [98] Zhang X, Guan Z, Liu X, Zhang Z. Digital reconstruction method for low-illumination road traffic accident scenes using UAV and auxiliary equipment. World Electric Vehicle Journal, 2025, 16(3): Article No. 171 doi: 10.3390/wevj16030171 [99] Bhat S F, Birkl R, Wofk D, Wonka P, Müller M. ZoeDepth: zero-shot transfer by combining relative and metric depth. arXiv preprint arXiv: 2302.12288, 2023. [100] Luddecke T, Ecker A. Image segmentation using text and image prompts. In: Proceedings of 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). New Orleans, LA, USA: IEEE, 2022. 7076-7086 DOI: 10.1109/cvpr52688.2022.00695 [101] Kumar M, Mondal S. Recent developments on target tracking problems: a review. Ocean Engineering, 2021, 236: Article No. 109558 doi: 10.1016/j.oceaneng.2021.109558 [102] Byun S, Shin I K, Moon J, Kang J, Choi S I. Road traffic monitoring from UAV images using deep learning networks. Remote Sensing, 2021, 13(20): Article No. 4027 doi: 10.3390/rs13204027 [103] Bisio I, Garibotto C, Haleem H, Lavagetto F, Sciarrone A. Vehicular/Non-Vehicular multi-class multi-object tracking in drone-based aerial scenes. IEEE Transactions on Vehicular Technology, 2024, 73(4): 4961−4977 doi: 10.1109/tvt.2023.3332132 [104] Yuan Y, Wu Y, Zhao L, Liu Y, Pang Y. End-to-end multiple object tracking in high-resolution optical sensors of drones with transformer models. Scientific Reports, 2024, 14(1). DOI: 10.1038/s41598-024-75934-9 [105] Ma Y, Tang Y, Yang W, Zhang T, Zhang J, Kang M. Unifying visual and vision-language tracking via contrastive learning. Proceedings of the AAAI Conference on Artificial Intelligence, 2024, 38(5): 4107−4116 doi: 10.1609/aaai.v38i5.28205 [106] Cao J, Pang J, Weng X, Khirodkar R, Kitani K. Observation-Centric SORT: rethinking SORT for robust multi-object tracking. In: Proceedings of 2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Vancouver, BC, Canada: IEEE, 2023. 9686-9696 DOI: 10.1109/cvpr52729.2023.00934 [107] Anh D L D, Tran K H, Nguyen Q T, Le N H. Enhanced kalman with adaptive appearance motion SORT for grounded generic multiple object tracking. In: Proceedings of Lecture Notes in Computer Science. Springer Nature Singapore, 2024. 310-328. DOI: 10.1007/978-981-96-0917-8_18 [108] Ye M, Shen J, Lin G, Xiang T, Shao L, Hoi S C H. Deep learning for person re-identification: a survey and outlook. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2022, 44(6): 2872−2893 doi: 10.1109/tpami.2021.3054775 [109] Wang P, Jiao B, Yang L, Yang Y, Zhang S, Wei W, et al. Vehicle re-identification in aerial imagery: dataset and approach. In: Proceedings of 2019 IEEE/CVF International Conference on Computer Vision (ICCV). Seoul, Korea (South): IEEE, 2019. 460-469 DOI: 10.1109/iccv.2019.00055 [110] Guo X, Yang J, Jia X, Zang C, Xu Y, Chen Z. A novel dual-pooling attention module for UAV vehicle re-identification. Scientific Reports, 2024, 14(1). DOI: 10.1038/s41598-024-52225-x [111] Li S, Sun L, Li Q. CLIP-ReID: exploiting vision-language model for image re-identification without concrete text labels. Proceedings of the AAAI Conference on Artificial Intelligence, 2023, 37(1): 1405−1413 doi: 10.1609/aaai.v37i1.25225 [112] Bozcan I, Kayacan E. UAV-AdNet: unsupervised anomaly detection using deep neural networks for aerial surveillance. In: Proceedings of 2020 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Las Vegas, NV, USA: IEEE, 2020. 1158-1164 DOI: 10.1109/iros45743.2020.9341790 [113] Jin P, Mou L, Xia G S, Zhu X X. Anomaly detection in aerial videos with transformers. IEEE Transactions on Geoscience and Remote Sensing, 2022, 60: 1−13 doi: 10.1109/tgrs.2022.3198130 [114] Tran T M, Vu T N, Nguyen T V, Nguyen K. UIT-ADrone: a novel drone dataset for traffic anomaly detection. IEEE Journal of Selected Topics in Applied Earth Observations and Remote Sensing, 2023, 16: 5590−5601 doi: 10.1109/JSTARS.2023.3285905 [115] Carreira J, Zisserman A. Quo vadis, action recognition? a new model and the kinetics dataset. In: Proceedings of 2017 IEEE Conference on Computer Vision and Pattern Recognition (CVPR). Honolulu, HI: IEEE, 2017. 4724-4733 DOI: 10.1109/cvpr.2017.502 [116] Tran D, Bourdev L, Fergus R, Torresani L, Paluri M. Learning spatiotemporal features with 3D convolutional networks. In: Proceedings of 2015 IEEE International Conference on Computer Vision (ICCV). Santiago, Chile: IEEE, 2015. 4489-4497 DOI: 10.1109/iccv.2015.510 [117] Lin K, Li L, Lin C C, Ahmed F, Gan Z, Liu Z, et al. SwinBERT: end-to-end transformers with sparse attention for video captioning. In: Proceedings of 2022 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). New Orleans, LA, USA: IEEE, 2022. 17928-17937 DOI: 10.1109/cvpr52688.2022.01742 [118] Stefanini M, Cornia M, Baraldi L, Cascianelli S, Fiameni G, Cucchiara R. From show to tell: a survey on deep learning-based image captioning. IEEE Transactions on Pattern Analysis and Machine Intelligence, 2023, 45(1): 539−559 doi: 10.1109/tpami.2022.3148210 [119] Sakaino H. Dynamic texts from UAV perspective natural images. In: Proceedings of 2023 IEEE/CVF International Conference on Computer Vision Workshops (ICCVW). Paris, France: IEEE, 2023. 2062-2073 DOI: 10.1109/iccvw60793.2023.00221 [120] Sakaino H. Semantically enhanced scene captions with physical and weather condition changes. In: Proceedings of 2023 IEEE/CVF International Conference on Computer Vision Workshops (ICCVW). Paris, France: IEEE, 2023. 3656-3668 DOI: 10.1109/iccvw60793.2023.00393 [121] Kim B S, Kim J, Lee D, Jang B. Visual question answering: a survey of methods, datasets, evaluation, and challenges. ACM Computing Surveys, 2025, 57(10): 1−35 doi: 10.1145/3728635 [122] Xiao J, Zhang R, Zhang Y, Feroskhan M. Vision-Based learning for drones: a survey. IEEE Transactions on Neural Networks and Learning Systems, 2025, 36(9): 15601−15621 doi: 10.1109/tnnls.2025.3564184 [123] Gupta T, Kembhavi A. Visual programming: compositional visual reasoning without training. In: Proceedings of 2023 IEEE/CVF Conference on Computer Vision and Pattern Recognition (CVPR). Vancouver, BC, Canada: IEEE, 2023. 14953-14962 DOI: 10.1109/cvpr52729.2023.01436 [124] Cai Z, Cardenas C R, Leo K, Becker J, Adams S, Kassas Z M, et al. NEUSIS: a compositional neuro-symbolic framework for autonomous perception, reasoning, and planning in complex UAV search missions. IEEE Robotics and Automation Letters, 2025, 10(9): 9502−9509 doi: 10.1109/LRA.2025.3592098 [125] Anderson P, Wu Q, Teney D, Bruce J, Johnson M, Sunderhauf N, et al. Vision-and-Language navigation: interpreting visually-grounded navigation instructions in real environments. In: Proceedings of 2018 IEEE/CVF Conference on Computer Vision and Pattern Recognition. Salt Lake City, UT: IEEE, 2018. 3674-3683 DOI: 10.1109/cvpr.2018.00387 [126] Krantz J, Wijmans E, Majumdar A, Batra D, Lee S. Beyond the nav-graph: vision-and-language navigation in continuous environments. In: Proceedings of Lecture Notes in Computer Science. Springer International Publishing, 2020. 104-120. DOI: 10.1007/978-3-030-58604-1_7 [127] Oquab M, Darcet T, Moutakanni T, Vo H, Szafraniec M, Khalidov V, et al. DINOv2: learning robust visual features without supervision. Transactions on Machine Learning Research, 2024. [128] OpenAI. GPT-4 technical report. arXiv preprint arXiv: 2303.08774, 2023. [129] Wu R, Zhang Y, Chen J, Huang L, Zhang S, Zhou X, et al. AeroDuo: aerial duo for uav-based vision and language navigation. In: Proceedings of the 33rd ACM International Conference on Multimedia. Dublin Ireland: ACM, 2025. 2576-2585 DOI: 10.1145/3746027.3754498 [130] Cai H, Dong J, Tan J, Deng J, Li S, Gao Z, et al. FlightGPT: towards generalizable and interpretable UAV vision-and-language navigation with vision-language models. In: Proceedings of the 2025 Conference on Empirical Methods in Natural Language Processing. Suzhou, China: Association for Computational Linguistics, 2025. 6670-6687 DOI: 10.18653/v1/2025.emnlp-main.338 [131] Rahman M, Sarkar N I, Lutui R. A survey on multi-uav path planning: classification, algorithms, open research problems, and future directions. Drones, 2025, 9(4): Article No. 263 doi: 10.3390/drones9040263 [132] Kannan S S, Venkatesh V L N, Min B C. SMART-LLM: smart multi-agent robot task planning using large language models. In: Proceedings of 2024 IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS). Abu Dhabi, United Arab Emirates: IEEE, 2024. 12140-12147 DOI: 10.1109/iros58592.2024.10802322 [133] Zhou Y, Yan L, Han Y, Xie H, Zhao Y. A survey on the key technologies of UAV motion planning. Drones, 2025, 9(3): Article No. 194 doi: 10.3390/drones9030194 [134] Luo J, Wang Z, Xia M, Wu L, Tian Y, Chen Y. Path planning for UAV communication networks: related technologies, solutions, and opportunities. ACM Computing Surveys, 2023, 55(9): 1−37 doi: 10.1145/3560261 [135] Zhu Y, Zhang X, Li Y, Liu Y, Ma J. Grid matrix-based ground risk map generation for unmanned aerial vehicles in urban environments. Drones, 2024, 8(11): Article No. 678 doi: 10.3390/drones8110678 [136] Lin X, Wang C, Wang K, Li M, Yu X. Trajectory planning for unmanned aerial vehicles in complicated urban environments: a control network approach. Transportation Research Part C: Emerging Technologies, 2021, 128: Article No. 103120 doi: 10.1016/j.trc.2021.103120 [137] Moon J, Lee B Y, Tahk M J. A hybrid dynamic window approach for collision avoidance of VTOL UAVs. International Journal of Aeronautical and Space Sciences, 2018, 19(4): 889−903 doi: 10.1007/s42405-018-0061-z [138] Cao L, Chi H. Dynamic obstacle avoidance of UAV using chance constrained model predictive control. Optimal Control Applications and Methods, 2025, 46(5): 1914−1931 doi: 10.1002/oca.3298 [139] Zhang X, Ma J, Cheng Z, Huang S, Ge S S, Lee T H. Trajectory generation by chance-constrained nonlinear MPC with probabilistic prediction. IEEE Transactions on Cybernetics, 2021, 51(7): 3616−3629 doi: 10.1109/tcyb.2020.3032711 [140] Tordesillas J, How J P. PANTHER: perception-aware trajectory planner in dynamic environments. IEEE Access, 2022, 10: 22662−22677 doi: 10.1109/access.2022.3154037 [141] Li Z, Li S, Lu J, Wang S. Air route network planning method of urban low-altitude logistics UAV with double-layer structure. Drones, 2025, 9(3): Article No. 193 doi: 10.3390/drones9030193 [142] Xu C, Liao X, Ye H, Yue H. Iterative construction of low-altitude UAV air route network in urban areas: case planning and assessment. Journal of Geographical Sciences, 2020, 30(9): 1534−1552 doi: 10.1007/s11442-020-1798-4 [143] Oh S, Yoon Y. Urban drone operations: a data-centric and comprehensive assessment of urban airspace with a pareto-based approach. Transportation Research Part A: Policy and Practice, 2024, 182: Article No. 104034 doi: 10.1016/j.tra.2024.104034 [144] Ma Z, Wang Z, Ma A, Liu Y, Niu Y. A low-altitude obstacle avoidance method for UAVs based on polyhedral flight corridor. Drones, 2023, 7(9): Article No. 588 doi: 10.3390/drones7090588 [145] Mao X, Wu G, Fan M, Cao Z, Pedrycz W. DL-DRL: a double-level deep reinforcement learning approach for large-scale task scheduling of multi-uav. IEEE Transactions on Automation Science and Engineering, 2025, 22: 1028−1044 doi: 10.1109/tase.2024.3358894 [146] Tsushima Y, Yamamoto S, Ravankar A A, Luces J V S, Hirata Y. Task planning for a factory robot using large language model. IEEE Robotics and Automation Letters, 2025, 10(3): 2383−2390 doi: 10.1109/lra.2025.3531153 [147] Zhang Y, Kantaros Y. NAMO-LLM: efficient navigation among movable obstacles with large language model guidance. IEEE Robotics and Automation Letters, 2025, 10(12): 13026−13033 doi: 10.1109/lra.2025.3621972 [148] Zhu F, Huang F, Yu Y, Liu G, Huang T. Task offloading with llm-enhanced multi-agent reinforcement learning in uav-assisted edge computing. Sensors, 2024, 25(1): Article No. 175 doi: 10.3390/s25010175 [149] Bai X, Ye Y, Zhang B, Ge S S. Efficient package delivery task assignment for truck and high capacity drone. IEEE Transactions on Intelligent Transportation Systems, 2023, 24(11): 13422−13435 doi: 10.1109/tits.2023.3287163 [150] Jia Z, Yu J, Ai X, Xu X, Yang D. Cooperative multiple task assignment problem with stochastic velocities and time windows for heterogeneous unmanned aerial vehicles using a genetic algorithm. Aerospace Science and Technology, 2018, 76: 112−125 doi: 10.1016/j.ast.2018.01.025 [151] Jung S, Yun W J, Shin M, Kim J, Kim J H. Orchestrated scheduling and multi-agent deep reinforcement learning for cloud-assisted multi-uav charging systems. IEEE Transactions on Vehicular Technology, 2021, 70(6): 5362−5377 doi: 10.1109/tvt.2021.3062418 [152] Tian Y, Lin F, Li Y, Zhang T, Zhang Q, Fu X, et al. UAVs meet LLMs: overviews and perspectives towards agentic low-altitude mobility. Information Fusion, 2025, 122: Article No. 103158 doi: 10.1016/j.inffus.2025.103158 [153] Yu H, Wang C, Wu L, Liu Y, Niu Y. LLMSTP: empowering swarm task planning with large language models. In: Proceedings of Lecture Notes in Electrical Engineering. Springer Nature Singapore, 2025. 500-510. DOI: 10.1007/978-981-96-3552-8_47 [154] Pang J, He J, Mohamed N M A A, Lin C, Zhang Z, Hao X. A hierarchical reinforcement learning framework for multi-UAV combat using leader-follower strategy. Knowledge-Based Systems, 2025, 316: Article No. 113387 doi: 10.1016/j.knosys.2025.113387 [155] Peng Z, Wu G, Luo B, Wang L. Multi-UAV cooperative pursuit strategy with limited visual field in urban airspace: a multi-agent reinforcement learning approach. IEEE/CAA Journal of Automatica Sinica, 2025, 12(7): 1350−1367 doi: 10.1109/jas.2024.124965 [156] Ekechi C C, Elfouly T, Alouani A, Khattab T. A survey on UAV control with multi-agent reinforcement learning. Drones, 2025, 9(7): Article No. 484 doi: 10.3390/drones9070484 [157] Zhang H, Li W, Zheng J, Liu H, Zhang P, Gao P, et al. Manned/unmanned aerial vehicle cooperative combat system: concepts, technologies, and challenges. Acta Aeronautica et Astronautica Sinica, 2024, 45(15): Article No. 029653 [158] 程洁, 郑远, 李诚龙, 江波. 面向超低空物流场景的多机协同航迹规划算法. 系统仿真学报, 2024, 36(1): 50−66 doi: 10.16182/j.issn1004731x.joss.22-1028Cheng Jie, Zheng Yuan, Li Cheng-Long, Jiang Bo. Multi-UAV collaborative trajectory planning algorithm for urban ultra-low-altitude air transportation scenario. Journal of System Simulation, 2024, 36(1): 50−66 doi: 10.16182/j.issn1004731x.joss.22-1028 [159] Long Q, Ma J, Jiang F, Webster C J. Demand analysis in urban air mobility: a literature review. Journal of Air Transport Management, 2023, 112: Article No. 102436 doi: 10.1016/j.jairtraman.2023.102436 [160] Zhao H, Pan F, Ping H, Zhou Y. Agent as Cerebrum, Controller as Cerebellum: Implementing an Embodied LMM-based Agent on Drones. arXiv preprint arXiv: 2311.15033, 2023. [161] Shi C, Xiong Z, Chen M, Wang R, Xiong J. Cooperative navigation for heterogeneous air-ground vehicles based on interoperation strategy. Remote Sensing, 2023, 15(8): Article No. 2006 doi: 10.3390/rs15082006 [162] Song N, Lv C, Nie J, Ye M, Zhao E, Ma J, et al. LLM-DSK: a domain-specific semantic knowledge-guided ocean environment prediction method based on large language models. IEEE Journal of Selected Topics in Applied Earth Observations and Remote Sensing, 2025, 18: 19453−19469 doi: 10.1109/jstars.2025.3590651 [163] Dorzhieva E, Baza A, Gupta A, Fedoseev A, Cabrera M A, Karmanova E, et al. DroneARchery: human-drone interaction through augmented reality with haptic feedback and multi-uav collision avoidance driven by deep reinforcement learning. In: Proceedings of 2022 IEEE International Symposium on Mixed and Augmented Reality (ISMAR). Singapore, Singapore: IEEE, 2022. 270-277 DOI: 10.1109/ismar55827.2022.00042 [164] Zhang L, Wang B, Zhao Y, Yuan Y, Zhou T, Li Z. Collaborative multimodal fusion network for multiagent perception. IEEE Transactions on Cybernetics, 2025, 55(1): 486−498 doi: 10.1109/tcyb.2024.3491756 [165] Singh A, Raut G, Choudhary A. Multi-agent collaborative perception for robotic fleet: a systematic review. In: Proceedings of Lecture Notes in Computer Science. Springer Nature Switzerland, 2025. 1-15. DOI: 10.1007/978-3-031-91813-1_1 [166] 彭周华, 吴文涛, 王丹, 等. 多无人艇集群协同控制研究进展与未来趋势. 中国舰船研究, 2021, 16(1): 51−64 doi: 10.19693/j.issn.1673-3185.01923Peng Zhou-Hua, Wu Wen-Tao, Wang Dan, et al. Coordinated control of multiple unmanned surface vehicles: recent advances and future trends. Chinese Journal of Ship Research, 2021, 16(1): 51−64 doi: 10.19693/j.issn.1673-3185.01923 [167] Alhammadi A, Abraham A, Zhao Q. LLM-powered UAV automations for city-wide operations. In: Internet of Vehicles and Computer Vision Solutions for Smart City Transformations. Cham, Switzerland: Springer, 2025. 69-83. [168] Wang Y, Wang Z, Cheng P, Tian P, Yang L, Wang Z, et al. AVCPNet: an AAV-vehicle collaborative perception network for 3D object detection. IEEE Transactions on Geoscience and Remote Sensing, 2025, 63: 1−16 doi: 10.1109/TGRS.2025.3546669 [169] Liu H, Ma Z, Li Y, Sugihara J, Chen Y, Li J, et al. Hierarchical language models for semantic navigation and manipulation in an aerial-ground robotic system. Advanced Intelligent Systems, 2025, 8(2). DOI: 10.1002/aisy.202500640 [170] Kim S, Seo H, Shin J, Kim H J. Cooperative aerial manipulation using multirotors with multi-dof robotic arms. IEEE/ASME Transactions on Mechatronics, 2018, 23(2): 702−713 doi: 10.1109/tmech.2018.2792318 [171] Miller I D, Cladera F, Smith T, Taylor C J, Kumar V. Stronger together: air-ground robotic collaboration using semantics. IEEE Robotics and Automation Letters, 2022, 7(4): 9643−9650 doi: 10.1109/lra.2022.3191165 [172] Yao F, Yue Y, Liu Y, Wang Z, Jin L, Zhao B, et al. AeroVerse: uav-agent benchmark suite for simulating, pre-training, finetuning, and evaluating aerospace embodied foundation models. IEEE Transactions on Pattern Analysis and Machine Intelligence, 20261−18 doi: 10.1109/tpami.2026.3697634 [173] Guo M, Wu M, He J, Li S, Li H, Tao C. BEDI: a comprehensive benchmark for evaluating embodied agents on UAVs. ISPRS Journal of Photogrammetry and Remote Sensing, 2026, 232: 910−936 doi: 10.1016/j.isprsjprs.2026.01.013 [174] Lyu Z, Gao Y, Chen J, Du H, Xu J, Huang K, et al. Empowering intelligent low-altitude economy with large ai model deployment. IEEE Wireless Communications, 2026, 33(1): 64−72 doi: 10.1109/mwc.2025.3631765 [175] Yuan L, Deng C, Han D J, Hwang I, Brunswicker S, Brinton C G. Next-Generation LLM for UAV: From Natural Language to Autonomous Flight. arXiv preprint arXiv: 2510.21739, 2025. [176] Koubaa A, Gabr K. Agentic UAVs: LLM-Driven Autonomy with Integrated Tool-Calling and Cognitive Reasoning. arXiv preprint arXiv: 2509.13352, 2025. [177] Eesaar H, Ahmed A, Farhan M, Chong K T, Lee D J, Tayara H. Multi-Modal autonomous drone system for real-time highway incident detection and analysis. IEEE Access, 2025, 13: 183314−183329 doi: 10.1109/access.2025.3623653 [178] Farhan M, Eesaar H, Ahmed A, Chong K T, Tayara H. Transforming highway safety with autonomous drones and ai: a framework for incident detection and emergency response. IEEE Open Journal of Vehicular Technology, 2025, 6: 829−845 doi: 10.1109/ojvt.2025.3549387 [179] 王飞跃. 迈向智业社会的新引擎: 低空经济与智能科技. 首届澳门粤港澳大湾区低空经济研讨会. 澳门, 2024年5月10日.Wang F-Y. The new engine toward the intelligent society: low-altitude economy and intelligent technology. The First Macao-Guangdong-Hong Kong-Macao Greater Bay Area Low-Altitude Economy Seminar, Macao, May 10, 2024. [180] Wang F-Y. New AI for smart logistics and mobility in smart cities: from low-altitude space to circular in situ economy and ecology (LaSEE/CiSEE). Lecture at Óbuda University, Budapest, March 31, 2025. [181] Wang F-Y. New AI and new SLAM: from LaSEE to CiSEE. Lecture at Óbuda University, Budapest, August 7, 2025. -

 下载:

计量
- 文章访问数: 12
- HTML全文浏览量: 12
- 被引次数: 0
