

-
摘要: 针对具有多个运行点的非线性离散时间多变量强耦合系统, 提出一种最优切换解耦控制方法. 首先, 将非线性系统在多个运行点附近泰勒展开, 得到多个近似线性模型, 通过引入开关函数, 并利用矩阵分解方法建立控制器设计模型; 然后, 基于考虑耦合影响的复合型性能指标, 利用嵌入转换技术、极小值原理及二次规划技术, 推导出最优切换准则函数及最优切换解耦控制器, 并设计鲁棒补偿器以提升控制系统性能; 最后, 进行数值仿真实验, 实验结果验证了所提方法的有效性及优越性.Abstract: An optimal switching decoupling control method for nonlinear discrete-time multivariable systems with multiple operating points and strong coupling. First, the nonlinear system is approximated by several local linear models obtained via Taylor expansion around multiple operating points. A switching function is introduced, and a controller design model is established using matrix decomposition techniques. Then, based on a composite performance index that takes coupling effects into account, the optimal switching criterion and the optimal decoupled controller are derived using embedding transformation, the minimum principle, and quadratic programming. A robust compensator is further designed to enhance the performance of the control system. Finally, numerical simulations are conducted, and the results verify the effectiveness and superiority of the proposed method.
-
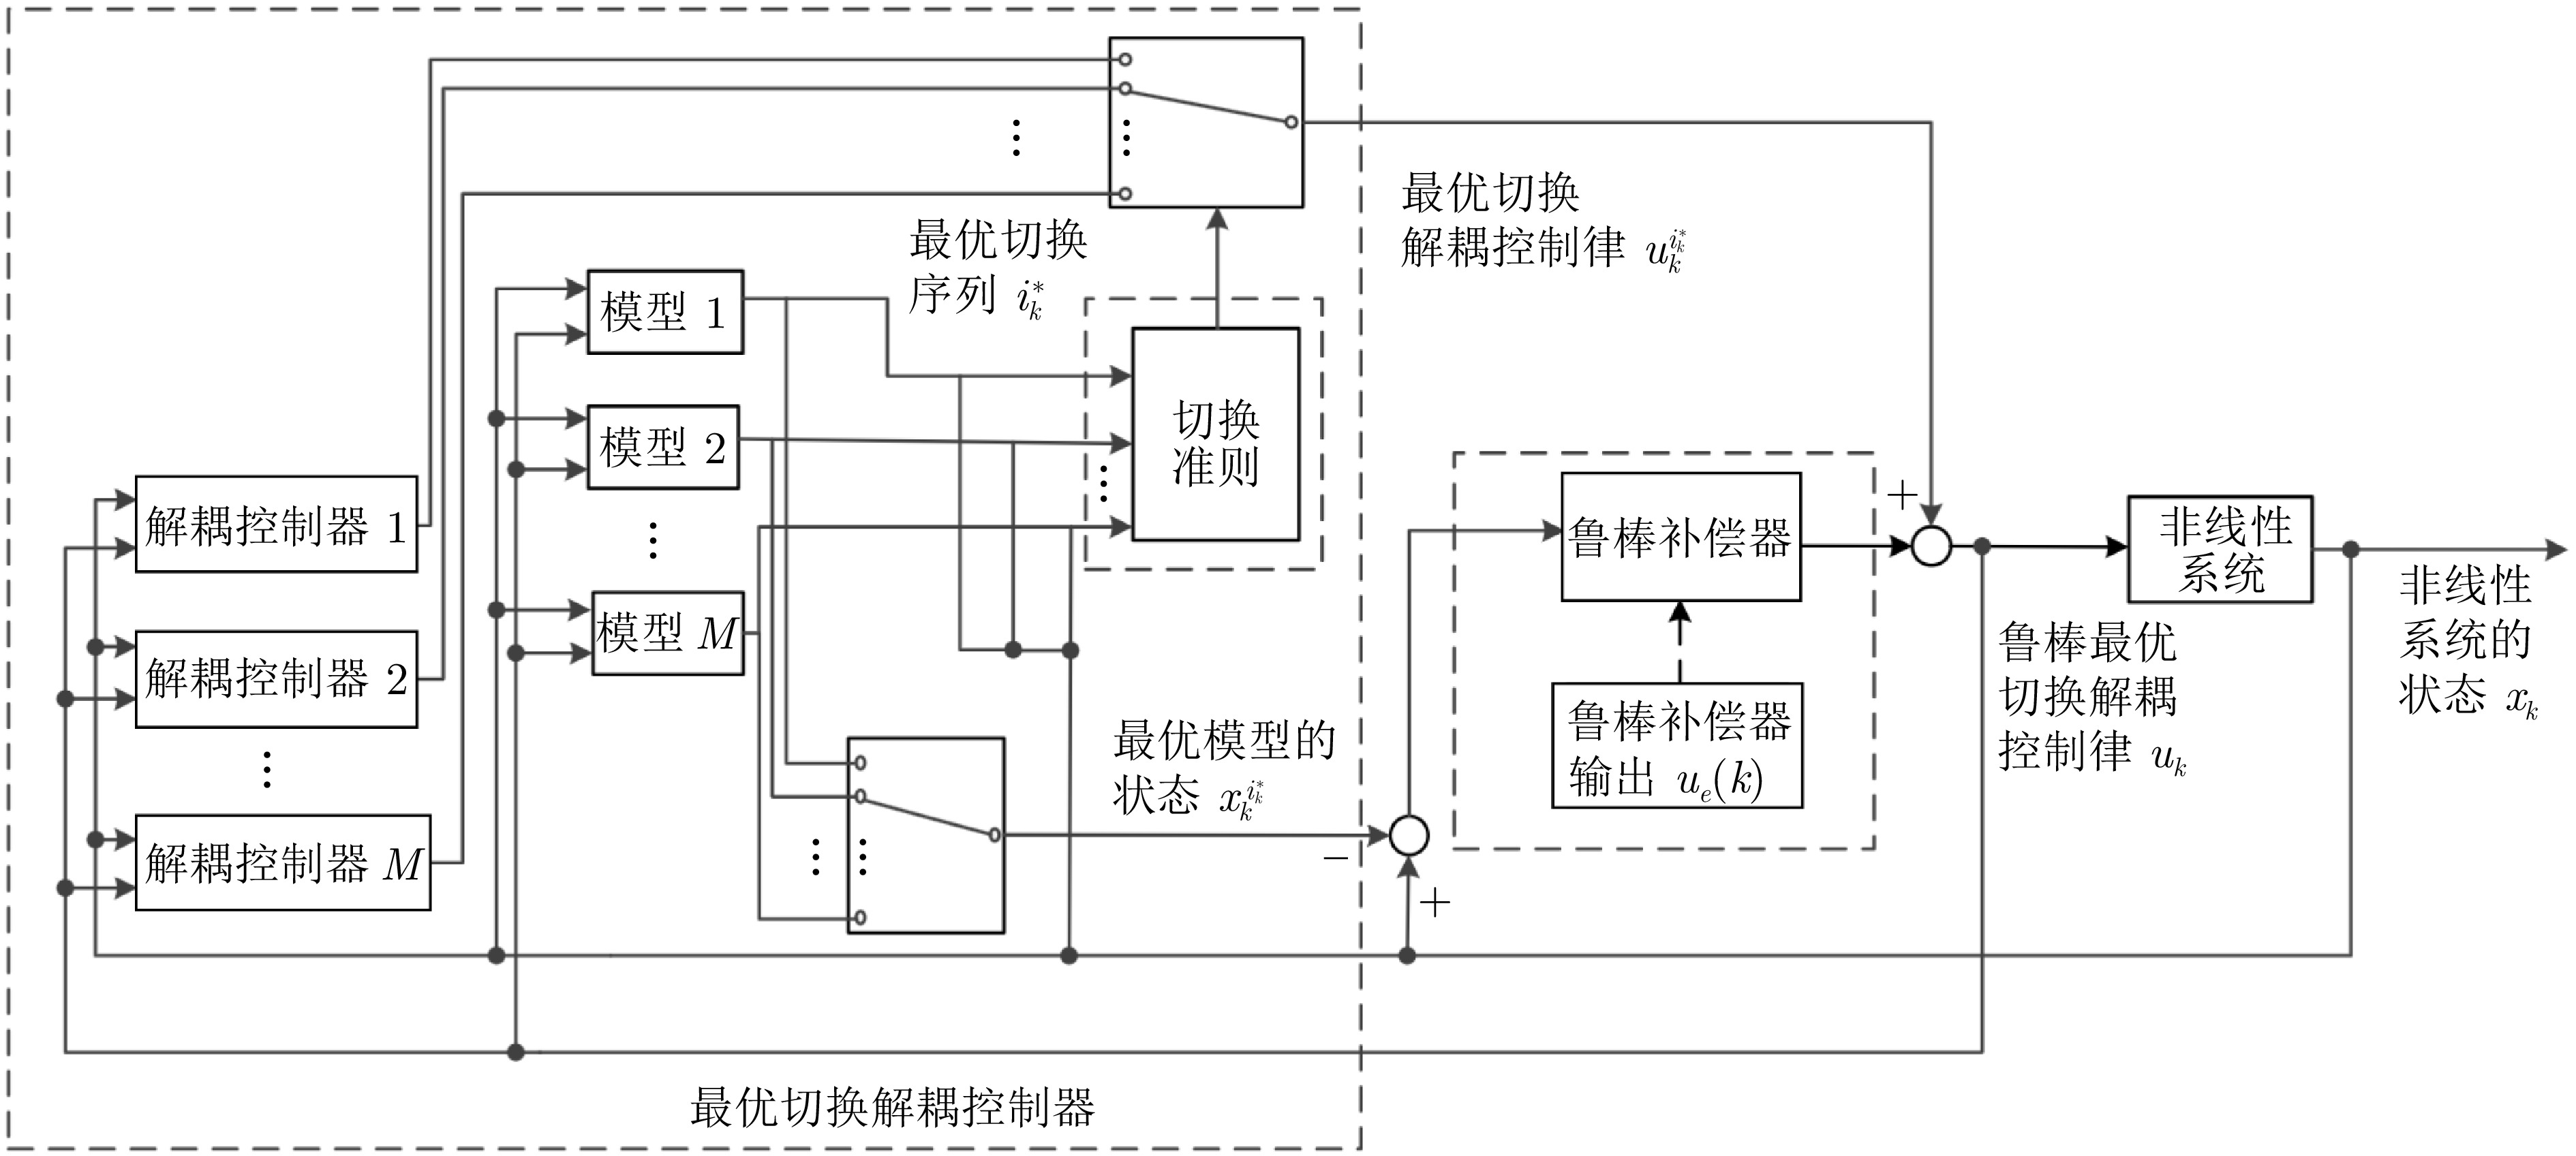
图 1 具有鲁棒特性的最优切换解耦控制系统结构图
Fig. 1 Structure of the robust optimal switching decoupling control system
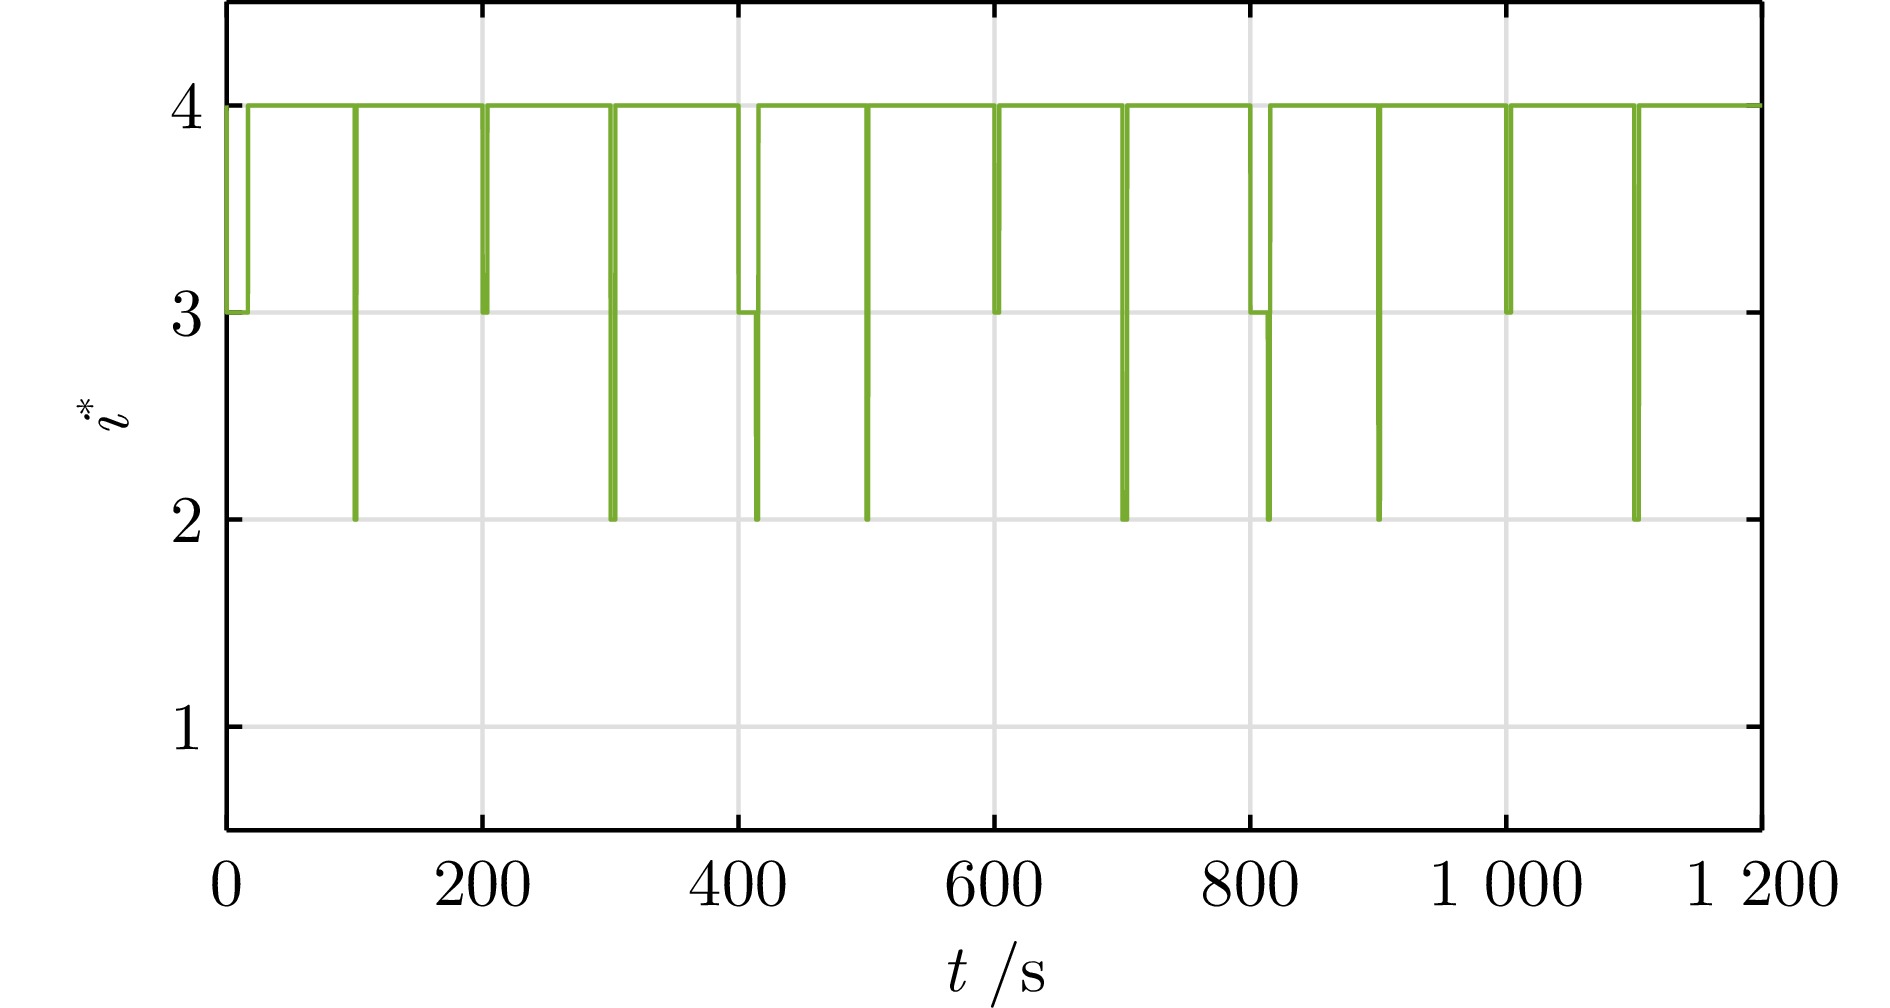
图 4 采用本文所提方法时系统的切换序列
Fig. 4 Switching sequence of the system using the proposed method
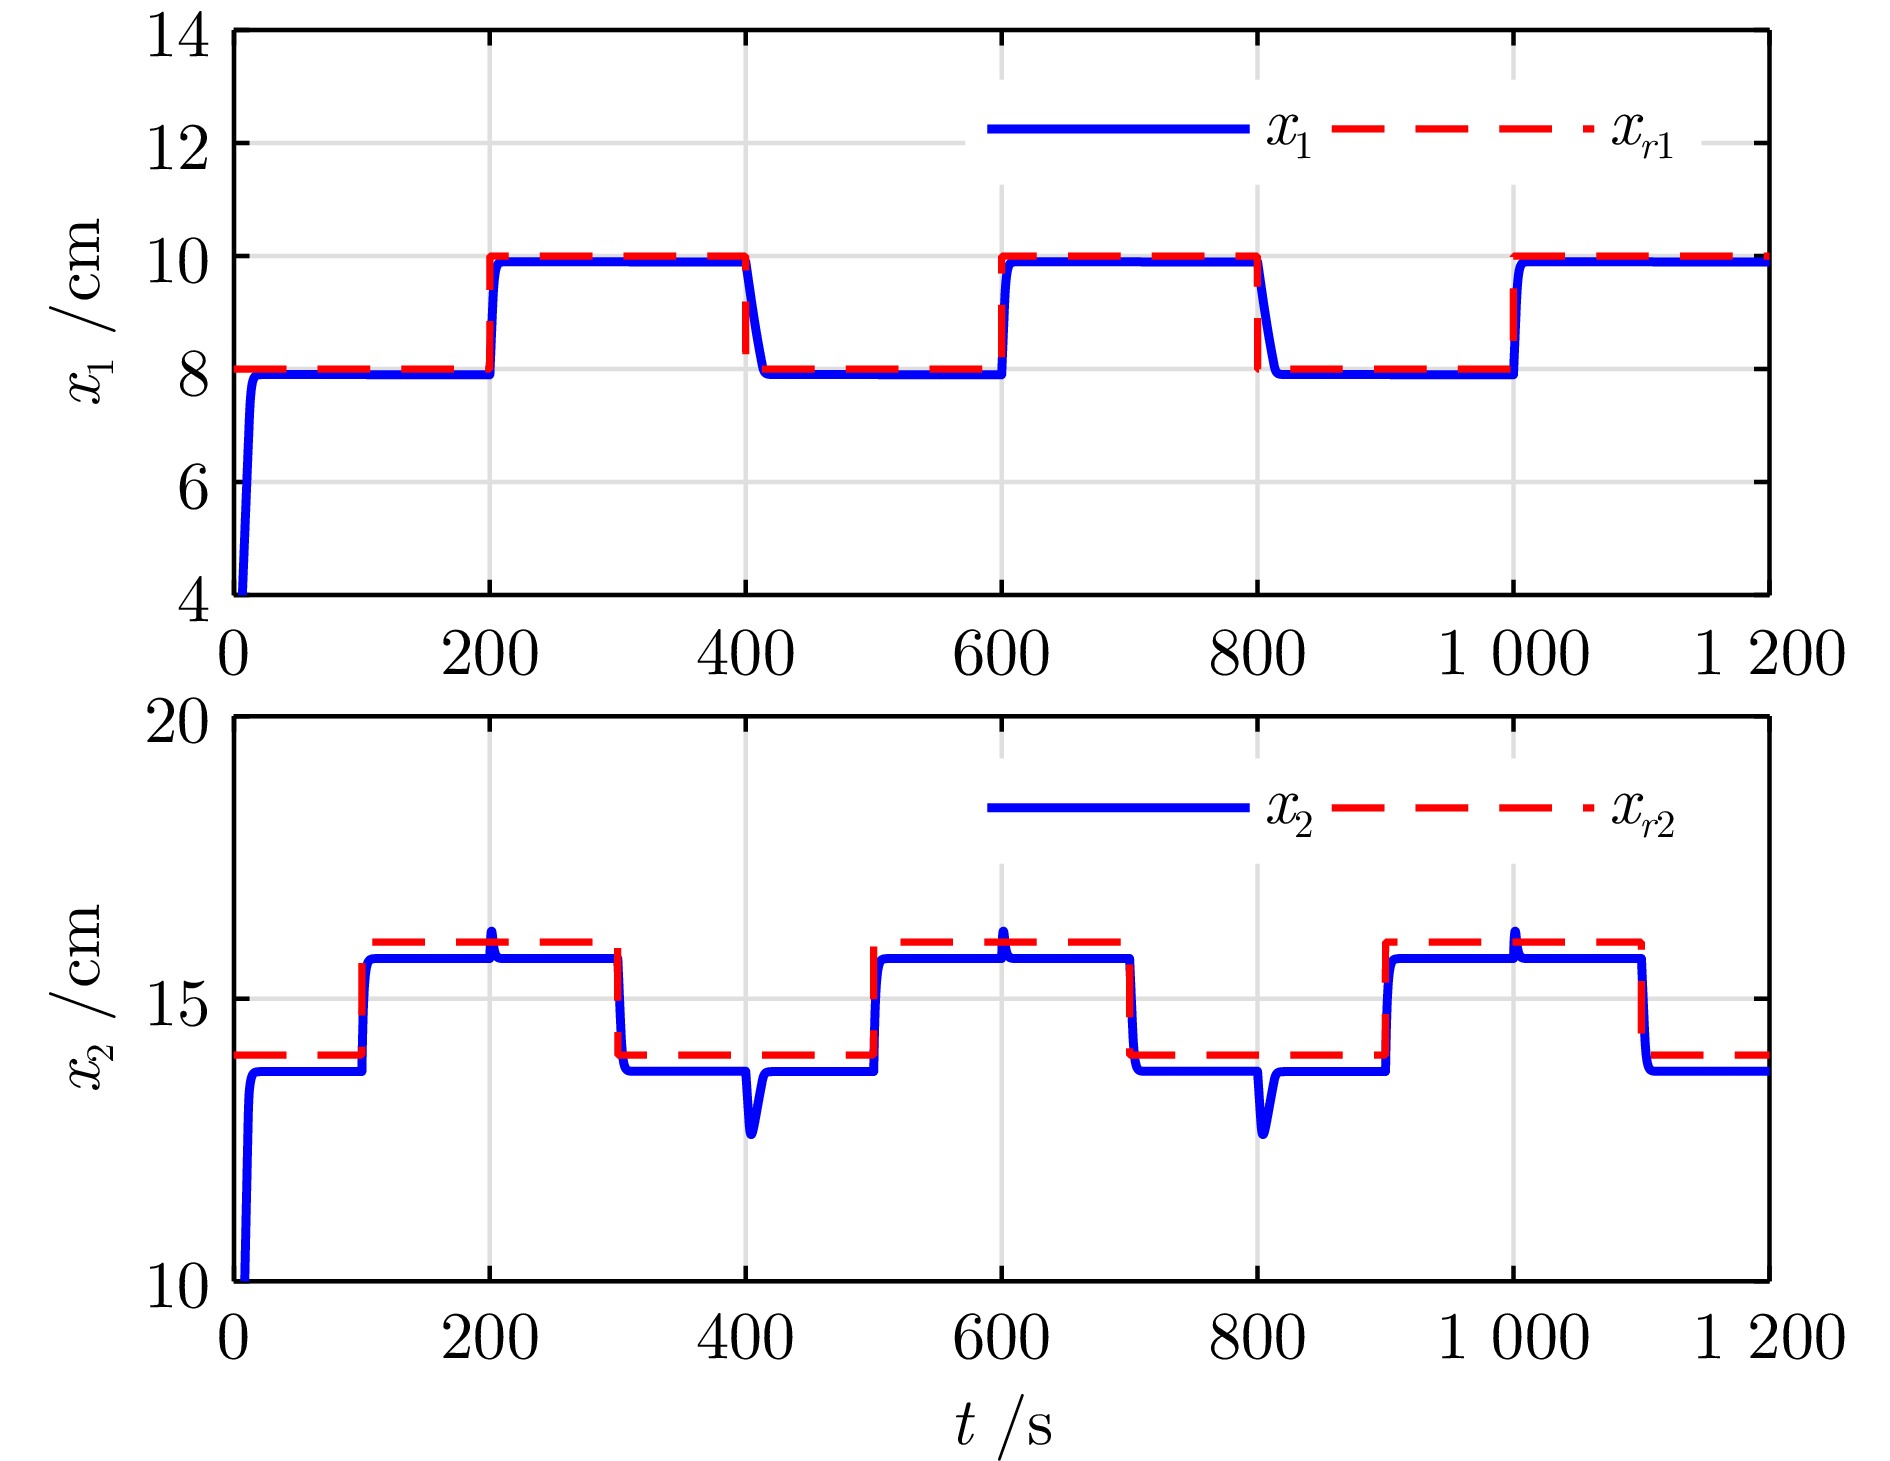
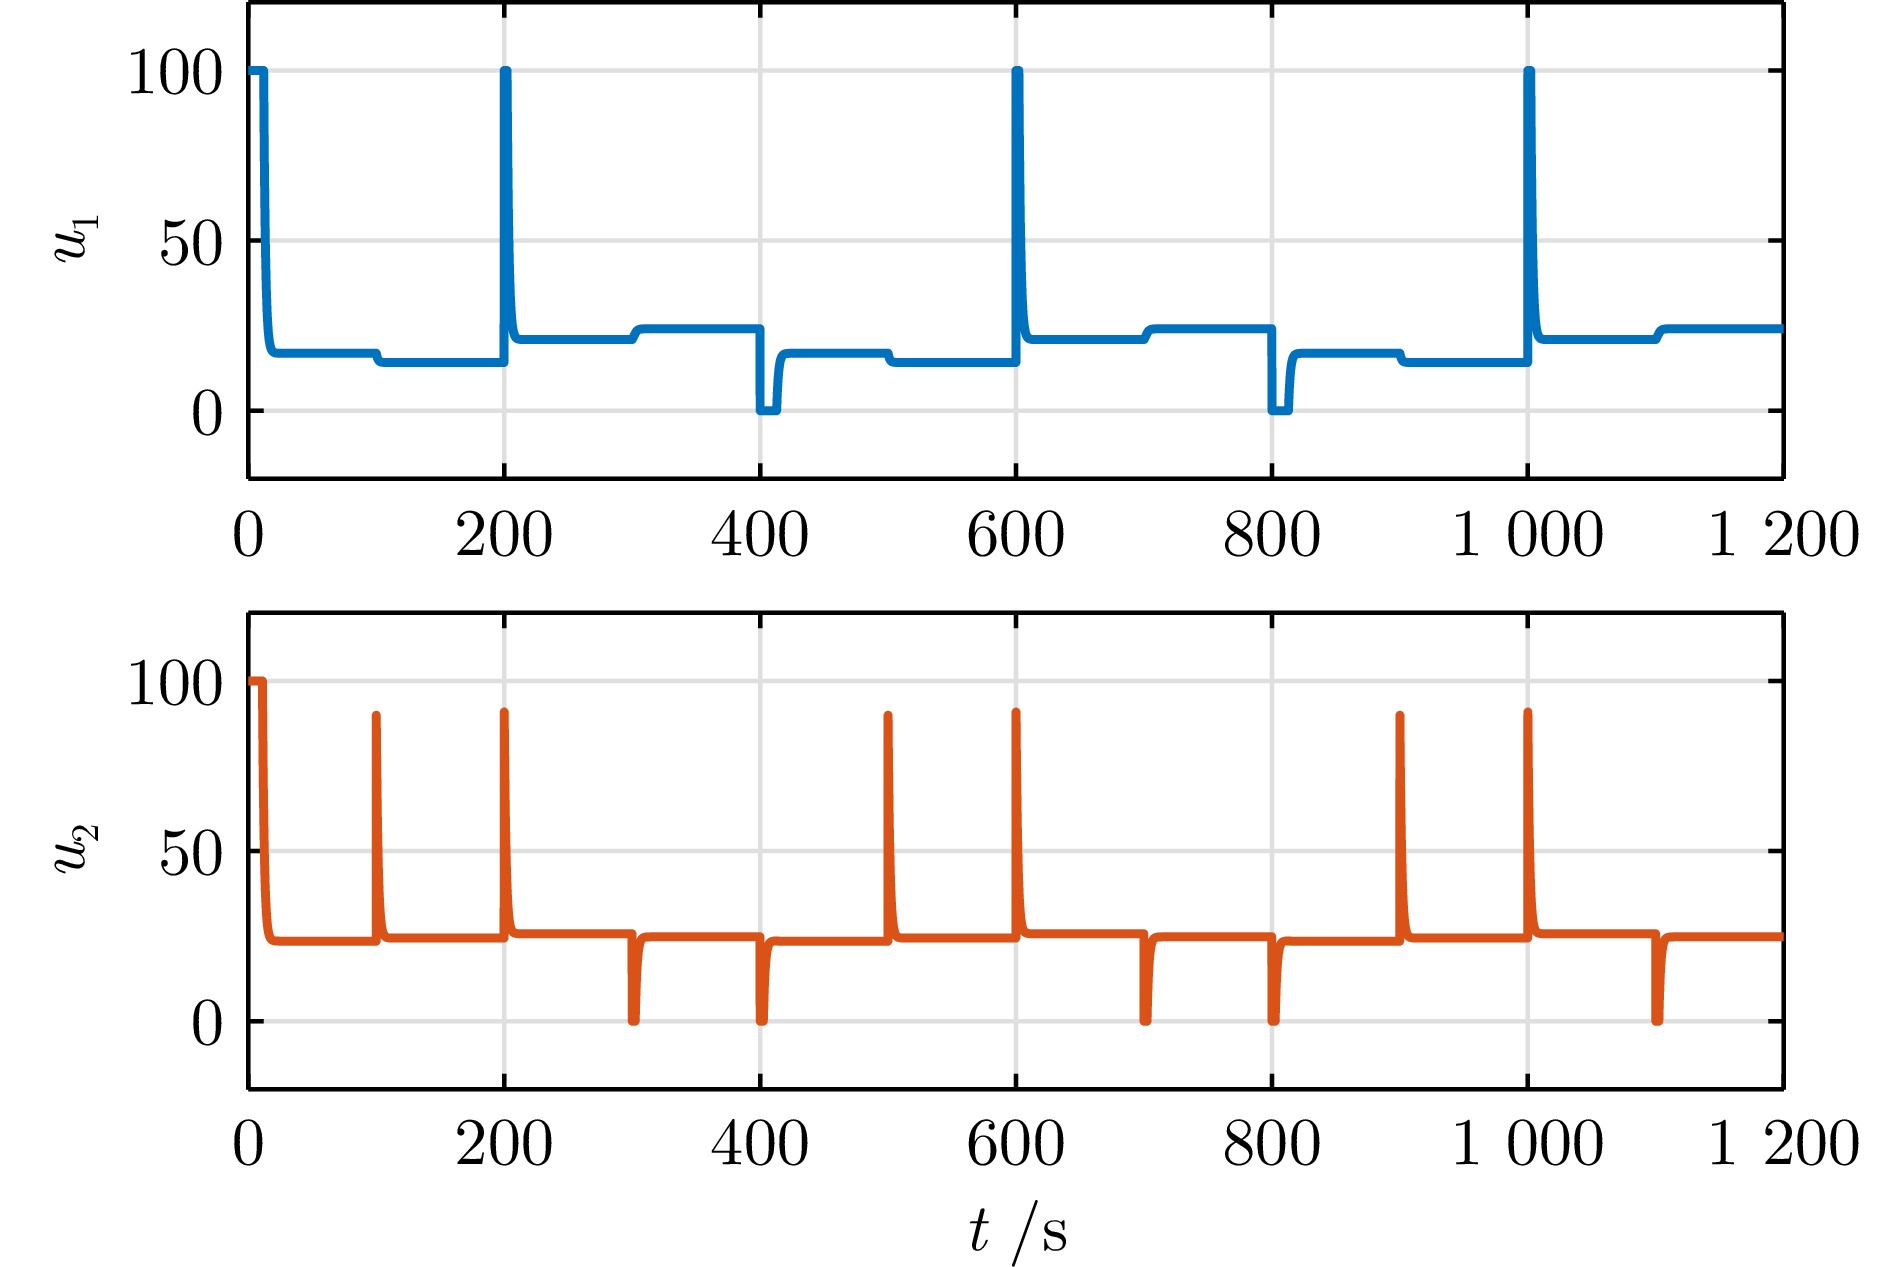
表 1 具有鲁棒特性的最优切换解耦控制算法
Table 1 The robust optimal switching decoupling control algorithm
算法1 具有鲁棒特性的最优切换解耦控制算法 步骤1. 根据先验知识, 确定线性化模型数量$M$并建立控制器设计模型; 步骤2. 选择系统初始状态$x_0 $, 终止时间$k_{\max}$; 步骤3. 根据式(42)计算最优切换函数$i_{k}^{*}$, 根据式(43)计算最优切换解耦控制律$u_{k}^{i^*}$; 步骤4. 根据式(44)获得最优模型状态$x_{k+1}^{i^*}$; 步骤5. 根据式(46)计算具有鲁棒特性的最优切换解耦控制律$u_k $; 步骤6. 返回步骤3直到$k>k_{\max}$.  下载: 导出CSV
-
[1] Hu C, Wang Z, Bu X W, Zhao J, Na J, Gao H. Optimal tracking control for autonomous vehicle with prescribed performance via adaptive dynamic programming. IEEE Transactions on Intelligent Transportation Systems, 2024, 25(9): 12437−12449 doi: 10.1109/TITS.2024.3384113 [2] Wang E H, Liu Y J, Xie C L. Optimal control of intelligent vehicle path tracking. IEEE Access, 2025, 13: 60148−60157 doi: 10.1109/ACCESS.2025.3557215 [3] Sun W, Xie S Y, Su S F. Learning-based adaptive optimal tracking control for flexible-joint robots with quantized states: theory and experiment. IEEE Transactions on Industrial Electronics, 2025, 72(8): 8230−8239 doi: 10.1109/TIE.2024.3522518 [4] Wang D, Ma H Y, Qiao J F. Multilayer adaptive critic design with digital twin for data-driven optimal tracking control and industrial applications. Engineering Applications of Artificial Intelligence, 2024, 133: Article No. 108228 doi: 10.1016/j.engappai.2024.108228 [5] Wang D, Zhao M M, Ha M M, Ren J. Neural optimal tracking control of constrained nonaffine systems with a wastewater treatment application. Neural Networks, 2021, 143: 121−132 doi: 10.1016/j.neunet.2021.05.027 [6] Tan H H, Shu S L, Lin F. An optimal control approach to robust tracking of linear systems. International Journal of Control, 2009, 82(3): 525−540 doi: 10.1080/00207170802187239 [7] Lewis F, Vrabie D, Syrmos V. Optimal control. Hoboken: John Wiley & Sons, 2012. 177-212 [8] 刘越, 周平, 孙霄阳. 基于Krotov方法的Markov跳变双线性系统最优跟踪控制及应用. 中国科学: 信息科学, 2025, 55: 582−600 doi: 10.1360/SSI-2024-0190Liu Yue, Zhou Ping, Sun Xiao-Yang. Optimal tracking control of Markov jump bilinear system based on Krotov’s method and its application. Scientia Sinica Informationis, 2025, 55: 582−600 doi: 10.1360/SSI-2024-0190 [9] Xia R S, Wu Q X, Chen M. Disturbance observer-based optimal longitudinal trajectory control of near space vehicle. SCIENTIA SINICA Informationis, 2019, 62(5): Article No. 050212 [10] 毛艳岭, 富月. 非线性系统自适应最优切换控制方法. 自动化学报, 2023, 49(10): 2122−2135 doi: 10.16383/j.aas.c220180Mao Yan-Ling, Fu Yue. Adaptive optimal switching control of nonlinear systems. Acta Automatica Sinica, 2023, 49(10): 2122−2135 doi: 10.16383/j.aas.c220180 [11] Wang W Z, Fu Y, Fu J. Indirect adaptive optimal tracking switching control of nonlinear systems. IEEE Transactions on Automatic Control, 2024, 69(6): 4142−4149 doi: 10.1109/TAC.2024.3351590 [12] Wang W Z, Fu Y. Robust adaptive optimal tracking switching control of nonlinear systems using embedding transformation and approximate dynamic programming. International Journal of Adaptive Control and Signal Processing, 2025, 39(5): 1079−1090 doi: 10.1002/acs.3993 [13] Lu J W, Wei Q L, Wang F Y. Parallel control for optimal tracking via adaptive dynamic programming. IEEE/CAA Journal of Automatica Sinica, 2020, 7(6): 1662−1674 doi: 10.1109/jas.2020.1003426 [14] Wei Q L, Jiao S S, Wang F Y, Dong Q. Robust optimal parallel tracking control based on adaptive dynamic programming. IEEE Transactions on Cybernetics, 2023, 54(77): 4308−4321 [15] Liu K X, Song F Z, Dong Y, Liu Y, Tan J B. Data-based dynamic decoupling control for MIMO precision motion stages with position-dependent disturbances. IEEE Transactions on Automation Science and Engineering, 2025, 22: 6122−6133 doi: 10.1109/TASE.2024.3439102 [16] Li M, Mao C H, Zhu Y, Yang K M, Li X. Data-based iterative dynamic decoupling control for precision MIMO motion systems. IEEE Transactions on Industrial Informatics, 2019, 16(3): 1668−1676 [17] Liu Y C, Huang C Y. DDPG-based adaptive robust tracking control for aerial manipulators with decoupling approach. IEEE Transactions on Cybernetics, 2021, 52(8): 8258−8271 doi: 10.1109/tcyb.2021.3049555 [18] Zhao H Y, Wan Y, Li L, Dong Y, Cui N. Iterative control decoupling tuning for precision MIMO motion systems: A matrix update method. ISA Transactions, 2024, 155: 398−413 doi: 10.1016/j.isatra.2024.10.003 [19] Zhao C, Yu C G, Yao J Y. Dynamic decoupling based robust synchronous control for a hydraulic parallel manipulator. IEEE Access, 2019, 7: 30548−30562 doi: 10.1109/ACCESS.2019.2894134 [20] Ji C, Zhang Z Q, Cheng G G, Kong M X, Li R F. Decoupled robust backstepping tracking control for variable stiffness actuated robot with input saturation. ISA Transactions, 2025, 156: 109−122 doi: 10.1016/j.isatra.2024.10.027 [21] Fu Y, Chen W, Fu J. A new optimal tracking controller of linear strongly coupled systems and its applications. IEEE Transactions on Circuits and Systems II: Express Briefs, 2021, 69(3): 1387−1391 doi: 10.1109/tcsii.2021.3122434 [22] 富月, 陈威. 具有解耦性能的离散时间线性多变量系统最优跟踪控制. 自动化学报, 2022, 48(8): 1931−1939Fu Y, Chen W. Optimal tracking control method for discrete-time linear multivariable systems with decoupling performance. Acta Automatica Sinica, 2022, 48(8): 1931−1939 [23] 宋君男. 双容水箱系统自适应解耦切换控制[硕士学位论文], 东北大学, 中国, 2012Song Jun-Nan. Adaptive Decoupling Switching Control on a Dual-tank Water System[Master thesis], Northeastern University, China, 2012 -

 下载:

计量
- 文章访问数: 4
- HTML全文浏览量: 2
- 被引次数: 0
